Related Experiment Video
Updated: Feb 15, 2026

Visualizing the Beating Heart in Drosophila
Published on: September 28, 2009
Force Tracking with Feed-Forward Motion Estimation for Beating Heart Surgery
Shelten G Yuen1, Douglas P Perrin2, Nikolay V Vasilyev2
1Harvard School of Engineering and Applied Sciences, Cambridge, MA 02138 USA.

Abstract:
The manipulation of fast moving, delicate tissues in beating heart procedures presents a considerable challenge to the surgeon. A robotic force tracking system can assist the surgeon by applying precise contact forces to the beating heart during surgical manipulation. Standard force control approaches cannot safely attain the required bandwidth for this application due to vibratory modes within the robot structure. These vibrations are a limitation even for single degree of freedom systems driving long surgical instruments. These bandwidth limitations can be overcome by incorporating feed-forward motion terms in the control law. For intracardiac procedures, the required motion estimates can be derived from 3D ultrasound imaging. Dynamic analysis shows that a force controller with feed-forward motion terms can provide safe and accurate force tracking for contact with structures within the beating heart. In vivo validation confirms that this approach confers a 50% reduction in force fluctuations when compared to a standard force controller and a 75% reduction in fluctuations when compared to manual attempts to maintain the same force.
Related Concept Videos
 01:10
Second Law: Motion under Same Force
Let's imagine a person is...
 01:17
Central-Force Motion
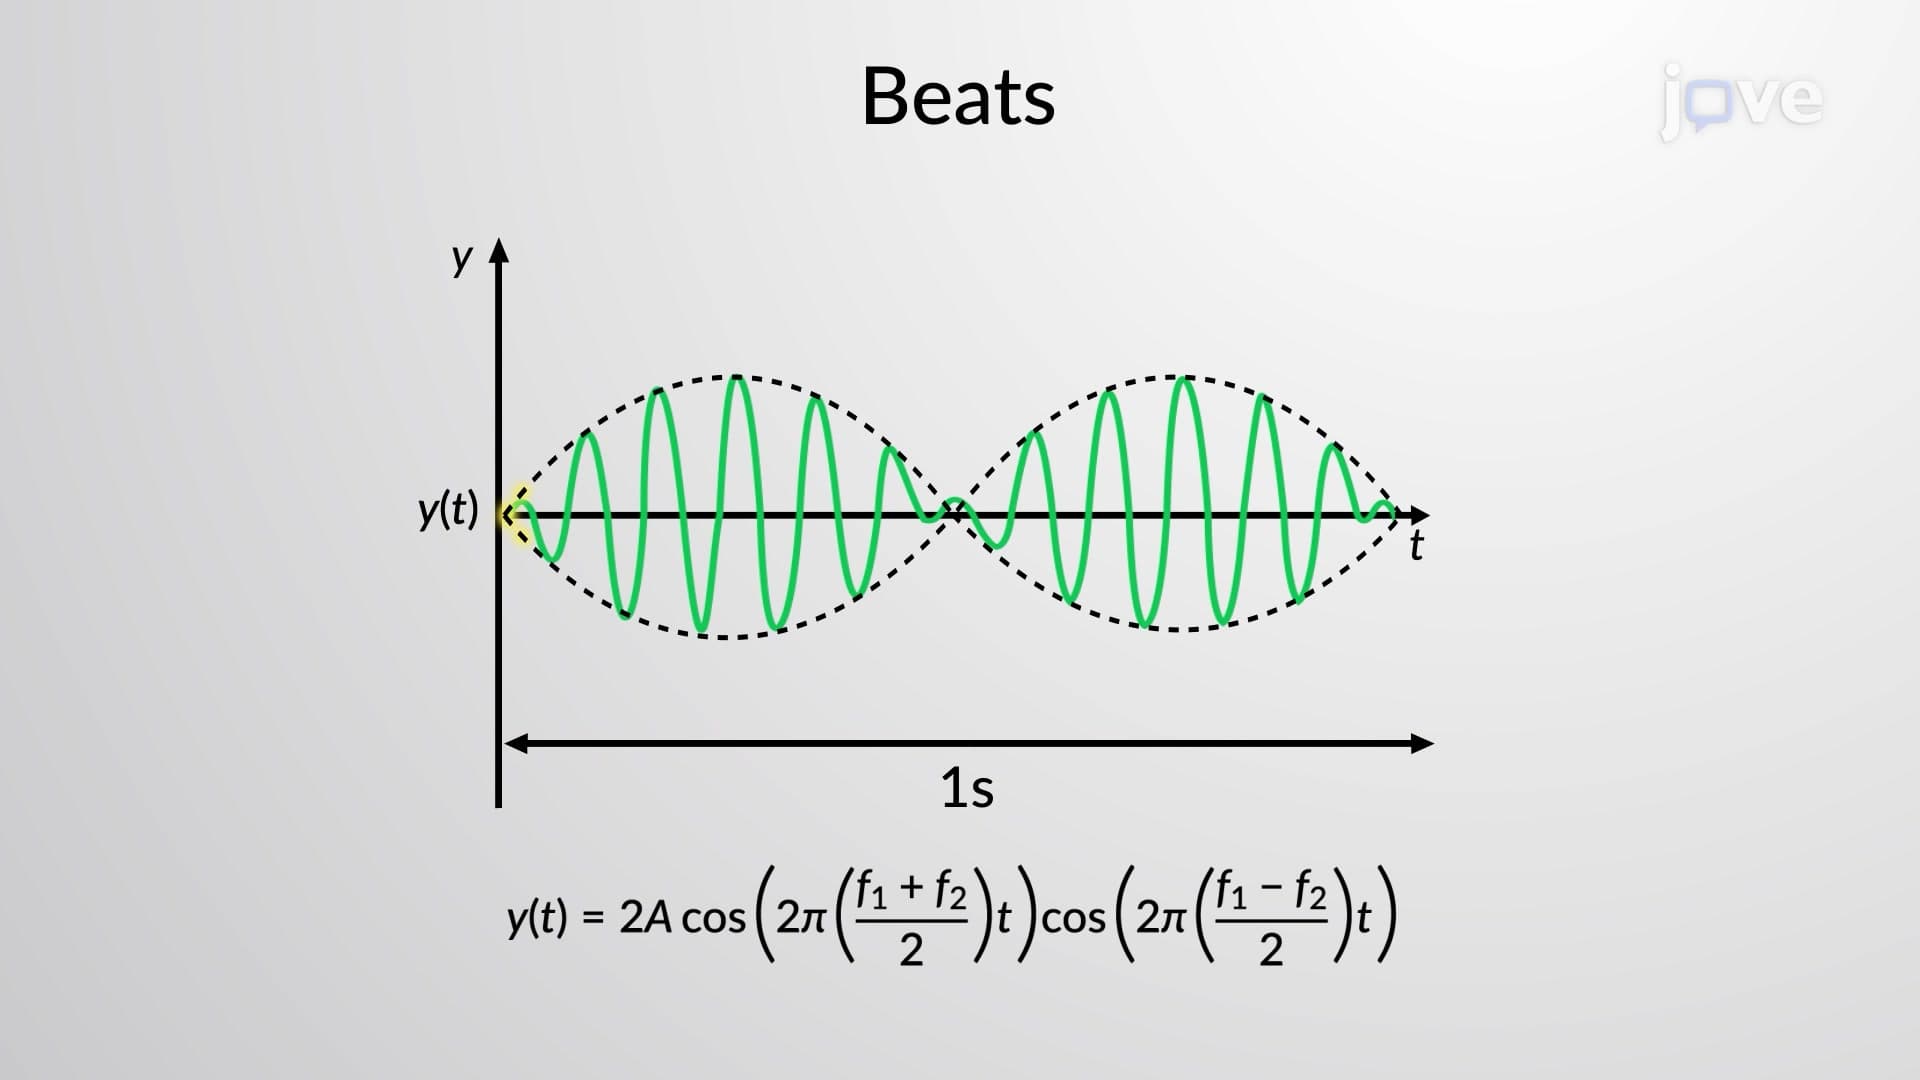 01:09
Beats
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 03:13
Intermolecular Forces
 02:36
Electromotive Force