An efficient algorithm for low-order direct discrete-time implementation of fractional order transfer functions
Related Experiment Video
Updated: Feb 15, 2026
The Participant-Reported Implementation Update and Score PRIUS: A Novel Method for Capturing Implementation-Related Data Over Time
Published on: February 19, 2021
Robin De Keyser1, Cristina I Muresan2, Clara M Ionescu3
1Ghent University, Research group DySC: Dynamical Systems and Control, Technologiepark 914, 9052, Ghent, Belgium.

Abstract:
Fractional order systems become increasingly popular due to their versatility in modelling and control applications across various disciplines. However, the bottleneck in deploying these tools in practice is related to their implementation on real-life systems. Numerical approximations are employed but their complexity no longer match the attractive simplicity of the original fractional order systems. This paper proposes a low-order, computationally stable and efficient method for direct approximation of general order (fractional order) systems in the form of discrete-time rational transfer functions, e.g. processes, controllers. A fair comparison to other direct discretization methods is presented, demonstrating its added value with respect to the state of art.
Related Concept Videos
 01:26
Discrete-time Fourier transform
One of the notable...
 01:16
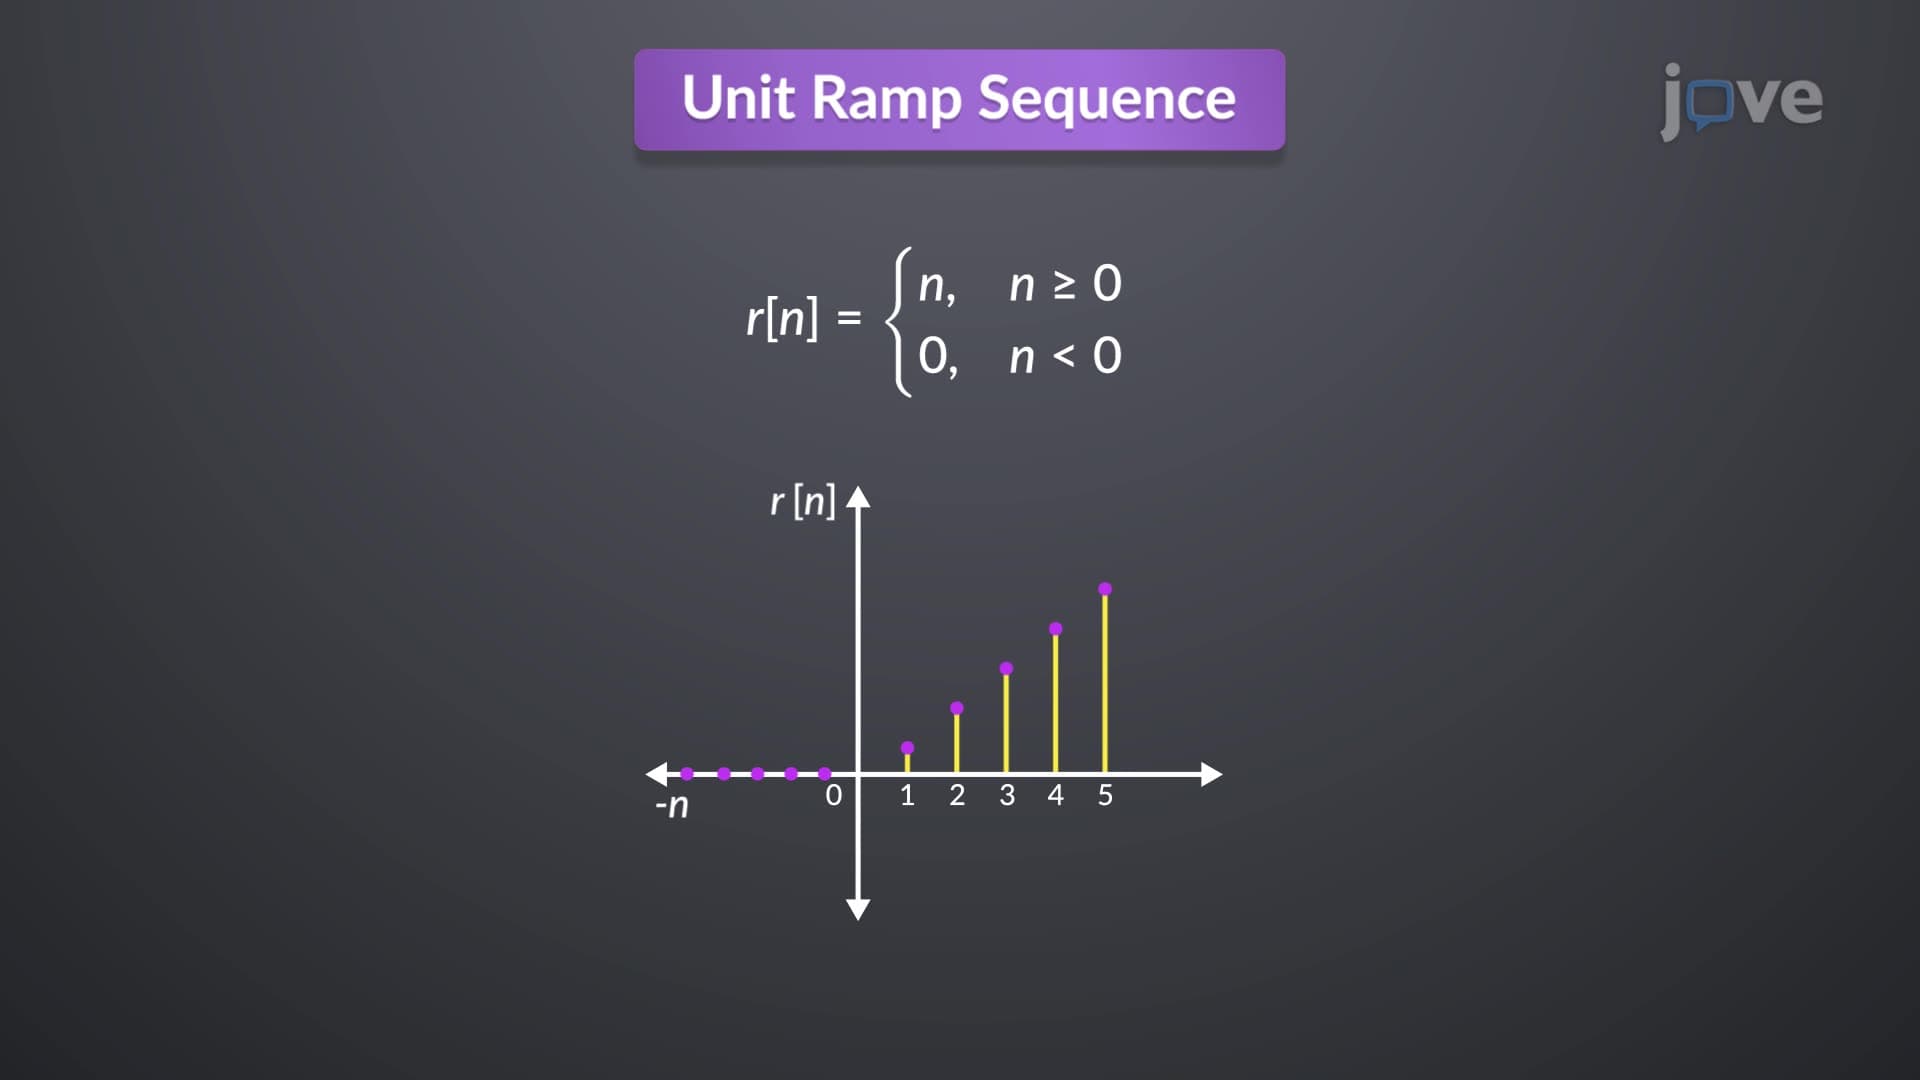
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
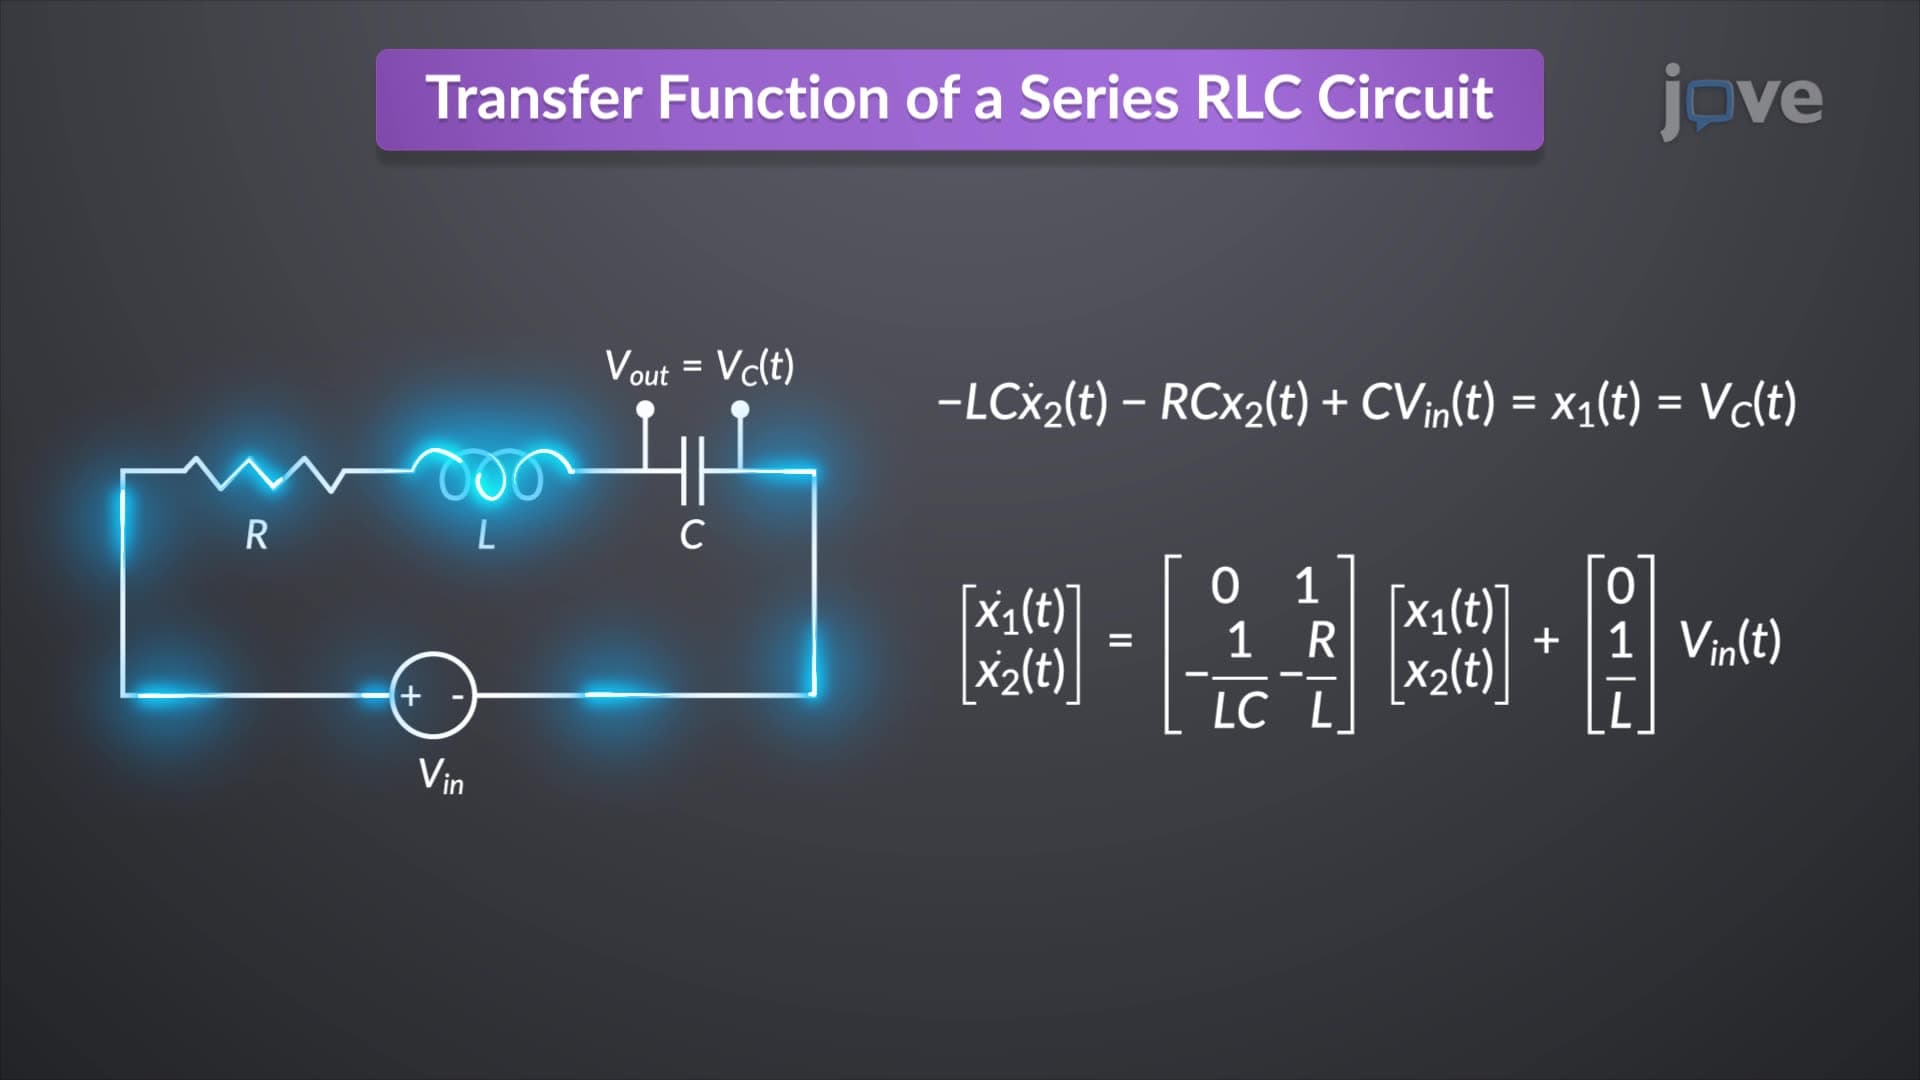
Transfer Function to State Space
In an RLC...
 01:21
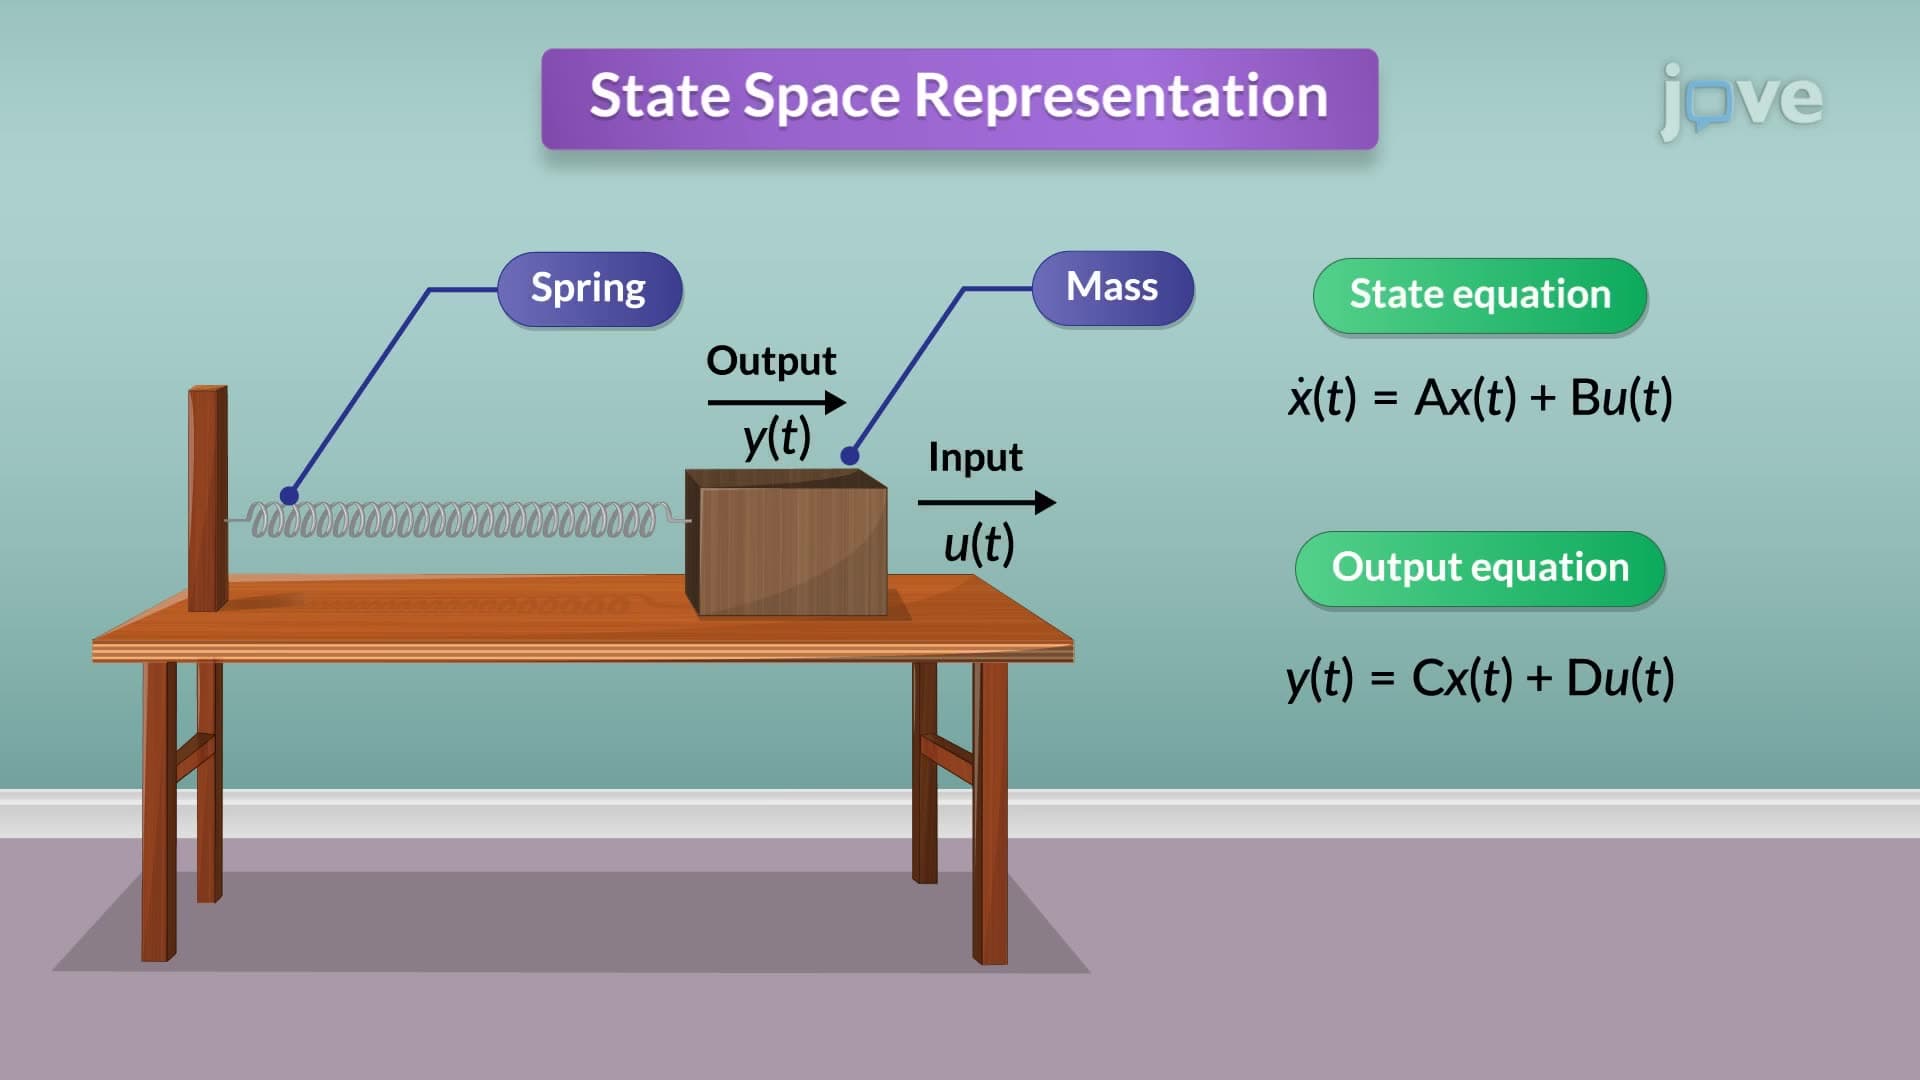
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: