Reconfigurable paramagnetic microswimmers: Brownian motion affects non-reciprocal actuation
Related Experiment Video
Updated: Feb 13, 2026
Free-form Light Actuators — Fabrication and Control of Actuation in Microscopic Scale
Published on: May 25, 2016
Di Du1, Elaa Hilou, Sibani Lisa Biswal
1Department of Chemical and Biomolecular Engineering, Rice University, 6100 Main St. MS 362, Houston, TX 77005, USA. biswal@rice.edu.

Abstract:
Swimming at low Reynolds number is typically dominated by a large viscous drag, therefore microscale swimmers require non-reciprocal body deformation to generate locomotion. Purcell described a simple mechanical swimmer at the microscale consisting of three rigid components connected together with two hinges. Here we present a simple microswimmer consisting of two rigid paramagnetic particles with different sizes. When placed in an eccentric magnetic field, this simple microswimmer exhibits non-reciprocal body motion and its swimming locomotion can be directed in a controllable manner. Additional components can be added to create a multibody microswimmer, whereby the particles act cooperatively and translate in a given direction. For some multibody swimmers, the stochastic thermal forces fragment the arm, which therefore modifies the swimming strokes and changes the locomotive speed. This work offers insight into directing the motion of active systems with novel time-varying magnetic fields. It also reveals that Brownian motion not only affects the locomotion of reciprocal swimmers that are subject to the Scallop theorem, but also affects that of non-reciprocal swimmers.
Related Concept Videos
 01:30
Paramagnetism
 01:28
Factors Influencing Attraction IV: Reciprocity
 01:22
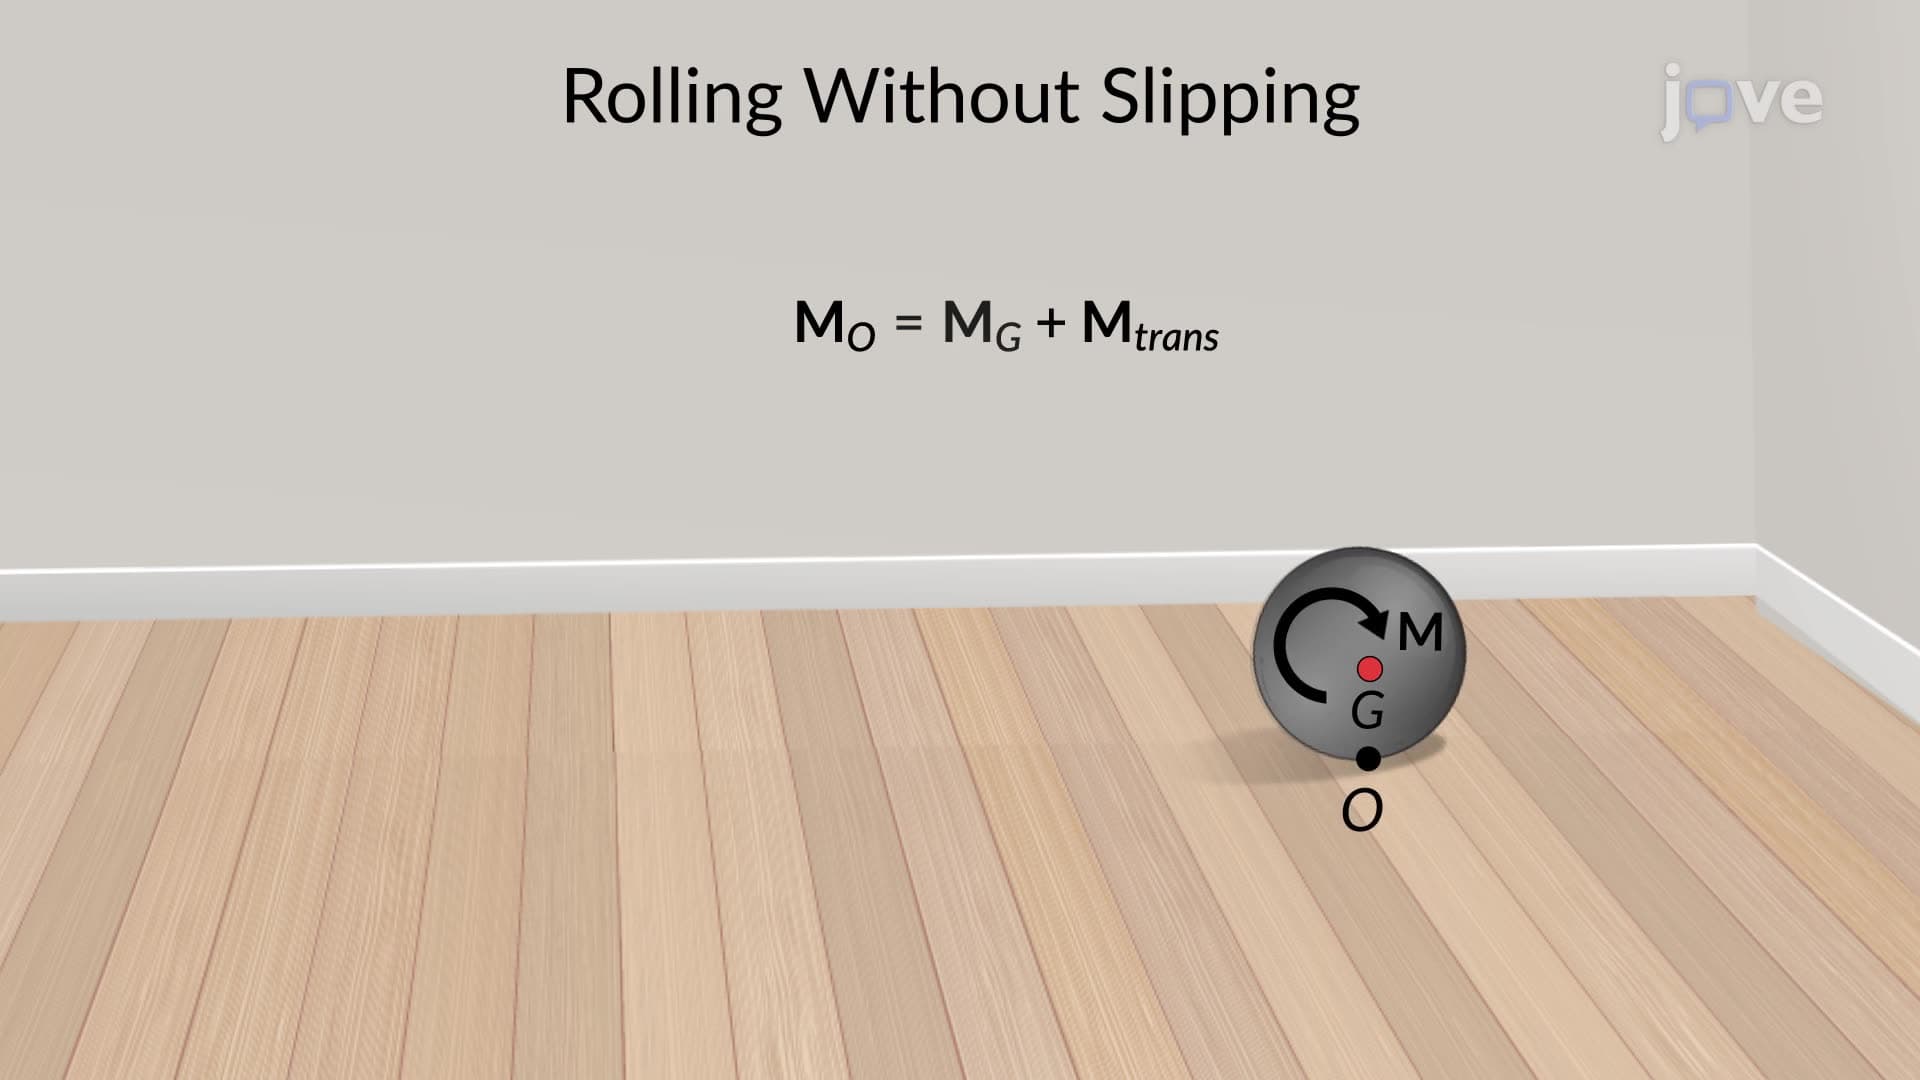
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:18
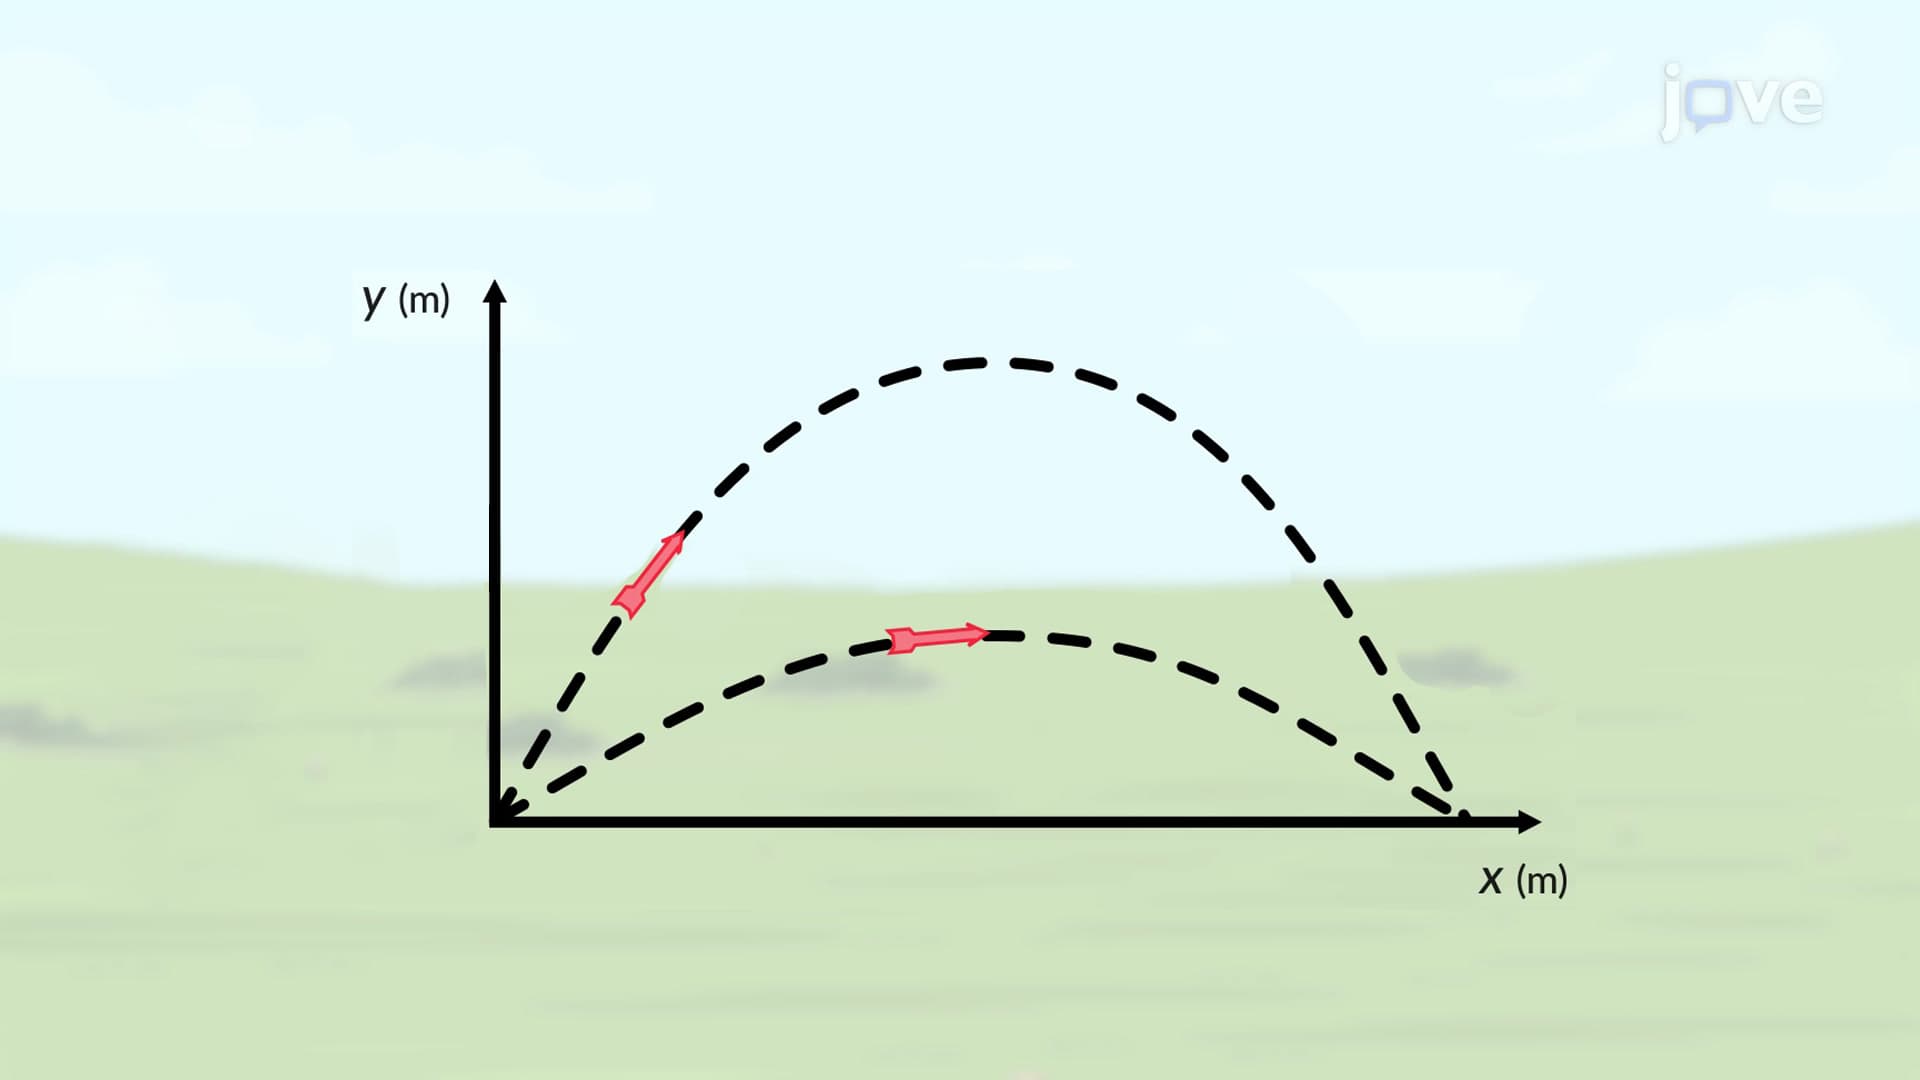
Projectile Motion: Example
When we speak of the range (R) of a projectile on...