Robotic-assisted surgery in ophthalmology
Related Experiment Video
Updated: Feb 13, 2026
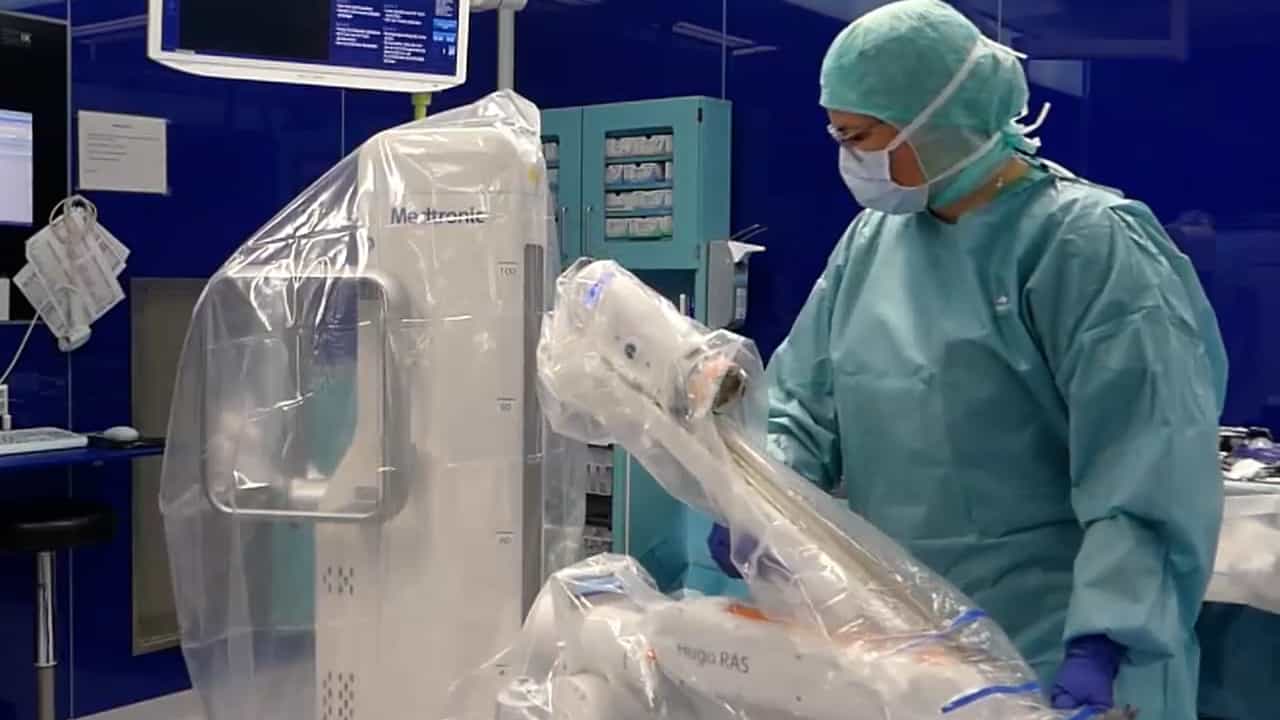
Robotics in Surgery: A Modular Robotic Platform Driven Gastric Wedge Resection
Published on: February 7, 2025
Marc D de Smet1,2, Gerrit J L Naus1, Koorosh Faridpooya3
1Preceyes BV, Eindhoven, the Netherlands.

Purpose Of Review:
Provide an overview of the current landscape of robotics in ophthalmology, including the pros and cons of system designs, the clinical development path, and the likely future direction of the field.
Recent Findings:
Robots designed for eye surgery should meet certain basic requirements. Three designs are currently being developed: smart surgical tools such as the steady hand, comanipulation devices and telemanipulators using either a fixed or virtual remote center of motion. Successful human intraocular surgery is being performed using the Preceyes surgical system. Another telemanipulation robot, the da Vinci Surgical System, has been used to perform a pterygium repair in humans and was successful in ex-vivo corneal surgery despite its nonophthalmic design. Apart from Preceyes' BV research platform, none of the currently eye-specific systems has reached a commercial stage. Systems are likely to evolve from robotic assistance during specific procedural steps to semiautonomous surgery, as smart sensors are introduced to enhance the basic functionalities of robotic systems.
Summary:
Robotics is still in its infancy in ophthalmology but is rapidly reaching a stage wherein it will be introduced into everyday ophthalmic practice. It will most likely be introduced first for demanding vitreo-retinal procedures, followed by anterior segment applications.
Related Concept Videos
 01:08
Matrix-Assisted Laser Desorption Ionization (MALDI)
 02:09
Bystander Effect
 02:41
Protein Complex Assembly
Many viruses self-assemble into a fully functional unit using the infected host cell to...
 01:32
RNA Splicing
 01:55
Egoism and Altruism
 03:00
Self-Evaluation: Self-Enhancement and Self-Verification