Related Experiment Video
Updated: Feb 12, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Accurate Object Pose Estimation Using Depth Only
1Graduate School of Information Sciences, Tohoku University, Aramaki Aza Aoba 6-6-01, Aoba-Ku, Sendai 980-8579, Japan. li.mingyu.s8@dc.tohoku.ac.jp.

Abstract:
Object recognition and pose estimation is an important task in computer vision. A pose estimation algorithm using only depth information is proposed in this paper. Foreground and background points are distinguished based on their relative positions with boundaries. Model templates are selected using synthetic scenes to make up for the point pair feature algorithm. An accurate and fast pose verification method is introduced to select result poses from thousands of poses. Our algorithm is evaluated against a large number of scenes and proved to be more accurate than algorithms using both color information and depth information.
More Related Videos
 15:25
Tomato Analyzer: A Useful Software Application to Collect Accurate and Detailed Morphological and Colorimetric Data from Two-dimensional Objects
Published on: March 16, 2010
 14:38
Creating Objects and Object Categories for Studying Perception and Perceptual Learning
Published on: November 2, 2012
Related Concept Videos
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:18
Velocity of an Object
 01:27
Uniform Depth Channel Flow
 01:15
Depth Perception and Spatial Vision
 01:20
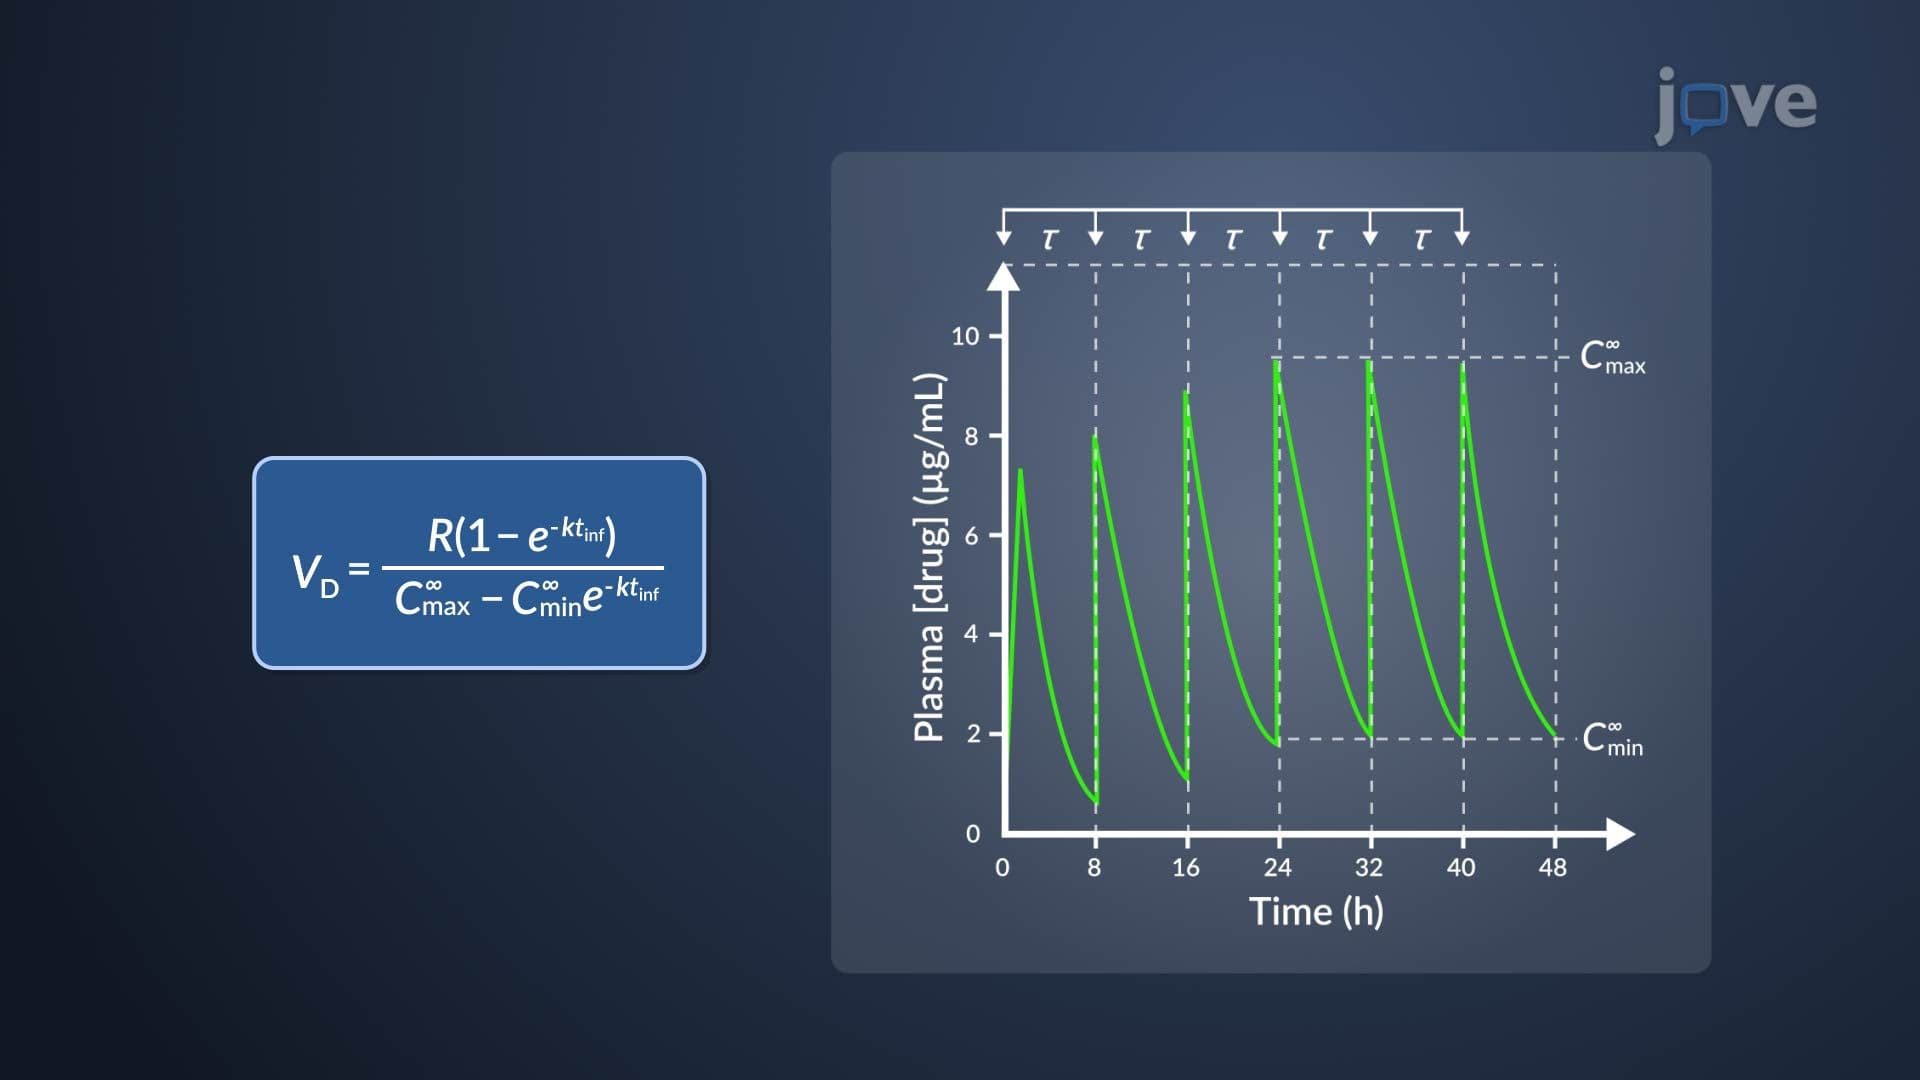
Estimation of k and VD of Aminoglycosides
 01:18
Uniform Depth Channel Flow: Problem Solving