Related Experiment Video
Updated: Feb 12, 2026
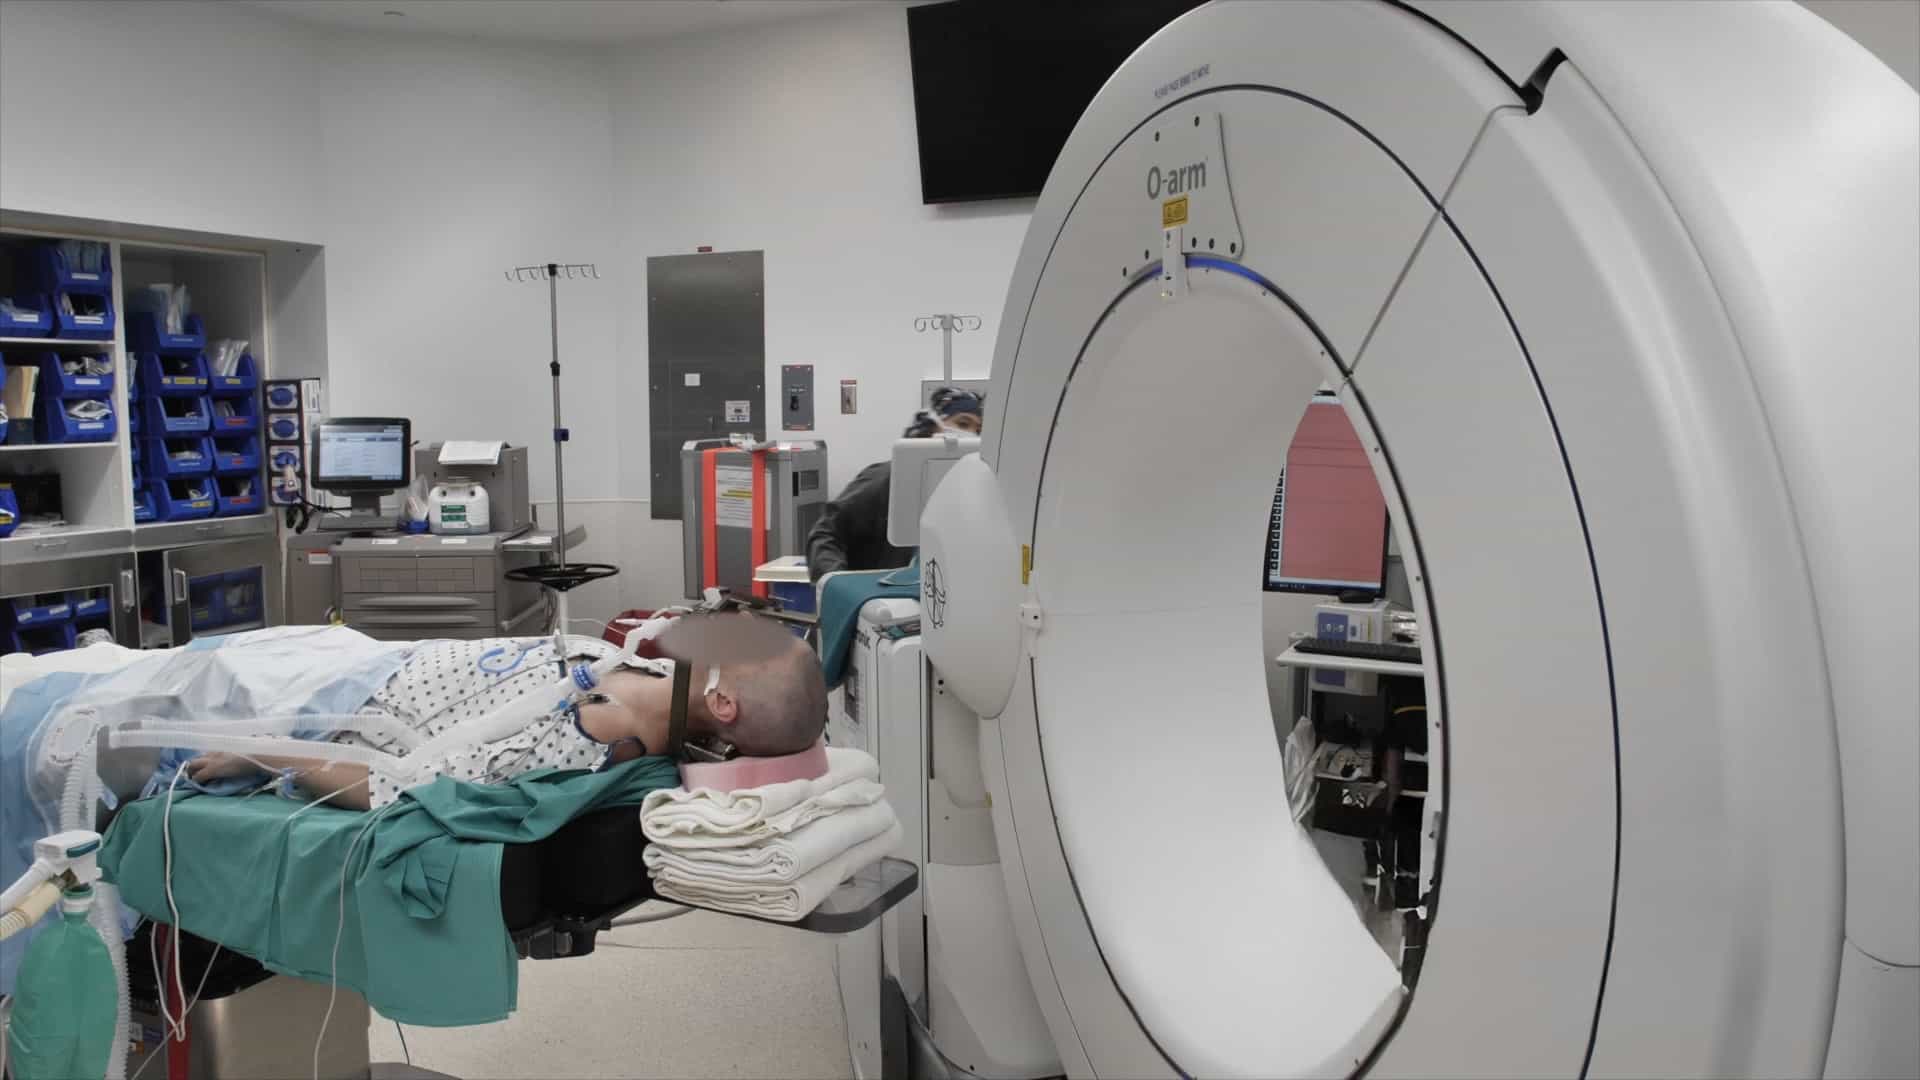

Robotic-Guided Stereoelectroencephalography for Invasive Epilepsy Monitoring
Published on: June 13, 2025
Evaluation of a CT-Guided Robotic System for Precise Percutaneous Needle Insertion
Eliel Ben-David1, Moran Shochat2, Ido Roth2
1Department of Diagnostic Imaging, Hadassah Hebrew University Medical Center, POB 12000, Ein Kerem, Jerusalem 9112001, Israel.

Purpose:
To assess overall targeting accuracy for CT-guided needle insertion using prototype robotic system for common target sites.
Materials And Methods:
Using CT guidance, metallic (2 × 1 mm) targets were embedded in retroperitoneum (n = 8), kidneys (n = 8), and liver (n = 14) of 8 Yorkshire pigs (55-65 kg). Bronchial bifurcations were targeted in the lung (n = 13). CT datasets were obtained for planning and controlled needle placement of commercially available 17- to 19-gauge needles (length 15-20 cm) using a small, patient-mounted, CT-guided robotic system with 5° of motion. Mean distance to target was 92.9 mm ± 19.7 (range, 64-146 mm). Planning included selection of target, skin entry point, and 4.6 ± 1.3 predetermined checkpoints (range, 2-9) where additional CT imaging was performed to permit stepwise correction of needle trajectory path as needed. Scanning and needle advancement were coordinated with breath motion using respiratory gating. Accuracy was assessed as distance from needle tip to predefined target.
Results:
Of 45 needle insertions performed, 2 were unsuccessful owing to technical issues. Accuracy of targeting was 1.2-1.4 mm ± 0.6 for kidney, retroperitoneum, and lung (P = .51), with 2.9 mm ± 1.9 accuracy for liver (P = .0003). This was achieved in 39 cases (91%) using a single insertion. Intraprocedural target movement was detected (3.5 mm ± 2.1 in retroperitoneum and 6.4 mm ± 3.9 in liver); the system compensated for 52.9% ± 30.3 of this movement. One pneumothorax was the only complication (8%).
Conclusions:
Accurate needle insertion (< 3 mm error) can be achieved in common target sites when using a CT-guided robotic system. Stepwise checks with corrective angulation can potentially overcome issues of target movement during a procedure from organ deformity and other causes.

Related Concept Videos
 03:37
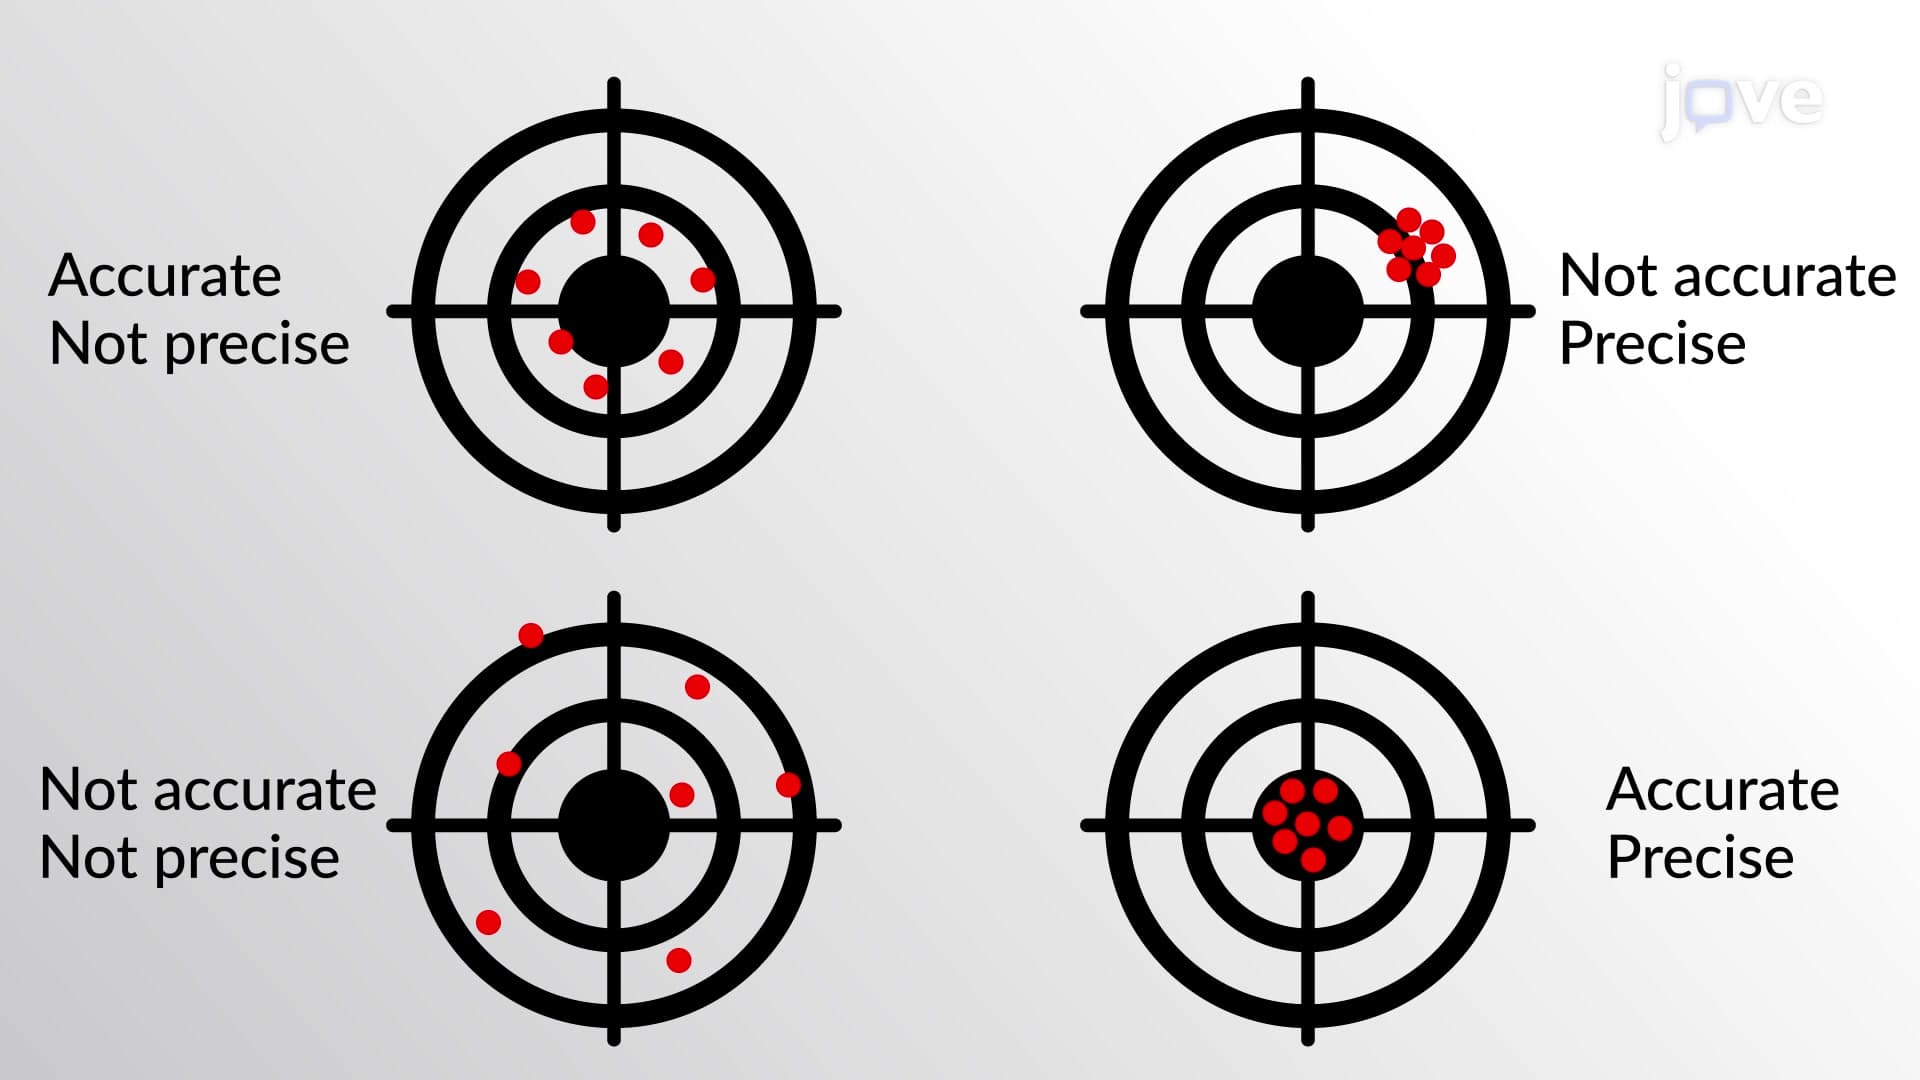
Uncertainty in Measurement: Accuracy and Precision
 01:52
Accuracy and Precision
 01:30
Radiological Investigation I: X-ray and CT
 01:14
Imaging Studies I: CT and MRI
Description of the Procedures
Computed Tomography (CT) scan:
Computed Tomography (CT) scans use X-ray technology to generate detailed images of bones, organs, and tissues. During the scan, the patient lies on a moving table...
 01:27
The Precise Definition of a Limit
 01:28
Imaging Studies for Cardiovascular System V: CT