Discrete fringe phase unwrapping algorithm based on Kalman motion estimation for high-speed I/Q-interferometry
Related Experiment Video
Updated: Feb 11, 2026

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013

Abstract:
A discrete fringe phase unwrapping algorithm (DFPUA) based on Kalman motion estimation is proposed to accurately demodulate the phases of I/Q-interferometers with deeply under-sampled quadrature signals, thus to break through the limitations of the Nyquist frequency for high-speed measurement. The basic concept of DFPUA is to estimate the current displacement according to the former motion state, then confirm the actual phase integer number by comparing the estimated phase decimal with the actual phase decimal; in this way, peak acceleration/jerk instead of peak velocity becomes the factor that determines the sampling rate. Two types of DFPUA including velocity estimation and velocity-acceleration estimation are illustrated in detail. Simulation experiment results indicate that the DFPUA realizes a significant reduction in the sampling rate and the amount of data for low frequency vibration measurement, proposing a practical approach for high-speed and long-time measurement such as ultra-low frequency vibration calibration.
More Related Videos
 06:31
Estimating Vestibular Perceptual Thresholds Using a Six-Degree-Of-Freedom Motion Platform
Published on: August 4, 2022
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:15
Discrete Fourier Transform
 01:12
Trial and Error and Algorithm
 01:26
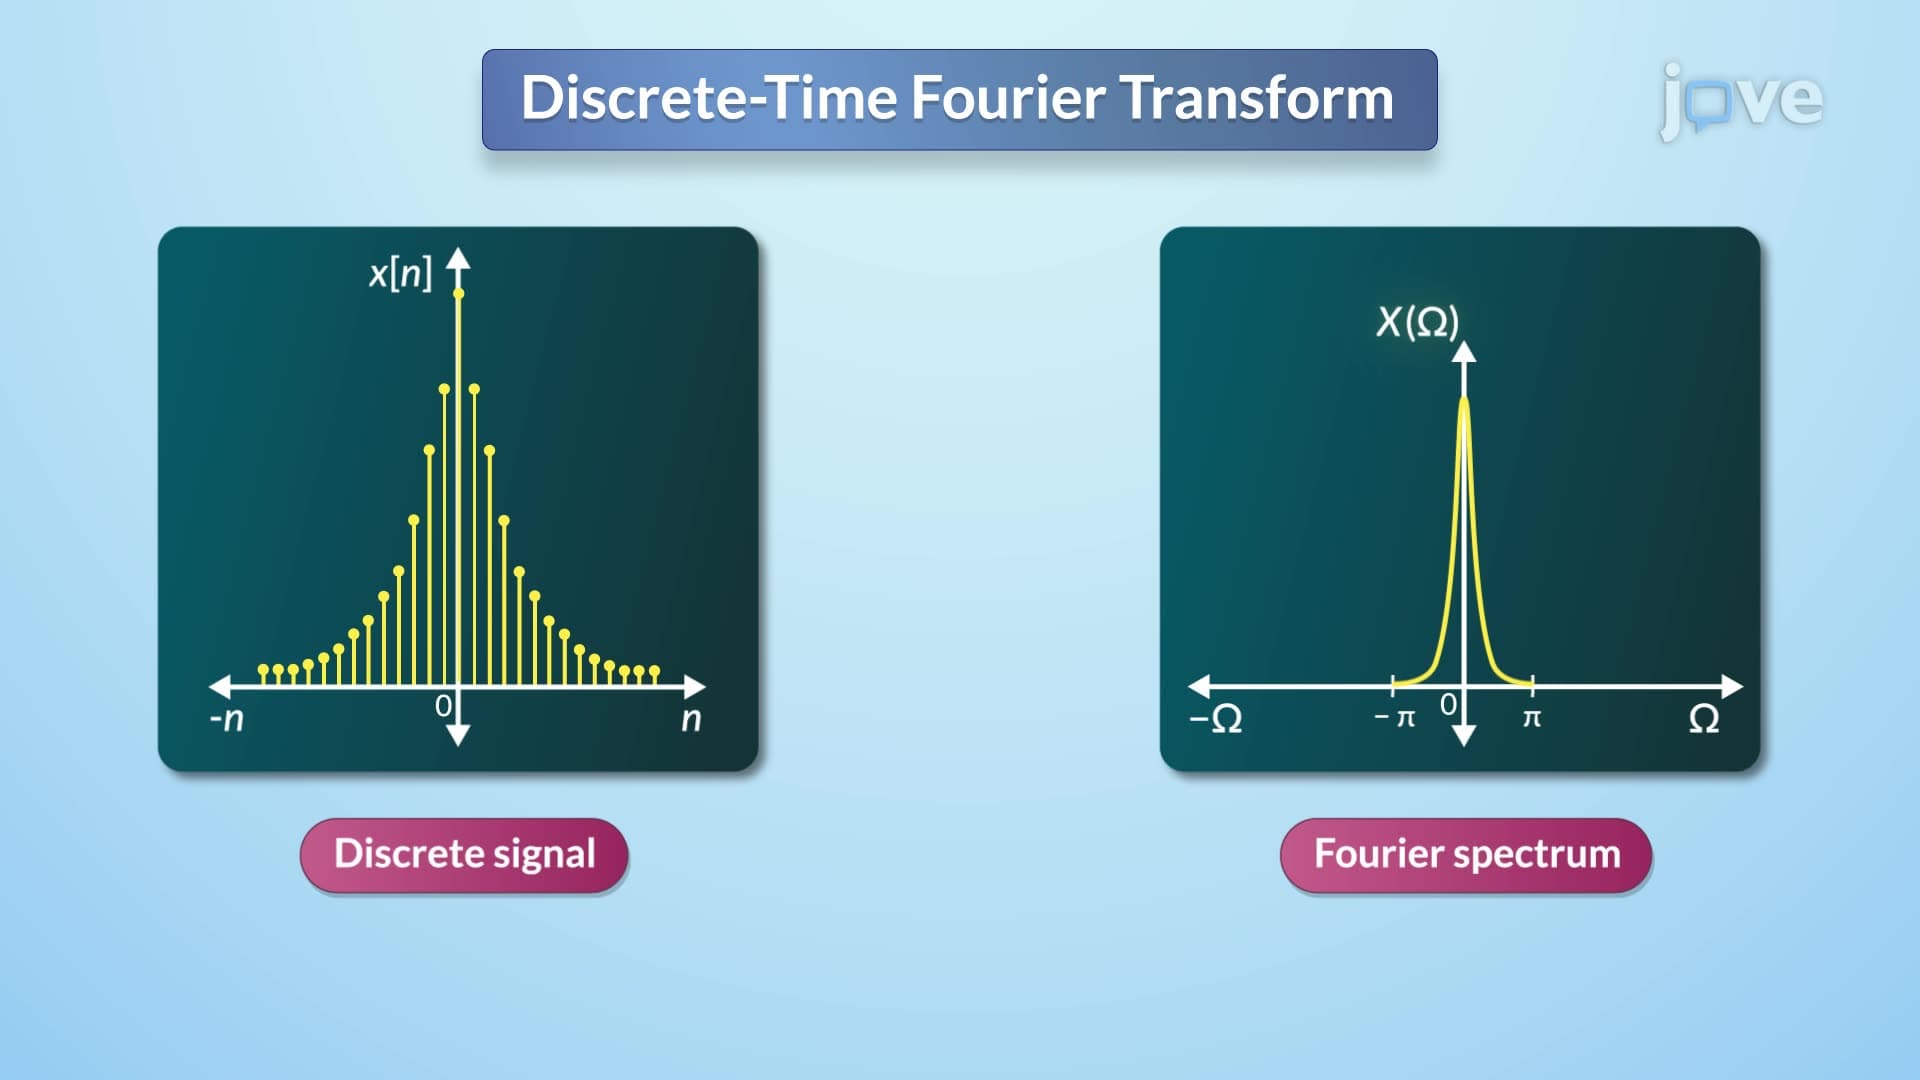
Discrete-time Fourier transform
One of the notable...
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:16
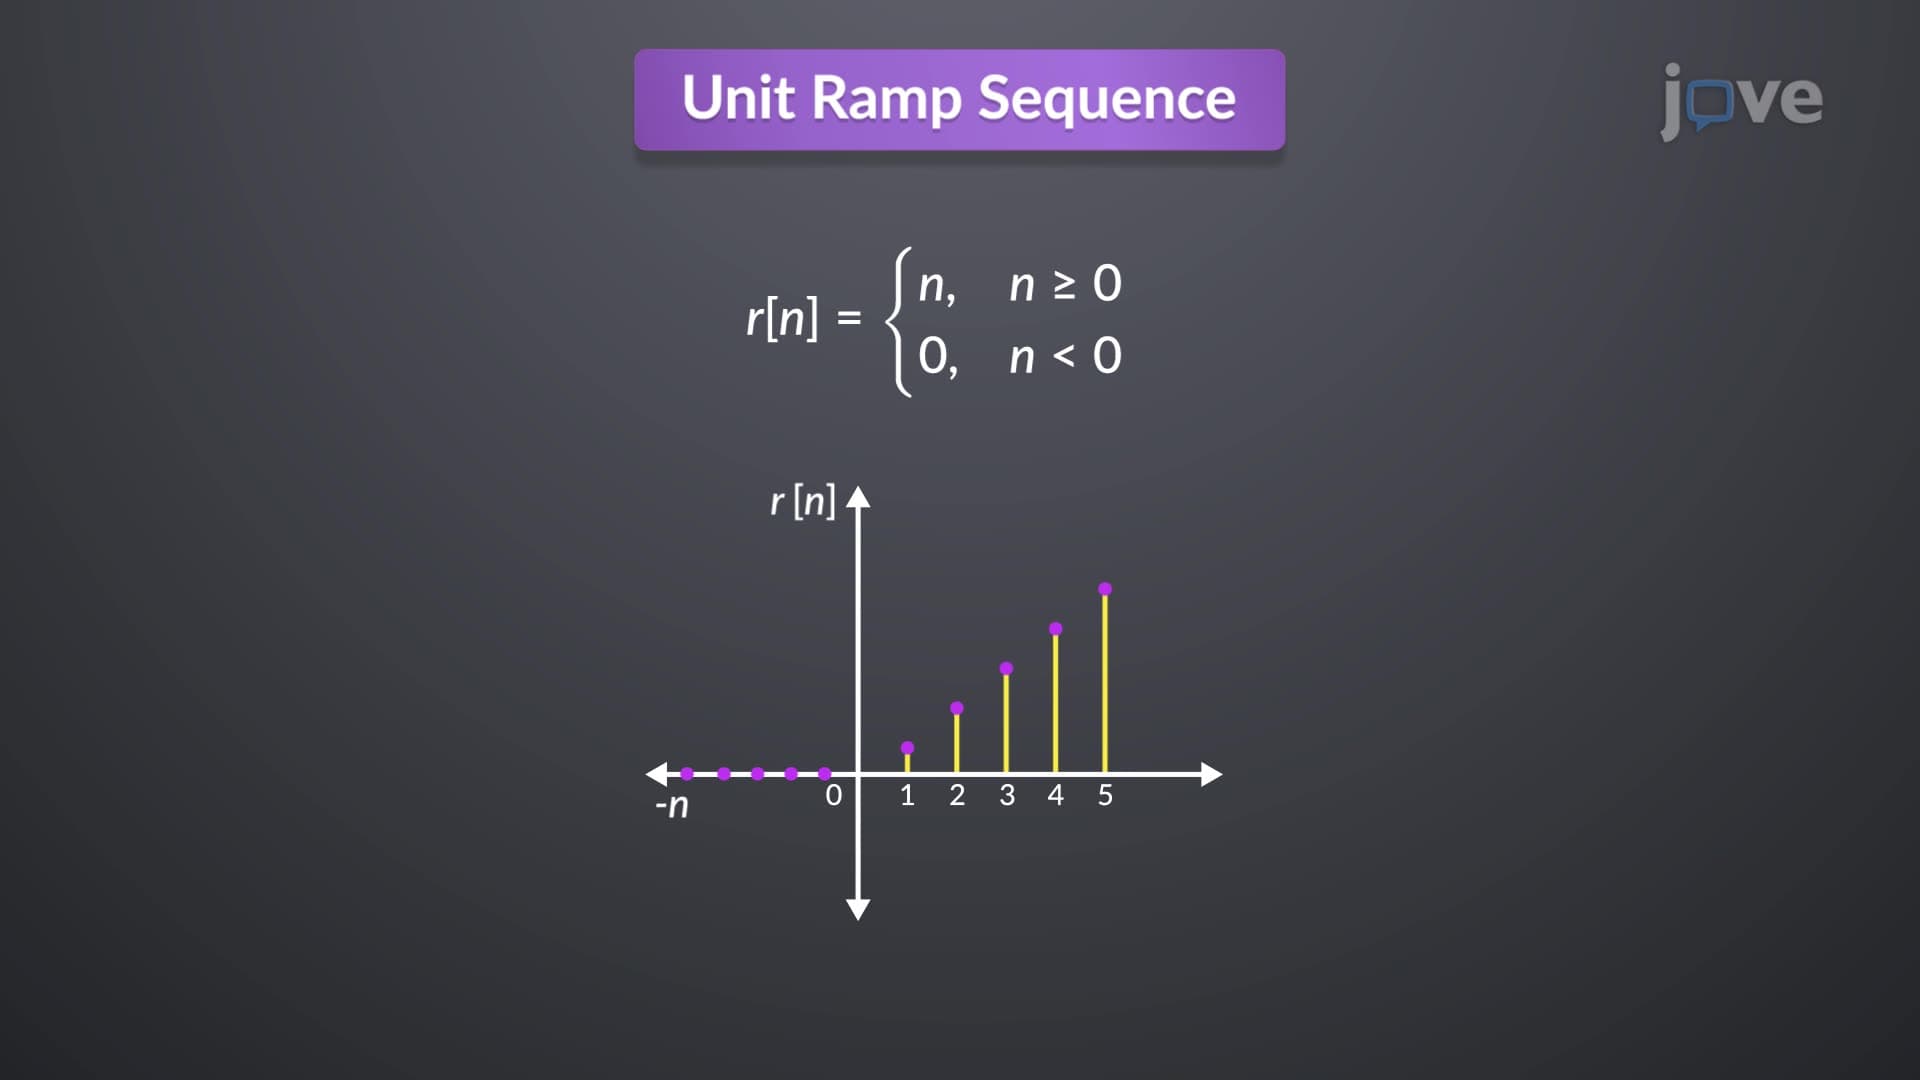
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...