Related Experiment Video
Updated: Feb 10, 2026

3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
Spine and lower extremity kinematics during gait in patients with cervical spondylotic myelopathy
Ram Haddas1, Sujal Patel2, Raj Arakal3
1Texas Back Institute Research Foundation, 6020 West Parker Rd, Plano, TX 75093, USA.

Background Context:
Cervical spondylotic myelopathy (CSM) typically manifests with a slow, progressive stepwise decline in neurologic function, including hand clumsiness and balance difficulties. Gait disturbances are frequently seen in patients with CSM, with more advanced cases exhibiting a stiff, spastic gait.
Purpose:
To evaluate the spatiotemporal parameters and spine and lower extremity kinematics during the gait cycle of adult patients with CSM before surgical intervention.
Study Design:
Prospective cohort study.
Patient Sample:
Twenty-eight subjects with symptomatic CSM who have been scheduled for surgery and 30 healthy controls (HC).
Outcome Measures:
Spine and lower extremity kinematics and spatiotemporal parameters.
Methods:
Clinical gait analysis was performed for patients with CSM and HC. The data were analyzed with a one-way analysis of variance.
Results:
Patients with CSM have significantly more anterior pelvis tilt (CSM: 13.97°, HC: 5.56°), larger lumbar lordosis (CSM: 8.59°, HC: 2.7°), smaller cervical lordosis (CSM: 6.02°, HC: 11.35°), and less head flexion (CSM: 0.69°, HC: 8.66°) at the beginning of the gait cycle. There was a decrease in knee range of motion in patients with CSM compared with controls (CSM: 36.31°, HC: 50.17°). Furthermore, patients with CSM presented with slower walking speed (CSM: 0.81 m/s, HC: 1.05 m/s), decreased cadence (CSM: 95.57 step/m, HC: 107.64 step/m), increased double support time (CSM: 0.40 s, HC: 0.28 s) and stride time (CSM:1.28 s, HC: 1.13 s), shorter stride length (CSM: 1.04 m, HC: 1.18 m) and step length (CSM:0.51 m, HC: 0.58 m), and wider width (CSM: 0.14 m, HC:0.11 m).
Conclusions:
Our study shows that patients with CSM enter the gait cycle with a larger anterior pelvic tilt and lumbar lordosis as well as less cervical lordosis and head flexion. As a consequence of these abnormal spinal parameters at the onset of the gait cycle, lower extremity biomechanics are also altered. Our study is the first to demonstrate the relationship between aberrant spinal alignment and lower extremity function. Identification of this interrelationship as well as the specific gait and biomechanical disturbances seen in myelopathic patients can both inform our understanding of the disease and tailor rehabilitation protocols.
More Related Videos
 08:45
Kinematic Analysis Using 3D Motion Capture of Drinking Task in People With and Without Upper-extremity Impairments
Published on: March 28, 2018
 07:44
Evaluation of Patients' Posture and Gait Profile After Lumbar Fusion Surgery by Video Rasterstereography and Treadmill Gait Analysis
Published on: March 23, 2019
Related Concept Videos
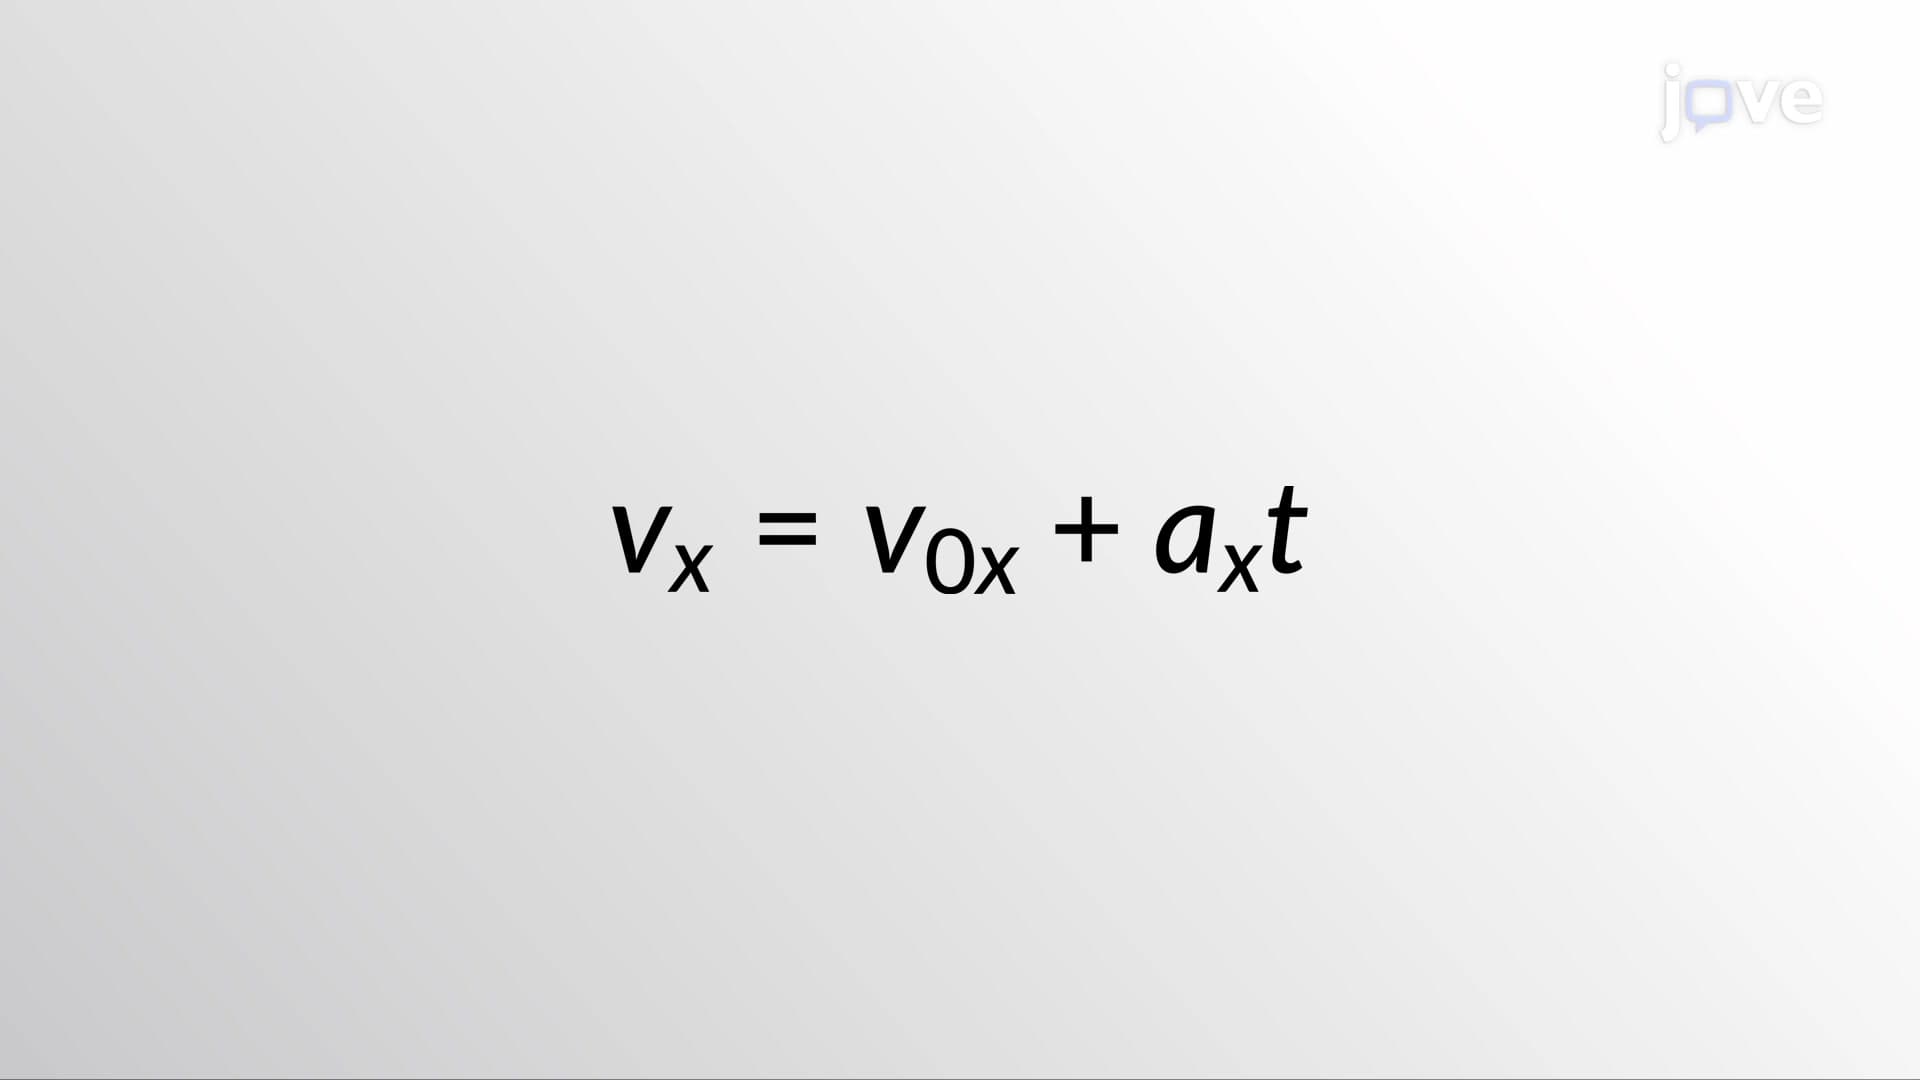 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:22
Absolute and Local Extreme Values
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving