A Subject-Specific Kinematic Model to Predict Human Motion in Exoskeleton-Assisted Gait
Related Experiment Video
Updated: Feb 10, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Diego Torricelli1, Camilo Cortés2, Nerea Lete2
1Cajal Institute, Spanish National Research Council (Consejo Superior de Investigaciones Científicas), Madrid, Spain.

Abstract:
The relative motion between human and exoskeleton is a crucial factor that has remarkable consequences on the efficiency, reliability and safety of human-robot interaction. Unfortunately, its quantitative assessment has been largely overlooked in the literature. Here, we present a methodology that allows predicting the motion of the human joints from the knowledge of the angular motion of the exoskeleton frame. Our method combines a subject-specific skeletal model with a kinematic model of a lower limb exoskeleton (H2, Technaid), imposing specific kinematic constraints between them. To calibrate the model and validate its ability to predict the relative motion in a subject-specific way, we performed experiments on seven healthy subjects during treadmill walking tasks. We demonstrate a prediction accuracy lower than 3.5° globally, and around 1.5° at the hip level, which represent an improvement up to 66% compared to the traditional approach assuming no relative motion between the user and the exoskeleton.
Related Concept Videos
 01:13
Sensitivity, Specificity, and Predicted Value
Sensitivity is the...
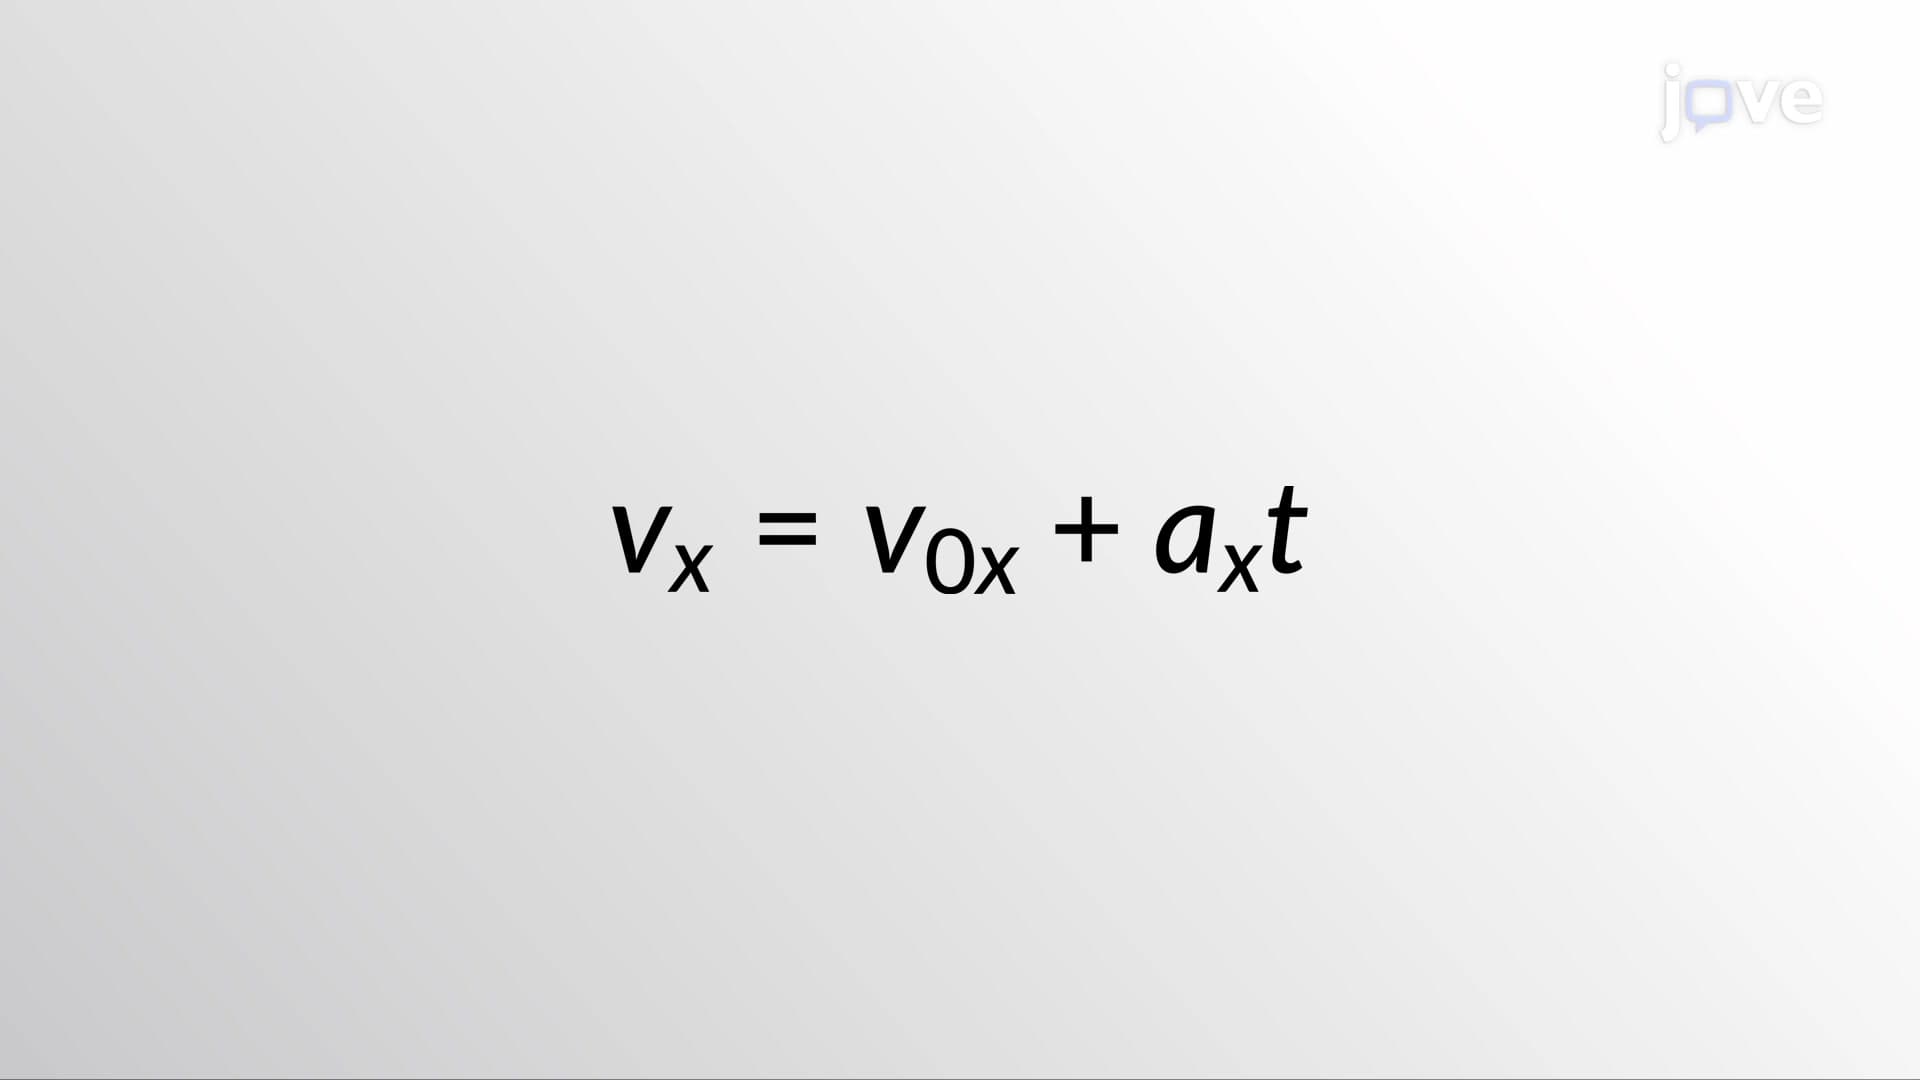 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 02:27
Predicting Molecular Geometry
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...