Local interactions underlying collective motion in human crowds
Related Experiment Video
Updated: Feb 10, 2026
In Vitro Model of Human Cutaneous Hypertrophic Scarring using Macromolecular Crowding
Published on: May 1, 2020
Kevin W Rio1, Gregory C Dachner1, William H Warren2
1Department of Cognitive, Linguistic and Psychological Sciences, Brown University, Providence, RI 02912, USA.

Abstract:
It is commonly believed that global patterns of motion in flocks, schools and crowds emerge from local interactions between individuals, through a process of self-organization. The key to explaining such collective behaviour thus lies in deciphering these local interactions. We take an experiment-driven approach to modelling collective motion in human crowds. Previously, we observed that a pedestrian aligns their velocity vector (speed and heading direction) with that of a neighbour. Here we investigate the neighbourhood of interaction in a crowd: which neighbours influence a pedestrian's behaviour, how this depends on neighbour position, and how the influences of multiple neighbours are combined. In three experiments, a participant walked in a virtual crowd whose speed and heading were manipulated. We find that neighbour influence is linearly combined and decreases with distance, but not with lateral position (eccentricity). We model the neighbourhood as (i) a circularly symmetric region with (ii) a weighted average of neighbours, (iii) a uni-directional influence, and (iv) weights that decay exponentially to zero by 5 m. The model reproduces the experimental data and predicts individual trajectories in observational data on a human 'swarm'. The results yield the first bottom-up model of collective crowd motion.

Related Concept Videos
 01:22
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:18
Projectile Motion: Example
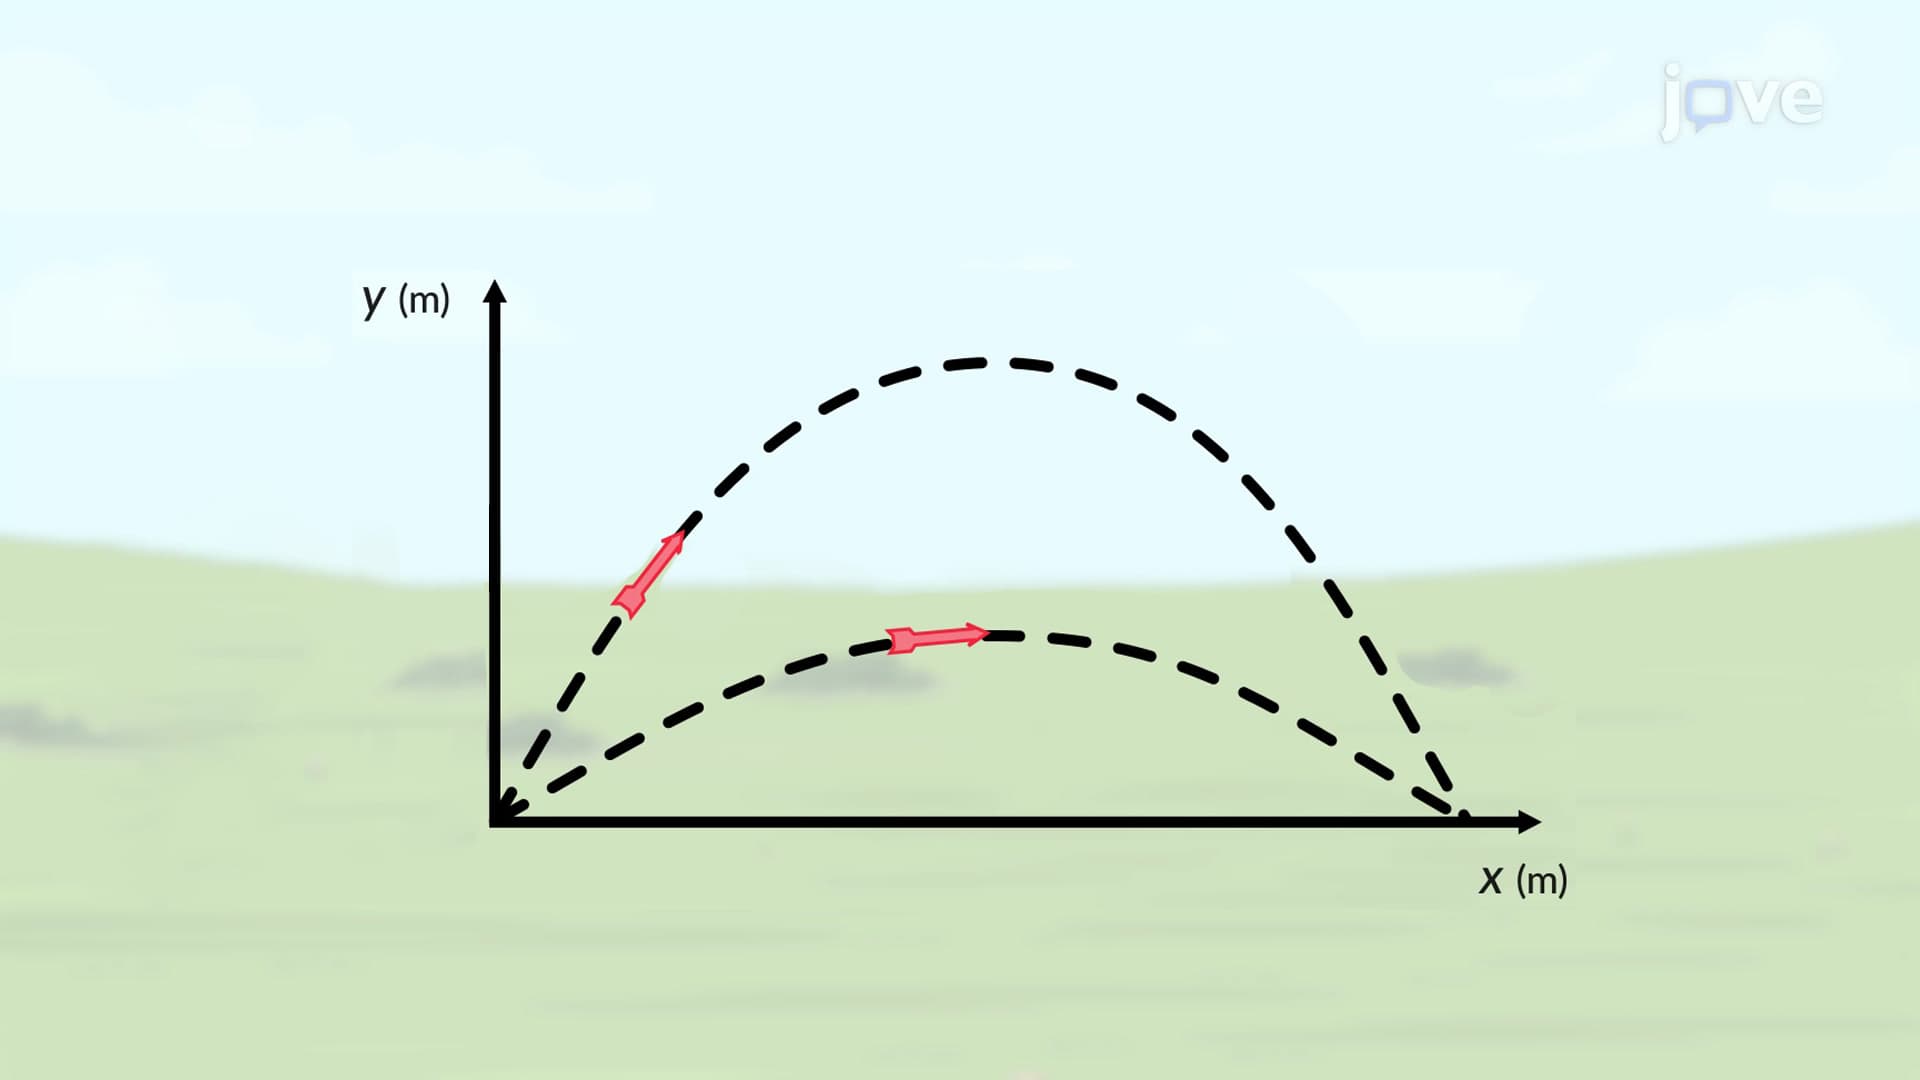
When we speak of the range (R) of a projectile on...
 01:42
Simple Harmonic Motion and Uniform Circular Motion
There is an easy way to produce simple harmonic motion by using uniform circular motion. For instance, consider a ball attached to a uniformly rotating...
 01:15
Torque Free Motion