Related Experiment Video
Updated: Feb 10, 2026

A Mouse Model of Lumbar Spine Instability
Published on: April 23, 2021
Effects of Spine Motion on Foot Slip in Quadruped Bounding
Dongliang Chen1, Ningjie Li1, Guifang Liu1
1College of Mechanical and Electrical Engineering, Harbin Engineering University, Harbin 150001, China.

Abstract:
Translation and bend of the spine in the sagittal plane during high-speed quadruped running were investigated. The effect of the two spine motions on slip between the foot and the ground was also explored. First, three simplified sagittal plane models of quadruped mammals were studied in symmetric bounding. The first model's trunk allowed no relative motion, the second model allowed only trunk bend, and the third model allowed both bend and translation. Next, torque was introduced to equivalently replace spine motion and the possibility of foot slip of the three models was analyzed theoretically. The results indicate that the third model has the least possibility of slip. This conclusion was further confirmed by simulation experiments. Finally, the conclusion was verified by the reductive model crawling robot.
Related Concept Videos
 01:09
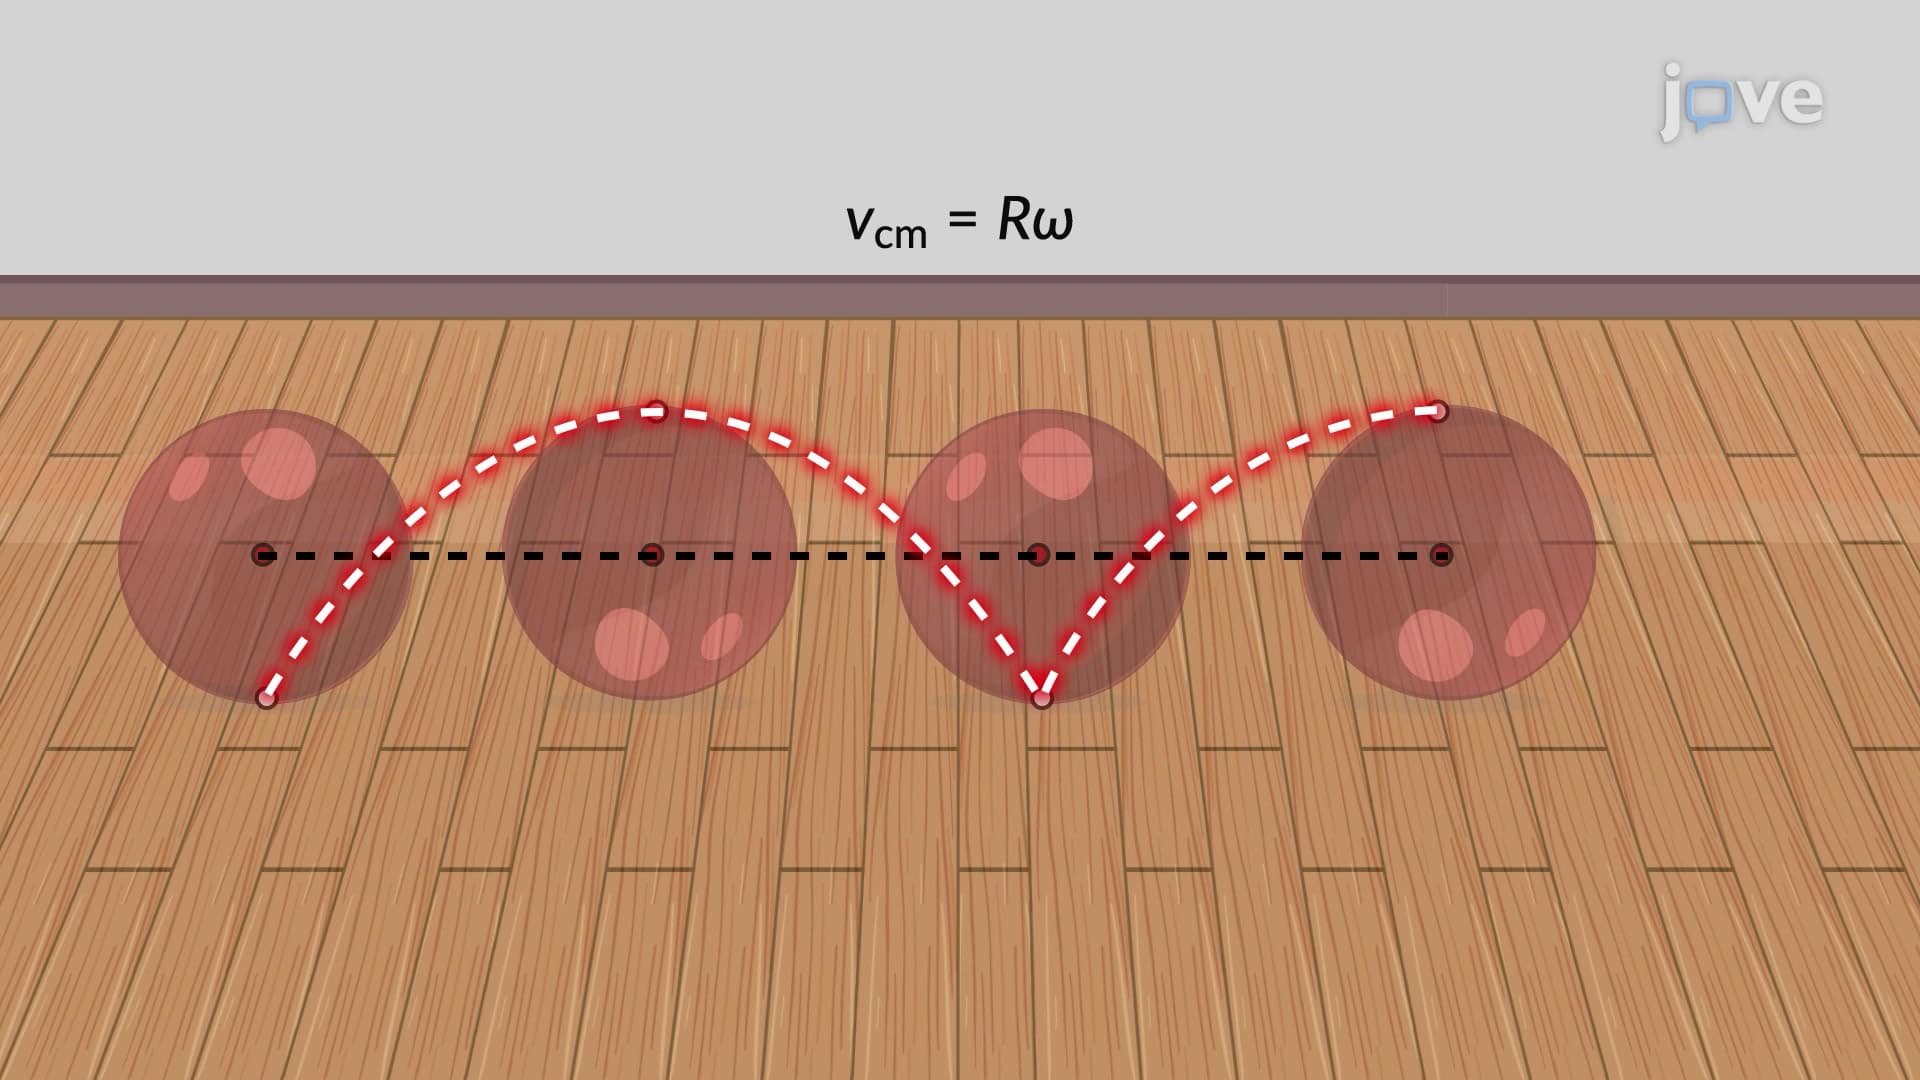
Rolling Without Slipping
 01:14
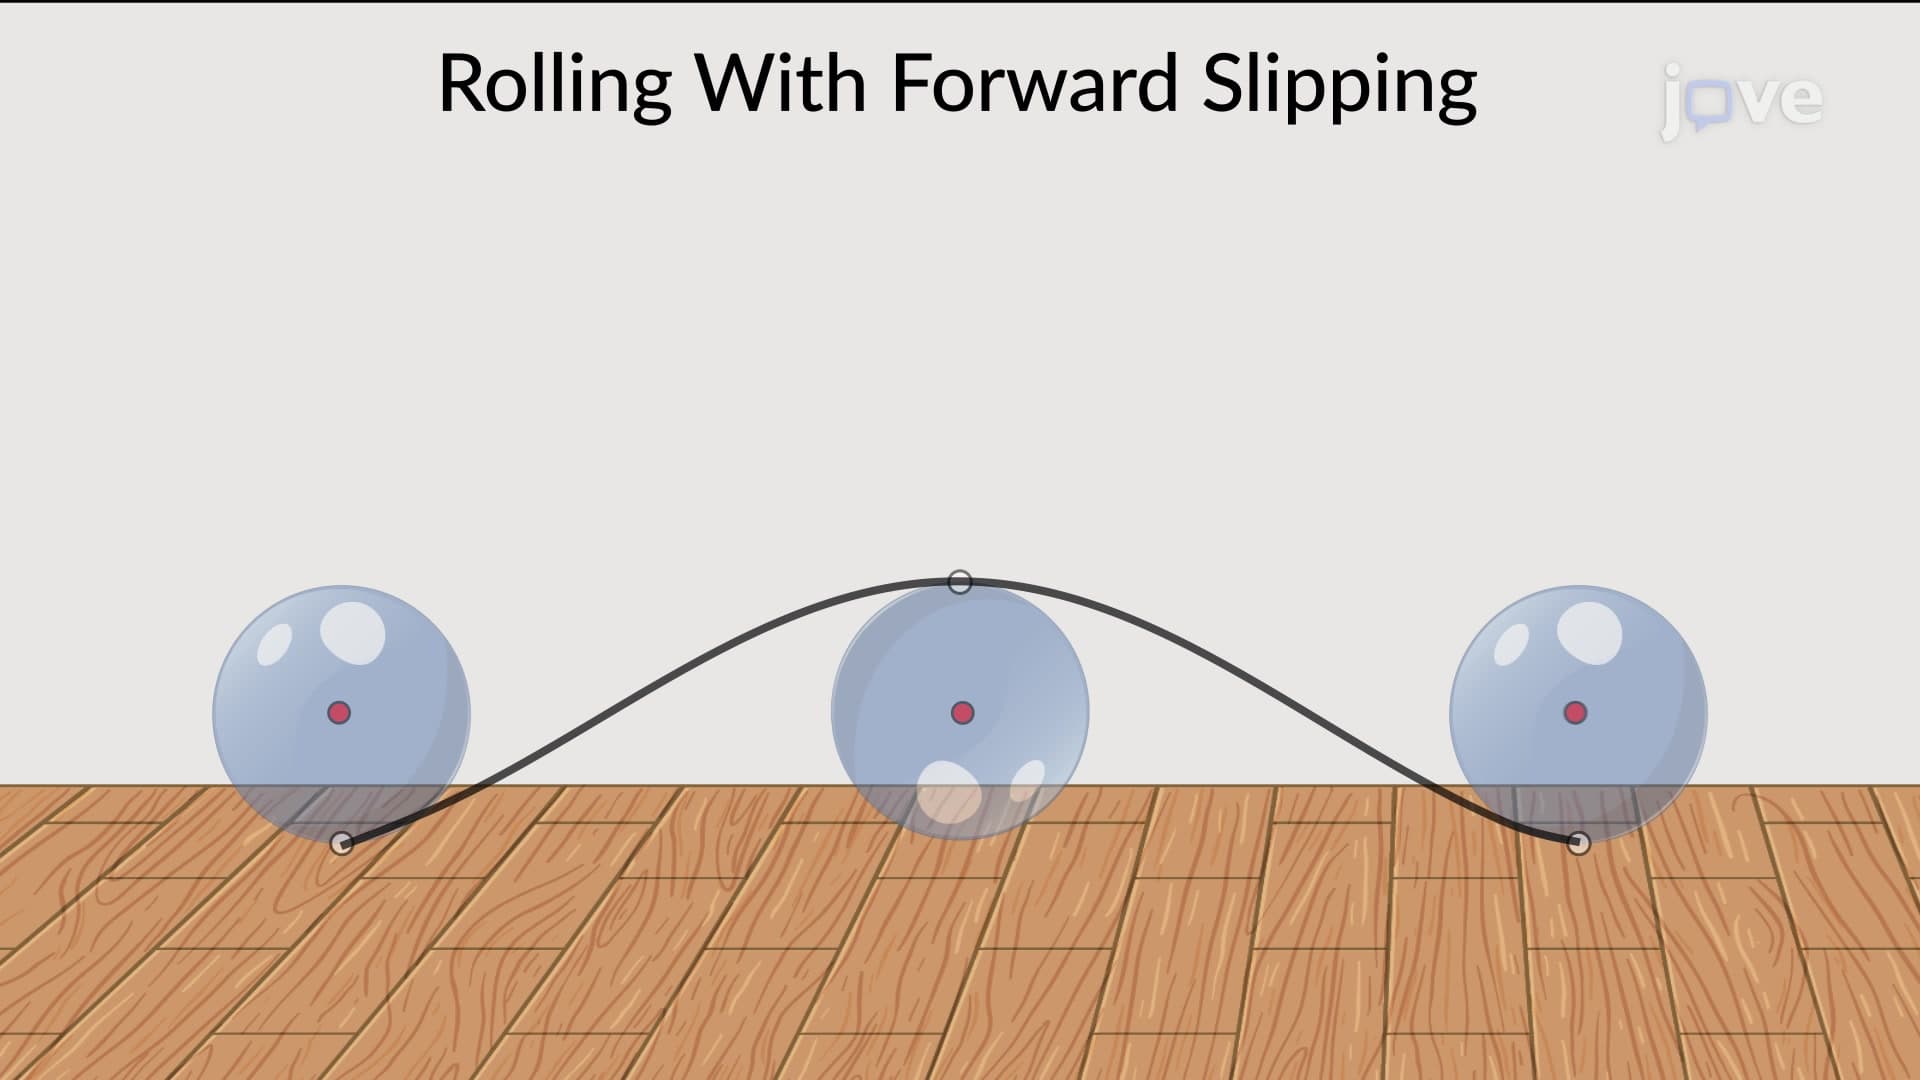
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:28
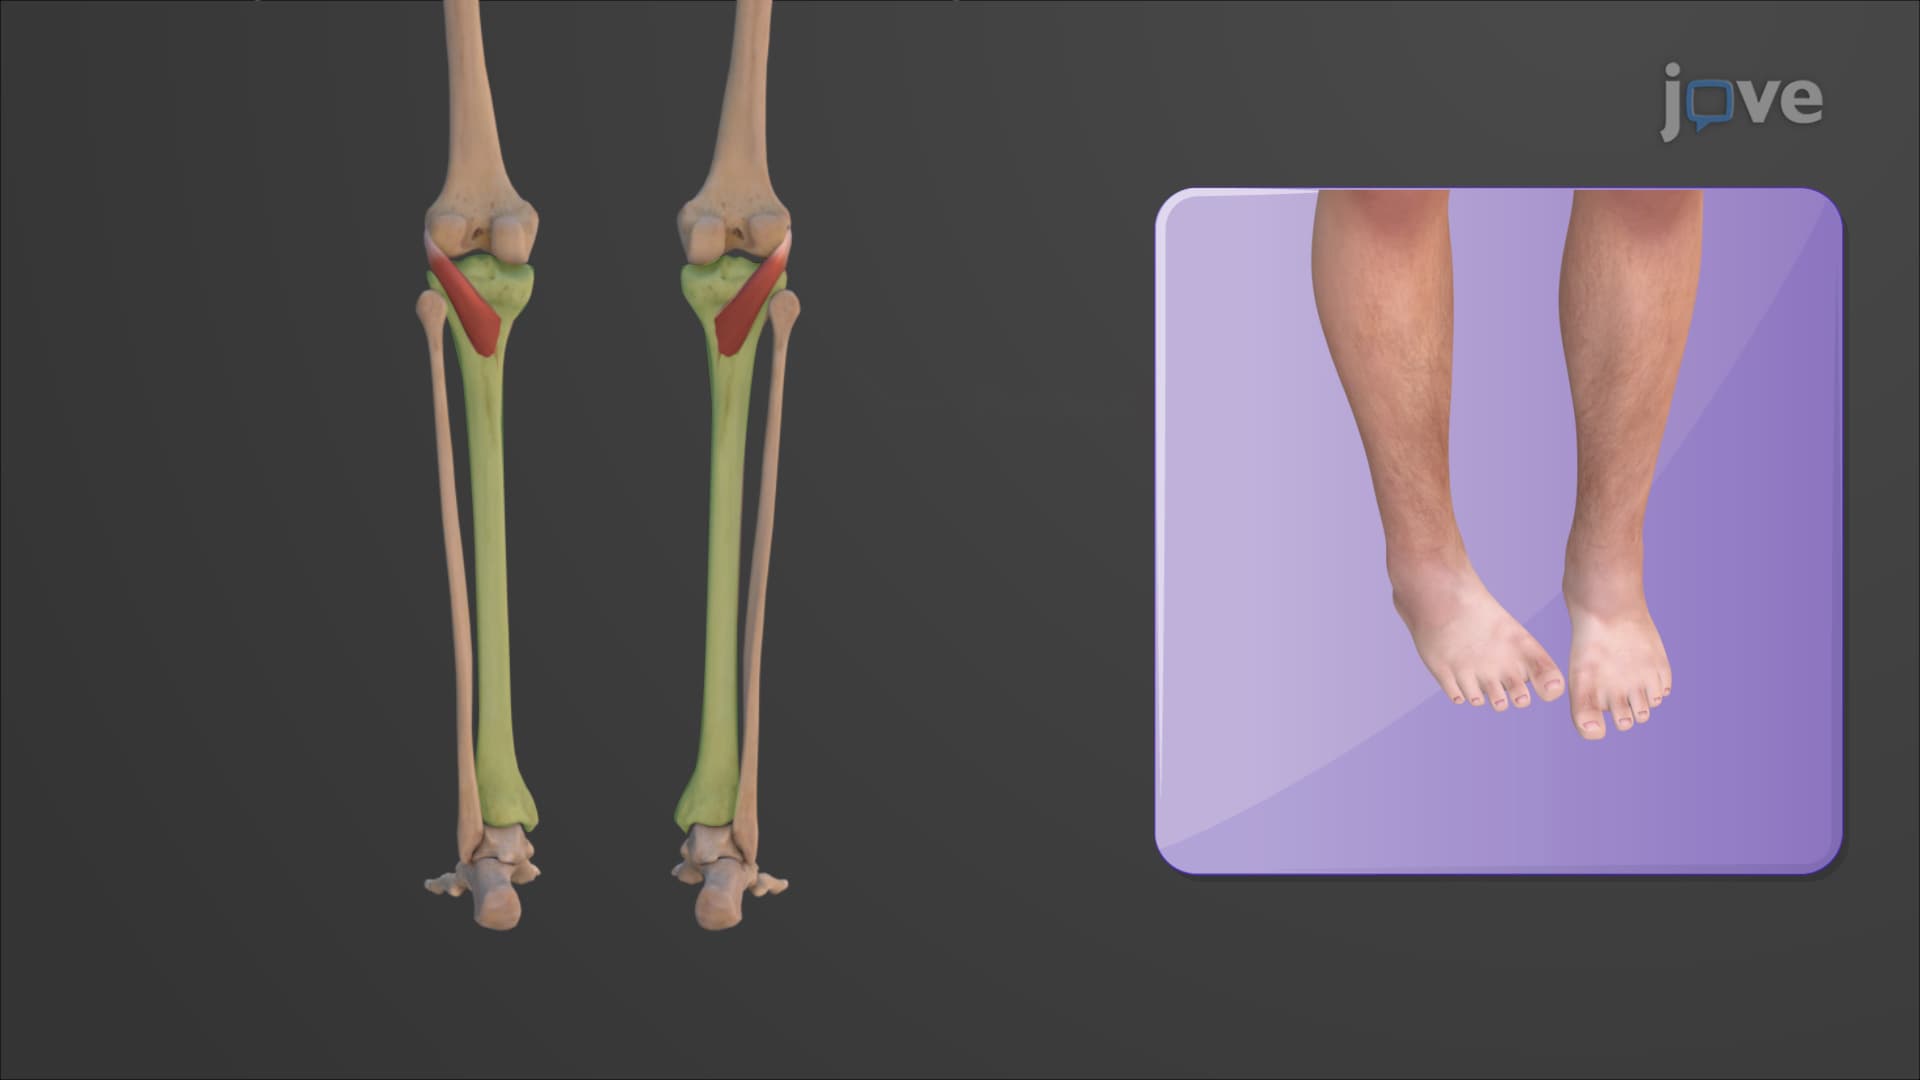
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....
 01:22
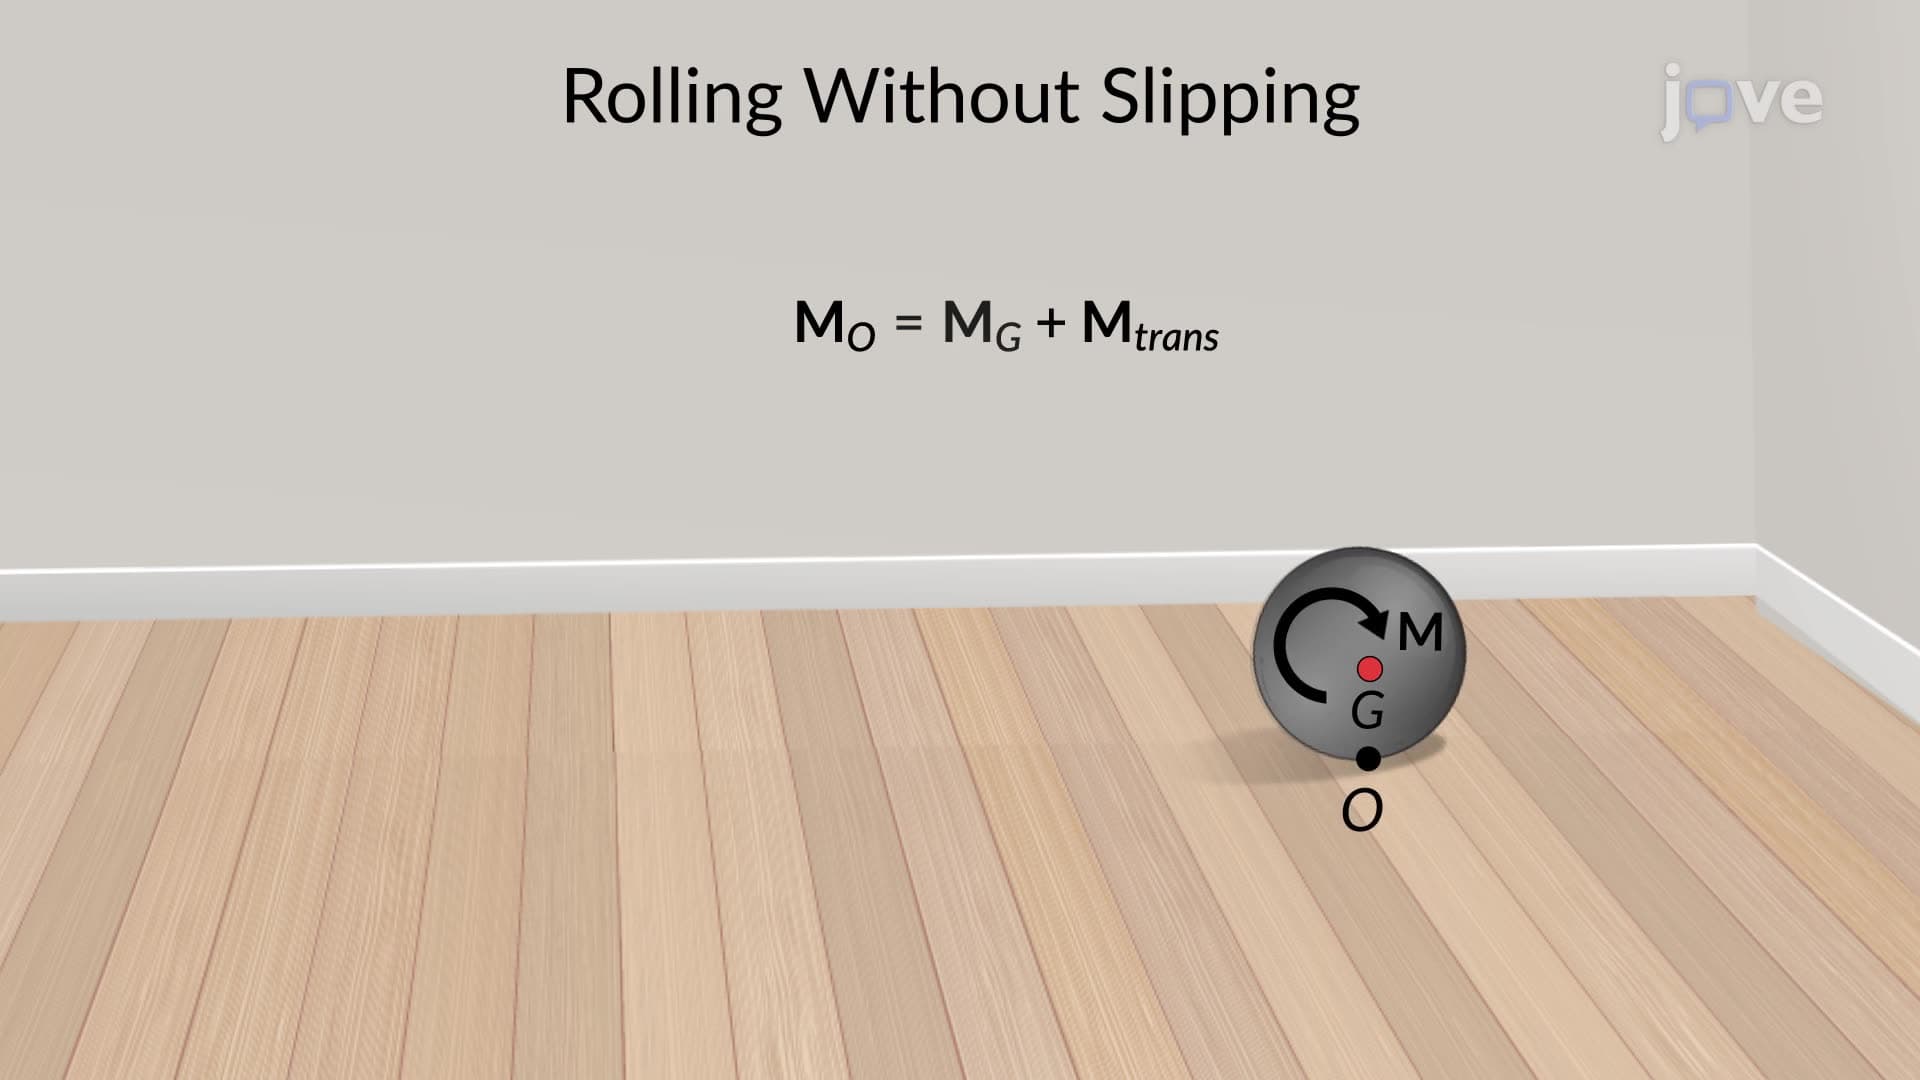
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...