Related Experiment Video
Updated: Feb 8, 2026
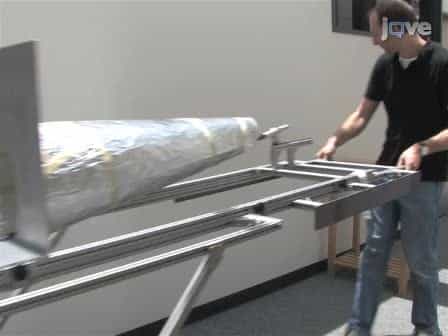

Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
Haptic Feedback for Control and Active Constraints in Contactless Laser Surgery: Concept, Implementation, and

Abstract:
Haptics has proven to be highly beneficial in surgical robotics, bringing enhanced safety and precision by complementing the surgeon's visual channel. However, most of the research body in this context is dedicated to applications involving traditional "cold steel" surgical instruments. This paper proposes to bring the benefits of haptics to contactless surgeries, and presents a novel method to achieve this. The specific case of robot-assisted laser microsurgery is investigated. Here, a fictitious force feedback is created through stereoscopic visualization and 3D reconstruction, allowing the surgeon to sense the surgical area haptically while controlling a non-contact surgical laser. This is shown to significantly improve system usability and the accuracy of laser incisions, especially in applications involving several passes of the laser over the same incision line. Validation of the system is performed through two series of experiments involving both naive users and expert surgeons. The obtained results demonstrate that haptics can indeed be introduced in contactless laser surgery, allowing the exploitation of active constraints and guidance techniques that significantly enhance laser control accuracy both in static and dynamic environments. Furthermore, the proposed haptic technology shows good acceptance and high usability, indicating it has great potential to positively impact real surgeries.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 00:46
Feedback Inhibition
 01:19
Self-Concept
Infancy and Emerging Recognition
During infancy, self-concept is virtually nonexistent. Babies do not distinguish themselves as separate entities and often mistake their...
 01:26
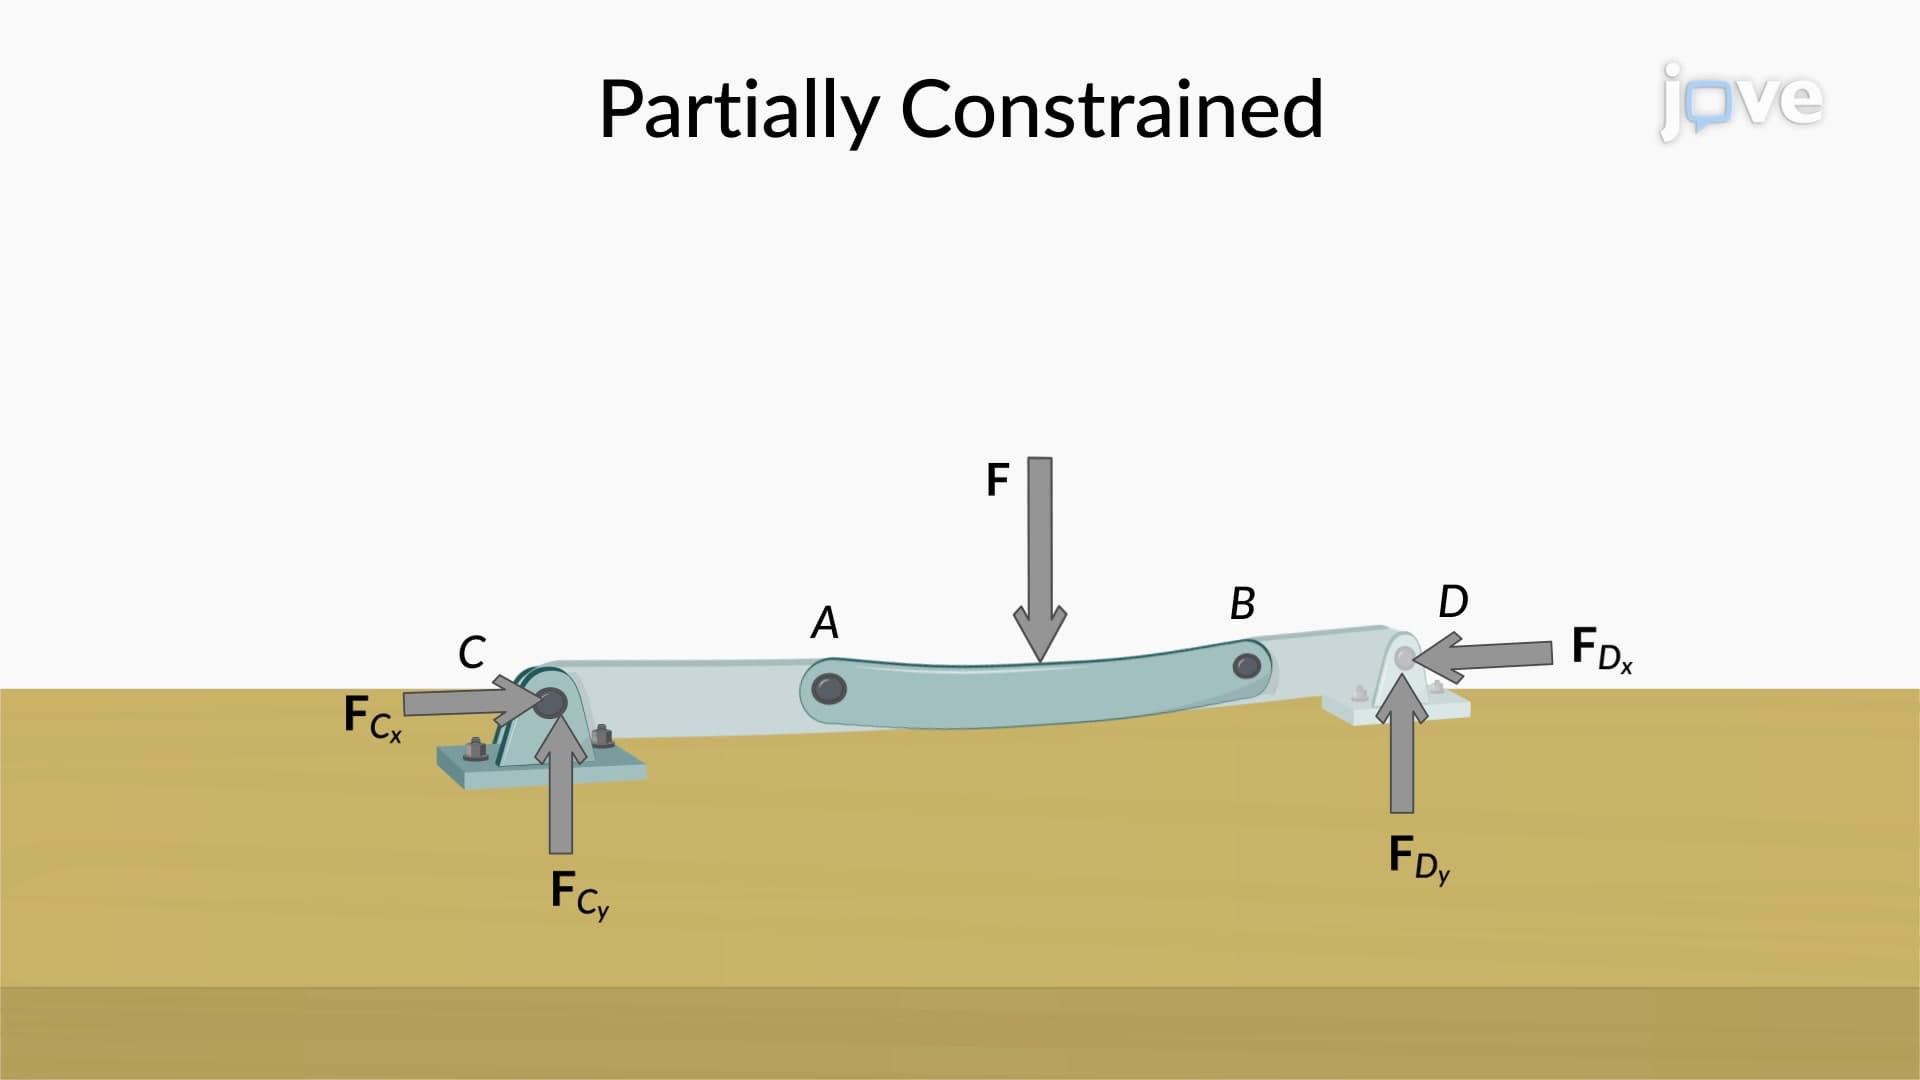
Constraints and Statical Determinacy
 01:01
Feedback Loops
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...