Related Experiment Video
Updated: Feb 8, 2026
Robotics in Surgery: A Modular Robotic Platform Driven Gastric Wedge Resection
Published on: February 7, 2025
Affordance Equivalences in Robotics: A Formalism
Mihai Andries1, Ricardo Omar Chavez-Garcia2, Raja Chatila3
1Institute for Systems and Robotics (ISR-Lisboa), Instituto Superior Técnico, Lisbon, Portugal.

Abstract:
Automatic knowledge grounding is still an open problem in cognitive robotics. Recent research in developmental robotics suggests that a robot's interaction with its environment is a valuable source for collecting such knowledge about the effects of robot's actions. A useful concept for this process is that of an affordance, defined as a relationship between an actor, an action performed by this actor, an object on which the action is performed, and the resulting effect. This paper proposes a formalism for defining and identifying affordance equivalence. By comparing the elements of two affordances, we can identify equivalences between affordances, and thus acquire grounded knowledge for the robot. This is useful when changes occur in the set of actions or objects available to the robot, allowing to find alternative paths to reach goals. In the experimental validation phase we verify if the recorded interaction data is coherent with the identified affordance equivalences. This is done by querying a Bayesian Network that serves as container for the collected interaction data, and verifying that both affordances considered equivalent yield the same effect with a high probability.
Related Concept Videos
 02:42
Formal Charges
 01:19
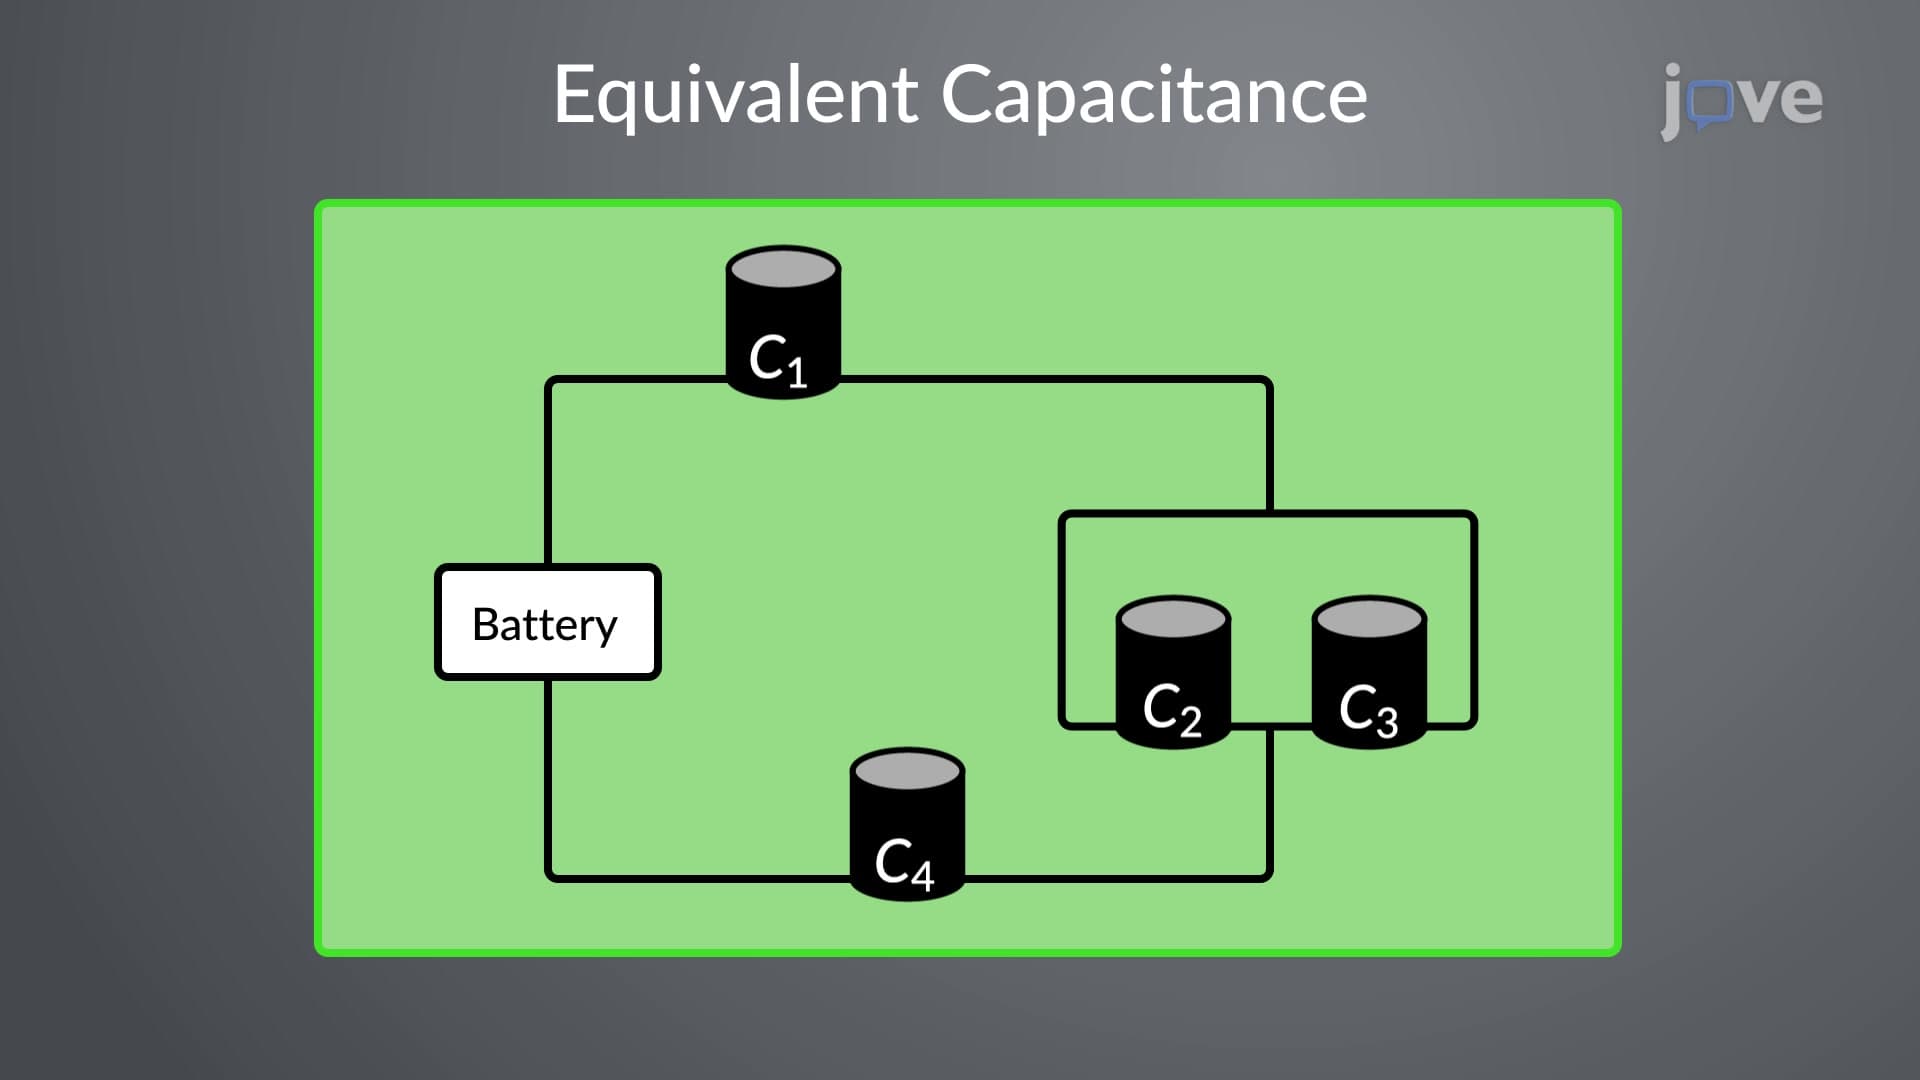
Equivalent Capacitance
The following strategies are adopted to calculate...
 01:19
Equivalent Capacitance
 01:26
Pharmaceutical Equivalents
 02:19
Lewis Structures and Formal Charges
 01:18
Thévenin Equivalent Circuits