Related Experiment Video
Updated: Feb 7, 2026


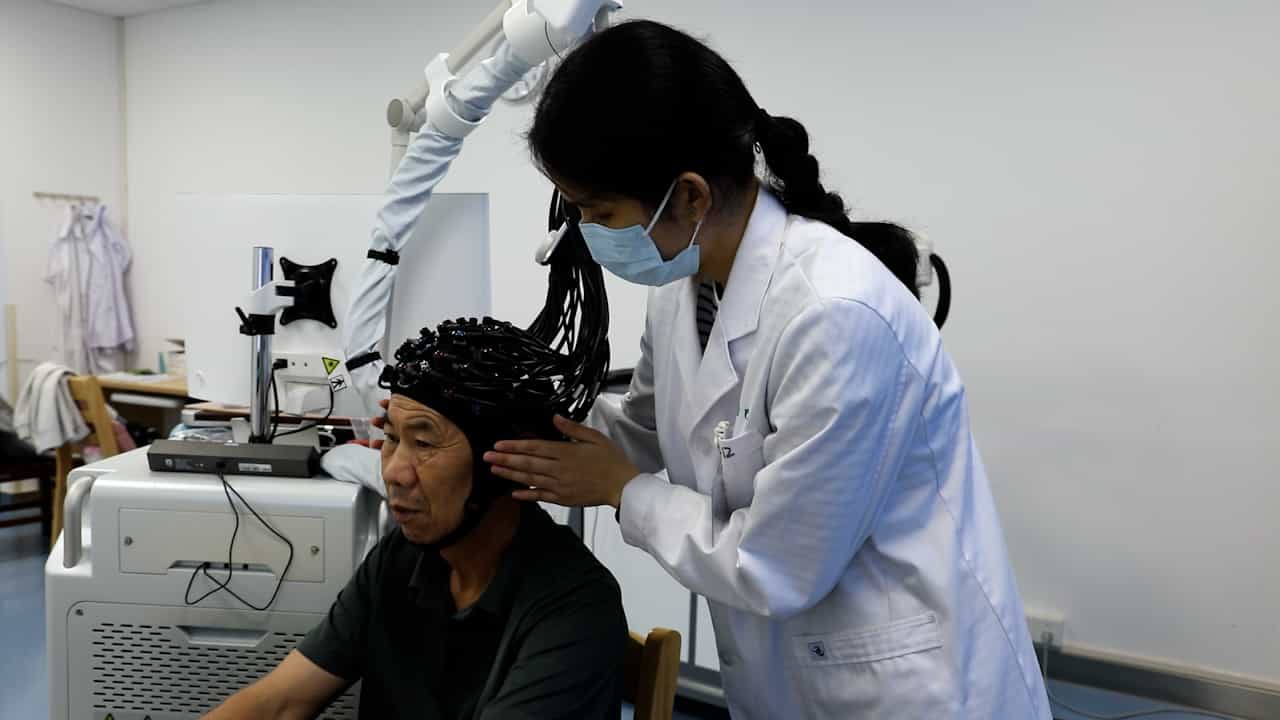
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Feasibility of a wearable soft-robotic glove to support impaired hand function in stroke patients
Bob Radder1, Gerdienke Prange-Lasonder, Anke I R Kottink
1Roessingh Research and Development, University of Twente, 7500 AH Enschede, The Netherlands. Roessingh Research and Development, University of Twente, 7500 AH Enschede, The Netherlands.

Objective:
To investigate the feasibility of a wear-able, soft-robotic glove system developed to combine assistive support in daily life with performing therapeutic exercises on a computer at home (the HandinMind system).
Design:
Feasibility study.
Patients:
Five chronic stroke patients with limitations in activities of daily living due to impaired hand function.
Methods:
Participants performed a usability test and several functional tasks with the HandinMind system across 2 sessions. Feasibility was measured using the System Usability Scale (SUS), Intrinsic Motivation Inventory (IMI) and performance times of the functional tasks.
Results:
User acceptance measured by the SUS and IMI was scored high. The median SUS scores of sessions 1 and 2 were 80.0 (interquartile range (IQR) 70.0-88.8) and 77.5 (IQR 75.0-87.5), respectively, and the median IMI score was 6.3 points out of 7 points (IQR 6.2-6.3). Functional task performance was initially slower with the HandinMind glove compared with performance without the glove, but improved up to the level of performance without the glove across no more than 3 repetitions.
Conclusion:
Chronic stroke patients with impaired hand function were positive about the feasibility of the first prototype of the HandinMind system. How-ever, performance and ease of use of the system should be improved further in future development phases.

Related Concept Videos
 01:28
Self-Help Support Groups
Accessibility and Cost-Effectiveness
One of the primary strengths of self-help...
 01:23
Hand hygiene
Hand washing...
 01:30
Support Reactions
The purpose of the supports is to prevent the translational motion of the system by applying an equal and opposite force and to prevent the system's rotation by applying...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:25
Types of Reports I: Hands-off Report
Following are the key components and categories of hand-off reports:
Purpose and Process:
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...