Predicting foot placement for balance through a simple model with swing leg dynamics
Related Experiment Video
Updated: Feb 7, 2026
Dynamic Navigation for Dental Implant Placement
Published on: September 13, 2022
1Department of Mechanical and Energy Engineering, Southern University of Science and Technology, Shenzhen 518055, China; Beijing Key Lab of Precision/Ultra-Precision Manufacturing Equipments and Control, Tsinghua University, Beijing 100084, China.

Abstract:
Stepping is one important strategy to restore balance against external perturbations. Although current literature have proposed models to predict the recovery foot placement, swing leg actuation is rarely taken into account. In this paper, we combine the capturability-based analysis with swing leg dynamics and seek to contribute to the following problem: for a biped system recovering balance from external perturbations, how to choose a step position and duration in minimizing swing actuation cost? We expand the linear inverted pendulum model with an actuated linear pendulum mounted on the pelvis, the addition of which is proposed to describe the swing leg dynamics. The closed-form expression of swing actuation with constraints is derived from the explicit formulations of the pelvis and swing foot motion. We calculate the optimal step position and duration to minimize swing cost under various perturbations. Results show that the optimal step duration keeps constant, while the optimal step position is linearly proportional to the magnitude of perturbations. Such findings match well with experimental data from ten subjects delivered with waist-perturbations. These current results demonstrate that our proposed model with swing dynamics suggests an effective alternative to predict recovery foot placement of biped systems following unexpected perturbations.
Related Concept Videos
 01:28
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....
 01:21
The Swing Equation
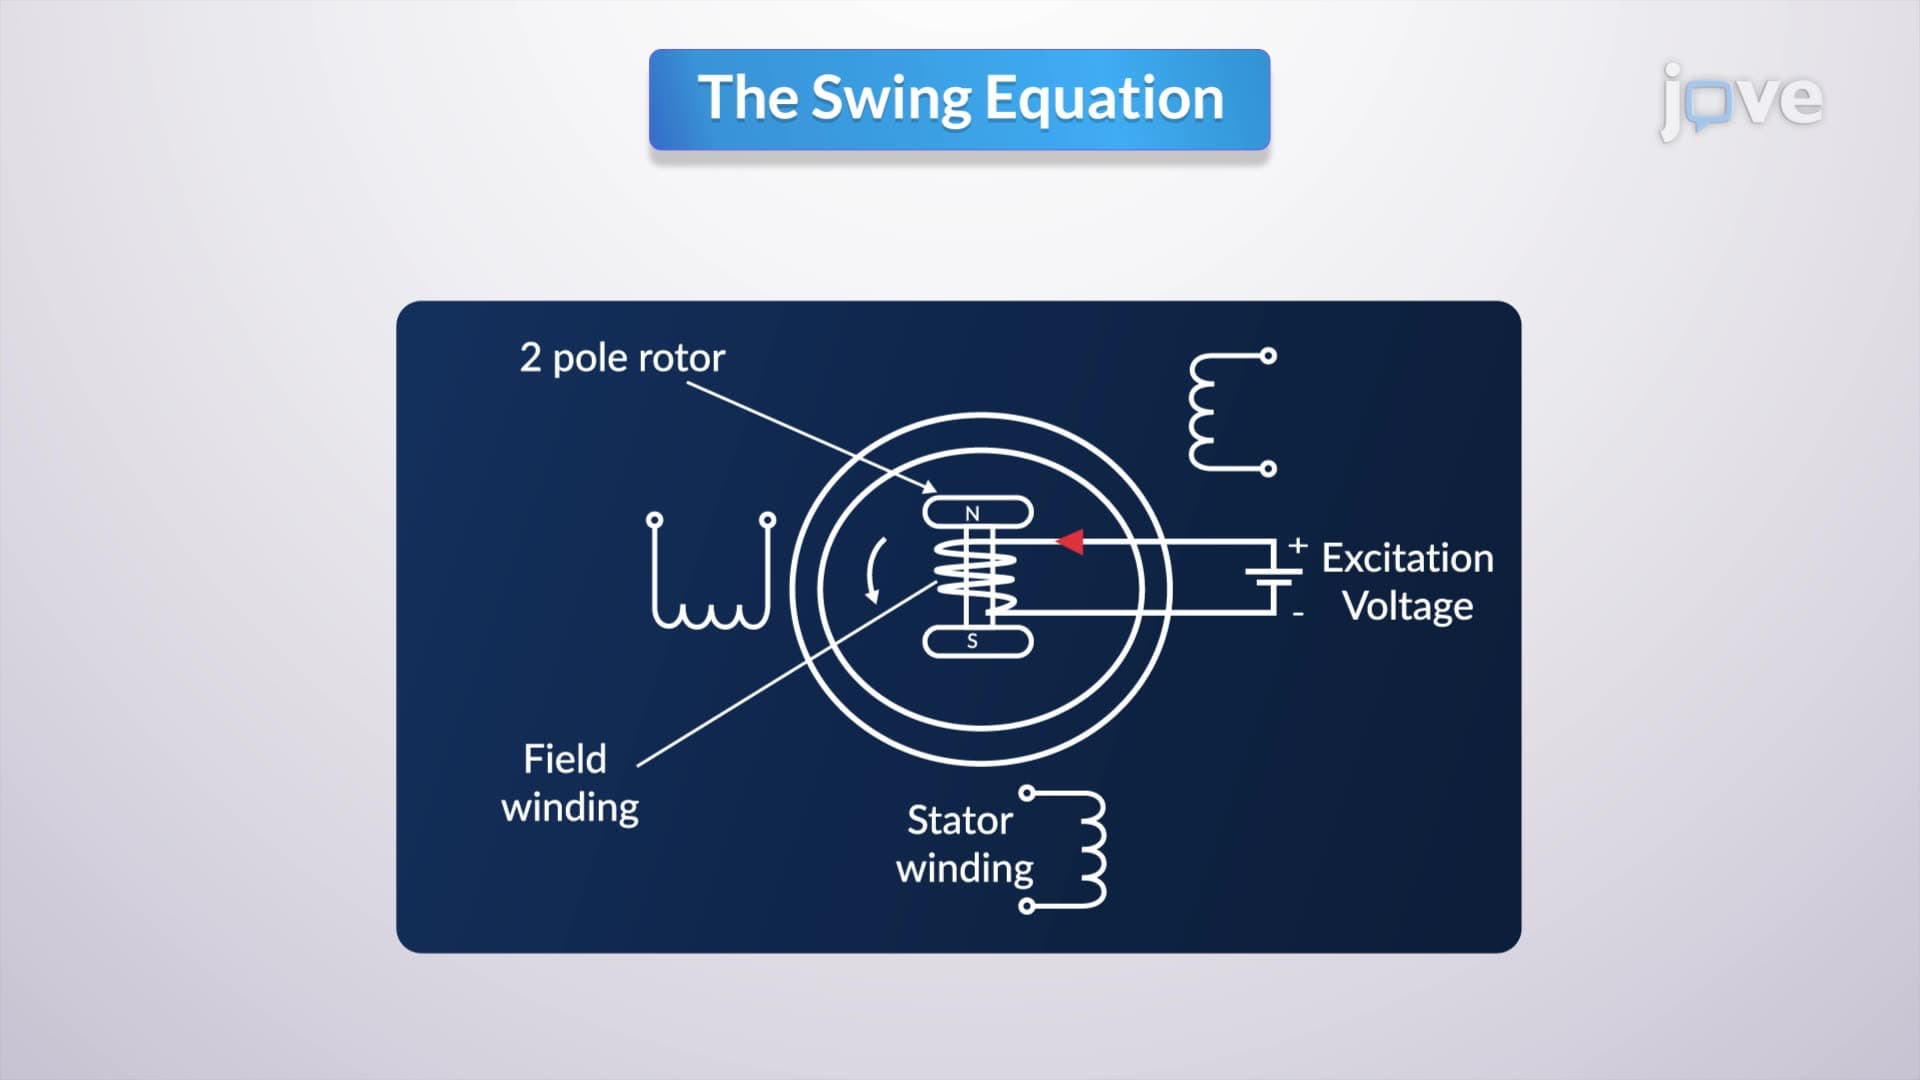
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 02:58
Balancing Redox Equations
 01:23
Muscles that Move the Leg
Anterior Compartment
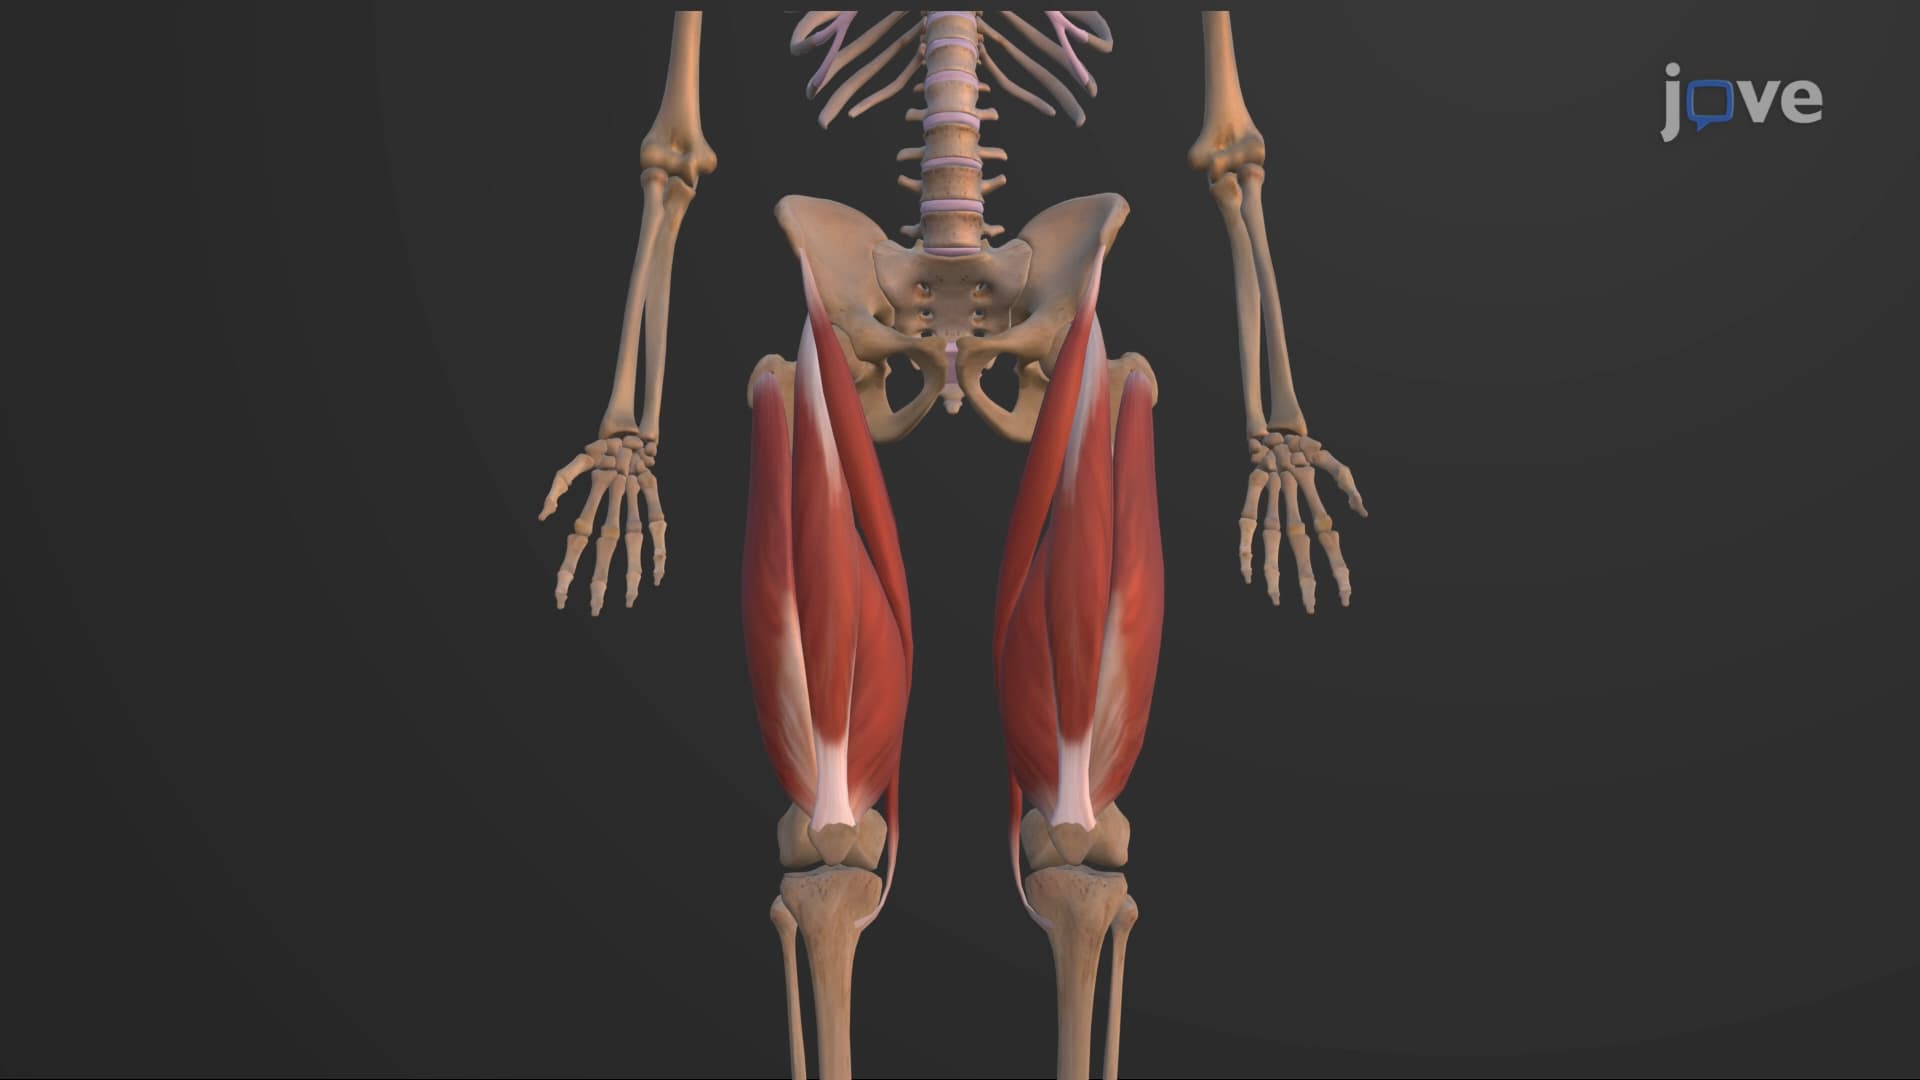
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 02:27
Predicting Molecular Geometry
 01:15
Equilibrium and Balance