Related Experiment Video
Updated: Feb 6, 2026

Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
Features of Invariant Extended Kalman Filter Applied to Unmanned Aerial Vehicle Navigation
Nak Yong Ko1, Wonkeun Youn2, In Ho Choi3
1Department of Electronic Engineering, Chosun University, 375 Seosuk-dong Dong-gu, Gwangju 501-759, Korea. nyko@chosun.ac.kr.

Abstract:
This research used an invariant extended Kalman filter (IEKF) for the navigation of an unmanned aerial vehicle (UAV), and compared the properties and performance of this IEKF with those of an open-source navigation method based on an extended Kalman filter (EKF). The IEKF is a fairly new variant of the EKF, and its properties have been verified theoretically and through simulations and experiments. This study investigated its performance using a practical implementation and examined its distinctive features compared to the previous EKF-based approach. The test used two different types of UAVs: rotary wing and fixed wing. The method uses sensor measurements of the location and velocity from a GPS receiver; the acceleration, angular rate, and magnetic field from a microelectromechanical system-attitude heading reference system (MEMS-AHRS); and the altitude from a barometric sensor. Through flight tests, the estimated state variables and internal parameters such as the Kalman gain, state error covariance, and measurement innovation for the IEKF method and EKF-based method were compared. The estimated states and internal parameters showed that the IEKF method was more stable and convergent than the EKF-based method, although the estimated locations, velocities, and altitudes of the two methods were comparable.
Related Concept Videos
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:25
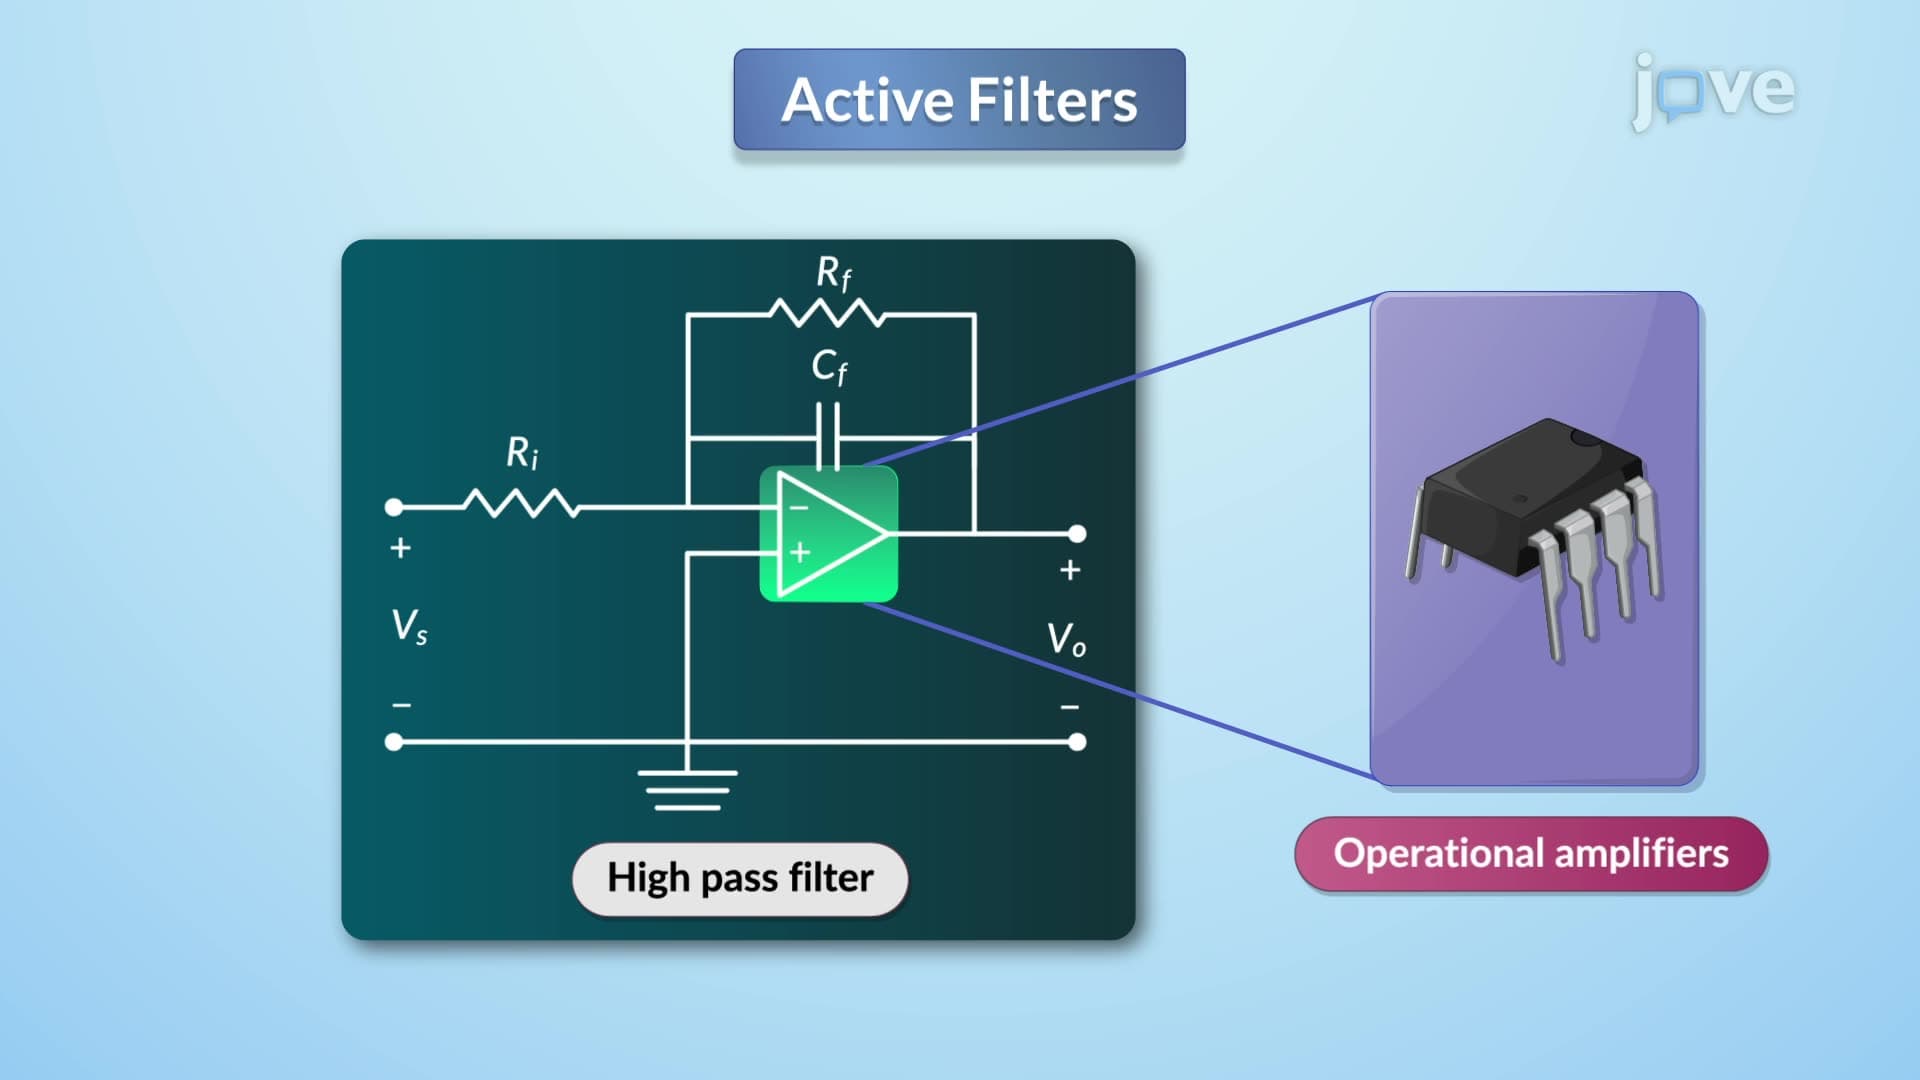
Active Filters
 01:07
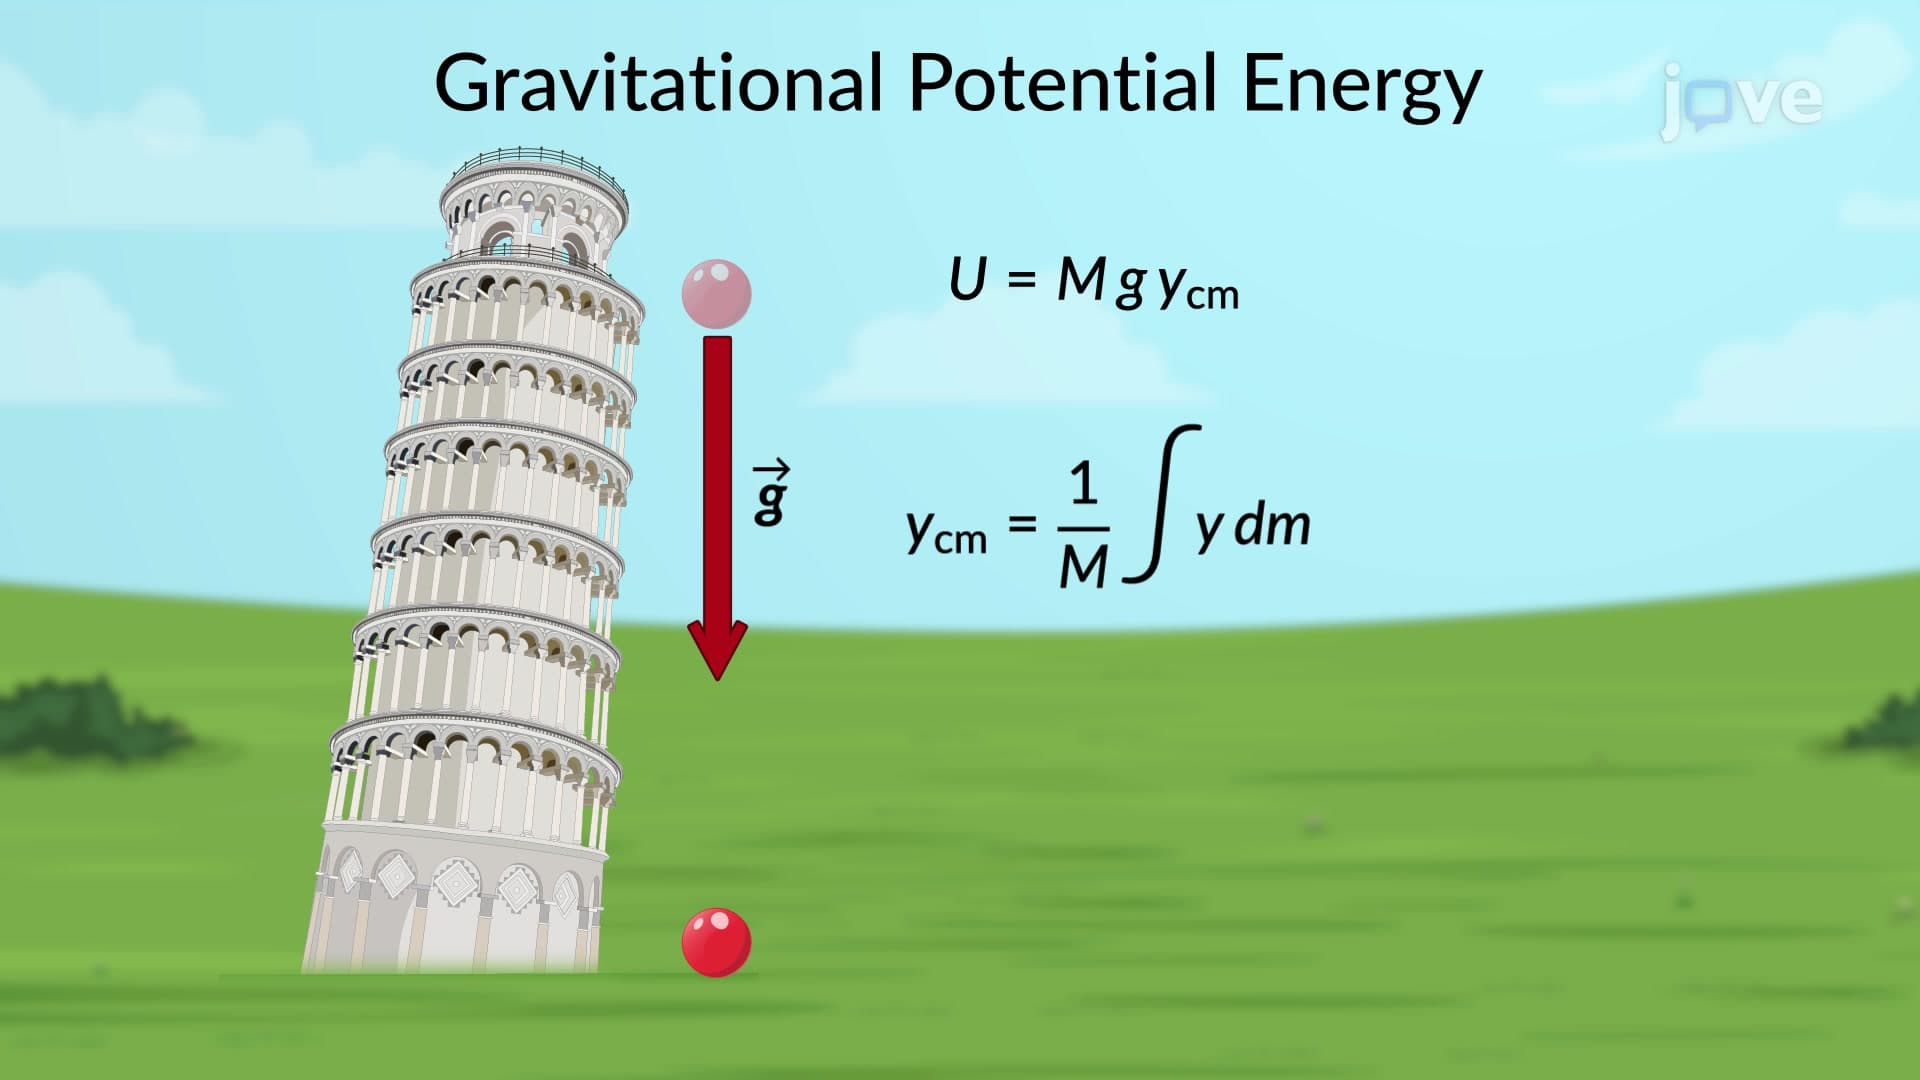
Gravitational Potential Energy for Extended Objects
 01:20
COPD: Pathogenesis and Clinical Features
The primary cause for the onset of COPD is cigarette smoking and exposure to air pollution. These hazardous factors initiate a chain reaction within the lungs, resulting in chronic inflammation, damage to the airways, and a...
 01:20
Special Features of Adaptive Immunity
The primary cell types involved in adaptive immunity are T cells and B cells. Each type has a unique role in defending the body against pathogens. T cells are responsible for cell-mediated immunity. They identify and eliminate infected cells directly,...