Technical efficiency analysis of marine shrimp farming (Litopenaeus vannamei) in biofloc and conventional systems: A case study in northeastern Brazil
Related Experiment Video
Updated: Feb 5, 2026

Breakfast Habits among Schoolchildren in the City of Uruguaiana, Brazil
Published on: July 29, 2020
Marcelo A S Rego1, Omar J Sabbag2, Roberta B Soares3
1Instituto Federal de Educação, Ciência e Tecnologia de Sergipe, Campus Estância, Rua Café Filho, 260, Cidade Nova, 49200-000 Estância, SE, Brazil.

Abstract:
Shrimp farming has a great ecological, economic, and social importance in northeastern Brazil. Although the conventional farming system is widely used, biofloc technology (BFT) system has been developed to reduce environmental impacts and optimizing the production. Thus,the present study evaluated the technical efficiency of production cycles of Litopenaeus vannamei in conventional and BFT systems.We analyzed 48 production cycles in the conventional system in 2013 and 2014 and 9 cycles in the BFT system in 2014 through data envelopment analysis (DEA). The inputs corresponded to the population density (post-larvae m-2), amount of feed (kg ha-1 cycle-1), labor (man ha-1) and power supply (HP ha-1), whereas the yield (kg ha-1 cycle-1) was considered the output. The results indicated four production cycles (7.0%) technically efficient, three in the conventional system and one in the BFT. By comparing the productive systems, there was significant difference in their mean scores of technical efficiency. There was a greater influence of the management inefficiency on the conventional system, while the production scale reduced the average scores of technical efficiency in the BFT system. These results may help to improve the development of sustainable L. vannamei farming in both systems by reducing waste and increasing profits.
Related Concept Videos
 01:30
Sign Convention
The normal force acts perpendicular to the beam's cross-section and can...
 02:24
Comparative Excretory Systems
 01:15
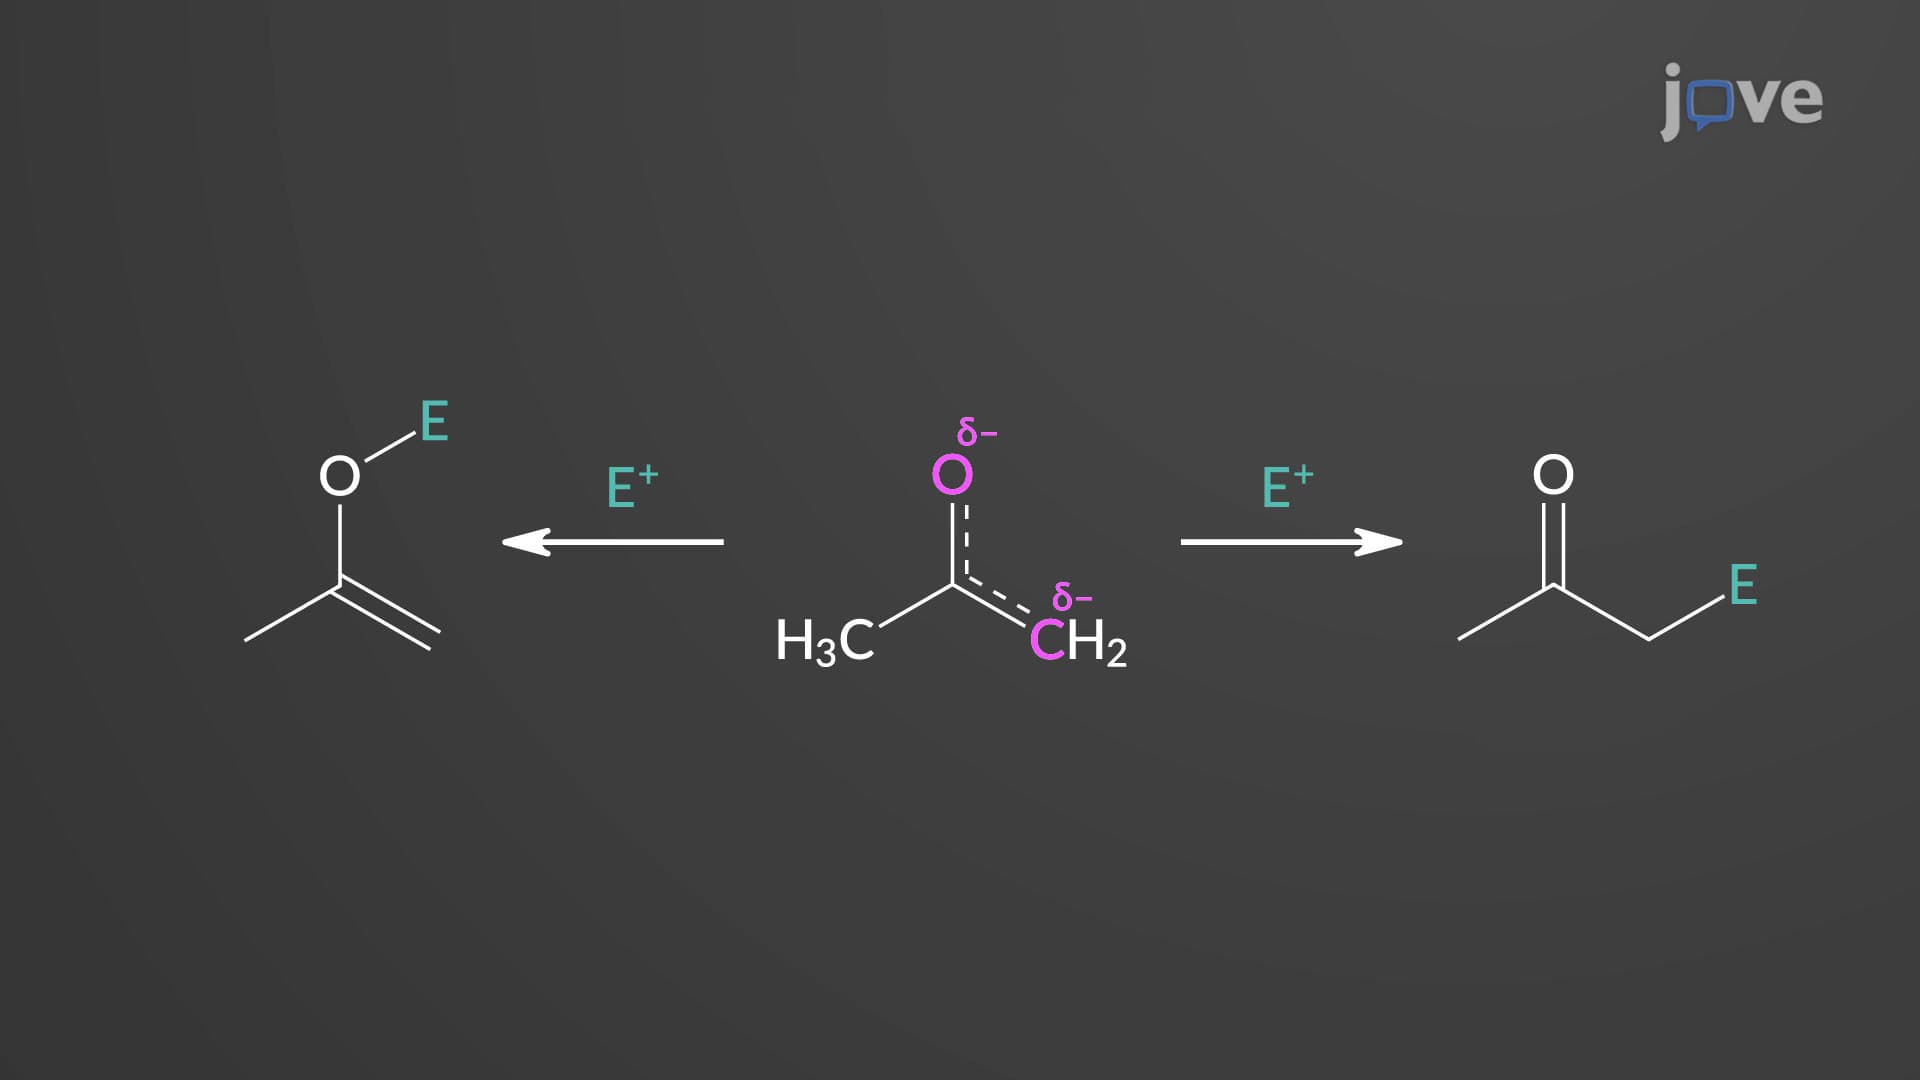
Enolate Mechanism Conventions
 01:18
Second Order systems II
 01:21
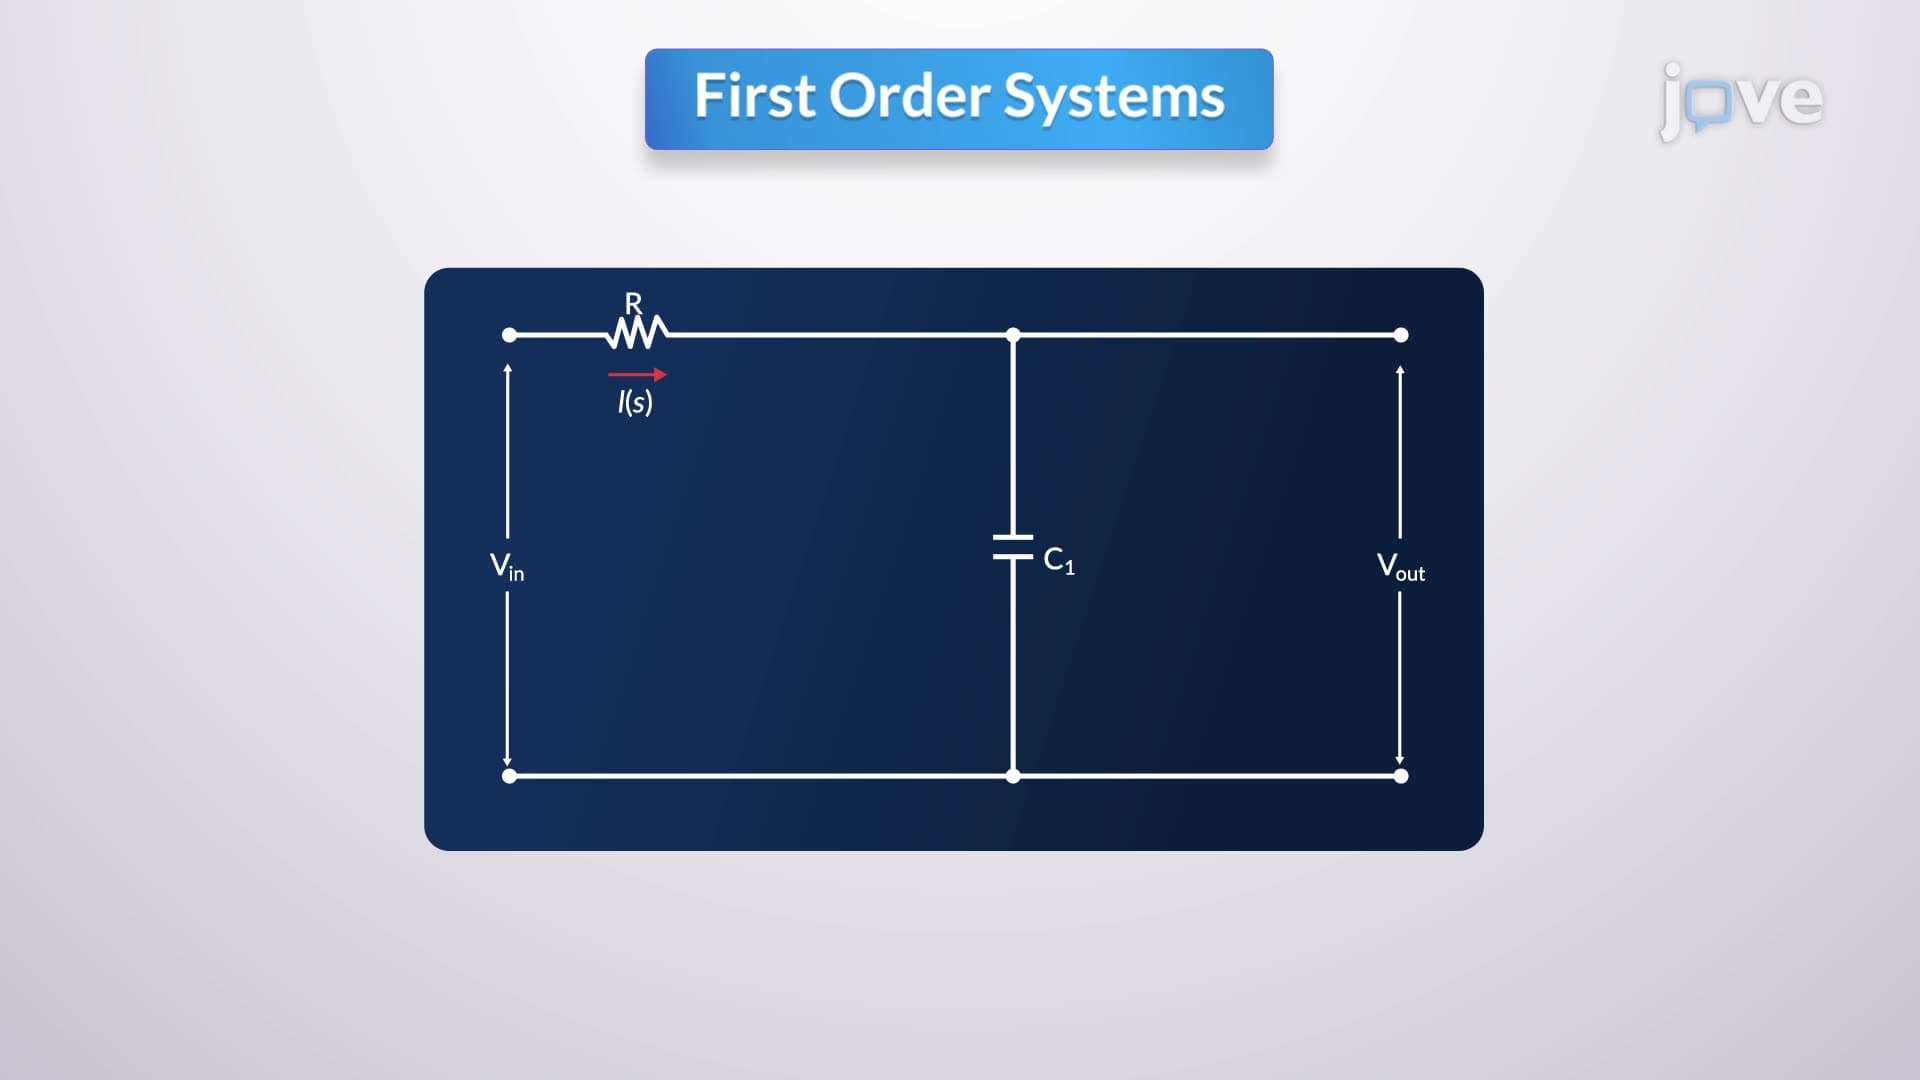
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...