Related Experiment Video
Updated: Feb 5, 2026
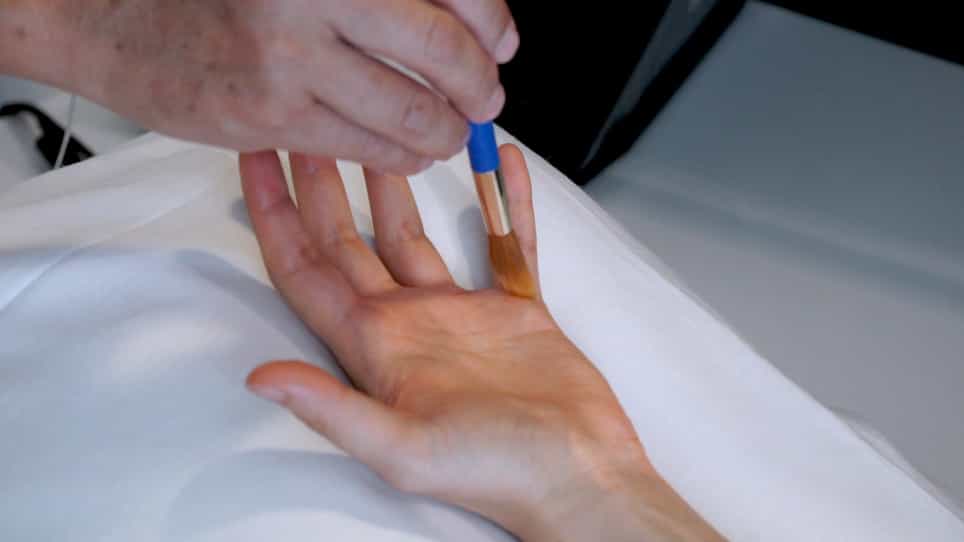

Virtual Hand with Ambiguous Movement between the Self and Other Origin: Sense of Ownership and 'Other-Produced' Agency
Published on: October 28, 2020
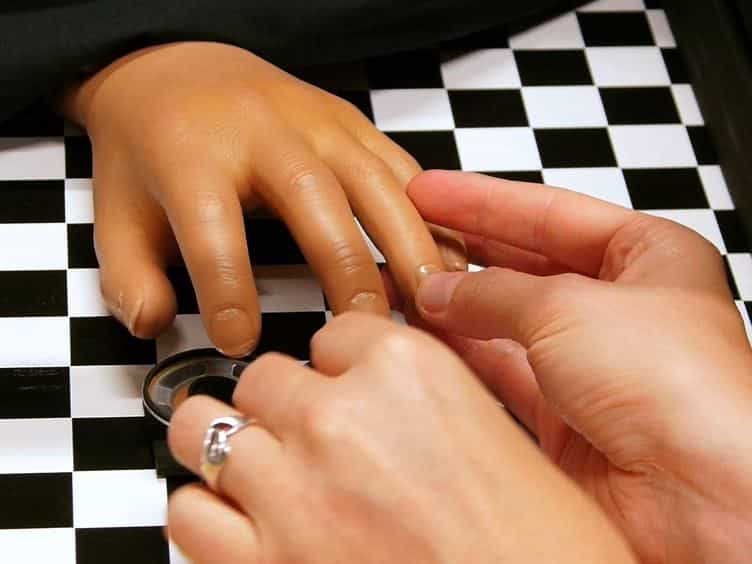
Body ownership and the absence of touch: approaching the rubber hand inside and outside peri-hand space
M Smit1, J T H Brummelman2,3, A Keizer2
1Department of Experimental Psychology, Helmholtz Institute, Utrecht University, Utrecht, The Netherlands. m.smit@uu.nl.

Abstract:
It is widely accepted that the integration of visual and tactile information is a necessity to induce ownership over a rubber hand. This idea has recently been challenged by Ferri et al. (Proc R Soc B 280:1-7, 2013), as they found that sense of ownership was evident by mere expectation of touch. In our study, we aimed to further investigate this finding, by studying whether the mere potential for touch yields a sense of ownership similar in magnitude to that resulting from actually being touched. We conducted two experiments. In the first experiment, our set-up was the classical horizontal set-up (similar to Botvinick and Cohen, Nature 391:756, 1998). Sixty-three individuals were included and performed the classical conditions (synchronous, asynchronous), an approached but not touched (potential for touch), and a 'visual only' condition. In the second experiment, we controlled for differences between the current set-up and the vertical set-up used by Ferri et al. (Proc R Soc B 280:1-7, 2013). Fifteen individuals were included and performed a synchronous and various approaching conditions [i.e., vertical approach, horizontal approach, and a control approach (no hands)]. In our first experiment, we found that approaching the rubber hand neither induced a larger proprioceptive drift nor a stronger subjective sense of ownership than asynchronous stimulation did. Generally, our participants gained most sense of ownership in the synchronous condition, followed by the visual only condition. When using a vertical set-up (second experiment), we confirmed previous suggestions that tactile expectation was able to induce embodiment over a foreign hand, similar in magnitude to actual touch, but only when the real and rubber hand were aligned on the vertical axis, thus along the trajectory of the approaching stimulus. These results indicate that our brain uses bottom-up sensory information, as well as top-down predictions for building a representation of our body.
Related Concept Videos
 01:23
Hand hygiene
Hand washing...
 01:25
Types of Reports I: Hands-off Report
Following are the key components and categories of hand-off reports:
Purpose and Process:
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 02:26
Responses to Gravity and Touch
 01:25
Space Trusses
At the core of a space truss lies the fundamental unit known as the tetrahedron. This structure is composed of six members that form a three-dimensional shape...
 01:27
State Space Representation
Consider an RLC circuit, a...