Related Experiment Video
Updated: Feb 5, 2026
Capturing Dynamic Finger Gesturing with High-resolution Surface Electromyography and Computer Vision
Published on: March 28, 2025
UMONS-TAICHI: A multimodal motion capture dataset of expertise in Taijiquan gestures
Mickaël Tits1, Sohaïb Laraba1, Eric Caulier2
1Numediart Institute, University of Mons, Belgium.

Abstract:
In this article, we present a large 3D motion capture dataset of Taijiquan martial art gestures (n = 2200 samples) that includes 13 classes (relative to Taijiquan techniques) executed by 12 participants of various skill levels. Participants levels were ranked by three experts on a scale of [0-10]. The dataset was captured using two motion capture systems simultaneously: 1) Qualisys, a sophisticated optical motion capture system of 11 cameras that tracks 68 retroreflective markers at 179 Hz, and 2) Microsoft Kinect V2, a low-cost markerless time-of-flight depth sensor that tracks 25 locations of a person׳s skeleton at 30 Hz. Data from both systems were synchronized manually. Qualisys data were manually corrected, and then processed to complete any missing data. Data were also manually annotated for segmentation. Both segmented and unsegmented data are provided in this dataset. This article details the recording protocol as well as the processing and annotation procedures. The data were initially recorded for gesture recognition and skill evaluation, but they are also suited for research on synthesis, segmentation, multi-sensor data comparison and fusion, sports science or more general research on human science or motion capture. A preliminary analysis has been conducted by Tits et al. (2017) [1] on a part of the dataset to extract morphology-independent motion features for skill evaluation. Results of this analysis are presented in their communication: "Morphology Independent Feature Engineering in Motion Capture Database for Gesture Evaluation" (10.1145/3077981.3078037) [1]. Data are available for research purpose (license CC BY-NC-SA 4.0), at https://github.com/numediart/UMONS-TAICHI.
More Related Videos
Related Concept Videos
 01:22
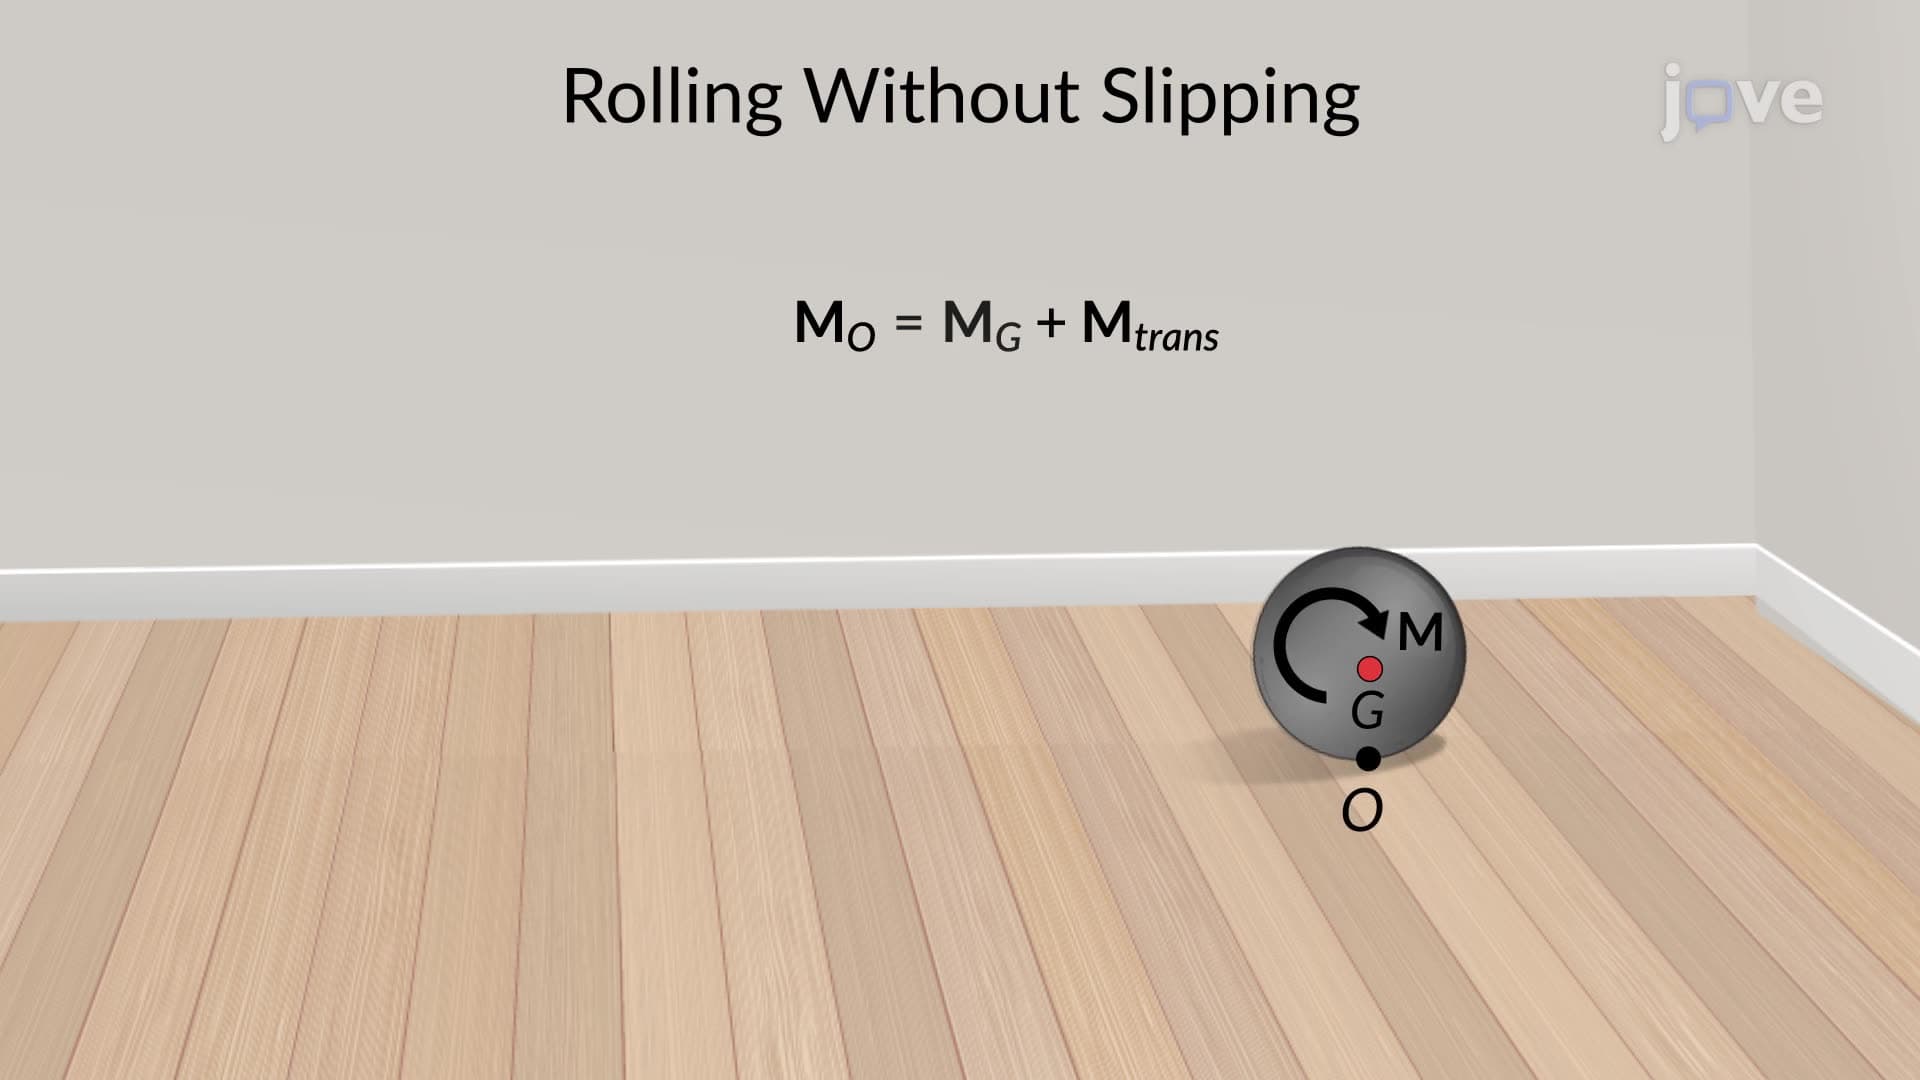
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:18
Projectile Motion: Example
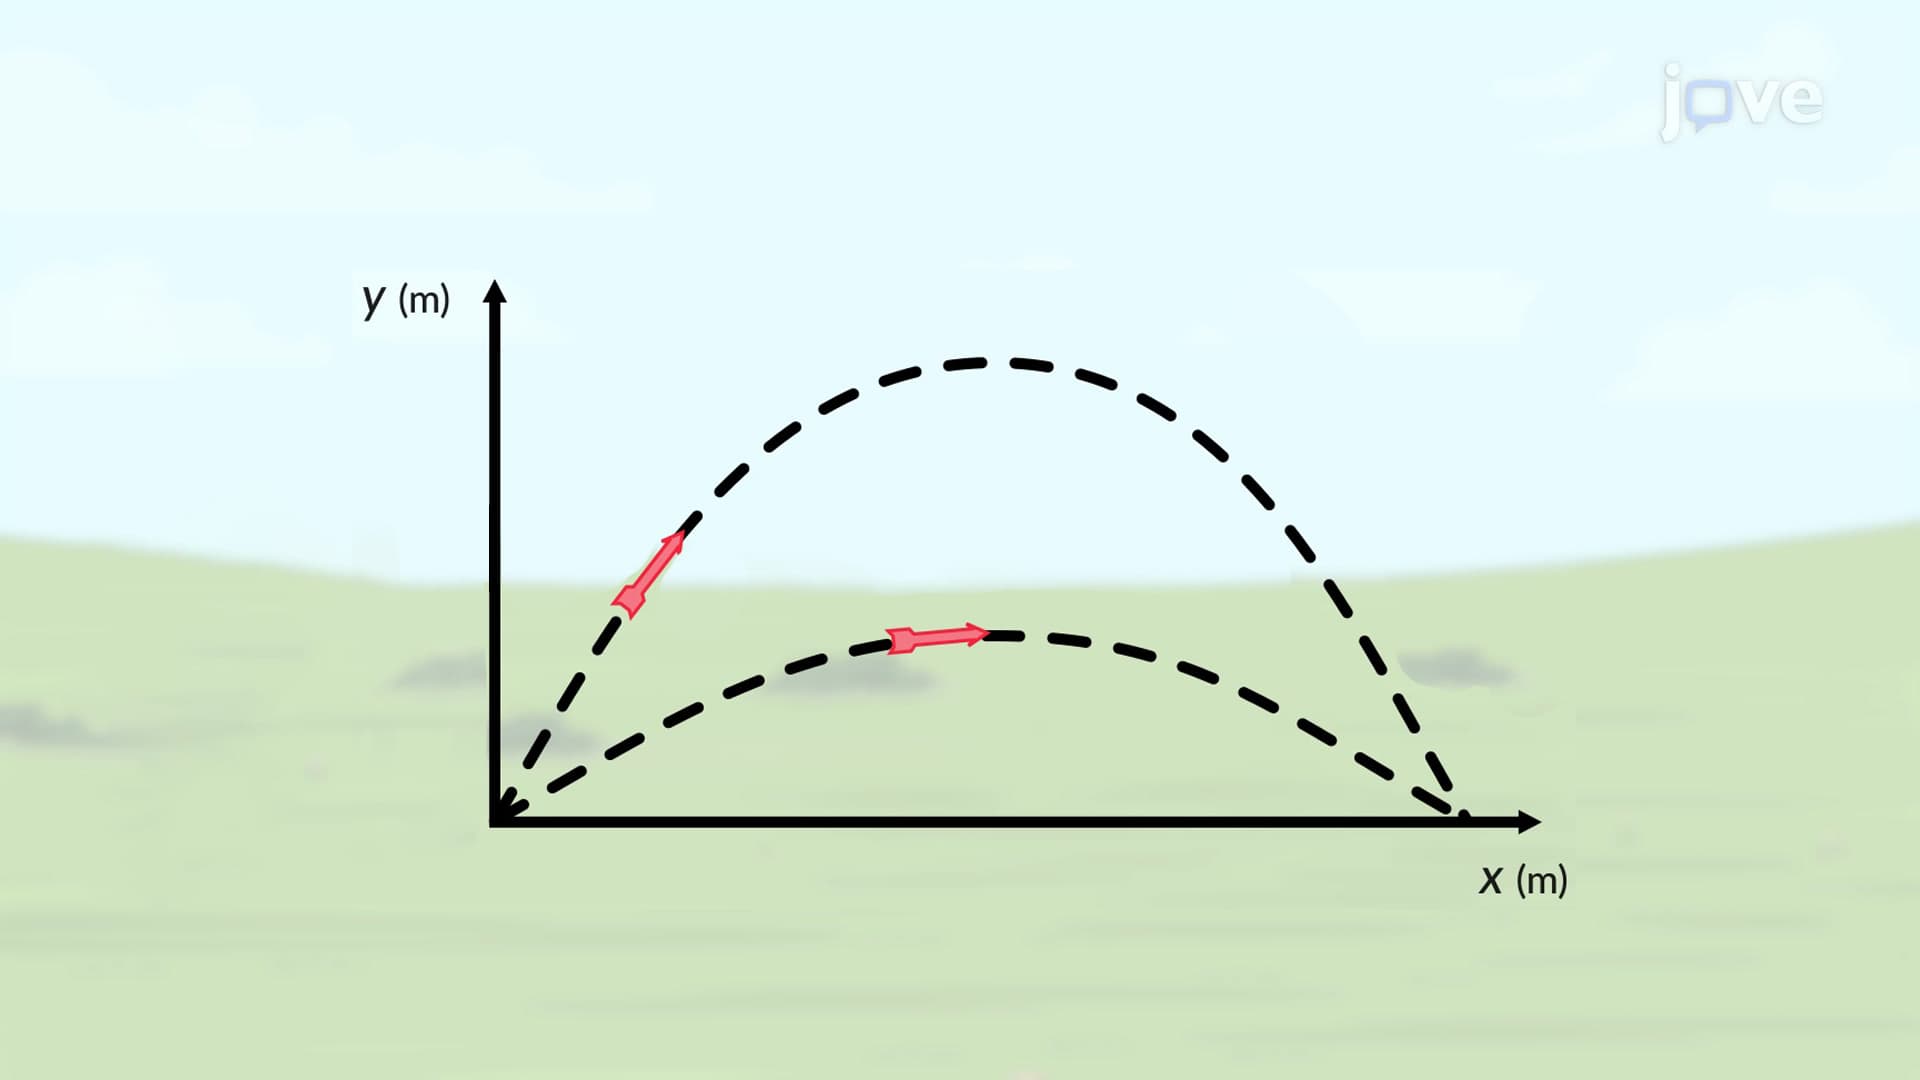
When we speak of the range (R) of a projectile on...
 01:42
Simple Harmonic Motion and Uniform Circular Motion
There is an easy way to produce simple harmonic motion by using uniform circular motion. For instance, consider a ball attached to a uniformly rotating...
 01:15
Torque Free Motion