Related Experiment Video
Updated: Feb 4, 2026
3D Orbital Tracking in a Modified Two-photon Microscope: An Application to the Tracking of Intracellular Vesicles
Published on: October 1, 2014
Tracking control of an underactuated ship by modified dynamic inversion
1School of Electrical and Information Engineering, Tianjin University, Tianjin 300072, China.

Abstract:
The tracking control problem of an underactuated ship is investigated. We intend to use the underactuated ship as an example to extend the traditional dynamic inversion control method to underactuated systems. The difficulty lies in the fact that the system has no relative degree, which prevents the application of standard dynamic inversion. Three modified dynamic inversion methods are proposed that are applicable to this system. The first is the well-known dynamic extension-based dynamic inversion (DEDI), which treats an input as a state and takes dynamic extension to achieve a relative degree. The second is virtual input-based dynamic inversion (VIDI), which treats a state as a virtual input to achieve a relative degree. The third is output redefinition-based dynamic inversion (ORDI), which selects a particular variable as a new output to achieve a relative degree. The three methods are generalizations of dynamic inversion control and remove some of its inherent limitations, making it applicable to a wide variety of underactuated systems. The effectiveness of the proposed methods is verified by numerical simulations.
Related Concept Videos
 01:29
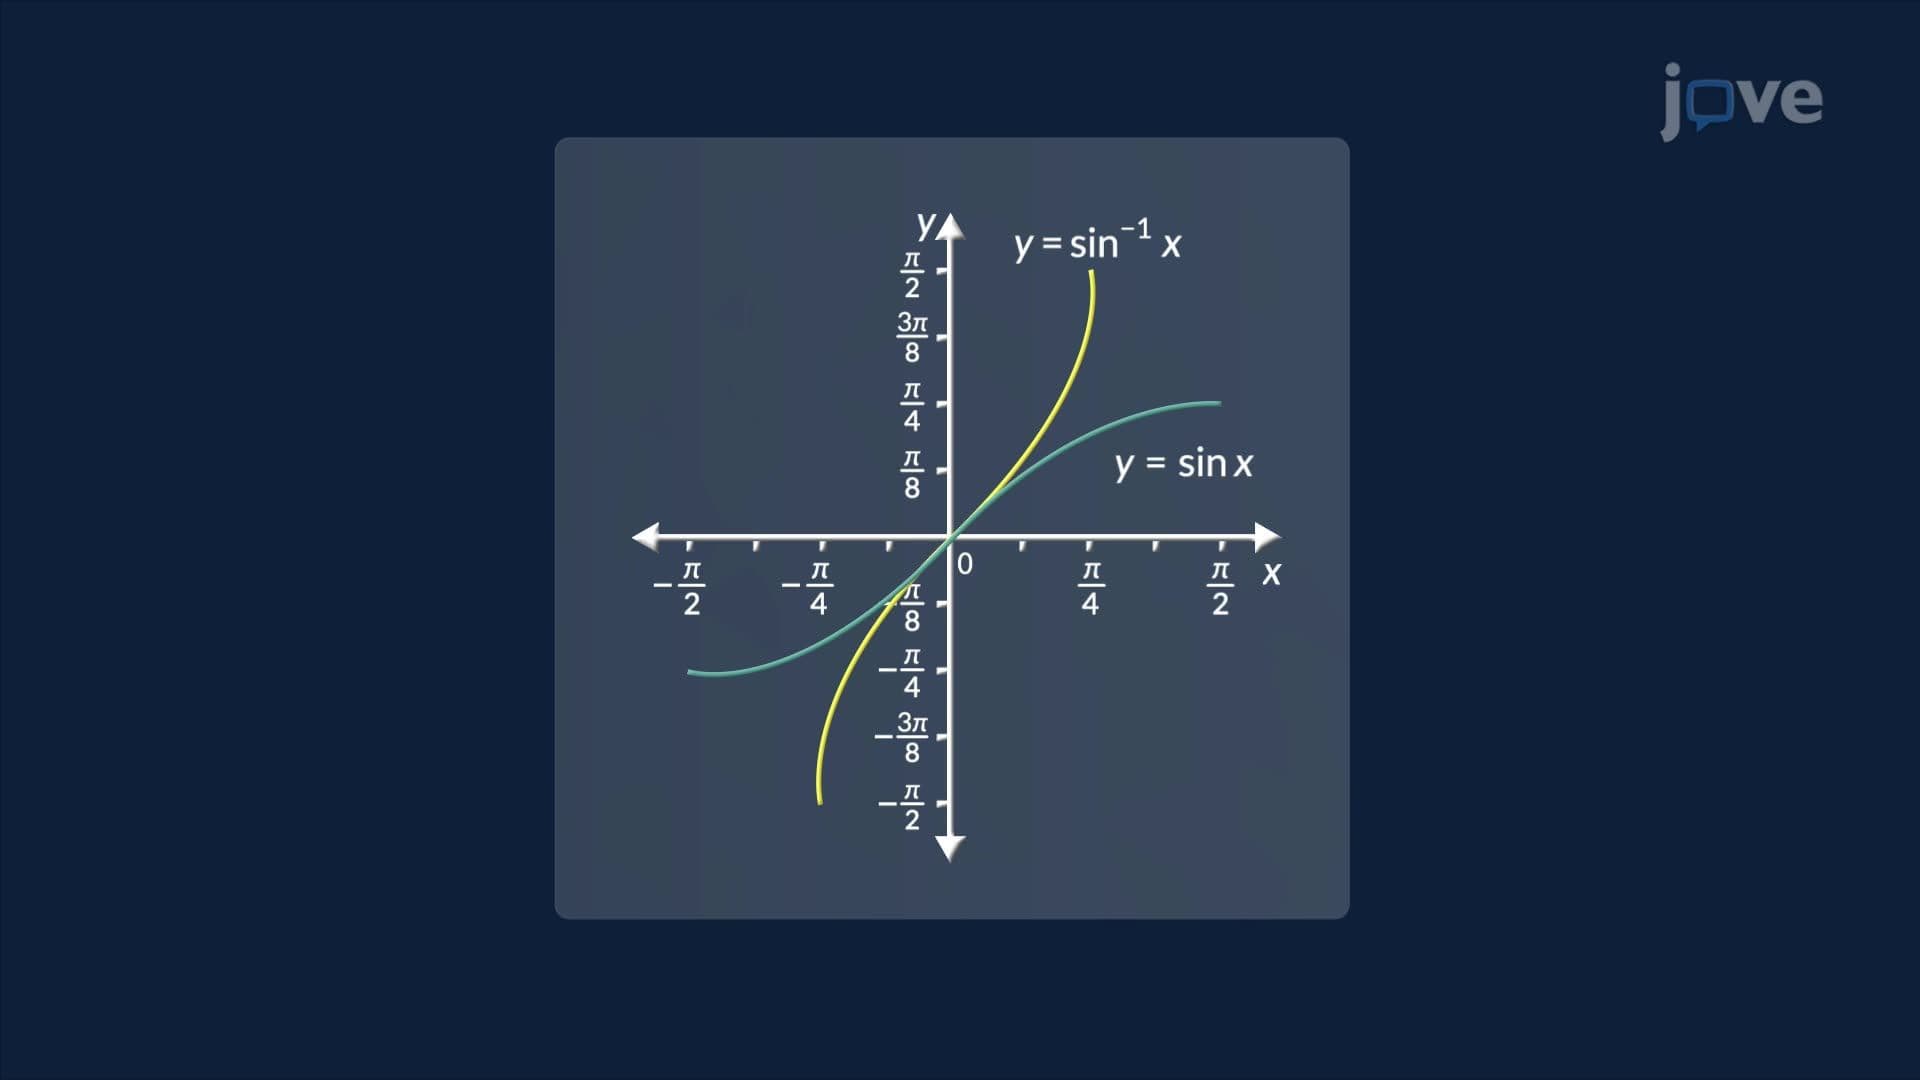
Inverse Trigonometric Functions
 01:25
Inverse Hyperbolic Functions and Their Derivatives
 01:30
Derivatives of Inverse Trigonometric Functions
 01:30
Hyperbolic and Inverse Hyperbolic Functions: Problem Solving
 01:20
Inverse z-Transform by Partial Fraction Expansion
To begin the process, the poles of the function are identified and the function is...
 02:20
Dynamic Equilibrium