Related Experiment Video
Updated: Feb 4, 2026
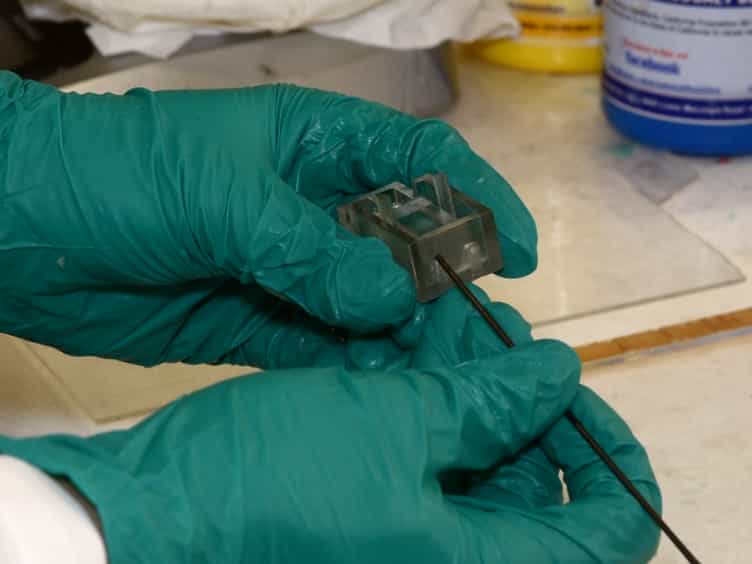
Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Evaluation of a pneumatic surgical robot with dynamic force feedback
Dimitrios Karponis1,2, Yokota Koya3, Ryoken Miyazaki3
1Institute of Biomaterials and Bioengineering, Tokyo Medical and Dental University, 2-3-10 Kanda-Surugadai, Chiyoda-ku, Tokyo, 101-0062, Japan. dk1714@imperial.ac.uk.

Abstract:
Robot-assisted surgery is limited by the lack of haptic feedback and increased operating times. Force scaling adjusts feedback transmitted to the operator through the use of scaling factors. Herein, we investigate how force scaling affects forces exerted in robotic surgery during simple and complex tasks, using a pneumatic surgical robot, IBIS VI. Secondary objectives were to test the effects of force scaling on operating time, depth of needle insertion and user satisfaction. Two novice males performed simple (modified block transfer) and complex (needle insertion) tasks under four scaling factors: 0.0, 0.5, 1.0 and 2.0. Single-blind experiments were repeated five times, with alternating scaling factors in random order. Increasing the scaling factor from 0.0 to 2.0 reduces forces in block transfer (p = 0.04). All feedback conditions reduce forces in needle insertion compared to baseline (0.5: p < 0.001, 1.0: p = 0.001, 2.0: p = 0.001). Time to complete block transfer is shorter for scaling factor 0.5 (p = 0.02), but not for 1.0 (p = 0.05) or 2.0 (p = 0.48), compared to baseline. Depth of needle insertion decreases consistently with incremental scaling factors (p < 0.001). Further reductions are observed upon augmenting feedback (0.5-2.0: p = 0.02). User satisfaction in block transfer is highest for intermediate scaling factors (0.0-1.0: p = 0.01), but no change is observed in needle insertion (p = 0.99). Increments in scaling factor reduce forces exerted, particularly in tasks requiring precision. Depth of needle insertion follows a similar pattern, but operating time and user satisfaction are improved by intermediate scaling factors. In summary, dynamic adjustment of force feedback can improve operative outcomes and advance surgical automation.
Related Concept Videos
 00:46
Feedback Inhibition
 01:01
Feedback Loops
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Facial Feedback Hypothesis
 01:07
Cell Signaling Feedback Loops
Negative feedback loops
Most signaling systems have negative feedback loops that can perform different functions such as output limiter, and adaptation.
Output limiter
Upon receiving an input signal, the cellular response rapidly increases until a threshold is reached. Beyond this threshold, a negative feedback loop...