Robust synchronization of networked manipulators using distributed dynamic H∞ controllers
Related Experiment Video
Updated: Feb 4, 2026
Author Spotlight: Investigating Islet Abnormalities and Function with a Pseudoislet Protocol
Published on: November 3, 2023
Haniyeh Seyed Alinezhad1, Mohammad Hosseinzadeh Yamchi1, Reza Mahboobi Esfanjani1
1Department of Electrical Engineering, Sahand University of Technology, Tabriz, Iran.

Abstract:
In this note, the problem of synchronization of networked non-identical manipulators is investigated in the presence of model uncertainties. The notion of nonlinear H∞ control is employed to design distributed output-feedback dynamic controllers for robust synchronization of the robots. The parameters of the synchronizing controllers are computed by solving a set of computationally tractable matrix inequalities instead of finding the solution of complicated differential inequalities which are usually encountered in the nonlinear H∞ context. Comparative simulation results are presented to verify the efficiency and applicability of the proposed method.
Related Concept Videos
 02:26
Protein Networks
These interactions can be represented through maps depicting protein-protein interaction networks, represented as nodes and edges. Nodes are circles that are representative of a protein,...
02:26Protein Networks
 02:18
Network Covalent Solids
To break or to melt a covalent network solid, covalent bonds must be broken. Because covalent bonds are relatively strong, covalent network solids are typically...
 01:30
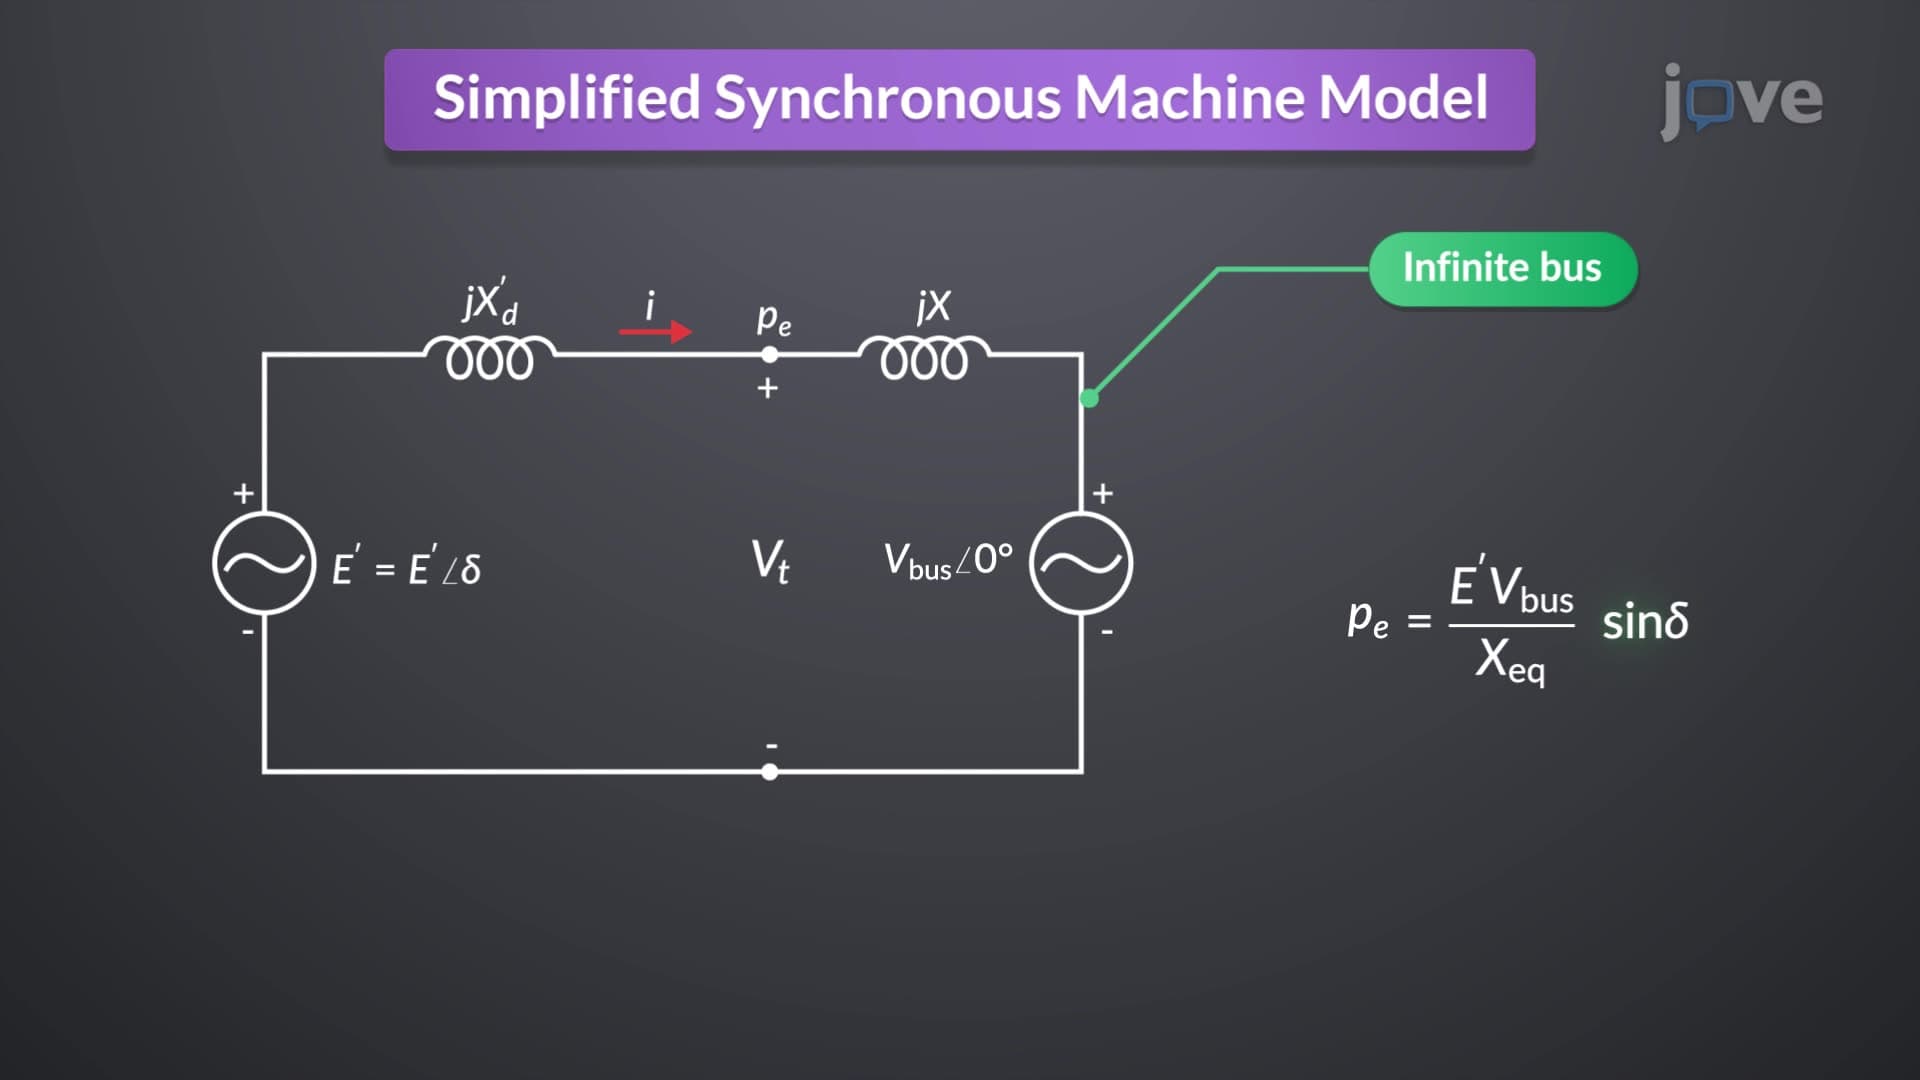
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:25
Drug Distribution: Volume of Distribution
 01:21
Manipulation and Analysis