Related Experiment Video
Updated: Feb 4, 2026
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Robust H∞ control for networked control systems with randomly occurring uncertainties: Observer-based case
1School of Information Science and Engineering, Wuhan University of Science and Technology, Wuhan, Hubei 430081, China; Engineering Research Center for Metallurgical Automation and Measurement Technology of Ministry of Education, Wuhan University of Science and Technology, Wuhan, Hubei 430081, China.

Abstract:
This paper investigates the problem of observer-based robust H∞ output feedback control for networked control systems (NCSs) with randomly occurring uncertainties, dynamic quantization, and packet loss. It is assumed that the system measurement output will be quantized by a dynamic quantizer and the random packet loss is represented by Bernoulli random binary distribution. In the presence of randomly occurring uncertainties, dynamic quantization, and packet loss, the attention of this research is focused on the design of observer-based robust H∞ output feedback controller such that the resulting system is stochastically stable with the prescribed H∞ noise attenuation level. The sufficient condition for the existence of such output feedback controller is expressed in the form of linear matrix inequality (LMI). Simulation results of two illustrative examples are proposed to demonstrate the effectiveness of the developed design method.
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
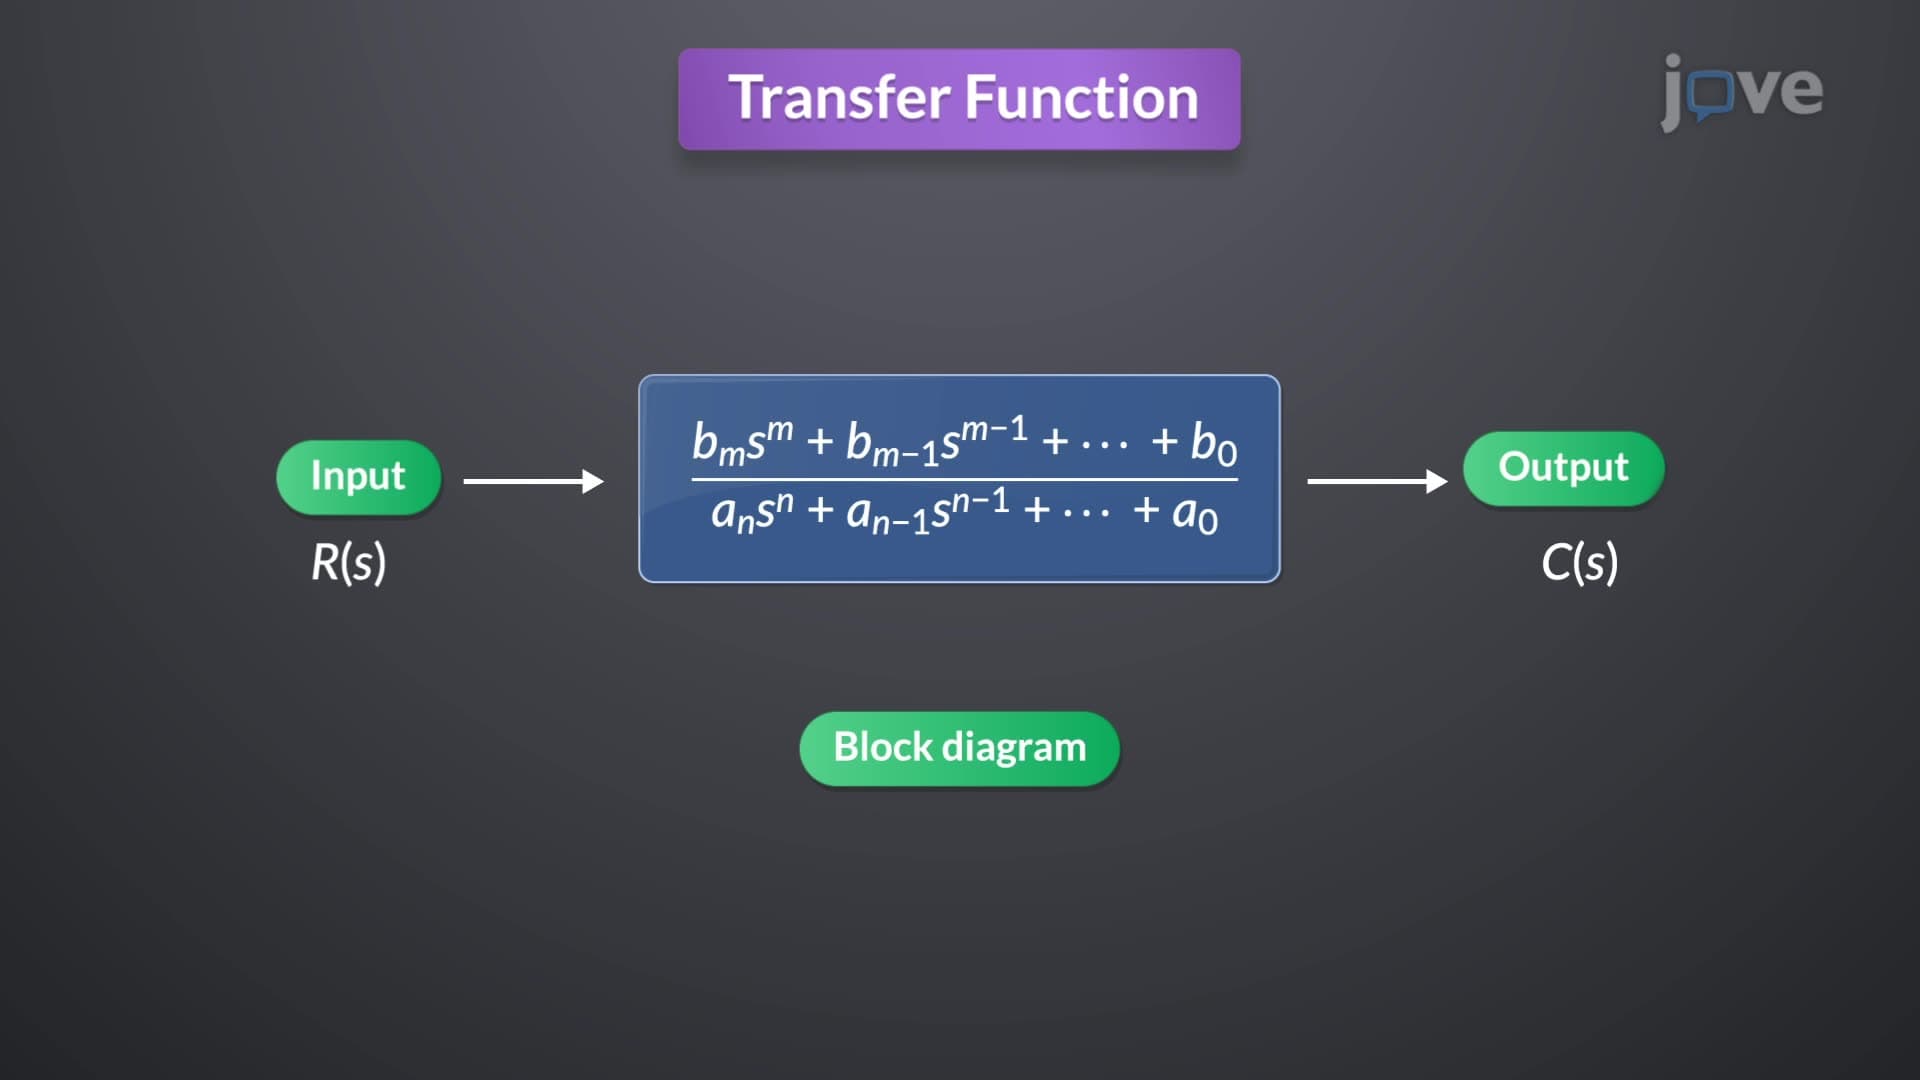
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 00:59
Propagation of Uncertainty from Random Error