Non-orthogonal one-step calibration method for robotized transcranial magnetic stimulation
Related Experiment Video
Updated: Feb 4, 2026
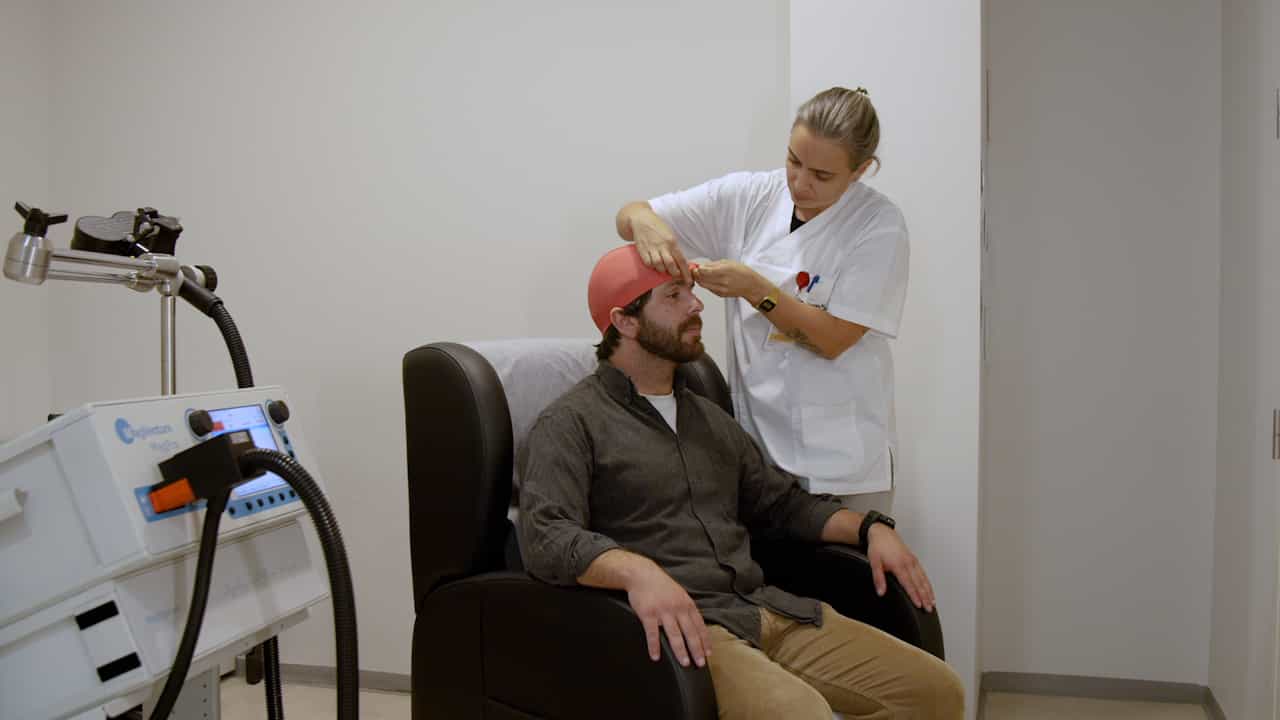
Conventional Repetitive Transcranial Magnetic Stimulation for Depression: A Step-by-Step Protocol
Published on: November 21, 2025
He Wang1, Jingna Jin1, Xin Wang1
1Institute of Biomedical Engineering, Chinese Academy of Medical Science & Peking Union Medical College, Tianjin, 300192, China.

Background:
Robotized transcranial magnetic stimulation (TMS) combines the benefits of neuro-navigation with automation and provides a precision brain stimulation method. Since the coil will normally remain unmounted between different clinical uses, hand/eye calibration and coil calibration are required before each experiment. Today, these two steps are still separate: hand/eye calibration is performed using methods proposed by Tsai/Lenz or Floris Ernst, and then the coil calibration is carried out based on the traditional TMS experimental step. The process is complex and time-consuming, and traditional coil calibration using a handheld probe is susceptible to greater calibration error.
Methods:
A novel one-step calibration method has been developed to confirm hand/eye and coil calibration results by formulating a matrix equation system and estimating its solution. Hand/eye calibration and coil calibration are performed to confirm the pose relationships of the marker/end effector 'X', probe/end effector 'Y', and robot/world 'Z'. First, the coil is fixed on the end effector of the robot. During the one-step calibration process, a marker is mounted on the top of the coil and a calibration probe is fixed at the actual effective position of the coil. Next, the robot end effector is moved to a series of random positions 'A', the tracking data of marker 'B' and probe 'C' is obtained correspondingly. Then, a matrix equation system AX = ZB and AY = ZC can be acquired, and it is computed using a least-squares approach. Finally, the calibration probe is removed after calibration, while the marker remains fixed to the coil during the TMS experiment. The methods were evaluated based on simulation data and on experimental data from an optical tracking device. We compared our methods with two classical methods: the QR24 method proposed by Floris Ernst and the handheld coil calibration method.
Results:
The new methods outperform the QR24 method in the aspect of translational accuracy and performs similarly in the aspect of rotational accuracy, the total translational error decreased more than fifty percent. The new approach also outperforms traditional handheld coil calibration of navigated TMS systems, the total translational error decreased three- to fourfold, and the rotational error decreased six- to eightfold. Furthermore, the convergence speed is improved 16- to 27-fold for the new algorithms.
Conclusion:
These results suggest that the new method can be used for hand/eye and coil calibration of a robotized TMS system. Two complex steps can be simplified using a least-squares approach.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:11
Glassware Calibration
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
 01:12
Instrument Calibration
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
 01:10
Calibration Curves: Correlation Coefficient
 01:19
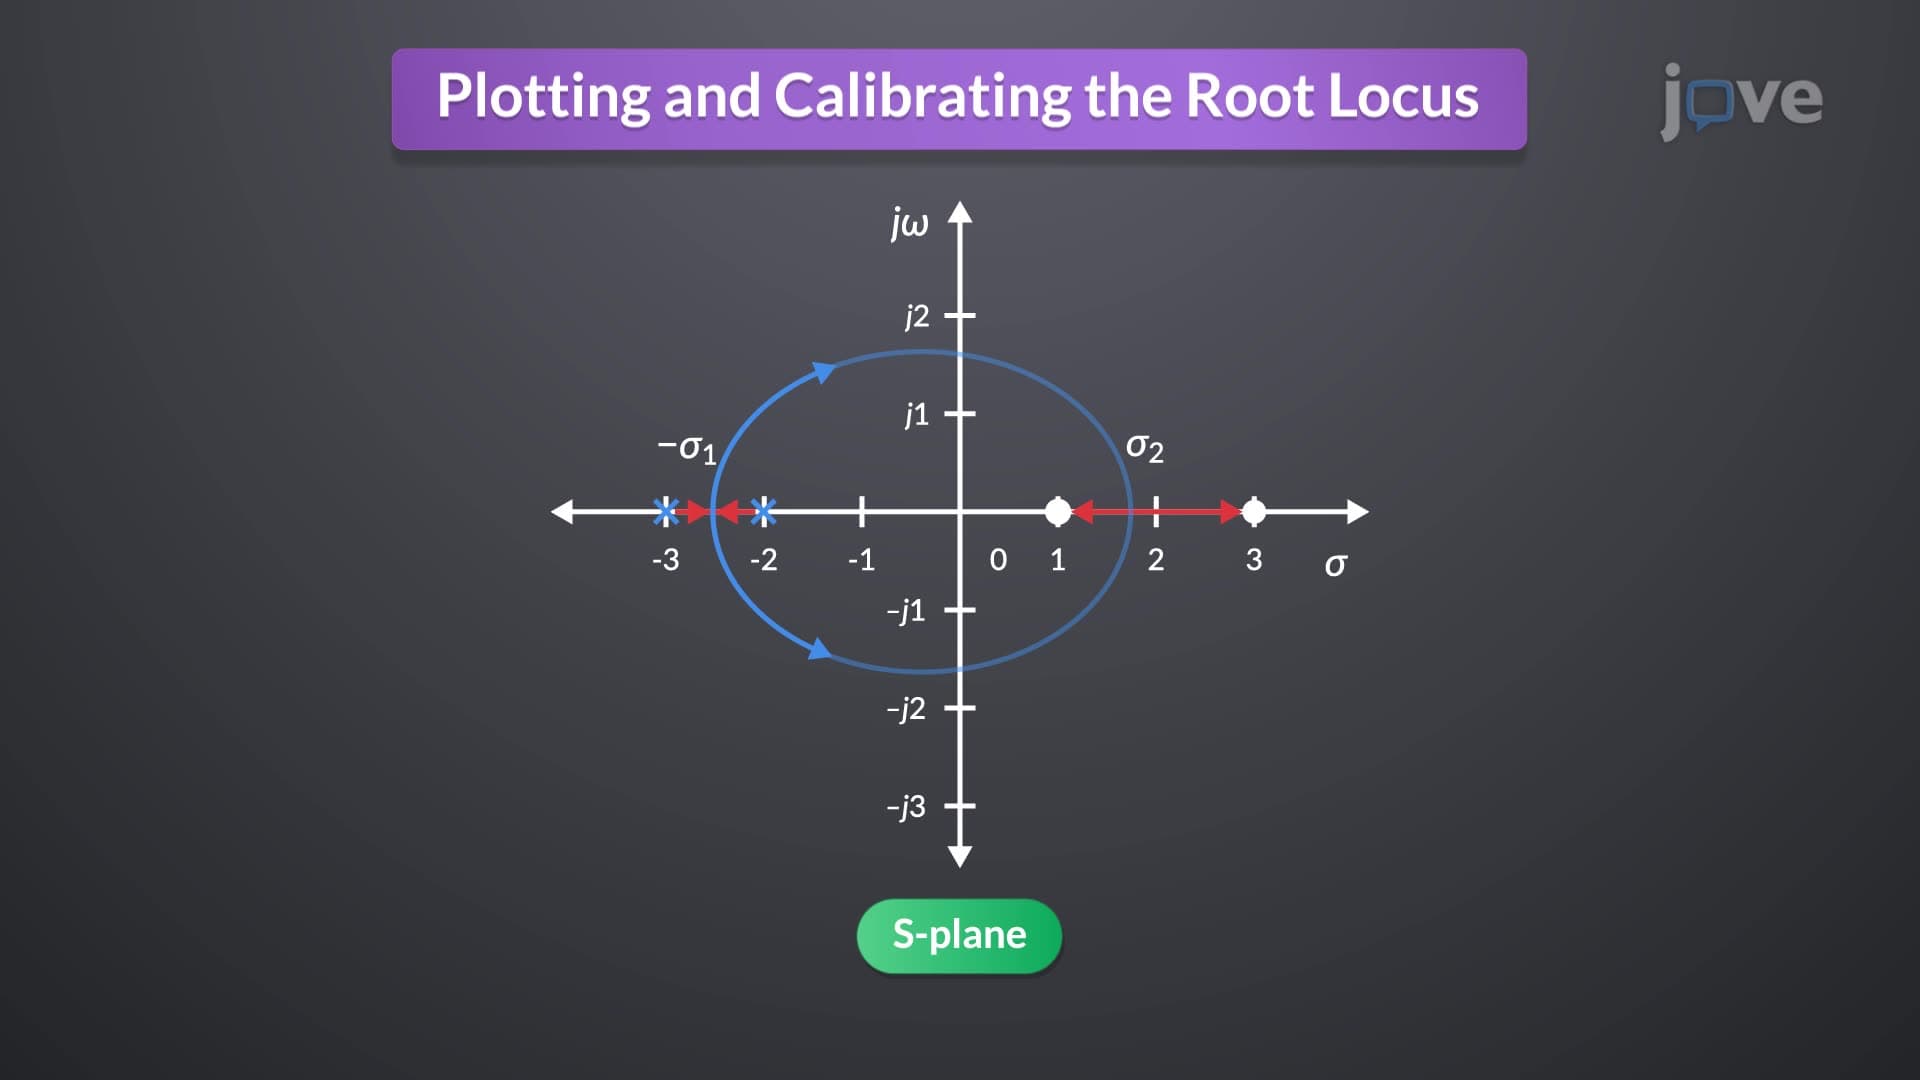
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:15
Assessment of blood pressure in brachial artery(one-step method)
Prepare for the Procedure: