
Dissociating motor learning from recovery in exoskeleton training post-stroke
Nicolas Schweighofer1, Chunji Wang2, Denis Mottet3
1Biokinesiology and Physical Therapy, University of Southern California, Los Angeles, USA. schweigh@usc.edu.

Background:
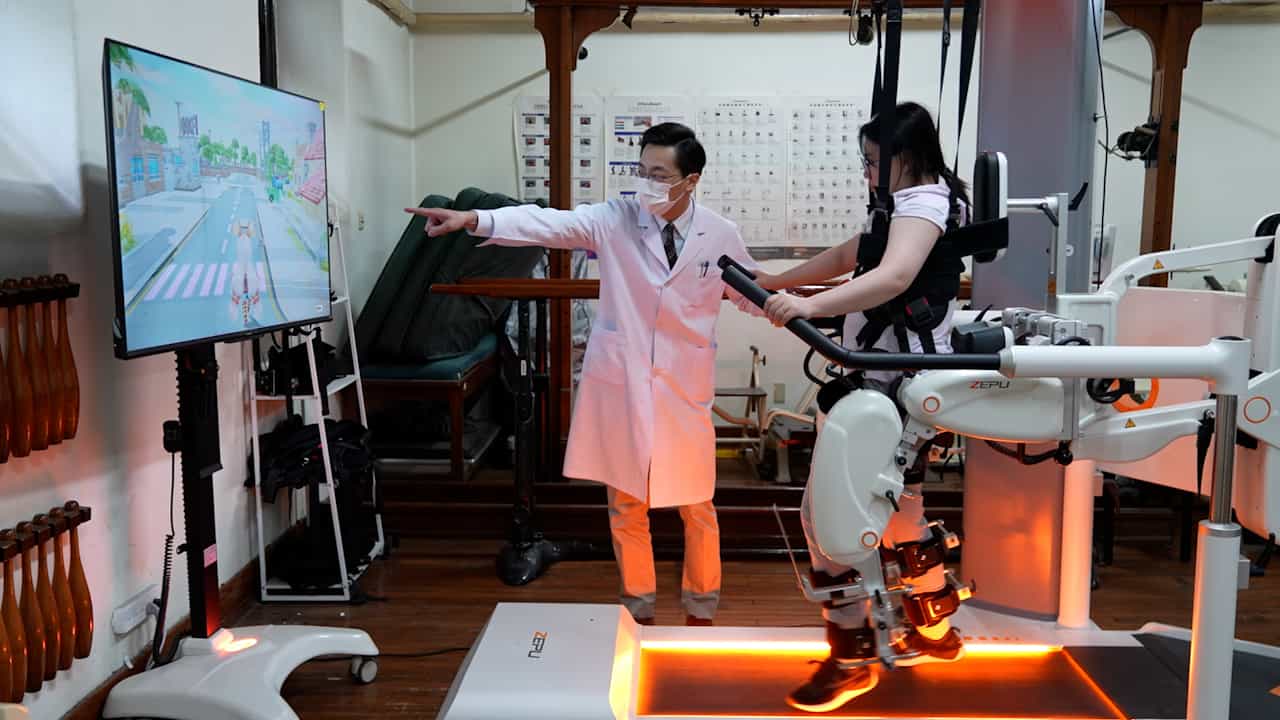
A large number of robotic or gravity-supporting devices have been developed for rehabilitation of upper extremity post-stroke. Because these devices continuously monitor performance data during training, they could potentially help to develop predictive models of the effects of motor training on recovery. However, during training with such devices, patients must become adept at using the new "tool" of the exoskeleton, including learning the new forces and visuomotor transformations associated with the device. We thus hypothesized that the changes in performance during extensive training with a passive, gravity-supporting, exoskeleton device (the Armeo Spring) will follow an initial fast phase, due to learning to use the device, and a slower phase that corresponds to reduction in overall arm impairment. Of interest was whether these fast and slow processes were related.
Methods:
To test the two-process hypothesis, we used mixed-effect exponential models to identify putative fast and slow changes in smoothness of arm movements during 80 arm reaching tests performed during 20 days of exoskeleton training in 53 individuals with post-acute stroke.
Results:
In line with our hypothesis, we found that double exponential models better fit the changes in smoothness of arm movements than single exponential models. In contrast, single exponential models better fit the data for a group of young healthy control subjects. In addition, in the stroke group, we showed that smoothness correlated with a measure of impairment (the upper extremity Fugl Meyer score - UEFM) at the end, but not at the beginning, of training. Furthermore, the improvement in movement smoothness due to the slow component, but not to the fast component, strongly correlated with the improvement in the UEFM between the beginning and end of training. There was no correlation between the change of peaks due to the fast process and the changes due to the slow process. Finally, the improvement in smoothness due to the slow, but not the fast, component correlated with the number of days since stroke at the onset of training - i.e. participants who started exoskeleton training sooner after stroke improved their smoothness more.
Conclusions:
Our results therefore demonstrate that at least two processes are involved in in performance improvements measured during mechanized training post-stroke. The fast process is consistent with learning to use the exoskeleton, while the slow process independently reflects the reduction in upper extremity impairment.

Related Concept Videos
 01:27
Dissociative Disorders
Dissociative Fugue
A hallmark feature of dissociative disorders is the dissociative fugue...
 01:21
Dissociative Amnesia
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:30
Dissociative Identity Disorder
 01:24
Muscle Recovery and Fatigue
 01:27
Associative Learning
Classical conditioning, also known...