Related Experiment Video
Updated: Feb 4, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Multiobjective Rule-Based Cooperative Continuous Ant Colony Optimized Fuzzy Systems With a Robot Control Application

Abstract:
This paper proposes a new rule-based cooperative framework for multiobjective evolutionary fuzzy systems (FSs). Based on the framework, a multiobjective rule-based cooperative continuous ant-colony optimization (MO-RCCACO) algorithm is proposed to optimize all of the free parameters in FSs. Instead of optimization using a single colony of FSs (solutions), the MO-RCCACO consists of r subcolonies of size N cooperatively optimizing an FS that consists of r rules, with a subcolony optimizing only a single fuzzy rule. In addition, an auxiliary colony is created to store all of the fuzzy rules in the best-so-far N FSs to enhance the optimization ability of MO-RCCACO. The performance ranking of different fuzzy rules in the same subcolony is performed based on the multiobjective function values of their participating FSs by using Pareto nondominated sorting and the crowding distance. The MO-RCCACO is applied to find the Pareto-optimal fuzzy controllers (FCs) of a mobile robot for wall following with multiple control objectives. The optimization ability of the MO-RCCACO is verified through comparisons with various multiobjective population-based optimization algorithms in the robot wall-following control problem. Experimental results verify the effectiveness of the MO-RCCACO-based FCs for the boundary following control of a real robot.
Related Concept Videos
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:22
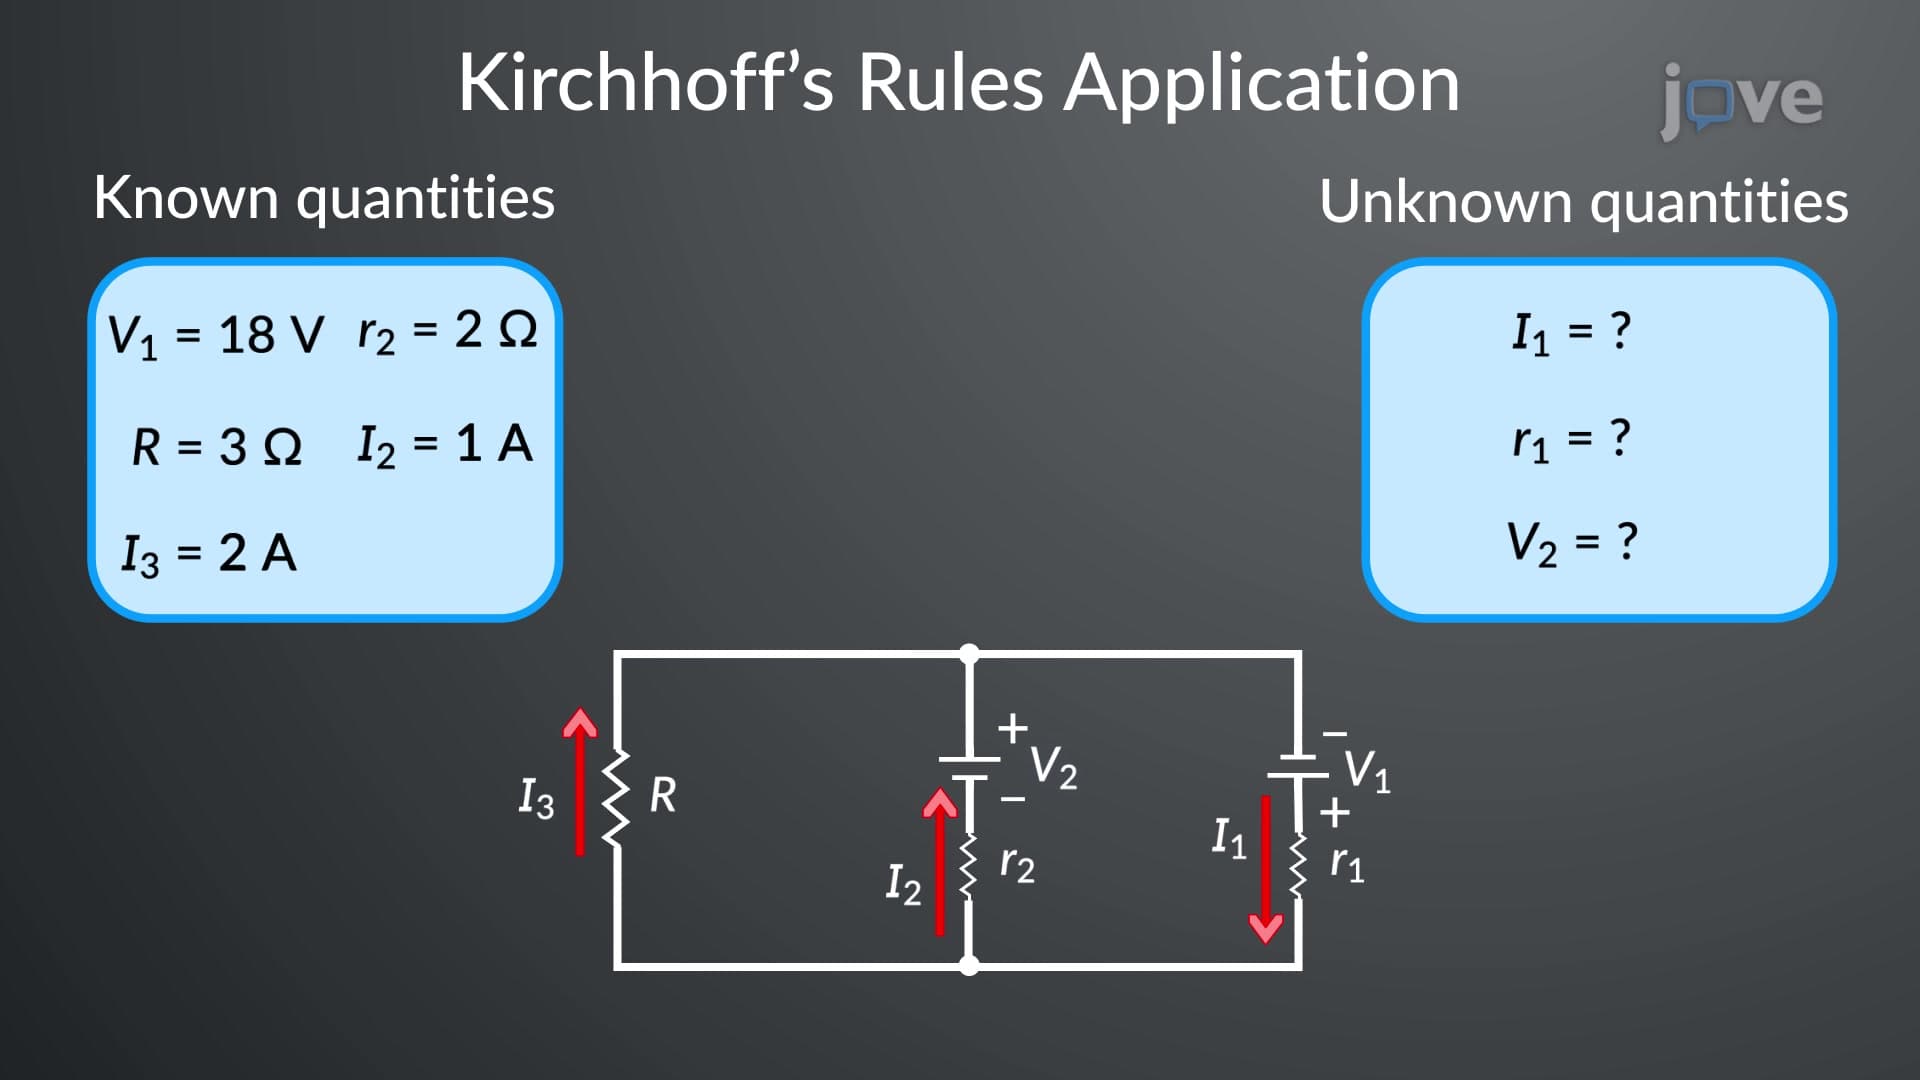
Kirchoff's Rules: Application
When applying Kirchhoff's first rule, the junction rule, label the current in each branch and decide its direction. If the chosen direction is wrong, it will have the correct magnitude, although the...
 01:58
Cooperative Allosteric Transitions
 01:10
Control Systems
At the heart...
 02:13
Cooperative Binding of Transcription Regulators
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...