A robust quantized consensus protocol for discrete-time multi-agent systems with additive noise
Related Experiment Video
Updated: Feb 2, 2026
Continuous Measurement of Biological Noise in Escherichia Coli Using Time-lapse Microscopy
Published on: April 27, 2021
1Department of Automation, University of Science and Technology of China, Hefei, China.

Abstract:
This paper investigates the consensus problem of multiple discrete-time integrator agents with communication constraints and additive process noise. It proposes a protocol to achieve the approximate consensus of agents over inter-agent communication networks with finite bit rates. Under that protocol, dynamic encoding and decoding algorithms are implemented for each pair of neighboring agents to transmit quantized states at a finite bit rate. With received quantized states of neighboring agents, the control input of each agent is locally computed. Particularly input saturation is introduced into the local controllers of agents and places both lower and upper bounds on the local control inputs of agents. These control input bounds can be known in advance and greatly enhance the robustness of the consensus protocol. Under the proposed protocol, the approximate consensus can be guaranteed at any finite bit rate to encode the states of agents. It is shown that even a single bit per time step is enough for the desired approximate consensus. The additive process noise does not increase the bit rate required for that approximate consensus. Moreover, the proposed consensus protocol can be designed with only an upper bound on the number of agents and is more robust than some previous consensus protocols which may require the global information of the inter-agent network topology, such as the second largest eigenvalue of the Laplacian matrix. Even when some communication links are broken due to communication failure or some nodes leave, the same set of consensus parameters can still robustly guarantee the expected approximate consensus. Simulations are conducted to illustrate the effectiveness of the proposed quantized consensus protocol.
More Related Videos
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:26
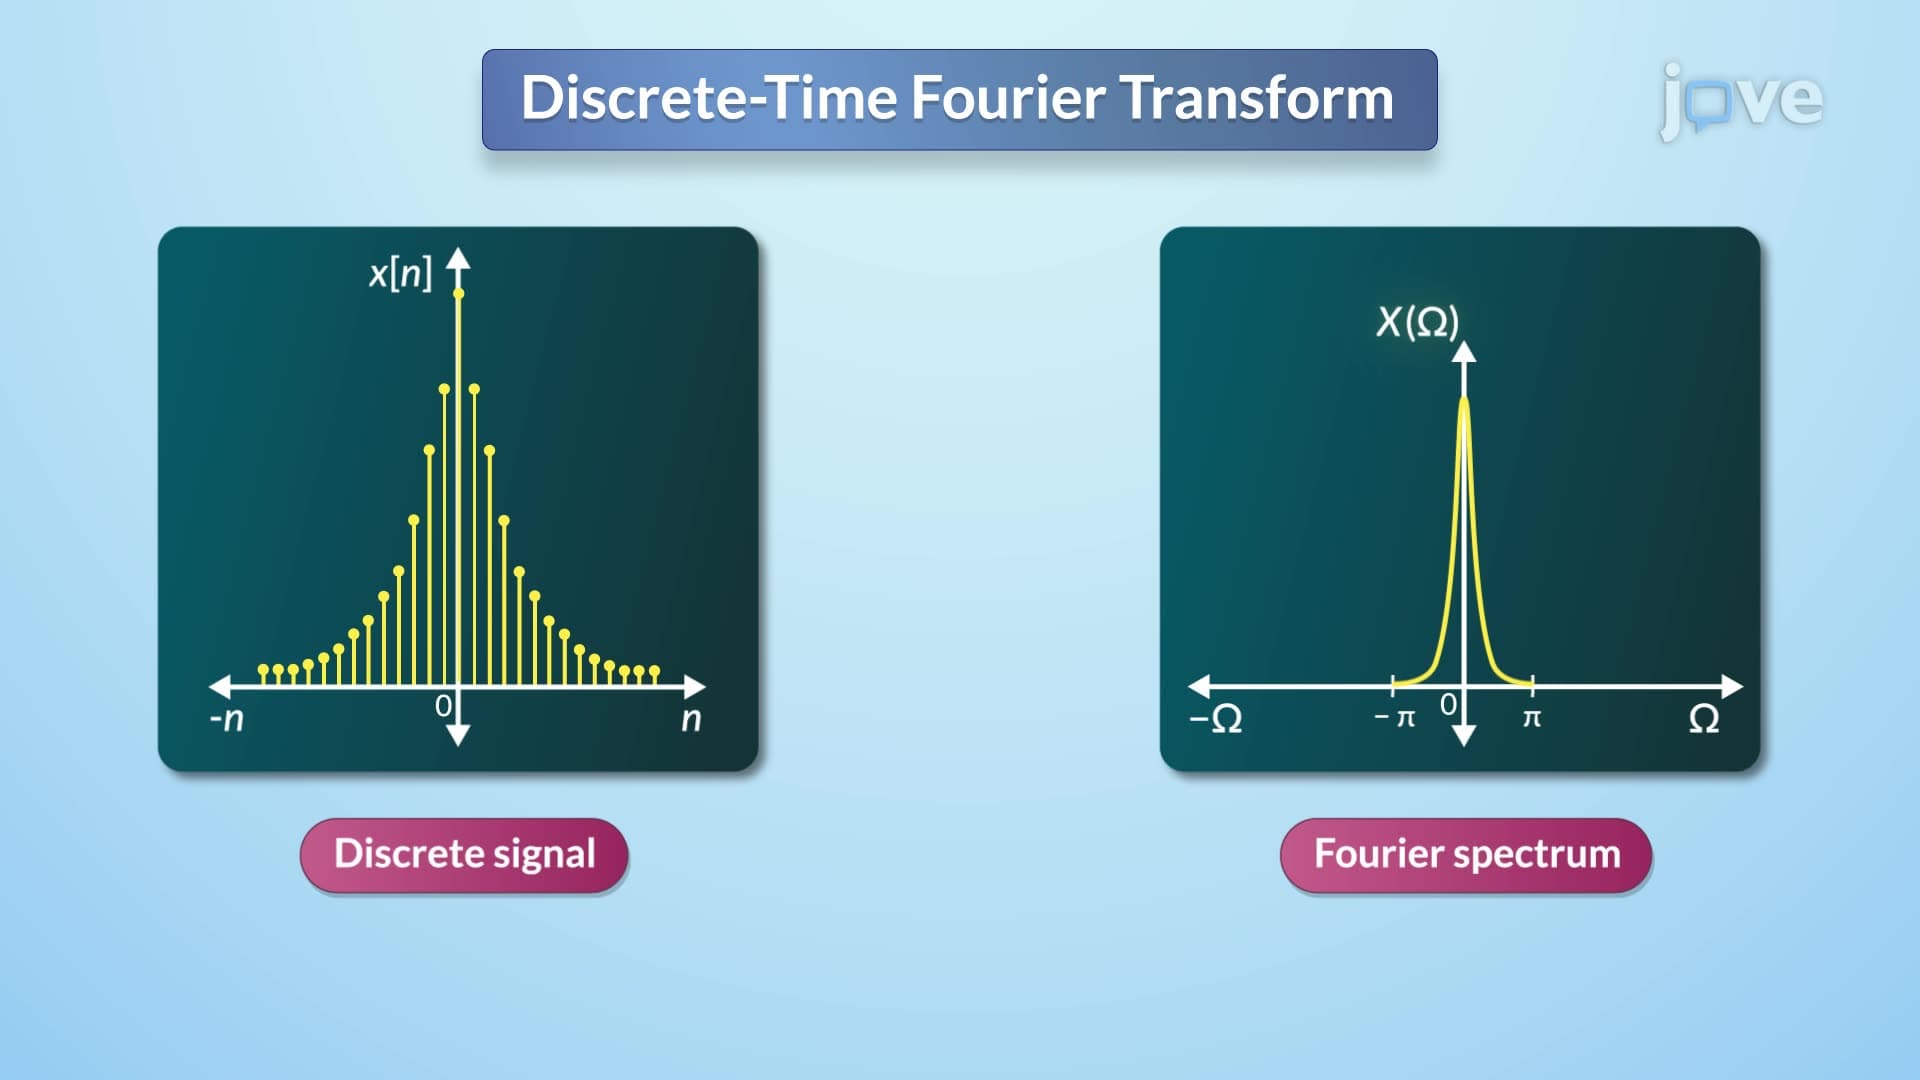
Discrete-time Fourier transform
One of the notable...
 01:16
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...