Related Experiment Video
Updated: Feb 1, 2026
Gene Editing of Primary Rhesus Macaque B Cells
Published on: February 10, 2023
Bipedal gait versatility in the Japanese macaque (Macaca fuscata)
Naomichi Ogihara1, Eishi Hirasaki2, Emanuel Andrada3
1Department of Mechanical Engineering, Keio University, 3-14-1 Hiyoshi Kohoku-ku, Yokohama 223-8522, Japan; Department of Biological Science, Graduate School of Science, The University of Tokyo, 7-3-1 Hongo Bunkyo-ku, Tokyo 113-0033, Japan.

Abstract:
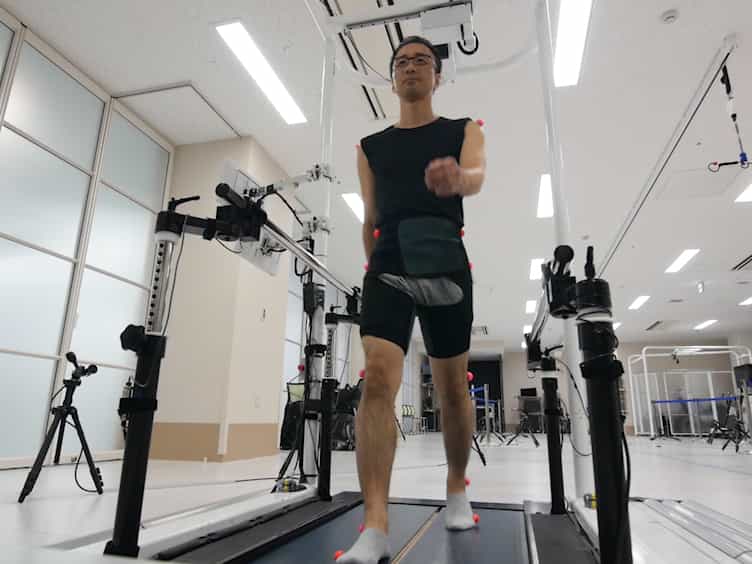
It was previously believed that, among primates, only humans run bipedally. However, there is now growing evidence that at least some non-human primates can not only run bipedally but can also generate a running gait with an aerial phase. Japanese macaques trained for bipedal performances have been known to exhibit remarkable bipedal locomotion capabilities, but no aerial-phase running has previously been reported. In the present study, we investigated whether Japanese macaques could run with an aerial phase by collecting bipedal gait sequences from three macaques on a level surface at self-selected speeds (n = 188). During our experiments, body kinematics and ground reaction forces were recorded by a motion-capture system and two force plates installed within a wooden walkway. Our results demonstrated that macaques were able to utilize a variety of bipedal gaits including grounded running, skipping, and even running with an aerial phase. The self-selected bipedal locomotion speed of the macaques was fast, with Froude speed ranging from 0.4 to 1.3. However, based on congruity, no single trial that could be categorized as a pendulum-like walking gait was observed. The parameters describing the temporal, kinematic, and dynamic characteristics of macaque bipedal running gaits follow the patterns previously documented for other non-human primates and terrestrial birds that use running gaits, but are different from those of humans and from birds' walking gaits. The present study confirmed that when a Japanese macaque engages in bipedal locomotion, even without an aerial phase, it generally utilizes a spring-like running mechanism because the animals have a limited ability to stiffen their legs. That limitation is due to anatomical restrictions determined by the morphology and structure of the macaque musculoskeletal system. The general adoption of grounded running in macaques and other non-human primates, along with its absence in human bipedal locomotion, suggests that abandonment of compliant gait was a critical transition in the evolution of human obligatory bipedalism.
Related Concept Videos
 03:21
Genome Size and the Evolution of New Genes
 03:02
Organic Compounds
 02:51
Metal-Ligand Bonds
In these complexes, transition metals form coordinate covalent bonds, a kind of Lewis acid-base interaction in which both of the electrons in the bond are contributed by a donor (Lewis base) to an electron acceptor (Lewis acid). The Lewis acid in...