LED chip accurate positioning control based on visual servo using dual rate adaptive fading Kalman filter

Ziyue Wang1, Shihua Gong1, Delong Li1
1State Key Lab of Digital Manufacturing Equipment & Technology, School of Mechanical Science and Engineering, Huazhong University of Science and Technology, Wuhan 430074, PR China.

Abstract:
In this paper, to improve the positioning accuracy of LED chip, a dual rate adaptive fading Kalman filter algorithm with delay compensation is proposed and applied to the LED chip visual servo positioning system. Firstly, a structure of dual rate Kalman filter is introduced to the visual servo control system, which compensate the visual information delay and realize the accurate time sequential coordination of encoder and visual feedback. Then, considering the inaccuracy of system mathematical model, the adaptive forgetting factor is added to the iterative process of above algorithm, and the impact of accumulated model error on system stability is consequently mitigated. Finally, the experimental results show that the proposed method obviously decreases the positioning errors of LED chip and is robust to inaccuracy and uncertainty of system model parameters.

Related Concept Videos
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:25
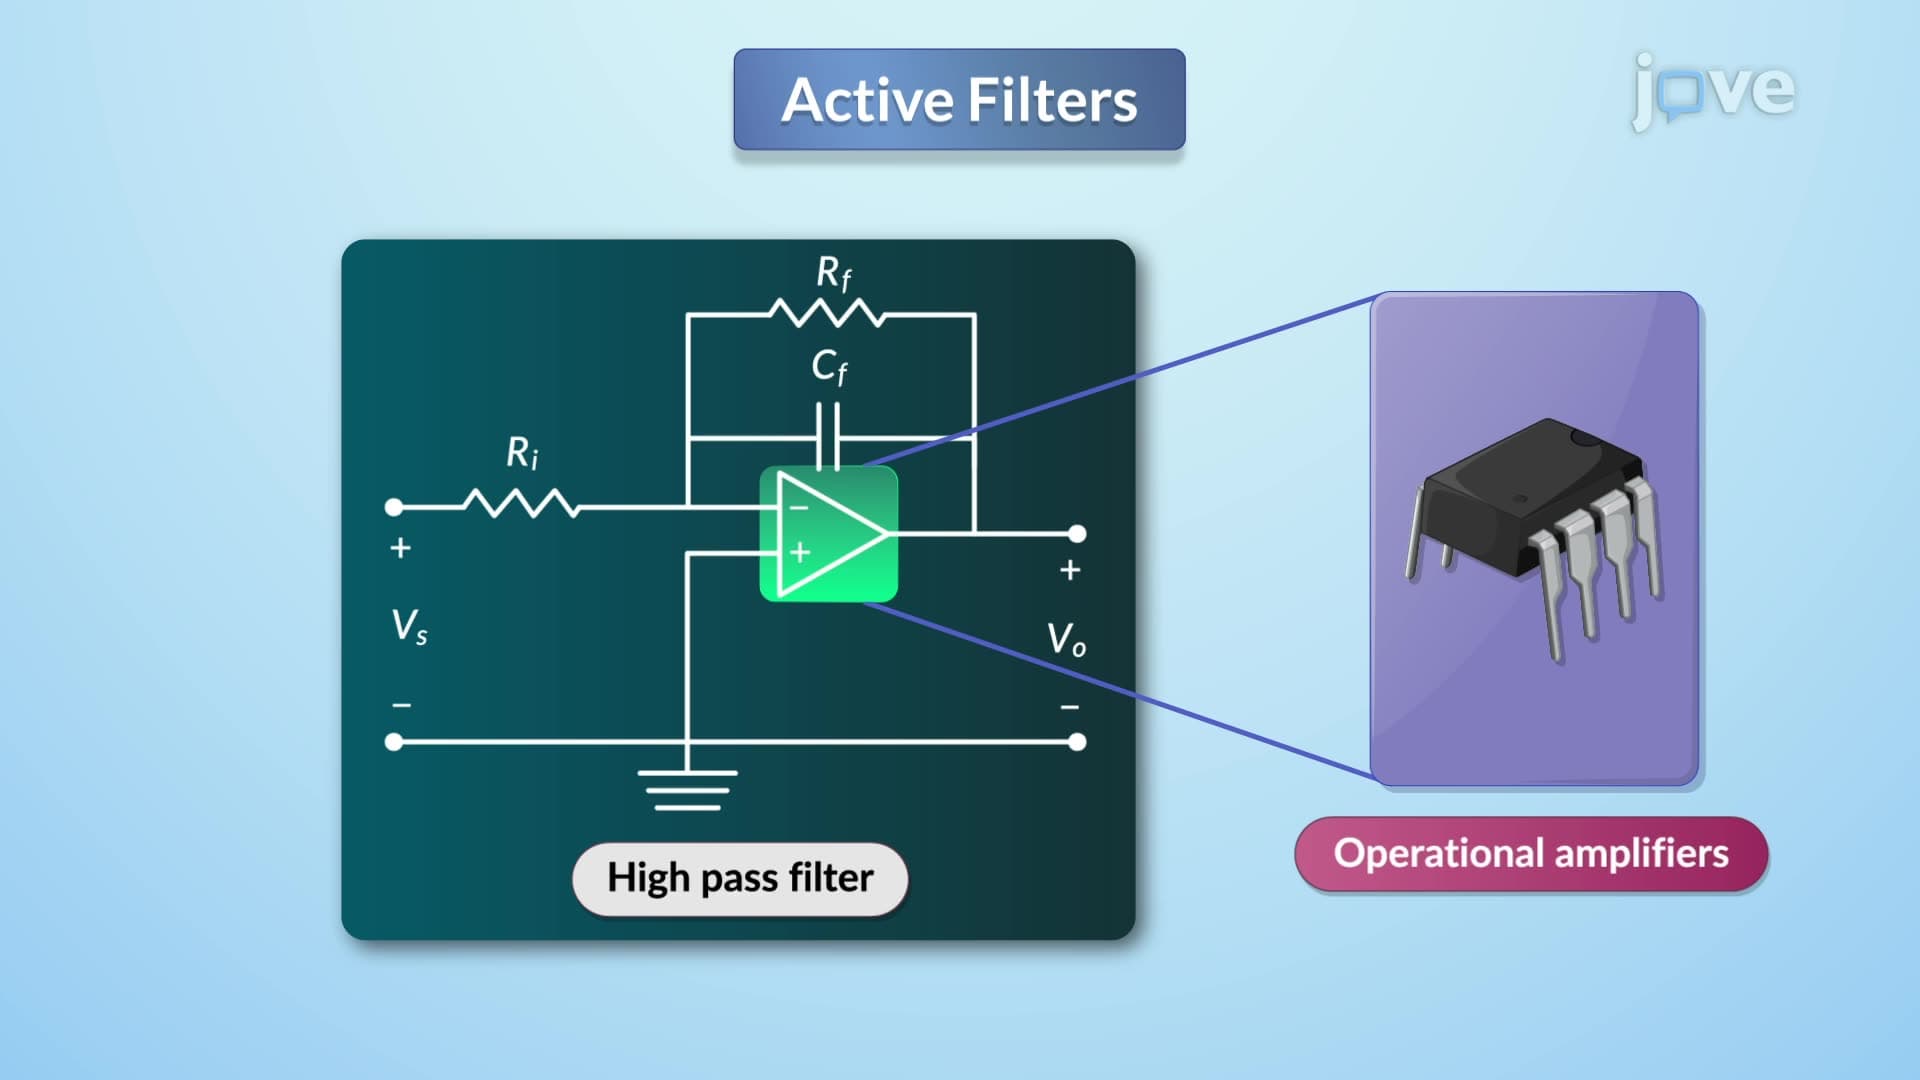
Active Filters
 02:05
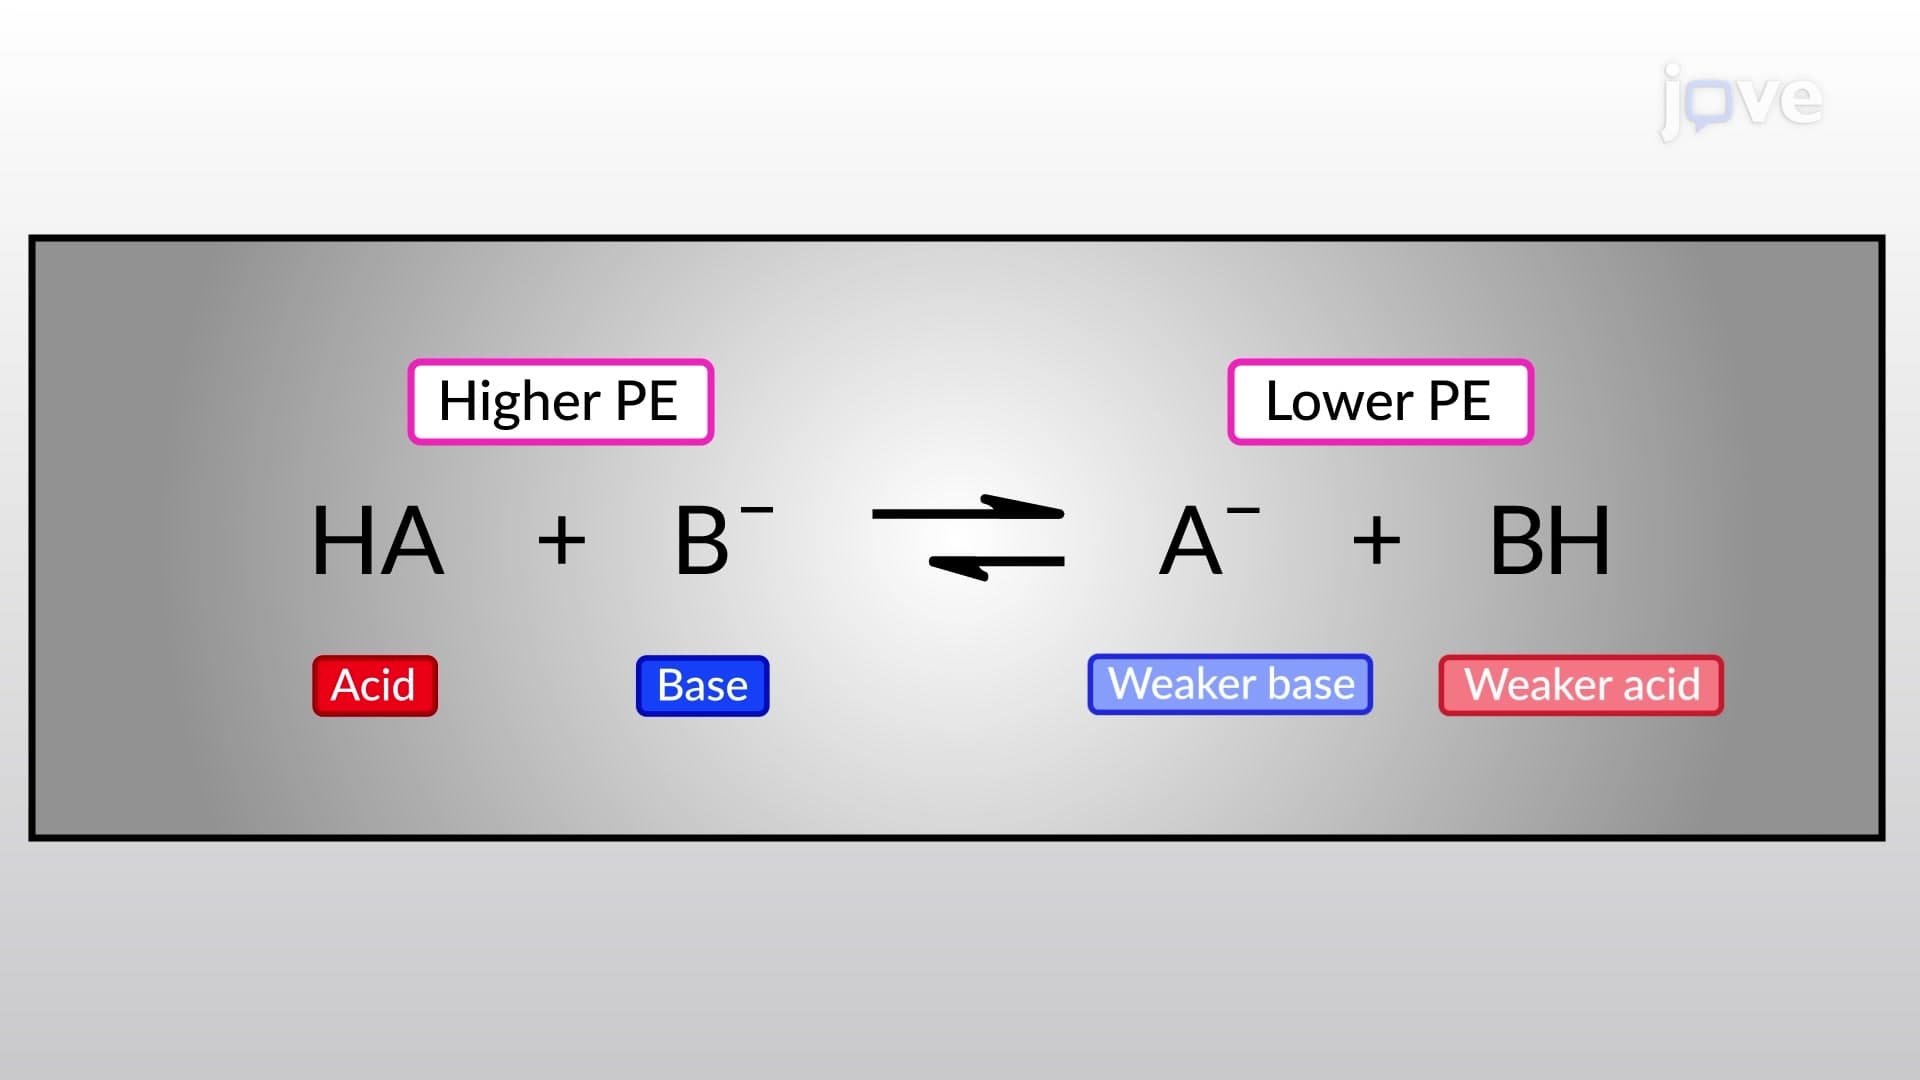
Position of Equilibrium in Acid-Base Reactions
 02:53
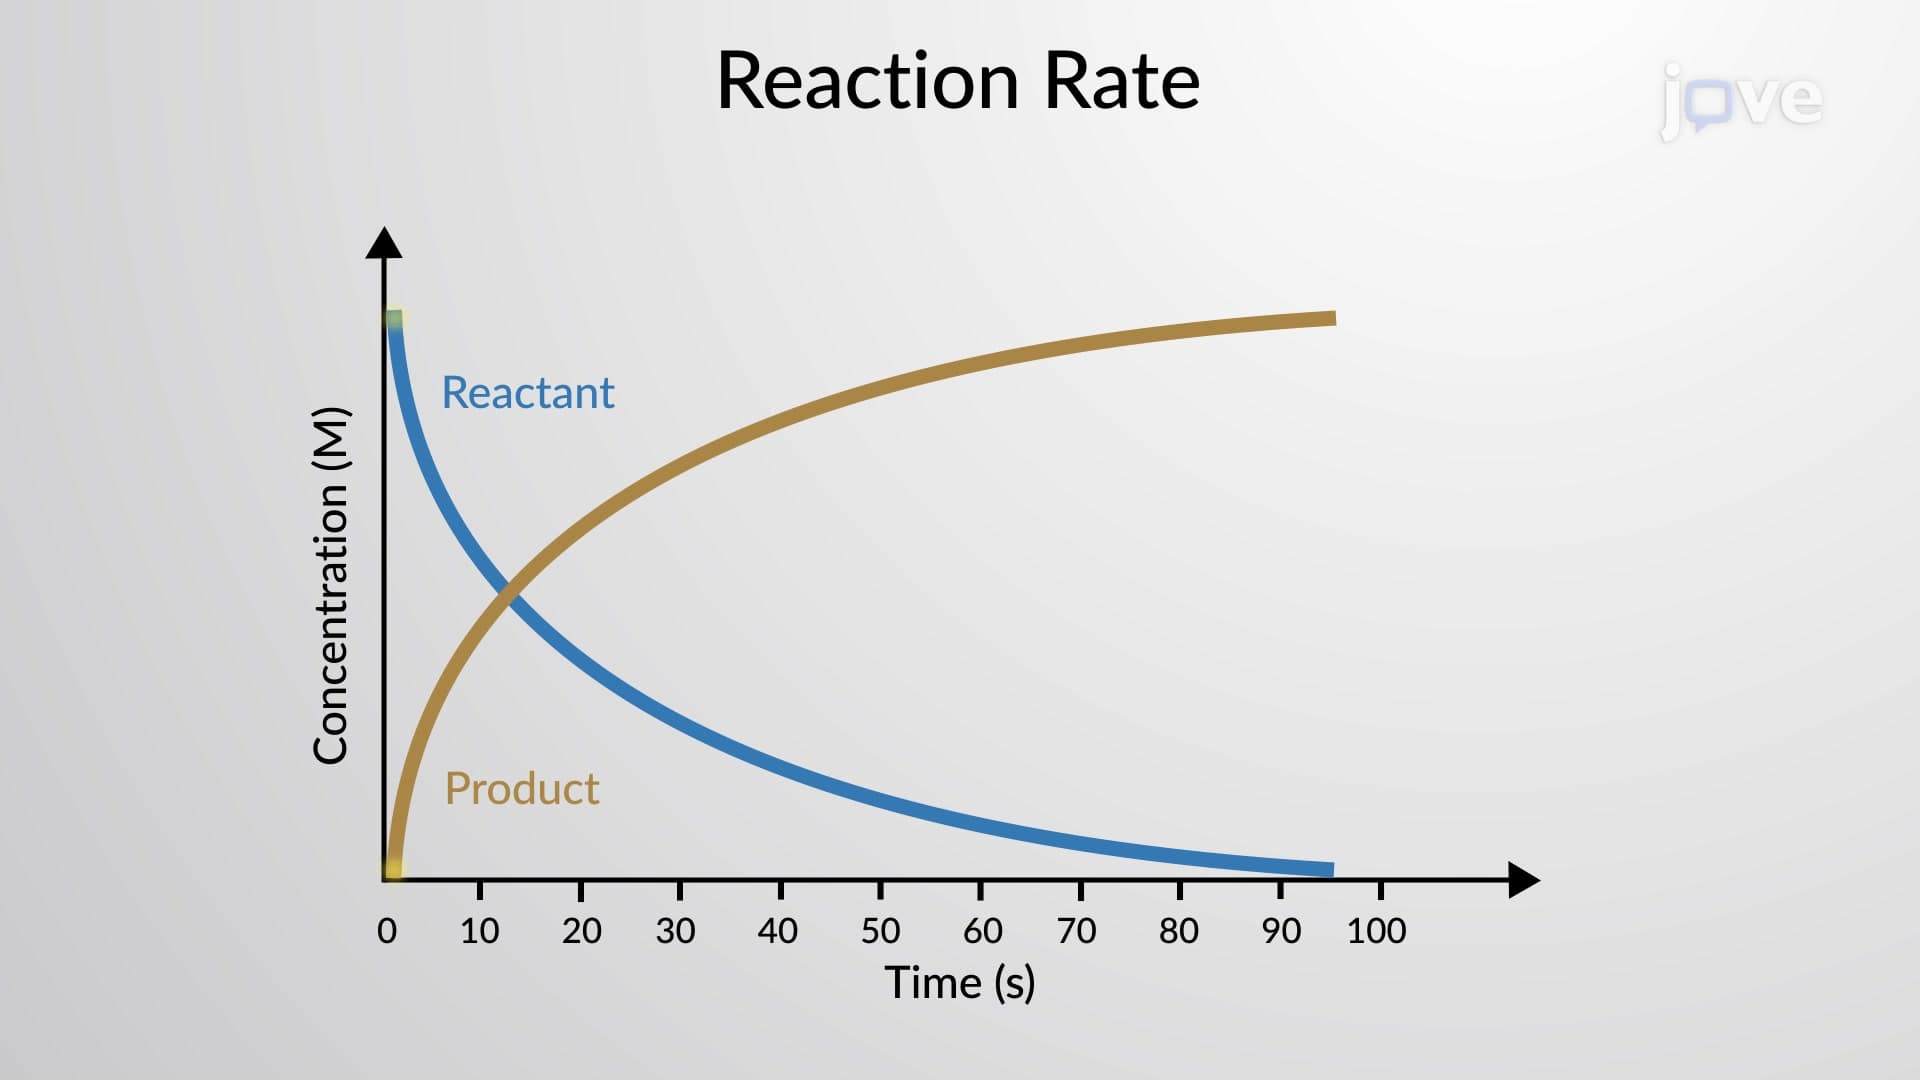
Reaction Rate
The mathematical representation of the change in the concentration of reactants and products, over time, is the rate...
 02:32
Position-effect Variegation
 03:03
Concentration and Rate Law
For example, in a generic reaction aA + bB ⟶ products, where a and b are stoichiometric coefficients, the rate law can be written as: