A Region-Based Gauss-Newton Approach to Real-Time Monocular Multiple Object Tracking
Related Experiment Video
Updated: Feb 1, 2026
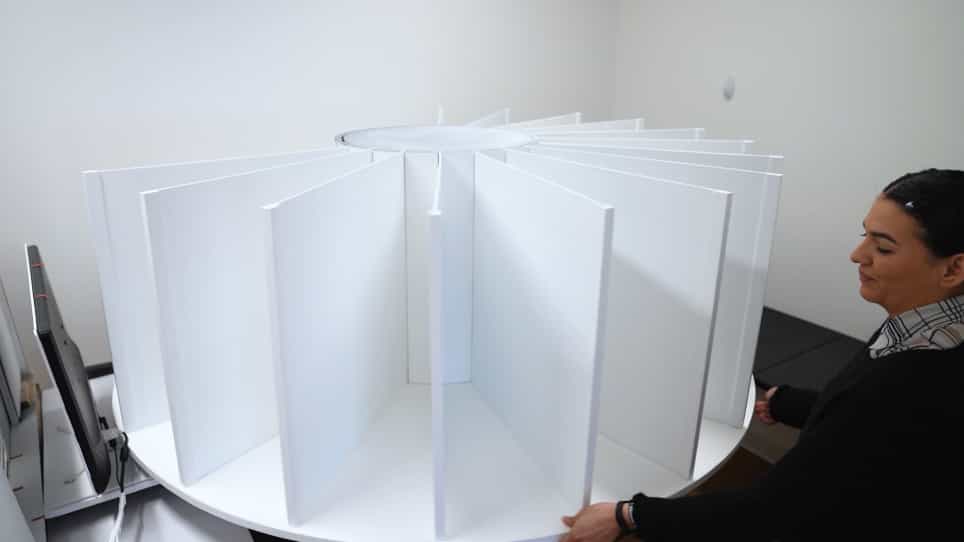
Methods for Presenting Real-world Objects Under Controlled Laboratory Conditions
Published on: June 21, 2019

Abstract:
We propose an algorithm for real-time 6DOF pose tracking of rigid 3D objects using a monocular RGB camera. The key idea is to derive a region-based cost function using temporally consistent local color histograms. While such region-based cost functions are commonly optimized using first-order gradient descent techniques, we systematically derive a Gauss-Newton optimization scheme which gives rise to drastically faster convergence and highly accurate and robust tracking performance. We furthermore propose a novel complex dataset dedicated for the task of monocular object pose tracking and make it publicly available to the community. To our knowledge, it is the first to address the common and important scenario in which both the camera as well as the objects are moving simultaneously in cluttered scenes. In numerous experiments-including our own proposed dataset-we demonstrate that the proposed Gauss-Newton approach outperforms existing approaches, in particular in the presence of cluttered backgrounds, heterogeneous objects and partial occlusions.

Related Concept Videos
 01:07
Gauss's Law
 02:57
Real Time RT-PCR
The real-time quantification of the number of amplified products is...
 01:10
Gauss's Law: Problem-Solving
 01:17
Gauss's Law in Dielectrics
 01:20
Newton's Law of Motion
The first law of motion, also known as the law of inertia, states that an object at rest will stay at rest, and an object in motion will continue to move at a constant speed and direction unless acted upon by an external...
 00:55
Newton's Second Law