Related Experiment Video
Updated: Jan 31, 2026
Dynamic Navigation in Endodontics: Guided Access Cavity Preparation by Means of a Miniaturized Navigation System
Published on: May 5, 2022
Implementation and Analysis of Tightly Coupled Global Navigation Satellite System Precise Point Positioning/Inertial
1College of Automation, Harbin Engineering University, Harbin 150001, China. liuyuehrb@outlook.com.

Abstract:
This paper implements and analyzes a tightly coupled single-frequency global navigation satellite system precise point positioning/inertial navigation system (GNSS PPP/INS) with insufficient satellites for land vehicle navigation using a low-cost GNSS receiver and a microelectromechanical system (MEMS)-based inertial measurement unit (IMU). For land vehicle navigation, it is inevitable to encounter the situation where insufficient satellites can be observed. Therefore, it is necessary to analyze the performance of tightly coupled integration in a GNSS-challenging environment. In addition, it is also of importance to investigate the least number of satellites adopted to improve the performance, compared with no satellites used. In this paper, tightly coupled integration using low-cost sensors with insufficient satellites was conducted, which provided a clear view of the improvement of the solution with insufficient satellites compared to no GNSS measurements at all. Specifically, in this paper single-frequency PPP was implemented to achieve the best performance, with one single-frequency receiver. The INS mechanization was conducted in a local-level frame (LLF). An extended Kalman filter was applied to fuse the two different types of measurements. To be more specific, in PPP processing, the atmosphere errors are corrected using a Saastamoinen model and the Center for Orbit Determination in Europe (CODE) global ionosphere map (GIM) product. The residuals of atmosphere errors are not estimated to accelerate the ambiguity convergence. For INS error mitigation, velocity constraints for land vehicle navigation are adopted to limit the quick drift of a MEMS-based IMU. Field tests with simulated partial and full GNSS outages were conducted to show the performance of tightly coupled GNSS PPP/INS with insufficient satellites: The results were classified as long-term (several minutes) and short-term (less than 1 min). The results showed that generally, with GNSS measurements applied, although the number of satellites was not enough, the solution still could be improved, especially with more than three satellites observed. With three GPS satellites used, the horizontal drift could be reduced to a few meters after several minutes. The 3D position error could be limited within 10 m in one minute when three GPS satellites were applied. In addition, a field test in an urban area where insufficient satellites were observed from time to time was also conducted to show the limited solution drift.
Related Concept Videos
 01:11
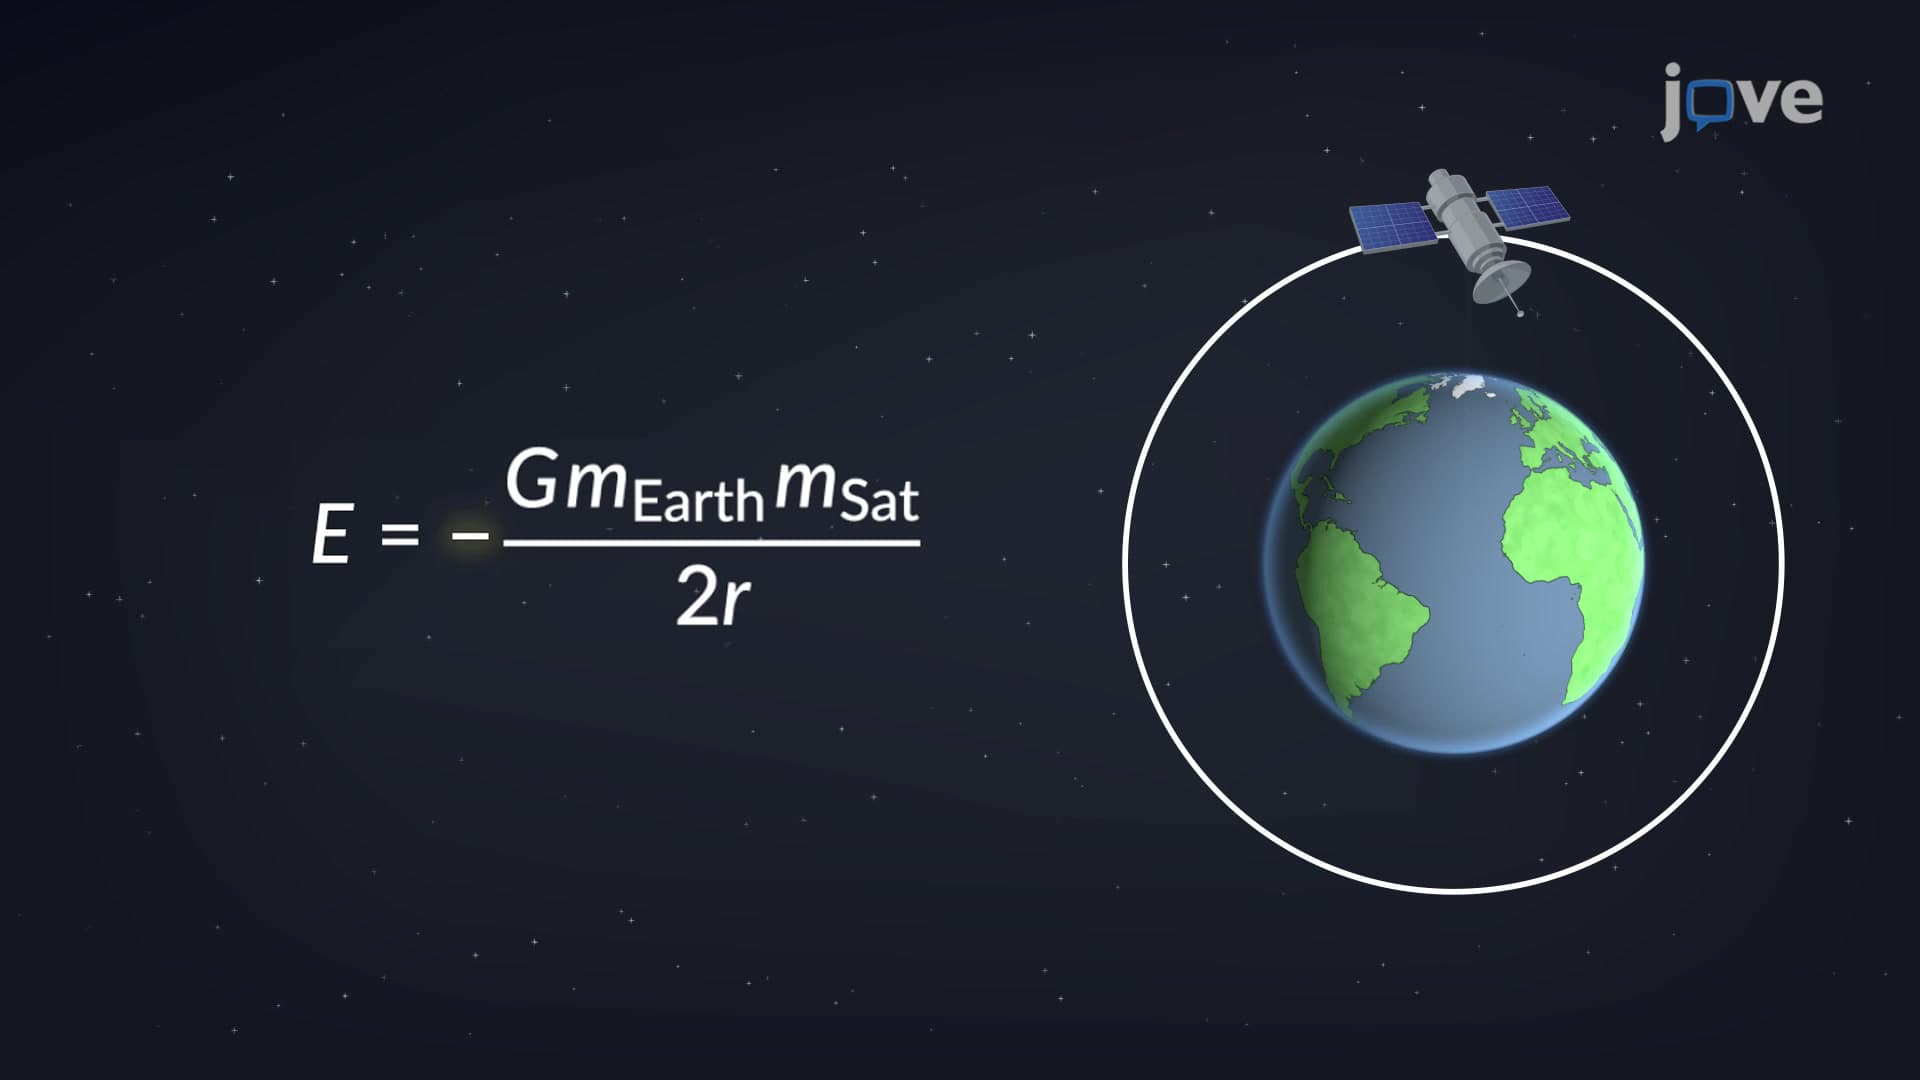
Energy of a Satellite in a Circular Orbit
 01:16
Circular Orbits and Critical Velocity for Satellites
Nicolaus Copernicus (1473-1543) first suggested that the Earth and all other planets orbit the Sun in...
 01:21
Satellite Stem Cells and Muscular Dystrophy
 01:30
Introduction to Global Positioning System
 02:22
The Colonization of Land
 01:26
Errors in Global Positioning System