Related Experiment Video
Updated: Jan 31, 2026

A Microfluidic Device with Groove Patterns for Studying Cellular Behavior
Published on: August 30, 2007
TKA design-integrated trochlea groove rotation reduces patellofemoral pressure
Matthias Woiczinski1, Manuel Kistler2, Christian Schröder2
1Department of Orthopaedics, Physical Medicine and Rehabilitation, University Hospital, LMU Munich, Munich, Germany. Matthias.Woiczinski@med.uni-muenchen.de.

Purpose:
Total knee arthroplasty (TKA) leaves 11-25% of the patients unsatisfied, and patellofemoral joint pain is one cause. This study aimed to compare the differences between kinematics and load transfer in the same knee with axial internal/external rotation of the femoral component (CoRo) versus a separate axial internal/external trochlear groove rotation (TrRo) which is included in the TKA trochlea design.
Methods:
A validated weight-bearing finite element model with modifications of the TKA axial femoral component rotation (CoRo) and a modified trochlear rotation (TrRo) was calculated and analysed.
Results:
Compared to the neutrally implanted TKA at 105° of flexion, a 6° external rotation of the trochlear groove reduced the retropatellar stress by 7%, whereas a 3° internal trochlear groove rotation increased the retropatellar stress by 7%. With femoral component rotation, the tibia inlay stress of 6.7 MPa at 60° of flexion was two times higher both with a 3° internal component rotation and a 6° external rotation.
Conclusion:
These results demonstrate in the tested TKA design that a trochlear groove rotation can reduce retropatellar stress. Additionally, during the TKA operation, the surgeon should be aware of the significant influence of axial femoral component rotation on mechanical inlay stress during flexion and of the fact that even small changes in the patellofemoral joint may influence the tibiofemoral joint. These results support that an external rotation of the femoral component should be preferred in TKA to avoid anterior knee pain. Furthermore, new developed TKA designs should integrate an externally rotated trochlea groove.
More Related Videos

Related Concept Videos
 01:30
Applications of Integration to Find Hydrostatic Pressure
 02:01
Group Design
 01:18
Reducing Line Loss
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss in...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
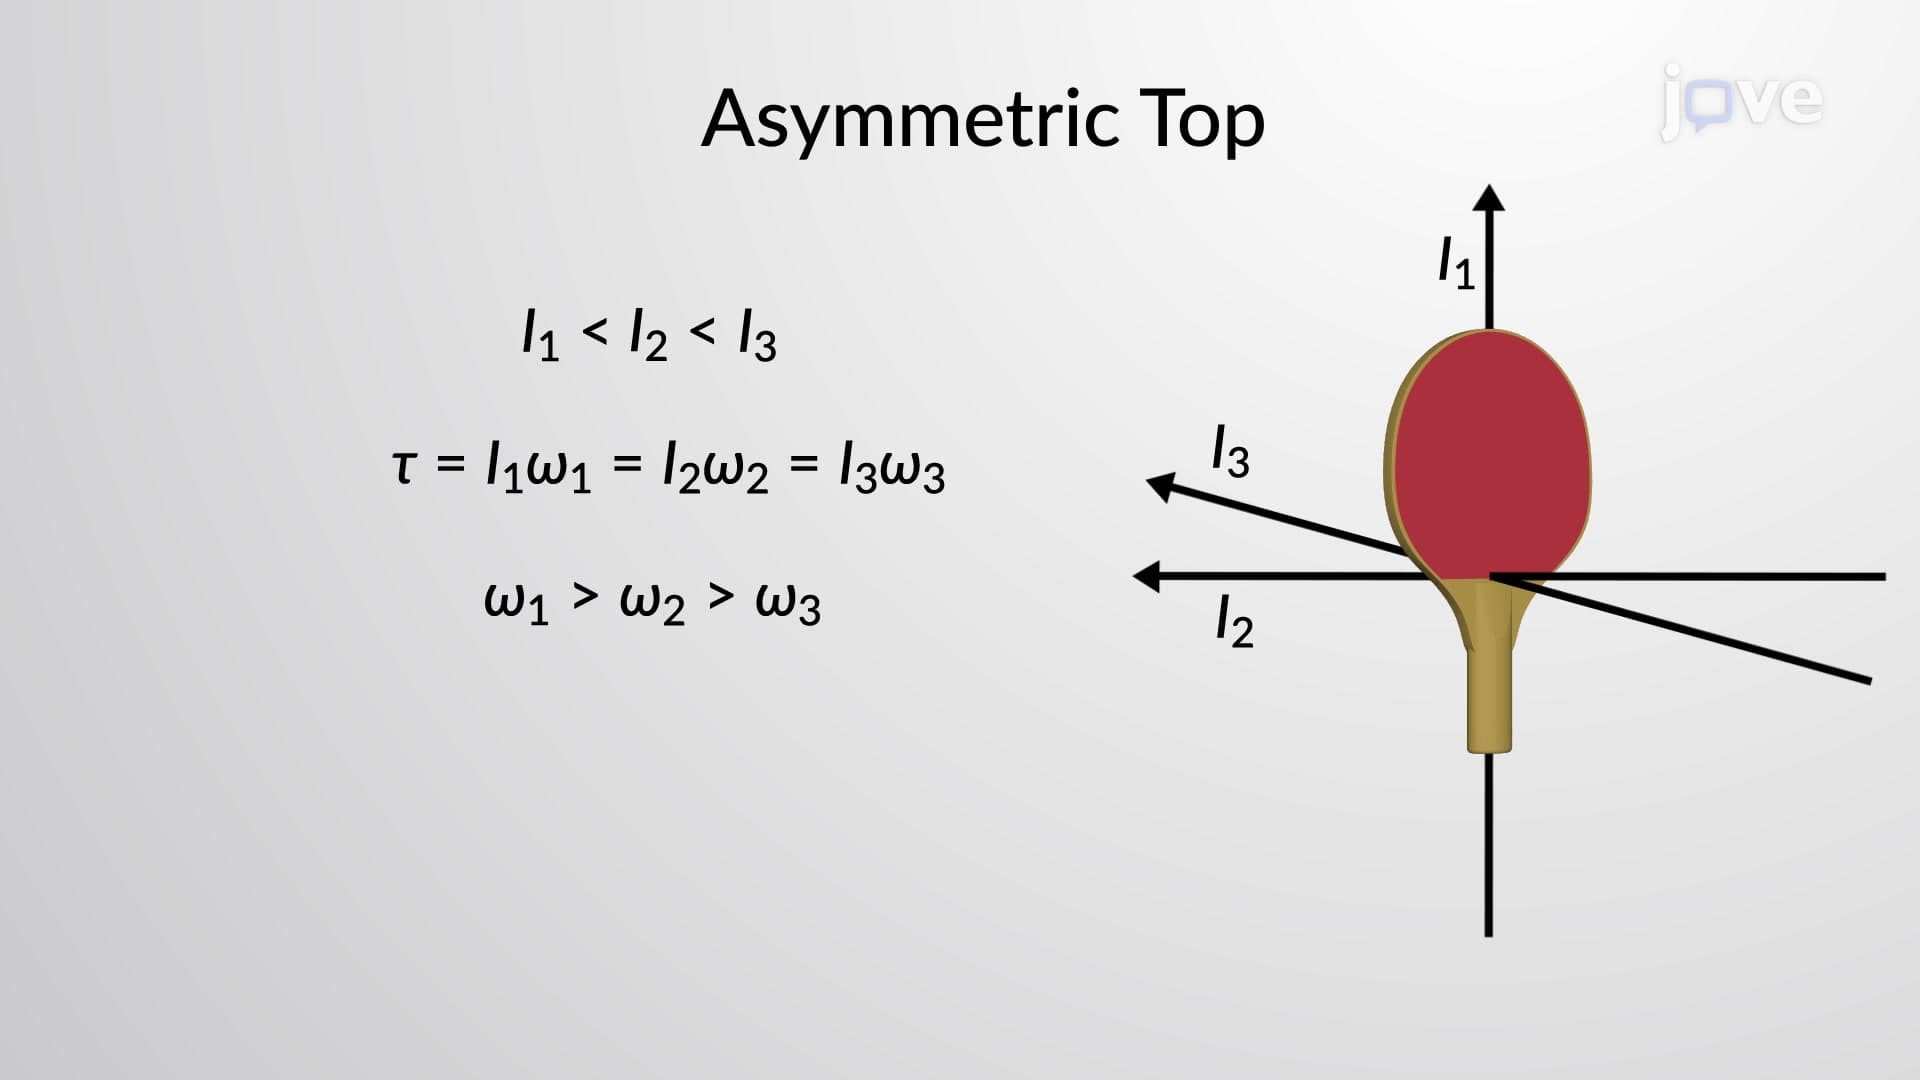
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:26
Integration by Parts: Indefinite Integrals