Finite-time extended dissipative control for fuzzy systems with nonlinear perturbations via sampled-data and quantized controller
Related Experiment Video
Updated: Jan 31, 2026
Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
1School of Science, Yanshan University, Qinhuangdao, Hebei, 066004, PR China.

Abstract:
This paper investigates the problem of finite-time extended dissipative control for T-S fuzzy time-varying delay systems with nonlinear perturbations via sampled-data and quantized controller. The definition of finite-time bounded mixed extended dissipative of fuzzy systems is first proposed. Based on the constructed Lyapunov-Krasovskii functional(LKF) and Peng-Parks integral inequality, some sufficient conditions are obtained in the form of linear matrix inequalities(LMIs), which are less conservative than other papers. By combining the input delay approach and dynamic quantizer, the sampled-data and quantized controller is designed to guarantee that the T-S fuzzy system is finite-time bounded mixed extended dissipative. Finally, some numerical examples and practical examples are presented to verify the feasibility and effectiveness of the proposed methods.

Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
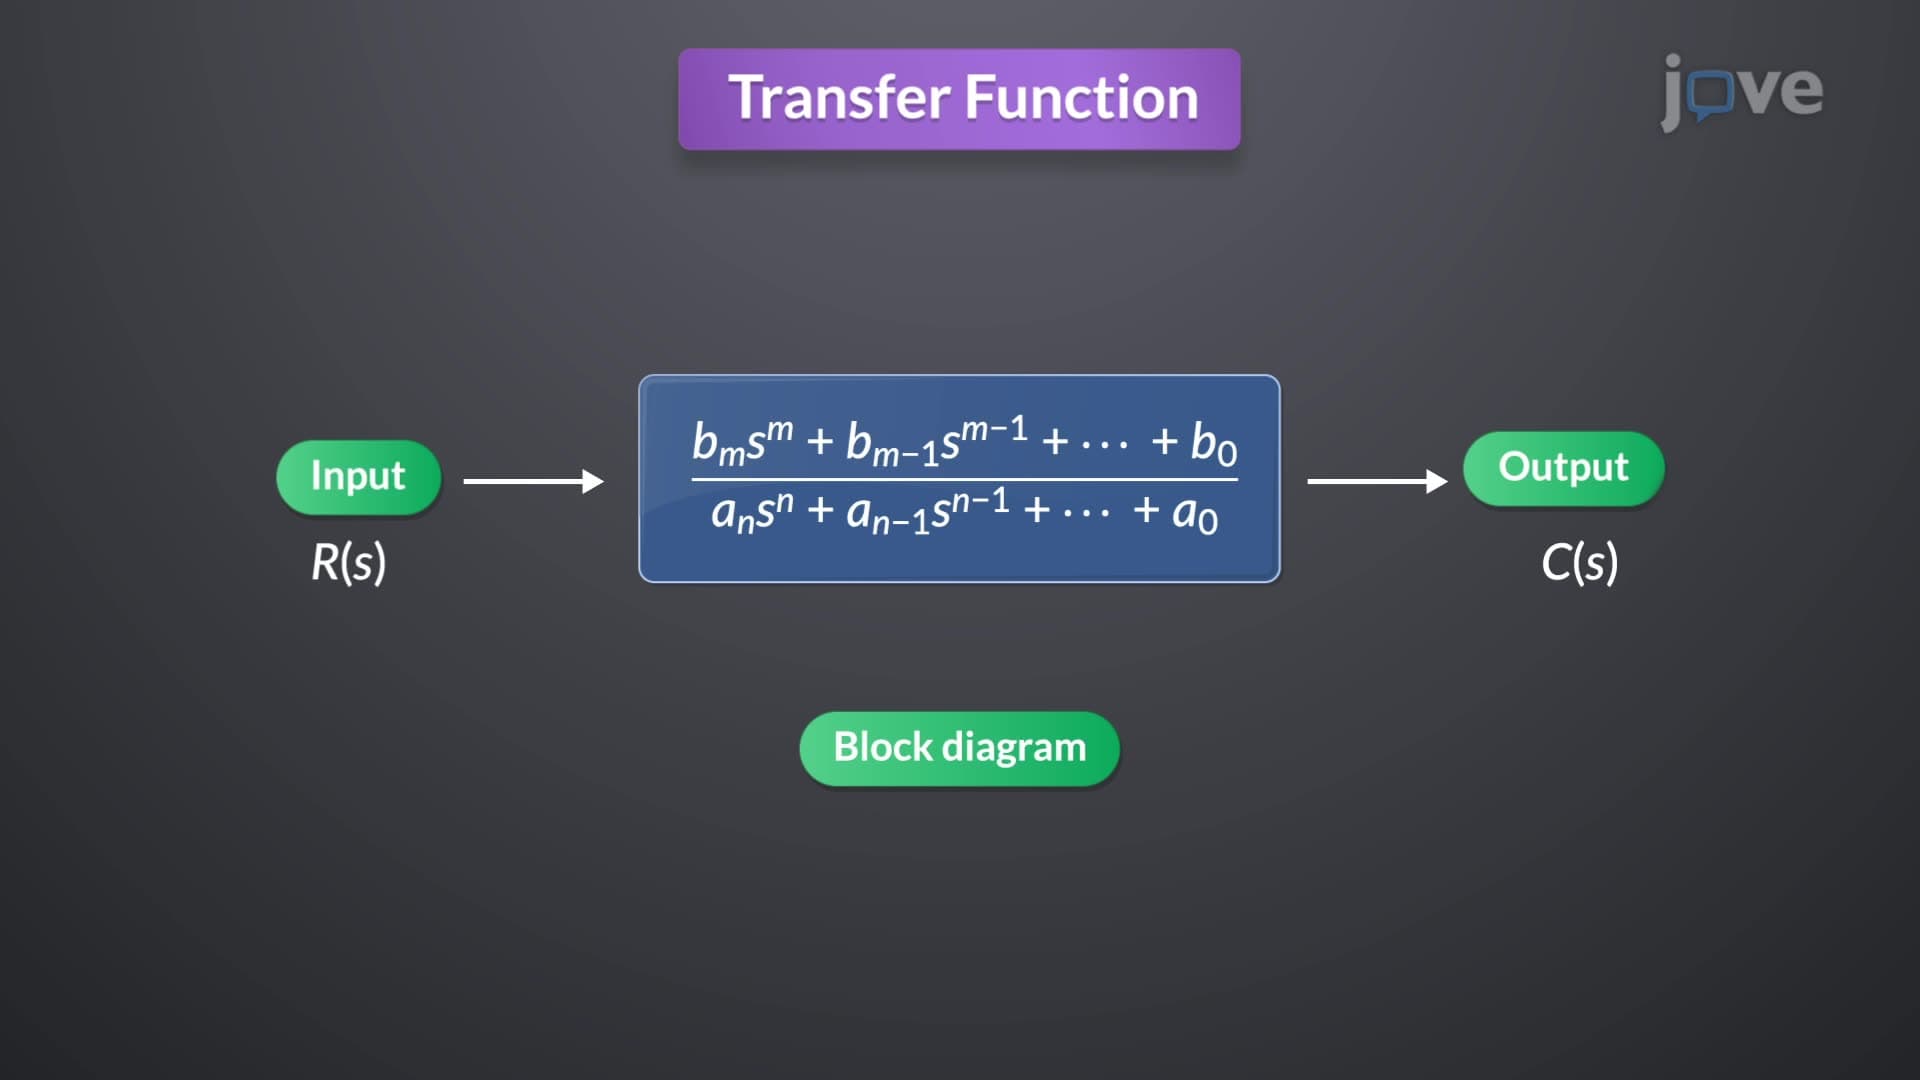
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...