Related Experiment Video
Updated: Aug 6, 2026
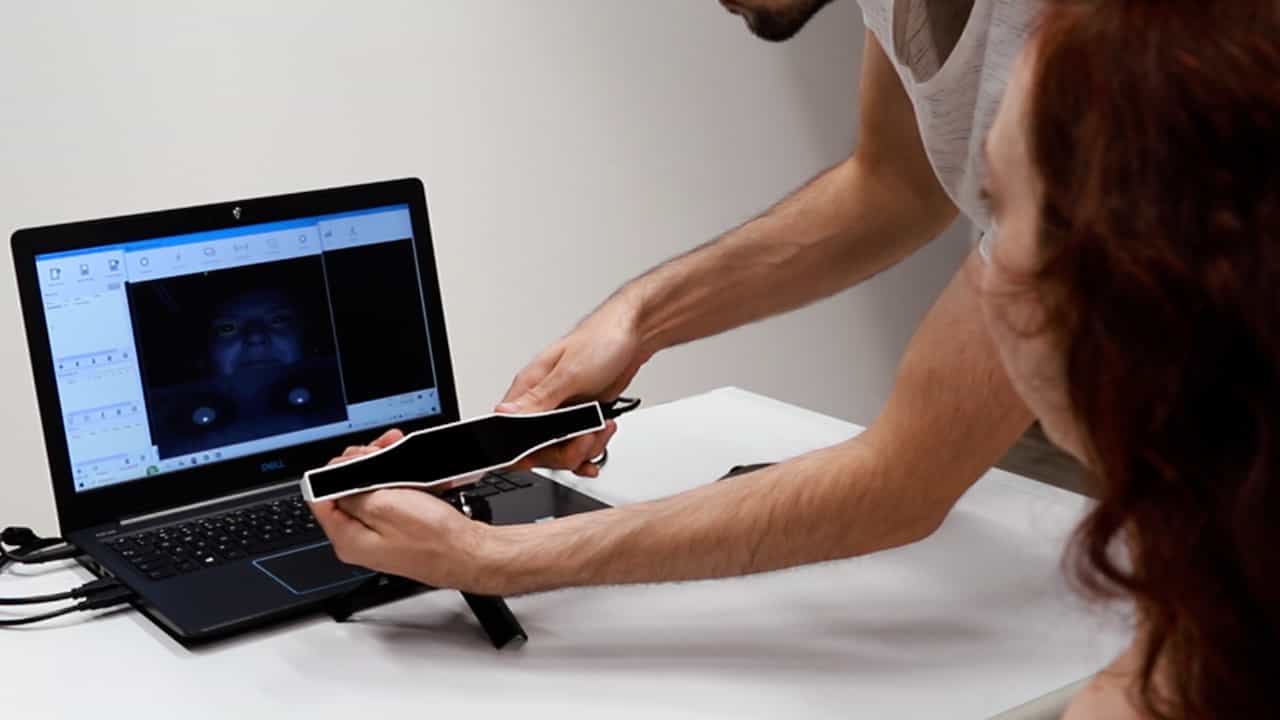

Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024
Quasi-projective synchronization of fractional-order quaternion-valued inertial neural networks with application to
Yanxia Hu1, Xiaofang Meng1, Zhouhong Li2
1School of Statistics and Mathematics, Yunnan University of Finance and Economics, Kunming, Yunnan 650221, China.

Abstract:
Fractional-order quaternion inertial neural networks have shown great potential for secure communications, as evidenced by the capability of efficiently capturing the dynamic characteristics of high-dimensional data. This article focuses on studying the quasi-projective synchronization problem of a class of delayed fractional-order quaternion-valued inertial neural networks. Firstly, a simple and efficient controller is designed without decomposing the quaternion-valued neural networks into multiple subsystems. Moreover, unlike previous studies, the non-reduced order method is adopted to analyze inertial neural networks directly. Secondly, a class of Lyapunov functions for quaternion states and their fractional-order derivatives is constructed, along with several inequalities. On this basis, a sufficient criterion for achieving quasi-projective synchronization of the constructed model, and an upper bound on the system synchronization error are estimated. A more complex form of controller is also proposed, and the synchronization of the studied system is achieved using the same proof method as before. Finally, the validity of the theoretical results is verified through a numerical example. This research has been successfully applied to the encryption and decryption of color images, demonstrating strong practical application prospects.
Related Concept Videos
 01:20
Inverse z-Transform by Partial Fraction Expansion
To begin the process, the poles of the function are identified and the function is...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:28
Partial Fractions
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:26
Linearization and Approximation