Localization and Completion for 3D Object Interactions
Related Experiment Video
Updated: Jan 30, 2026
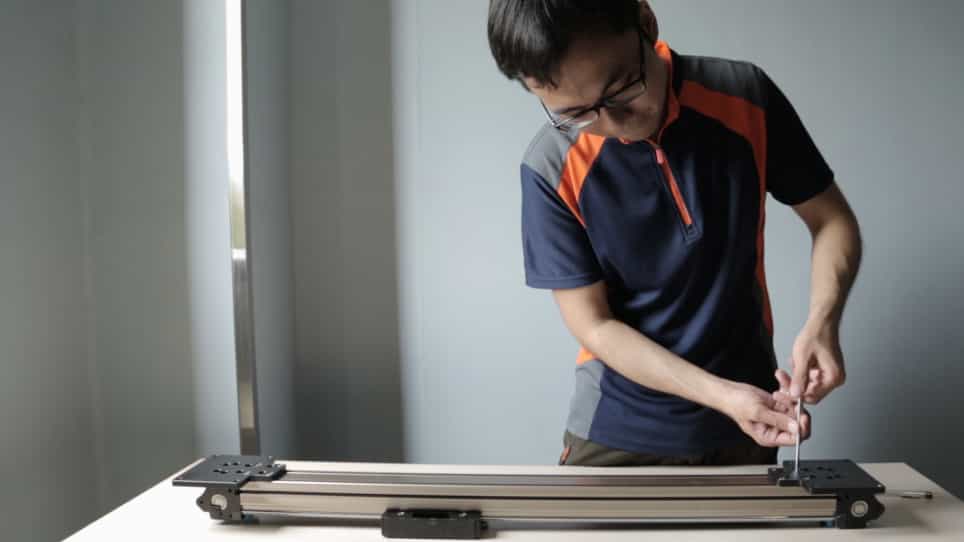
Design and Use of an Apparatus for Presenting Graspable Objects in 3D Workspace
Published on: August 8, 2019

Abstract:
Finding where and what objects to put into an existing scene is a common task for scene synthesis and robot/character motion planning. Existing frameworks require development of hand-crafted features suitable for the task, or full volumetric analysis that could be memory intensive and imprecise. In this paper, we propose a data-driven framework to discover a suitable location and then place the appropriate objects in a scene. Our approach is inspired by computer vision techniques for localizing objects in images: using an all directional depth image (ADD-image) that encodes the 360-degree field of view from samples in the scene, our system regresses the images to the positions where the new object can be located. Given several candidate areas around the host object in the scene, our system predicts the partner object whose geometry fits well to the host object. Our approach is highly parallel and memory efficient, and is especially suitable for handling interactions between large and small objects. We show examples where the system can hang bags on hooks, fit chairs in front of desks, put objects into shelves, insert flowers into vases, and put hangers onto laundry rack.

Related Concept Videos
 01:18
Velocity of an Object
 01:29
Potential Due to a Polarized Object
 01:24
Potential Due to a Magnetized Object
The vector...
 01:07
Moment of Inertia of Compound Objects
Consider a child of mass (mc) 25 kg standing at a distance (rc) of 1 m from the axis of a rotating...
 01:07
Gravitational Potential Energy for Extended Objects
 01:22
Local Attraction