Related Experiment Video
Updated: Jan 29, 2026

Training Rats to Voluntarily Dive Underwater: Investigations of the Mammalian Diving Response
Published on: November 12, 2014
Maximising forward somersault rotation in springboard diving
Mark A King1, Pui W Kong2, Maurice R Yeadon1
1School of Sport, Exercise and Health Sciences, Loughborough University, UK.

Abstract:
Performance in the flight phase of springboard diving is limited by the amounts of linear and angular momentum generated during the takeoff phase. A planar 8-segment torque-driven simulation model combined with a springboard model was used to investigate optimum takeoff technique for maximising rotation in forward dives from the one metre springboard. Optimisations were run by varying the torque activation parameters to maximise forward rotation potential (angular momentum × flight time) while allowing for movement constraints, anatomical constraints, and execution variability. With a constraint to ensure realistic board clearance and anatomical constraints to prevent joint hyperextension, the optimised simulation produced 24% more rotation potential than a simulation matching a 2½ somersault piked dive. When 2 ms perturbations to the torque onset timings were included for the ankle, knee and hip torques within the optimisation process, the model was only able to produce 87% of the rotation potential achieved in the matching simulation. This implies that a pre-planned technique cannot produce a sufficiently good takeoff and that adjustments must be made during takeoff. When the initial onset timings of the torque generators were unperturbed and 10 ms perturbations were introduced into the torque onset timings in the board recoil phase, the optimisation produced 8% more rotation potential than the matching simulation. The optimised simulation had more hip flexion and less shoulder extension at takeoff than the matching simulation. This study illustrates the difficulty of including movement variability within performance optimisation when the movement duration is sufficiently long to allow feedback corrections.
More Related Videos
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
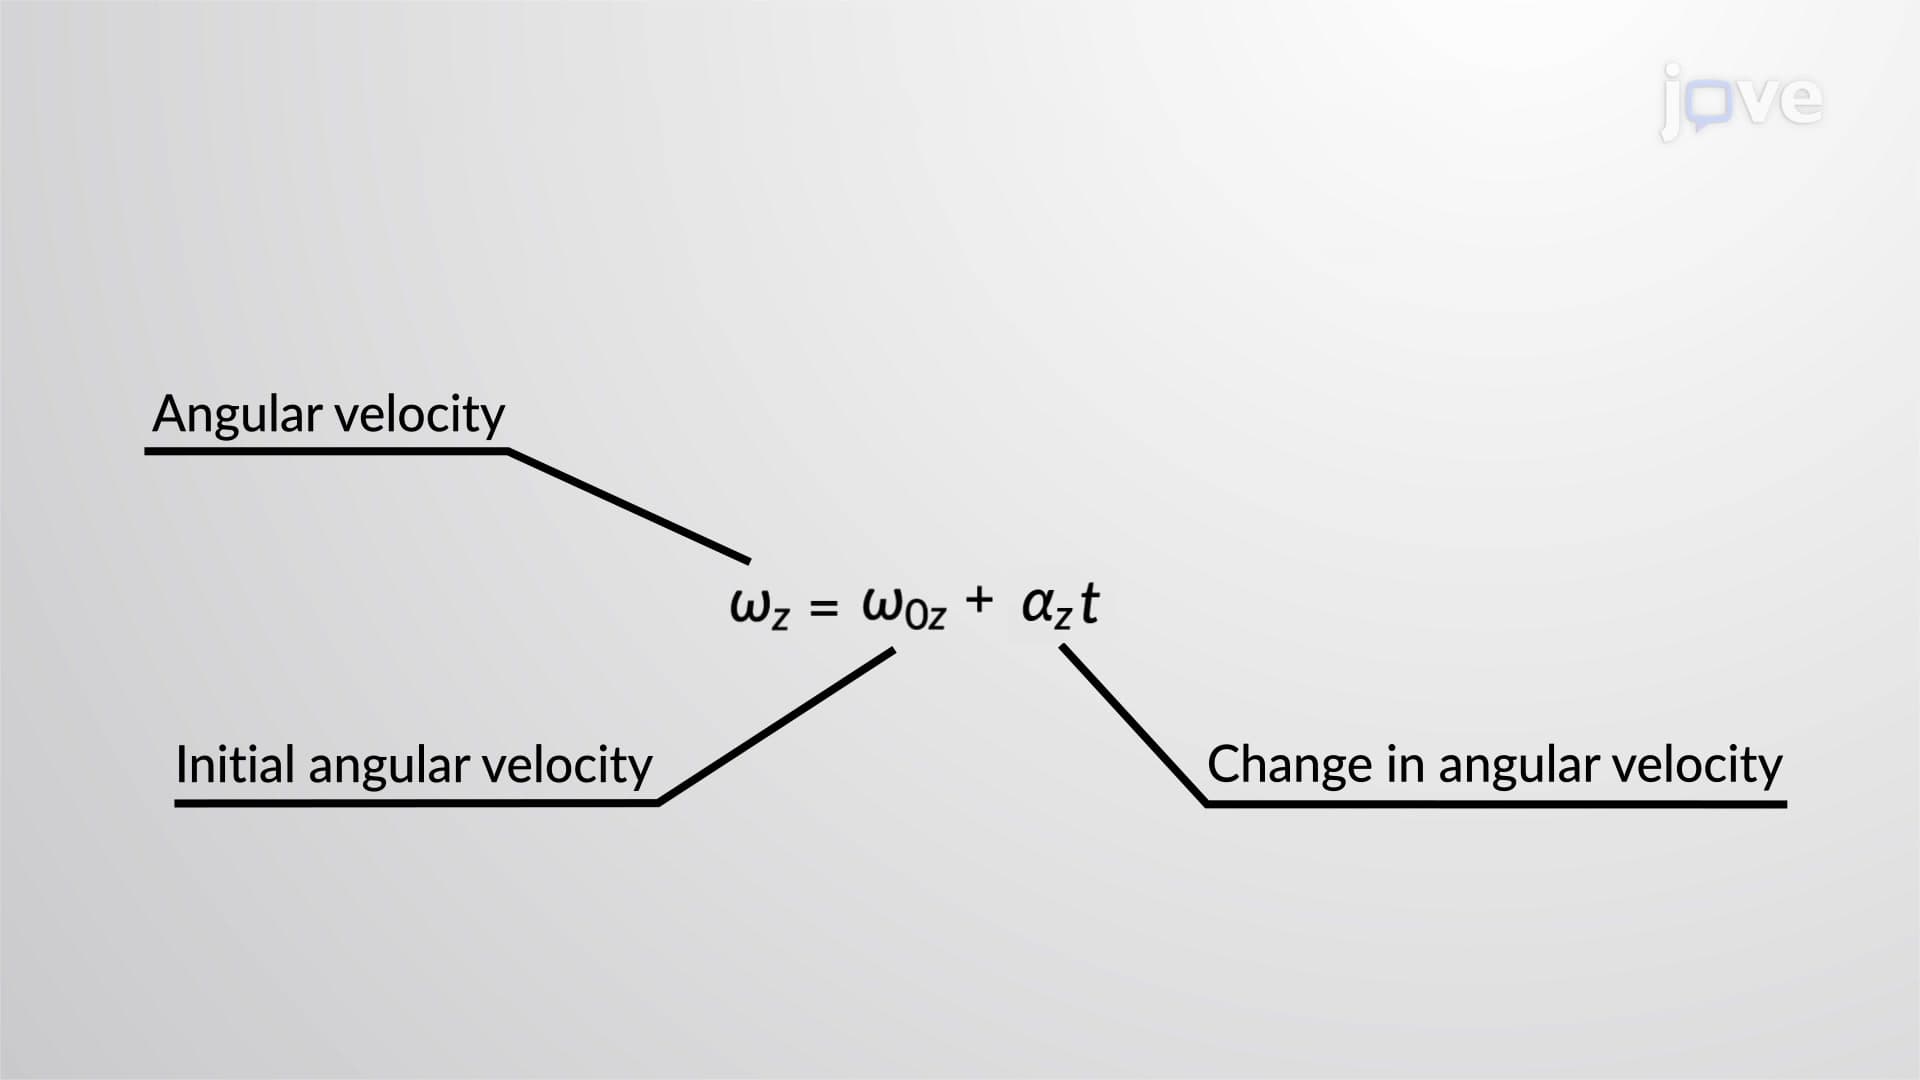 01:37
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
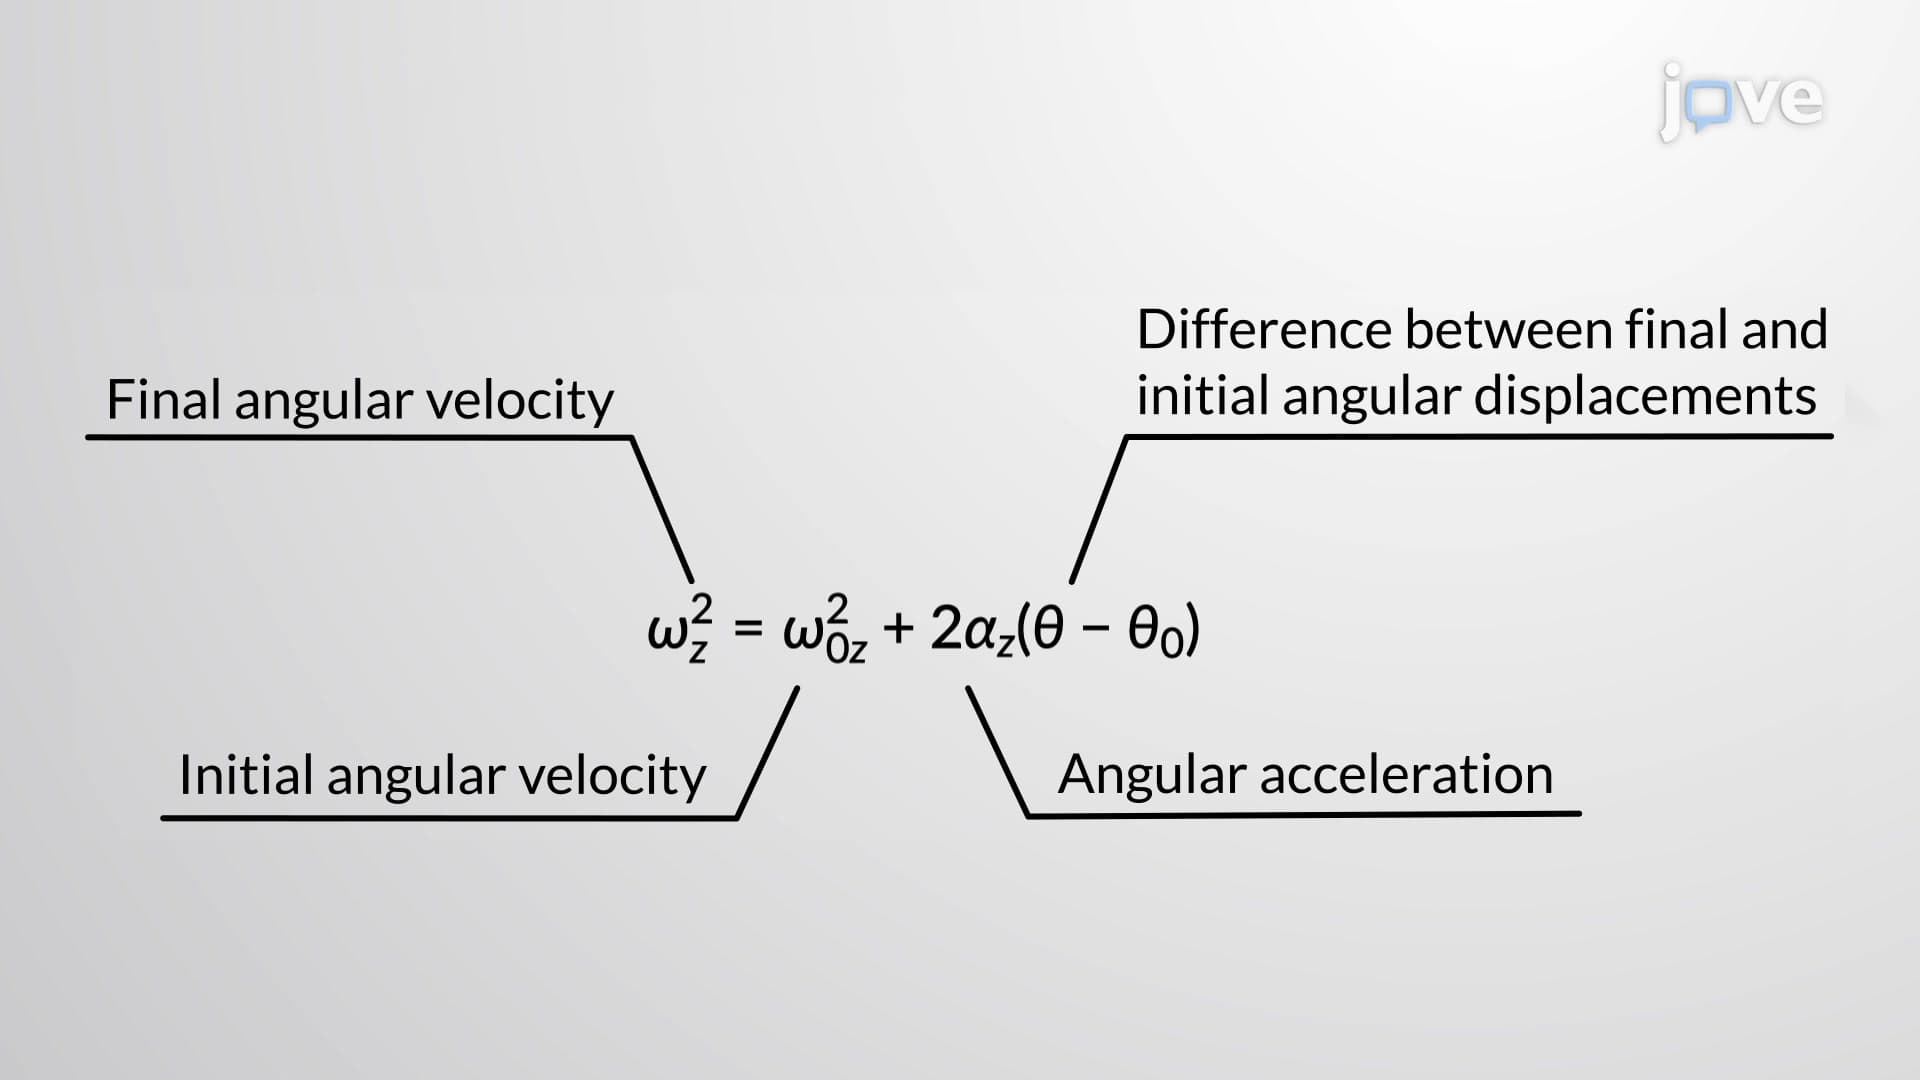 01:16
Rotation with Constant Angular Acceleration - II
The first...
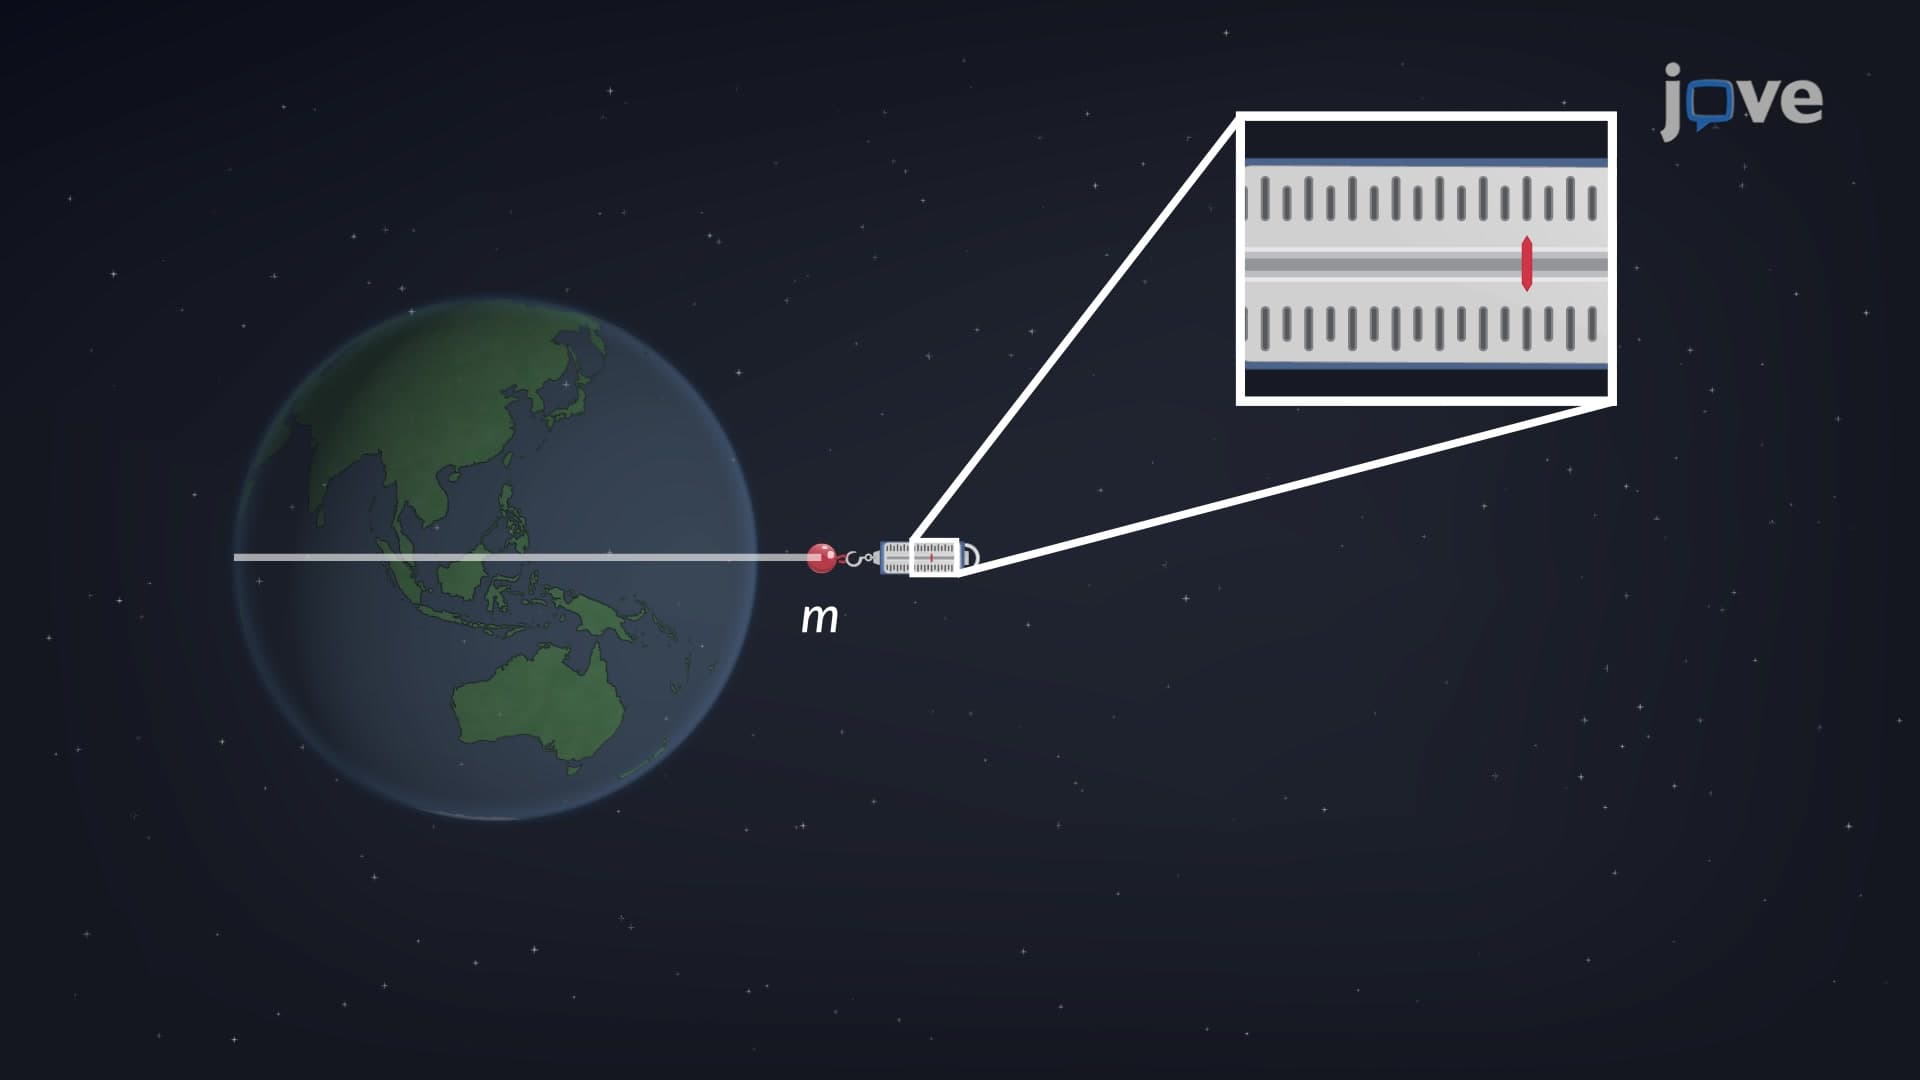 01:28
Apparent Weight and the Earth's Rotation
For an object on the Earth's equator, the net centripetal force that accounts for its rotation is the Earth's pull towards its center, or the weight minus the normal force that prevents it from piercing into the Earth's surface....
 01:26
Rotational Motion about a Fixed Axis