Related Experiment Video
Updated: Jan 28, 2026


Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
A Hybrid Path-Planning Strategy for Mobile Robots with Limited Sensor Capabilities
Guilherme Carlos R de Oliveira1, Kevin B de Carvalho2, Alexandre S Brandão3
1Núcleo de Especialização em Robótica-NERO, Departamento de Engenharia Elétrica-DEL, Universidade Federal de Viçosa-UFV, Viçosa MG 36570-900, Brazil. guilherme@ufv.br.

Abstract:
This paper introduces a strategy for the path planning problem for platforms with limited sensor and processing capabilities. The proposed algorithm does not require any prior information but assumes that a mapping algorithm is used. If enough information is available, a global path planner finds sub-optimal collision-free paths within the known map. For the real time obstacle avoidance task, a simple and cost-efficient local planner is used, making the algorithm a hybrid global and local planning solution. The strategy was tested in a real, cluttered environment experiment using the Pioneer P3-DX and the Xbox 360 kinect sensor, to validate and evaluate the algorithm efficiency.
Related Concept Videos
 01:21
Path Between Thermodynamics States
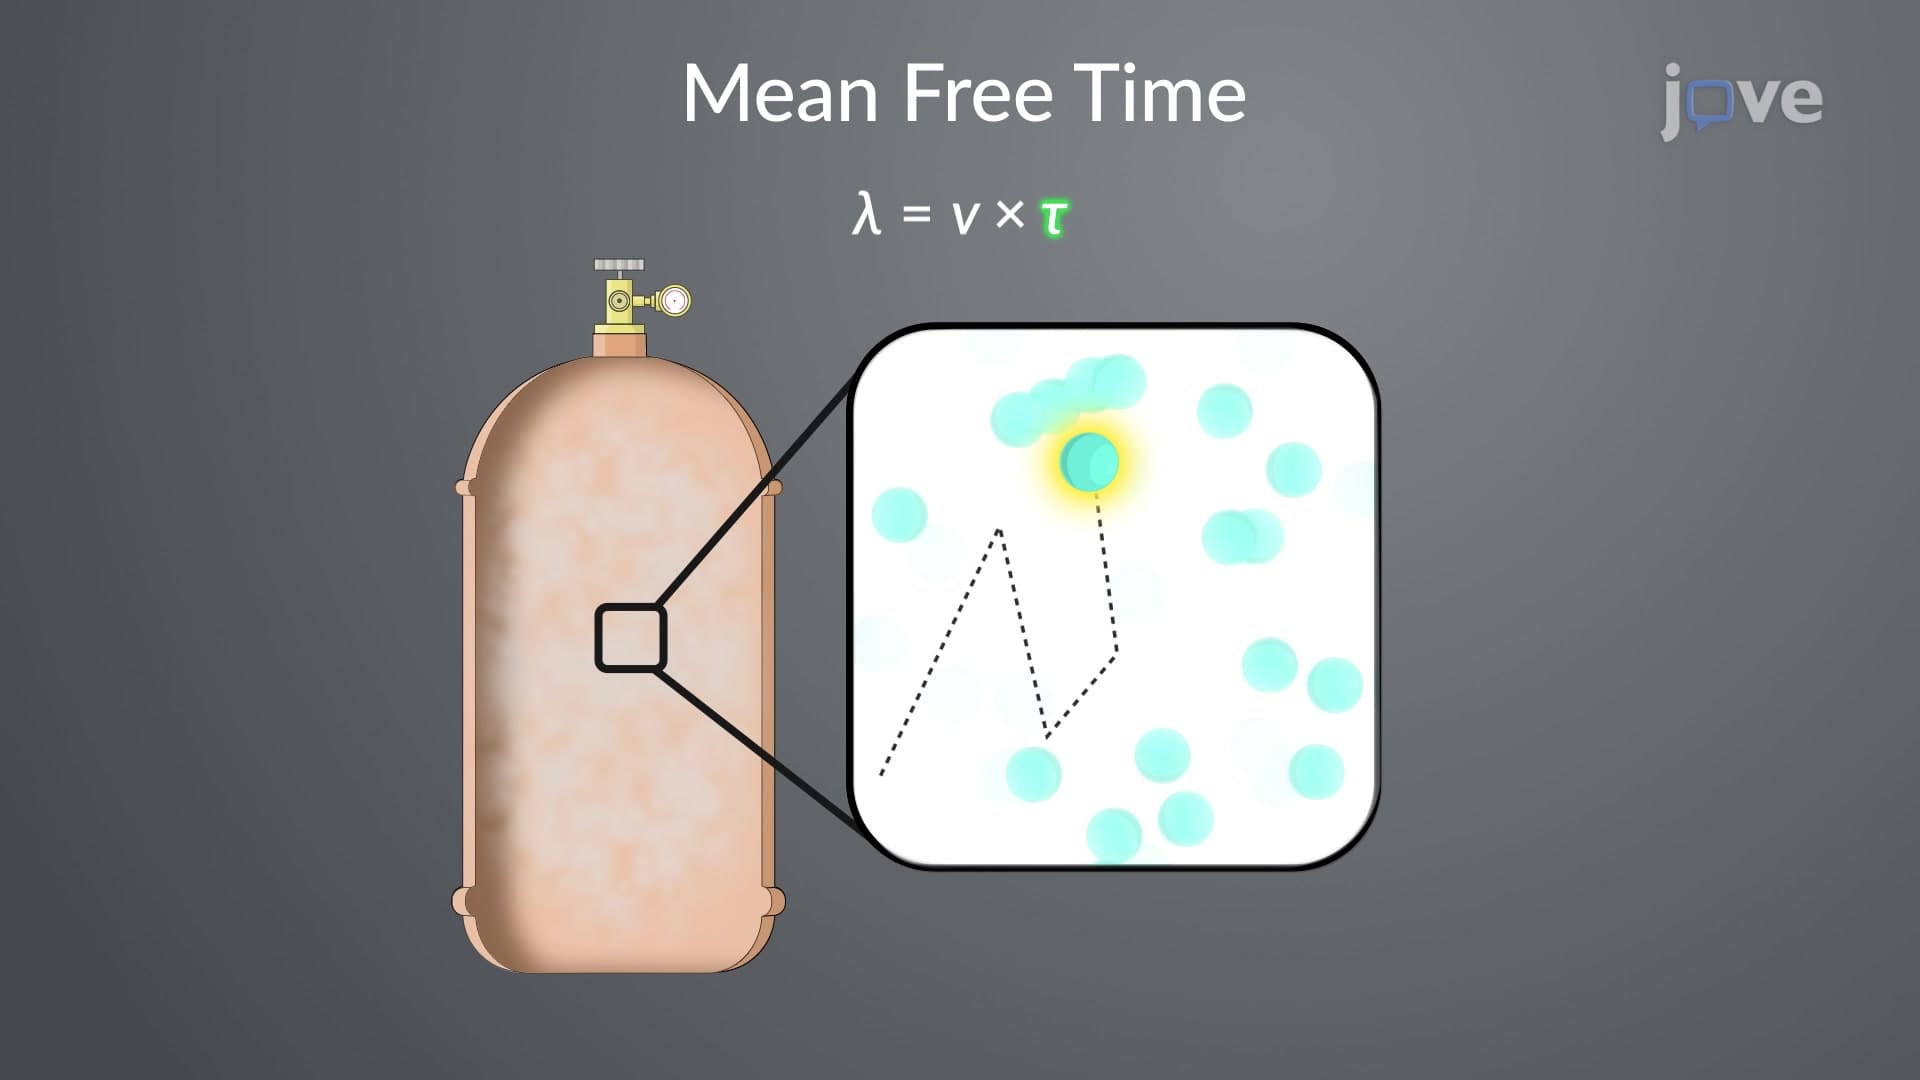 01:22
Mean free path and Mean free time
 01:10
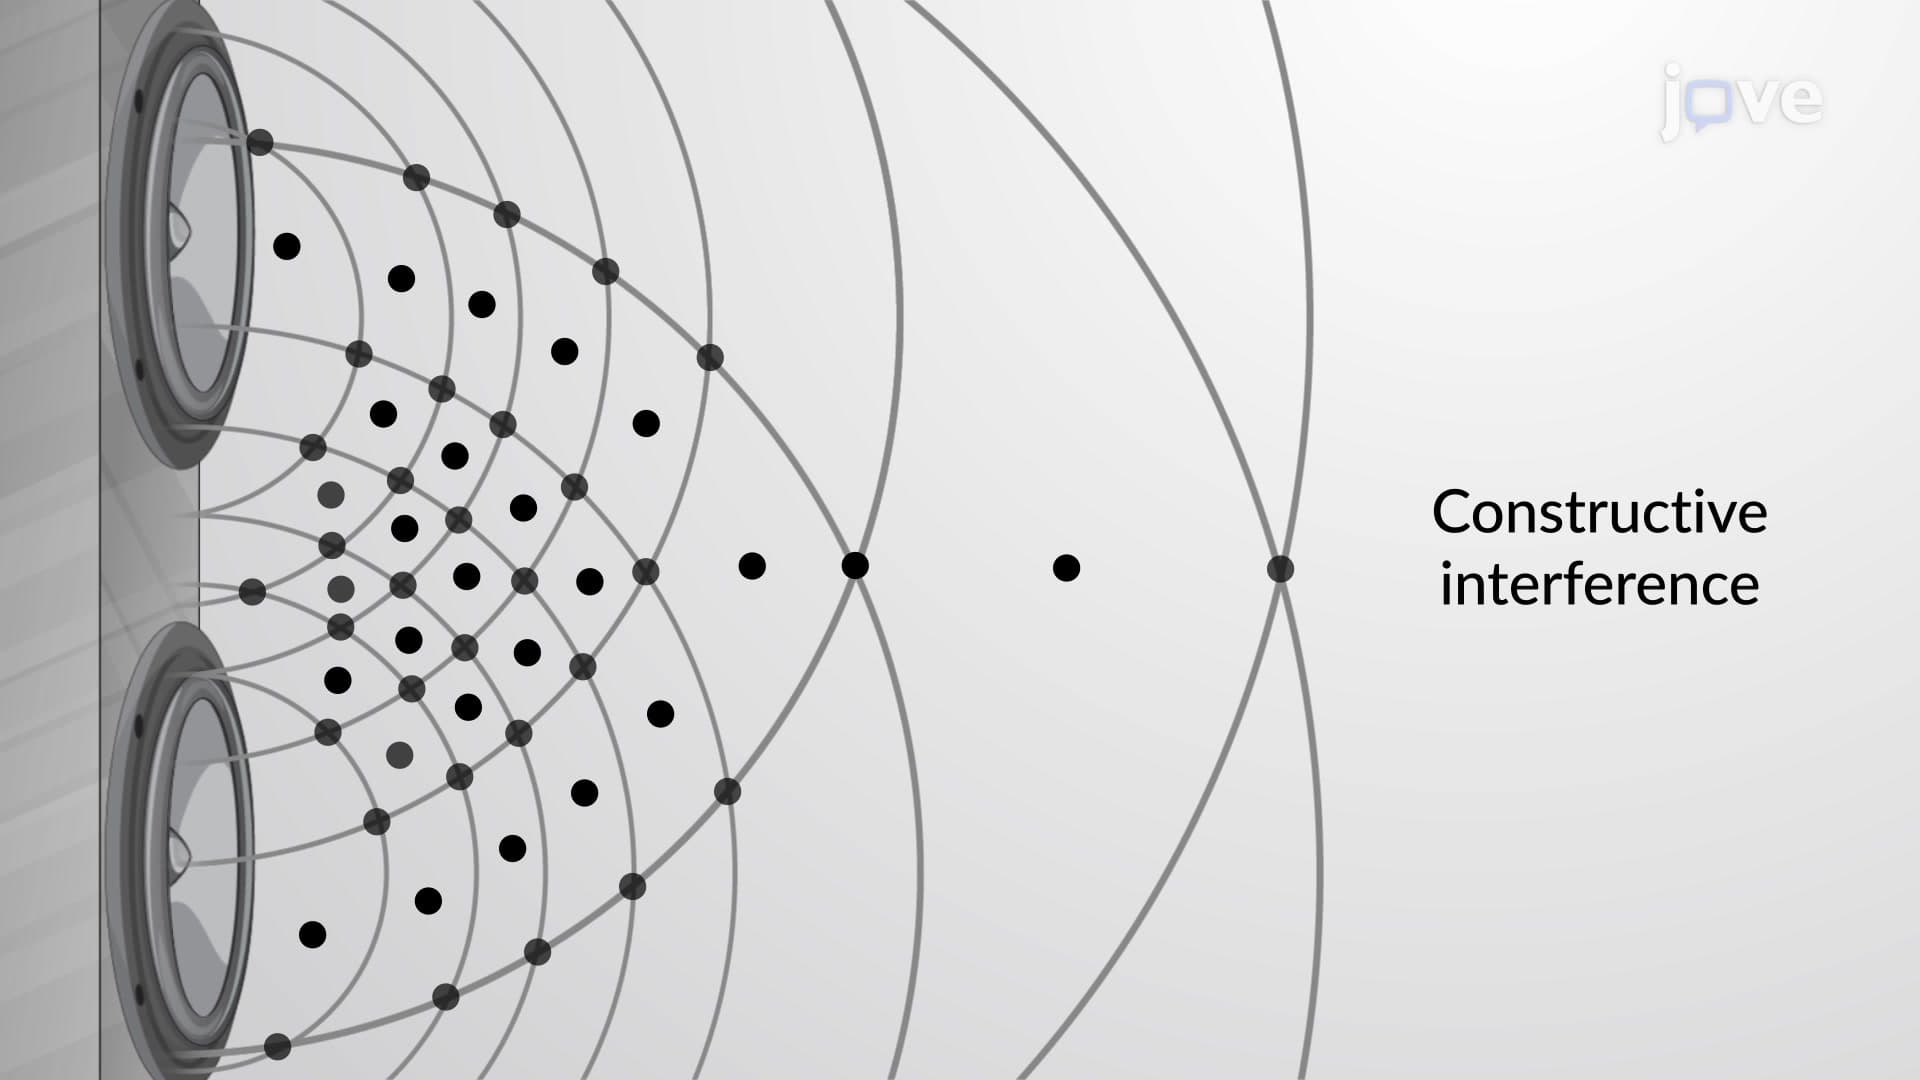
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 02:27
Limiting Reactant
 03:48
Behavior of Gas Molecules: Molecular Diffusion, Mean Free Path, and Effusion
 02:29
Hybrid Zones