Mixed Rigid and Flexible Component Design for High-Performance Polyimide Films
Related Experiment Video
Updated: Jan 26, 2026
Author Spotlight: Unlocking Plant Transformation by Innovating with Carbon Nanofiber Arrays
Published on: July 21, 2023
Xiaohui Yu1, Weihua Liang2, Jianhua Cao3
1Technical Institute of Physics and Chemistry, Chinese Academy of Sciences, Beijing 100190, China. xhyu@mail.ipc.ac.cn.

Abstract:
To develop the polyimide (PI) which is closely matched to the coefficient of the thermal expansion (CTE) of copper, a series of PIs are prepared from 5,4'-diamino-2-phenyl benzimidazole (DAPBI), 4,4'-diaminodiphenyl ether (ODA), and 3,3',4,4'-benzophenonetetracarboxylic dianhydride (BTDA) using a sequential copolymerization, blade coating, and thermal imidization process. The physical properties of the PIs are effectively regulated and optimized by adjusting the ratio of the rigid DAPBI and flexible ODA components. By increasing the DAPBI content, thermal stability, dimensional stability, and mechanical properties, the resultant polymer is enhanced. PI-80 exhibits an excellent comprehensive performance, a glass transition temperature of 370 °C, and a tensile strength of 210 MPa. Furthermore, the CTE as calculated in the range 50⁻250 °C is ca. 19 ppm/K, which is equal to that of copper. A highly dimensionally stable, curl-free, and high T-style peel strength (6.4 N/cm) of copper/PI laminate was obtained by casting the polyamic acid onto copper foil (13 μm) and thermally curing at 360 °C, which indicates that it has the potential to be applied as an electronic film for flexible displays and flexible printed circuit boards. A structural rationalization for these remarkable properties is also presented.
Related Concept Videos
 01:17
Design Example: Vintage Mixing Console
The specifications for the pre-amplifier were clear. It needed to amplify the audio signal by a factor of 10, have an input impedance above 10...
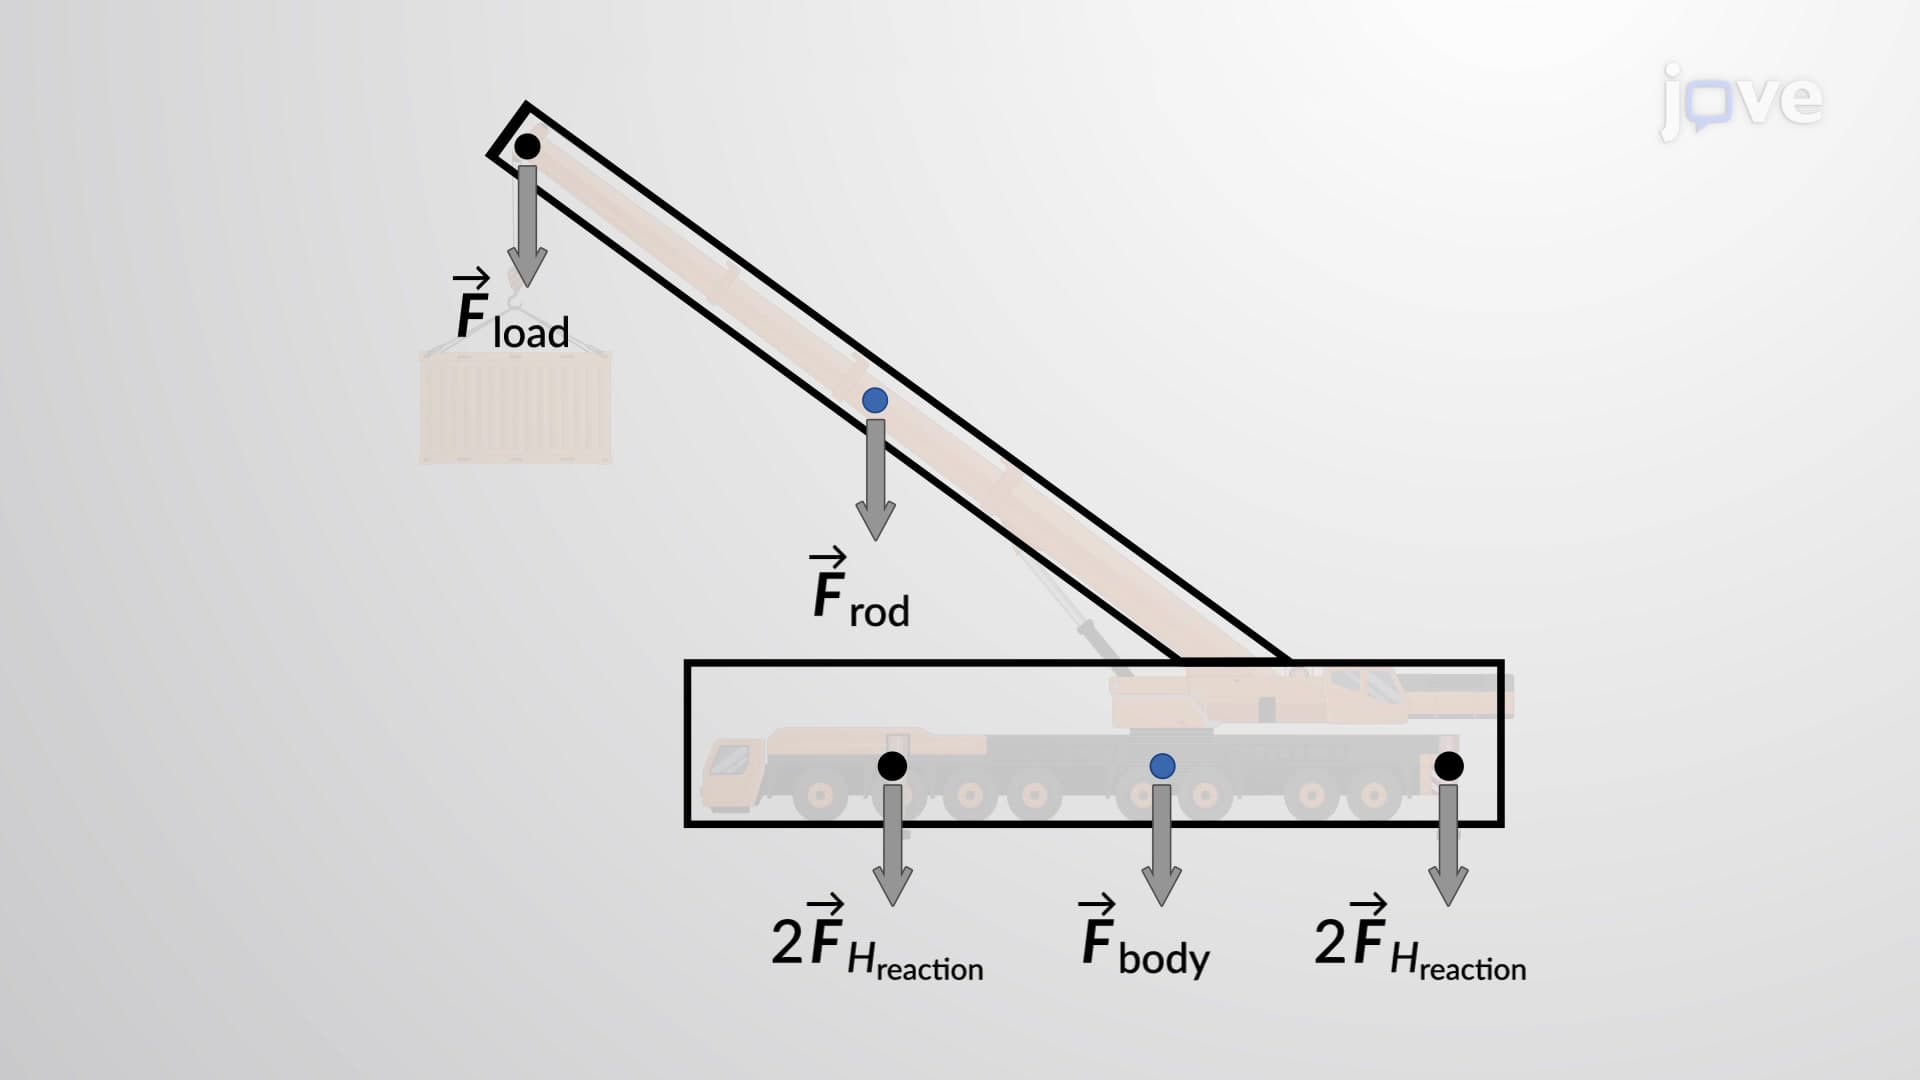 00:49
Rigid Body Equilibrium Problems - I
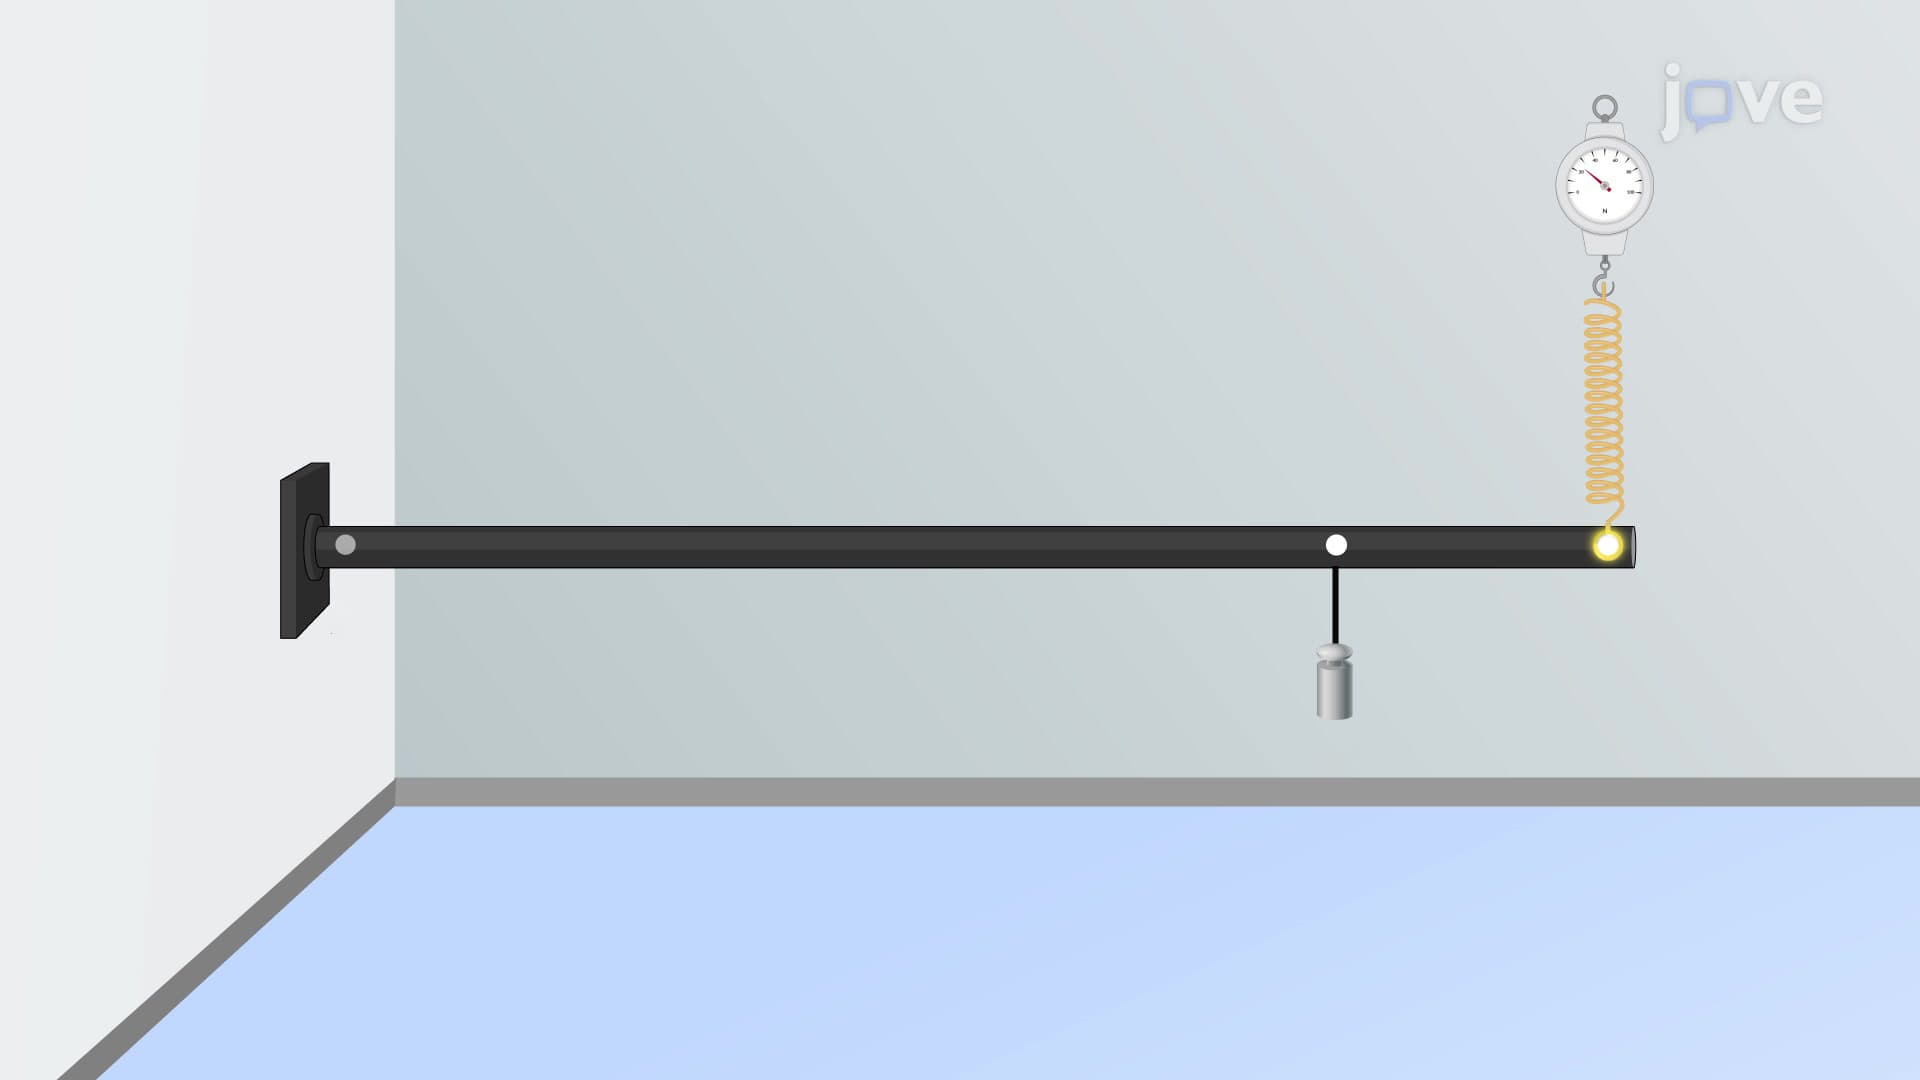 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 02:01
Group Design
 01:13
Kinetic Energy for a Rigid Body
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...