An Optimized Tightly-Coupled VIO Design on the Basis of the Fused Point and Line Features for Patrol Robot Navigation
Related Experiment Video
Updated: Jan 25, 2026
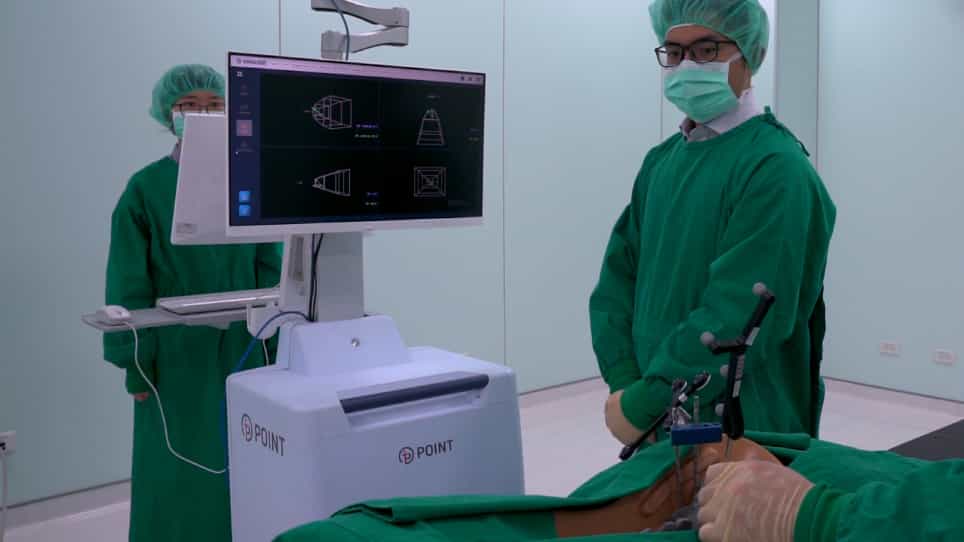
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Linlin Xia1, Qingyu Meng2, Deru Chi3
1School of Automation Engineering, Northeast Electric Power University, Jilin 132012, China. xiall521@neepu.edu.cn.

Abstract:
The development and maturation of simultaneous localization and mapping (SLAM) in robotics opens the door to the application of a visual inertial odometry (VIO) to the robot navigation system. For a patrol robot with no available Global Positioning System (GPS) support, the embedded VIO components, which are generally composed of an Inertial Measurement Unit (IMU) and a camera, fuse the inertial recursion with SLAM calculation tasks, and enable the robot to estimate its location within a map. The highlights of the optimized VIO design lie in the simplified VIO initialization strategy as well as the fused point and line feature-matching based method for efficient pose estimates in the front-end. With a tightly-coupled VIO anatomy, the system state is explicitly expressed in a vector and further estimated by the state estimator. The consequent problems associated with the data association, state optimization, sliding window and timestamp alignment in the back-end are discussed in detail. The dataset tests and real substation scene tests are conducted, and the experimental results indicate that the proposed VIO can realize the accurate pose estimation with a favorable initializing efficiency and eminent map representations as expected in concerned environments. The proposed VIO design can therefore be recognized as a preferred tool reference for a class of visual and inertial SLAM application domains preceded by no external location reference support hypothesis.
Related Concept Videos
 01:26
Reclosers and Fuses
A comprehensive protection scheme for radial distribution...
 01:29
Tight Junctions
 01:23
Circuit Breaker and Fuse Selection
In high-voltage systems,...
 02:01
Group Design
 01:20
Spin–Spin Coupling: Two-Bond Coupling (Geminal Coupling)
The central atom need not be NMR-active because its electrons are affected by the electron polarization of the spin-active atoms. However, spin information is transmitted less effectively than in one-bond coupling, and 2J values are usually weaker than 1J values. The energy of...
 01:22
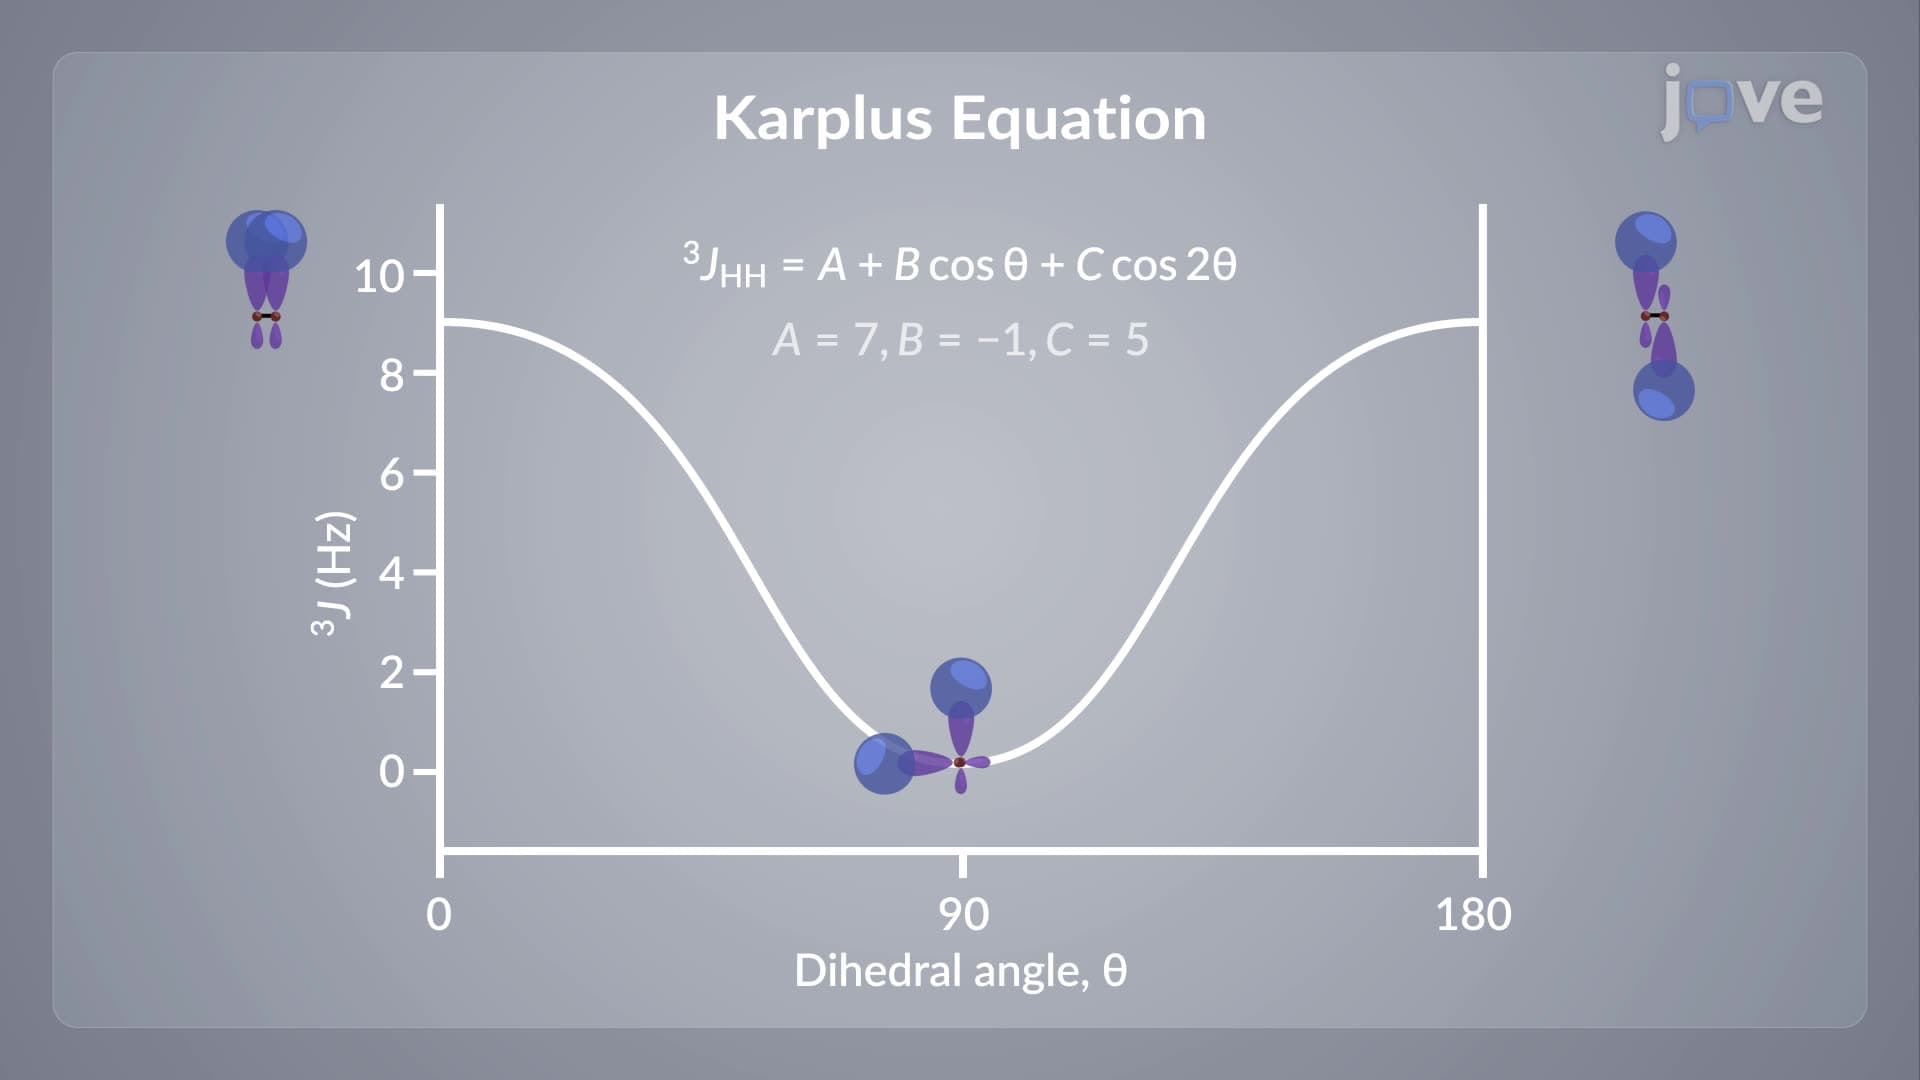
Spin–Spin Coupling: Three-Bond Coupling (Vicinal Coupling)
The extent of coupling depends on the C‑C bond length, the two H‑C‑C angles, any electron-withdrawing substituents, and the dihedral angle between the involved orbitals. The...