Related Experiment Video
Updated: Jan 24, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
RGBD-Inertial Trajectory Estimation and Mapping for Ground Robots
Zeyong Shan1,2,3, Ruijian Li4, Sören Schwertfeger5
1School of Information Science & Technology, ShanghaiTech University, Shanghai 201210, China. shanzy@shanghaitech.edu.cn.

Abstract:
Using camera sensors for ground robot Simultaneous Localization and Mapping (SLAM) has many benefits over laser-based approaches, such as the low cost and higher robustness. RGBD sensors promise the best of both worlds: dense data from cameras with depth information. This paper proposes to fuse RGBD and IMU data for a visual SLAM system, called VINS-RGBD, that is built upon the open source VINS-Mono software. The paper analyses the VINS approach and highlights the observability problems. Then, we extend the VINS-Mono system to make use of the depth data during the initialization process as well as during the VIO (Visual Inertial Odometry) phase. Furthermore, we integrate a mapping system based on subsampled depth data and octree filtering to achieve real-time mapping, including loop closing. We provide the software as well as datasets for evaluation. Our extensive experiments are performed with hand-held, wheeled and tracked robots in different environments. We show that ORB-SLAM2 fails for our application and see that our VINS-RGBD approach is superior to VINS-Mono.
Related Concept Videos
 01:03
Inertial Frames of Reference
 01:27
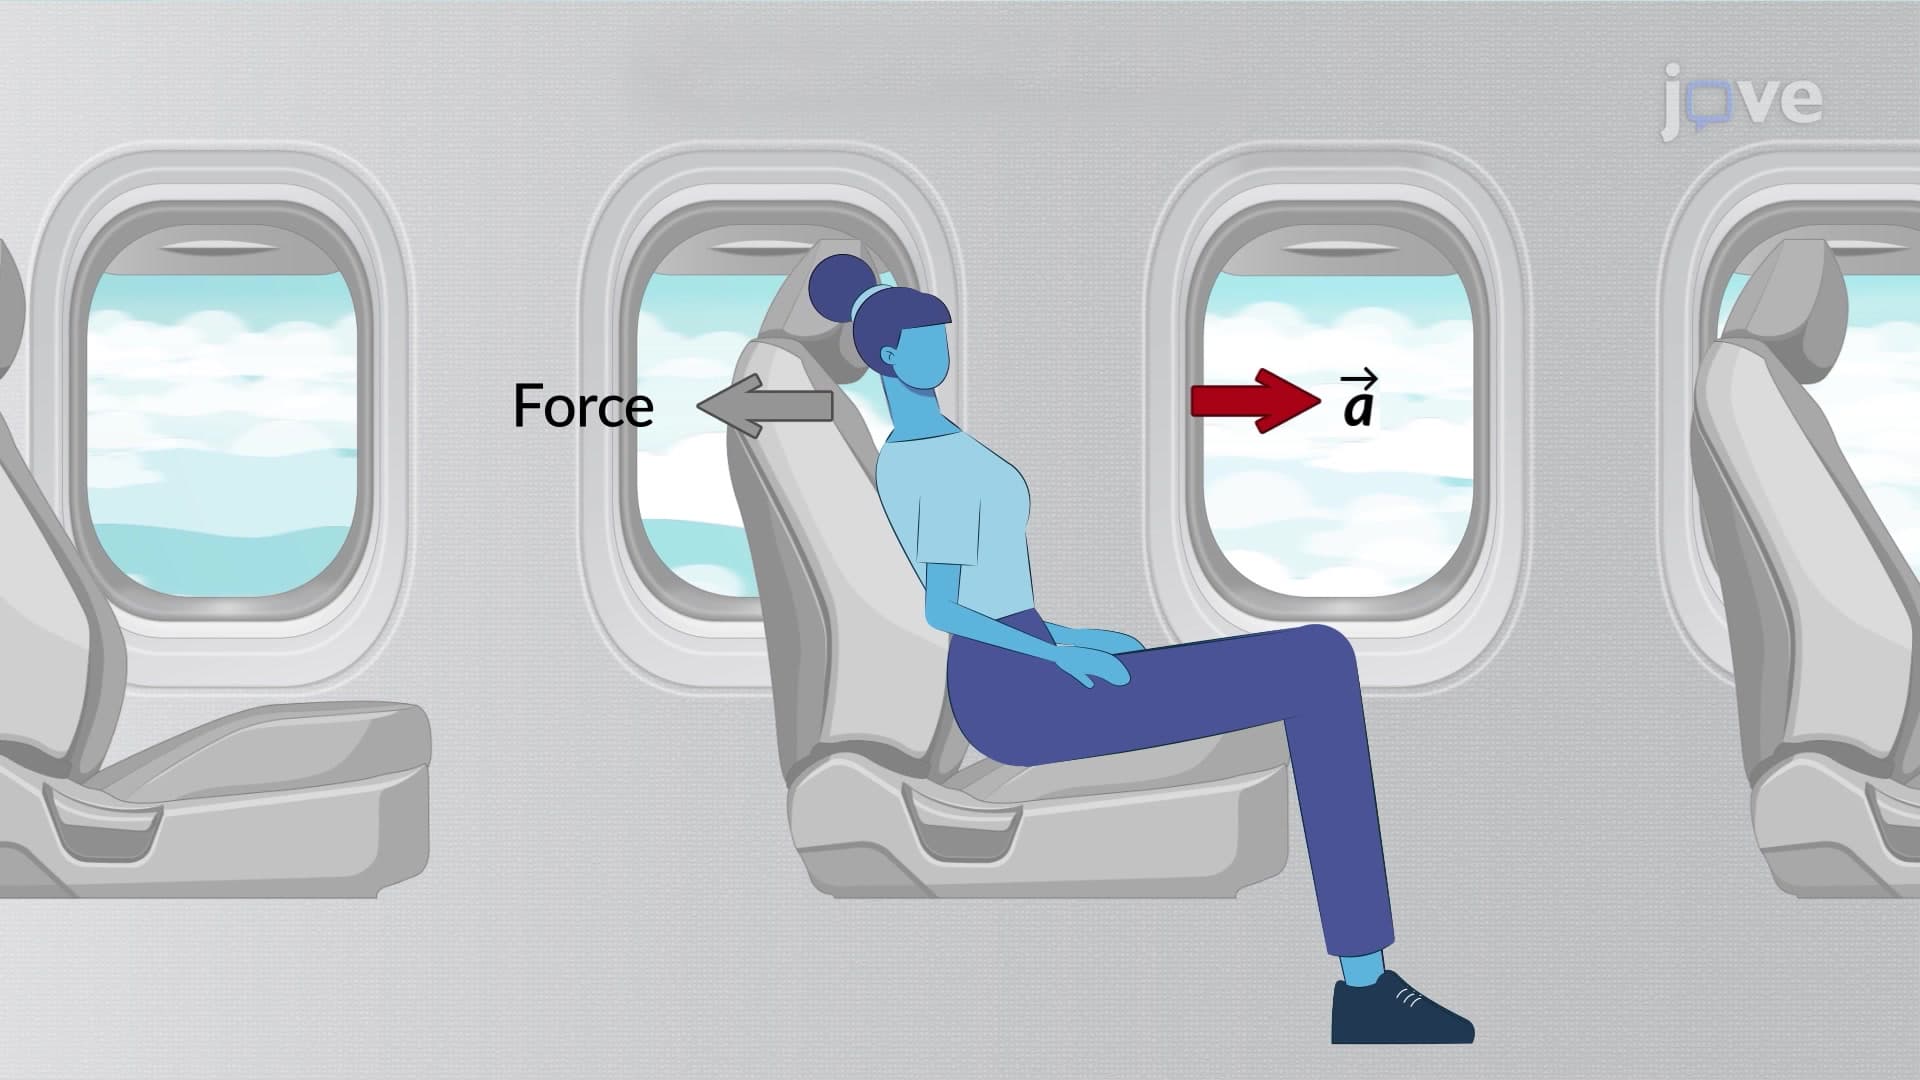
Non-inertial Frames of Reference
 01:12
Taping Over Different Ground Profiles
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:17
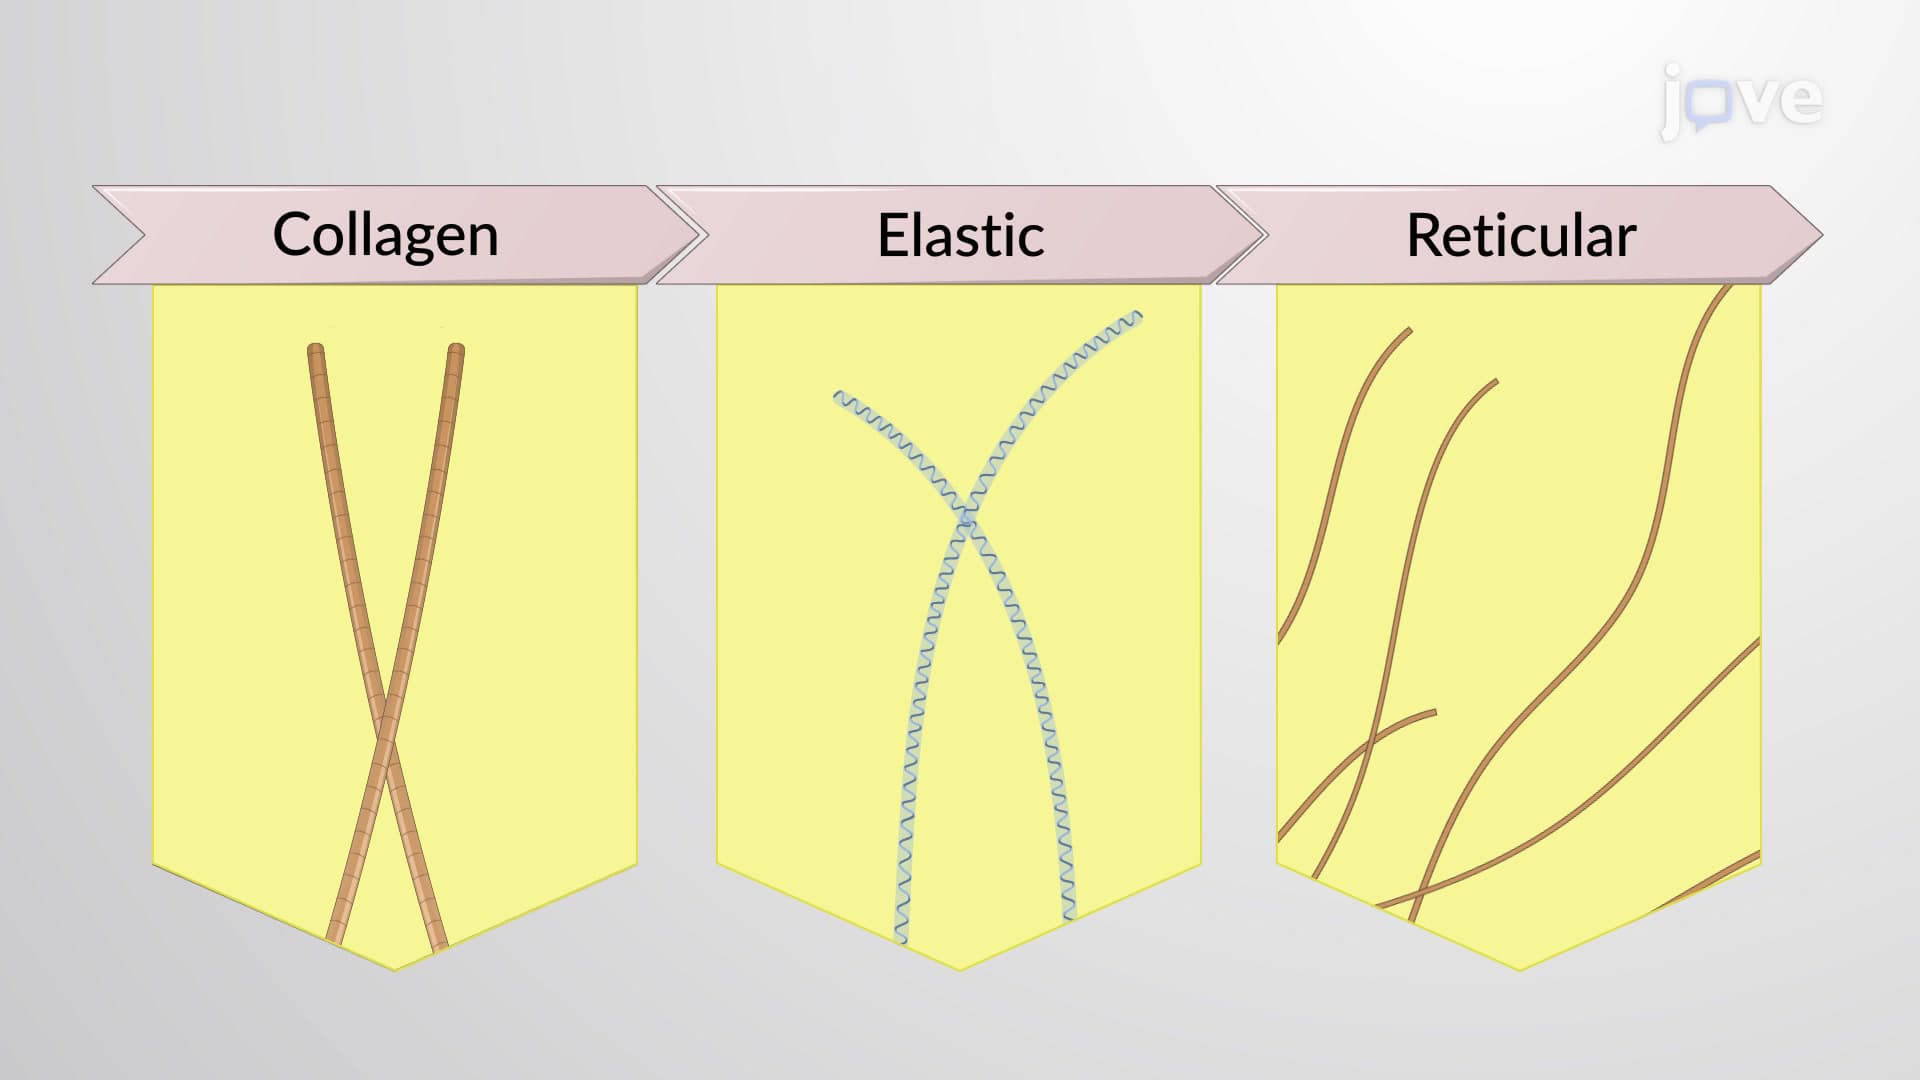
Connective Tissue Fibers and Ground Substance
 01:20
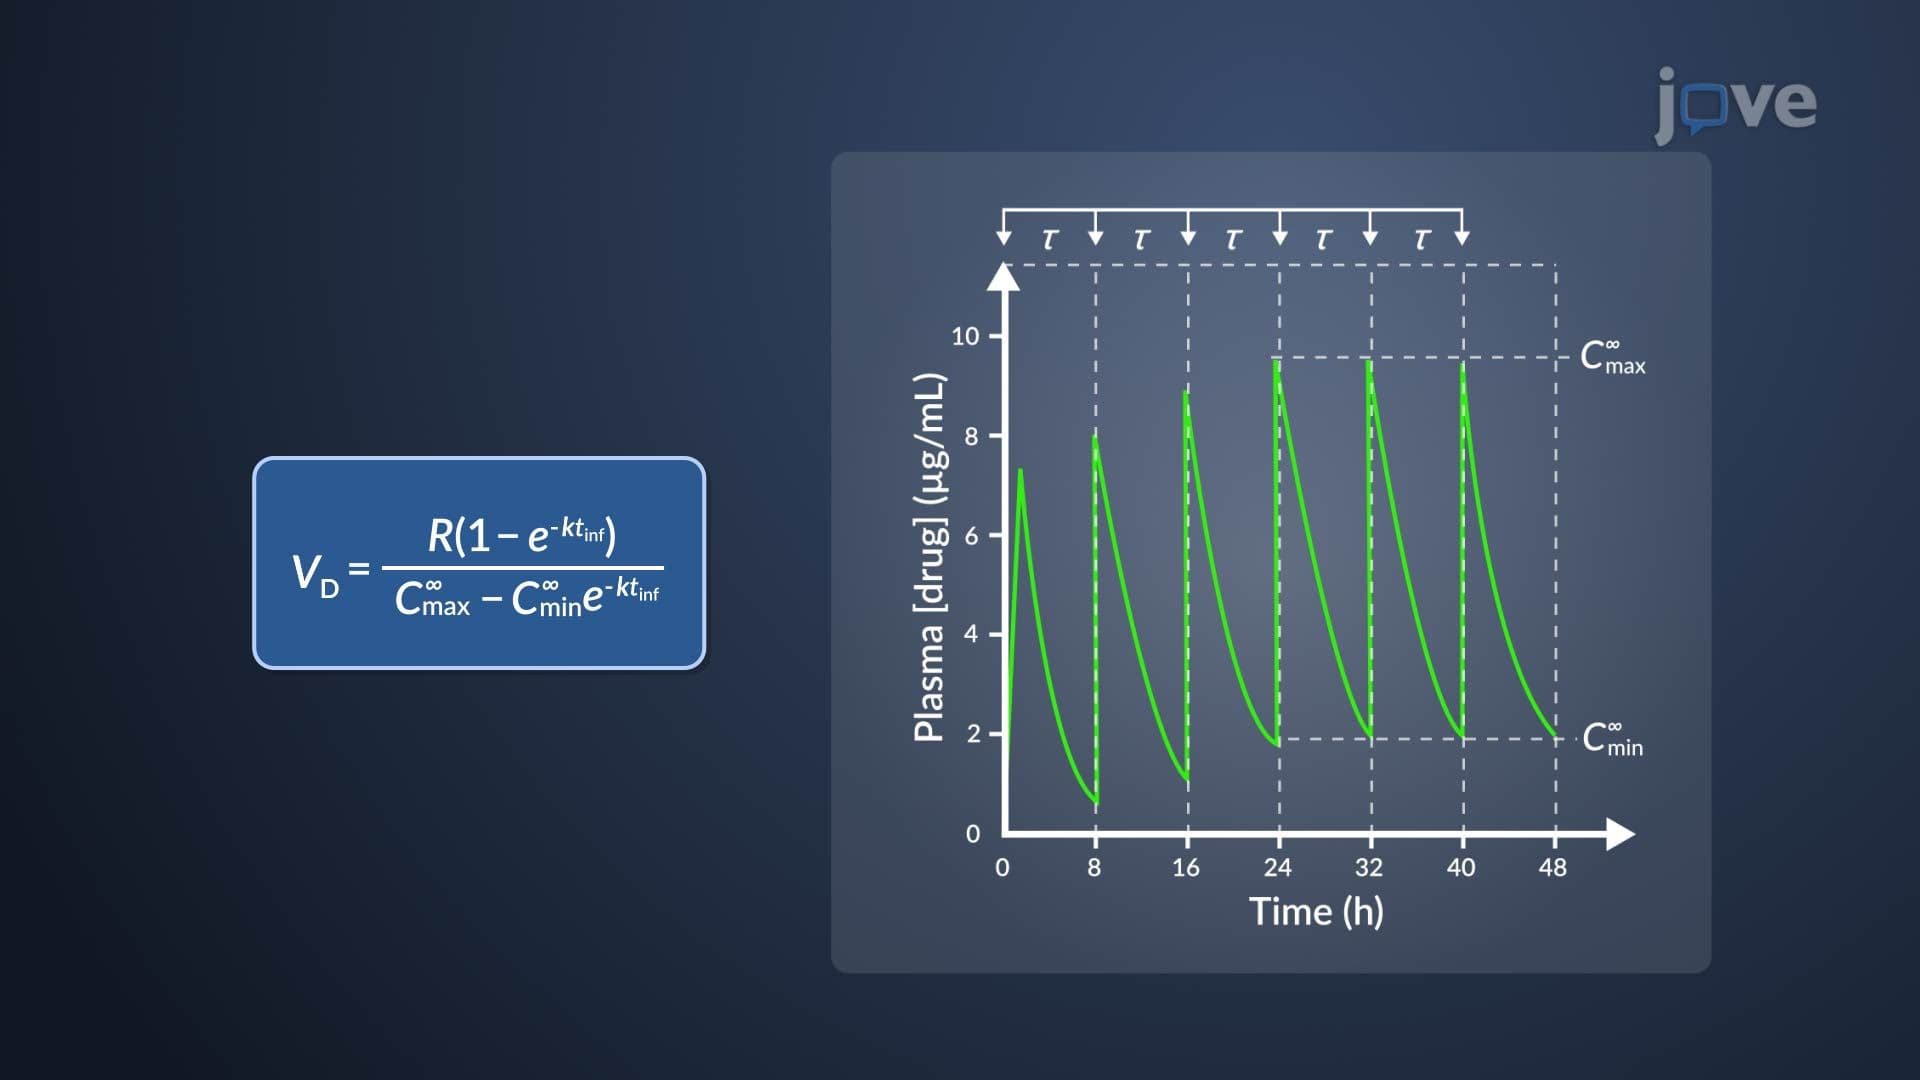
Estimation of k and VD of Aminoglycosides