Related Experiment Video
Updated: Jan 24, 2026

Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Tubular Jamming: A Variable Stiffening Method Toward High-Force Applications with Soft Robotic Components
Tiana Miller-Jackson1,2, Yi Sun2,3,4, Rainier Natividad1,2
11Department of Biomedical Engineering, National University of Singapore, Singapore, Singapore.

Abstract:
The use of soft robotic actuators is on the rise because these soft systems offer the advantage of being highly flexible, which affords safer robot-environment interactions and the gentleness necessary to handle delicate objects. However, this advantage becomes a shortcoming in high-force applications where flexible components fold and fail under large loads. Various methods were sought to meet this challenge by providing a level of rigidity to soft components, but previously proposed solutions bring their own drawbacks including bulky systems, addition of superfluous weight, and restriction of actuator motion. Alternatively, this article presents Tubular Jamming, a new and effective means of stiffening that is adaptable to motion, lightweight, and can be implemented with minimal equipment. In this study, the mechanism of tubular jamming is expounded and is demonstrated through two exemplary soft structures: a tubular jammed beam (TJB) and a tubular jammed hinge (TJH). Both TJB and TJH are exhibited in areas of fabrication, characterization, and a few possible examples of implementation in soft robotic systems. In the TJB structure, tubular jamming is found to increase bending stiffness by nearly threefold at the maximum pressure and packing ratio tested, compared with a traditional soft pneumatic actuator (SPA) beam. The TJB is shown to require less supply pressure to achieve the same performance as a traditional SPA and is shown to perform better in maintaining the vertical position of a borne object. A triangular support configuration made from TJBs is demonstrated to be proficient in weight bearing, supporting a load of nearly 33 times its own weight. In the TJH structure, tubular jamming is shown to have a compound effect on torque output, as three jammed tubule hinges produce approximately four times the torque of a single tubule hinge. The TJH is exhibited in a wearable elbow flexion device. Tubular jamming opens new possibilities for soft components to achieve the stiffness needed to perform high-force tasks such as weight bearing and large-scale actuation while retaining the suppleness to enable a safe robot-to-environment interface.

Related Concept Videos
 01:10
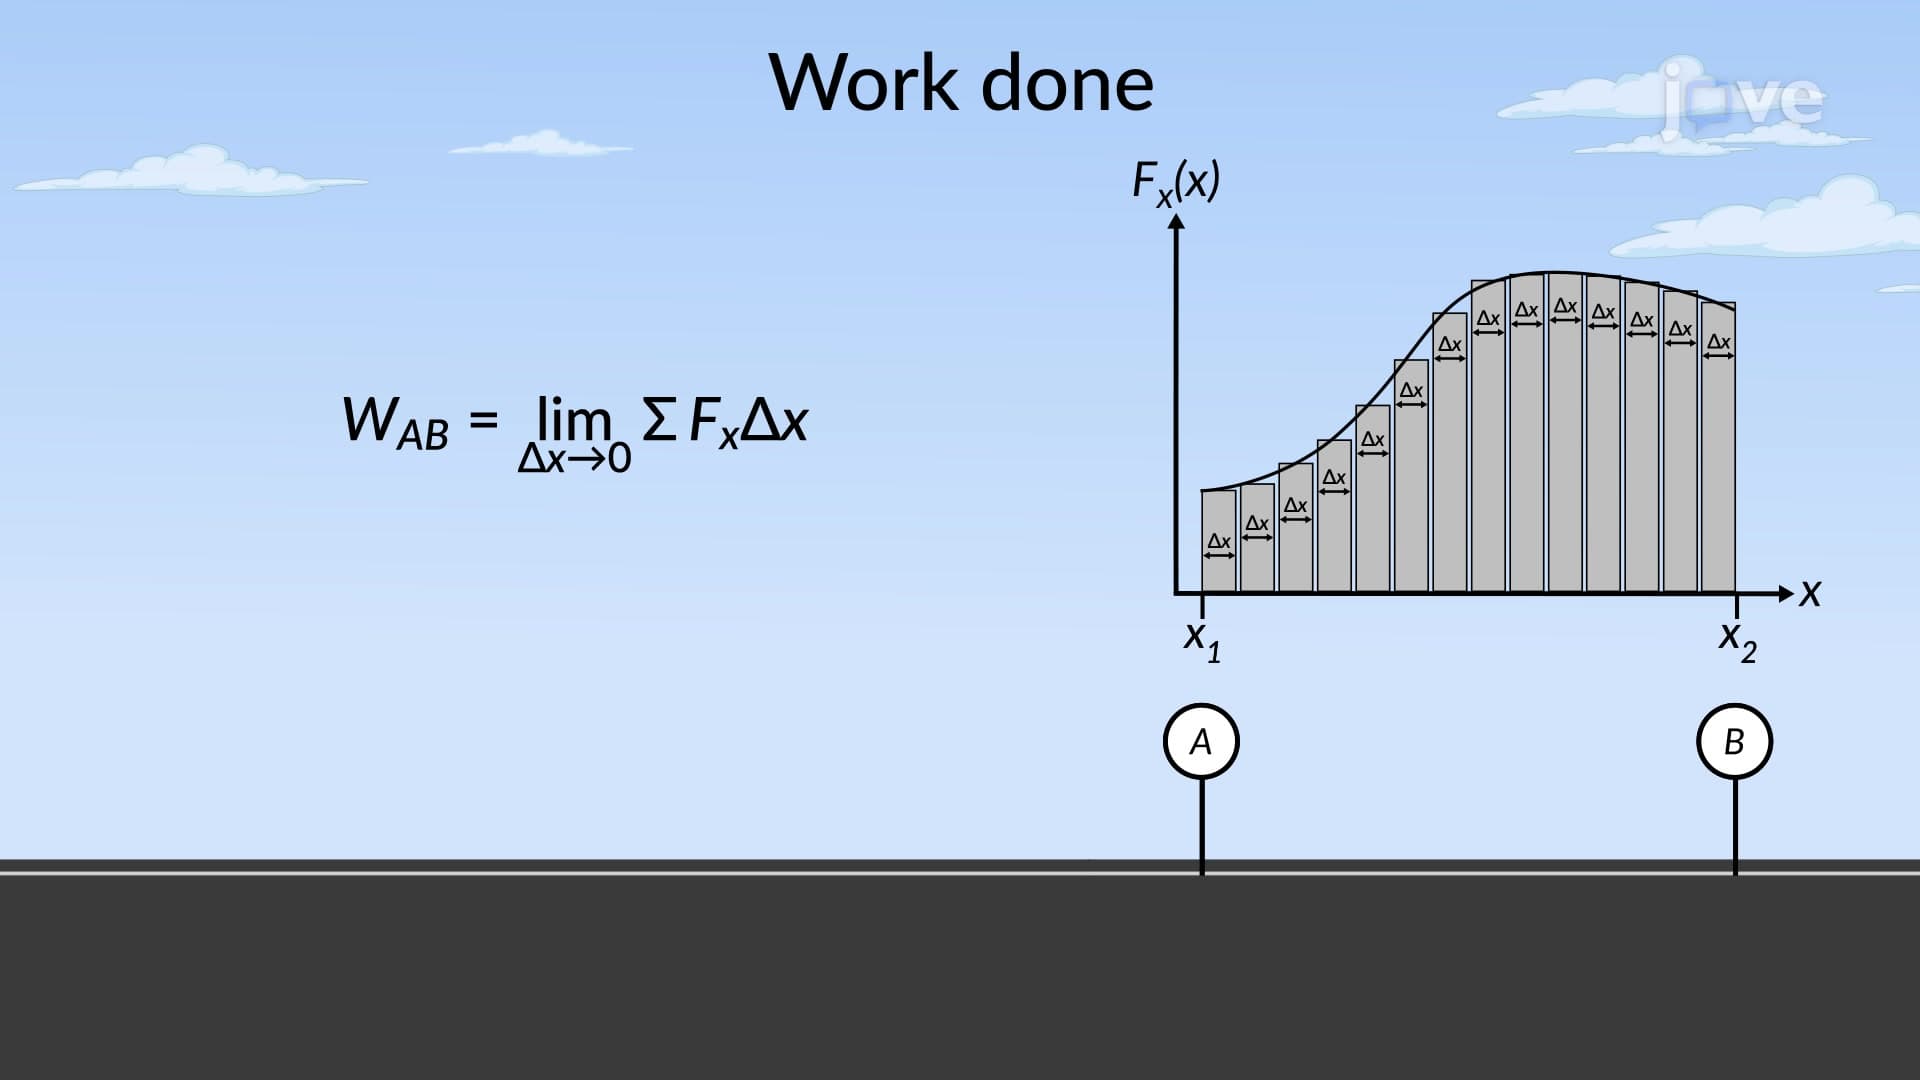
Work and Energy for Variable Forces
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:45
Vesicular Tubular Clusters
With the help of motor proteins such...
 01:28
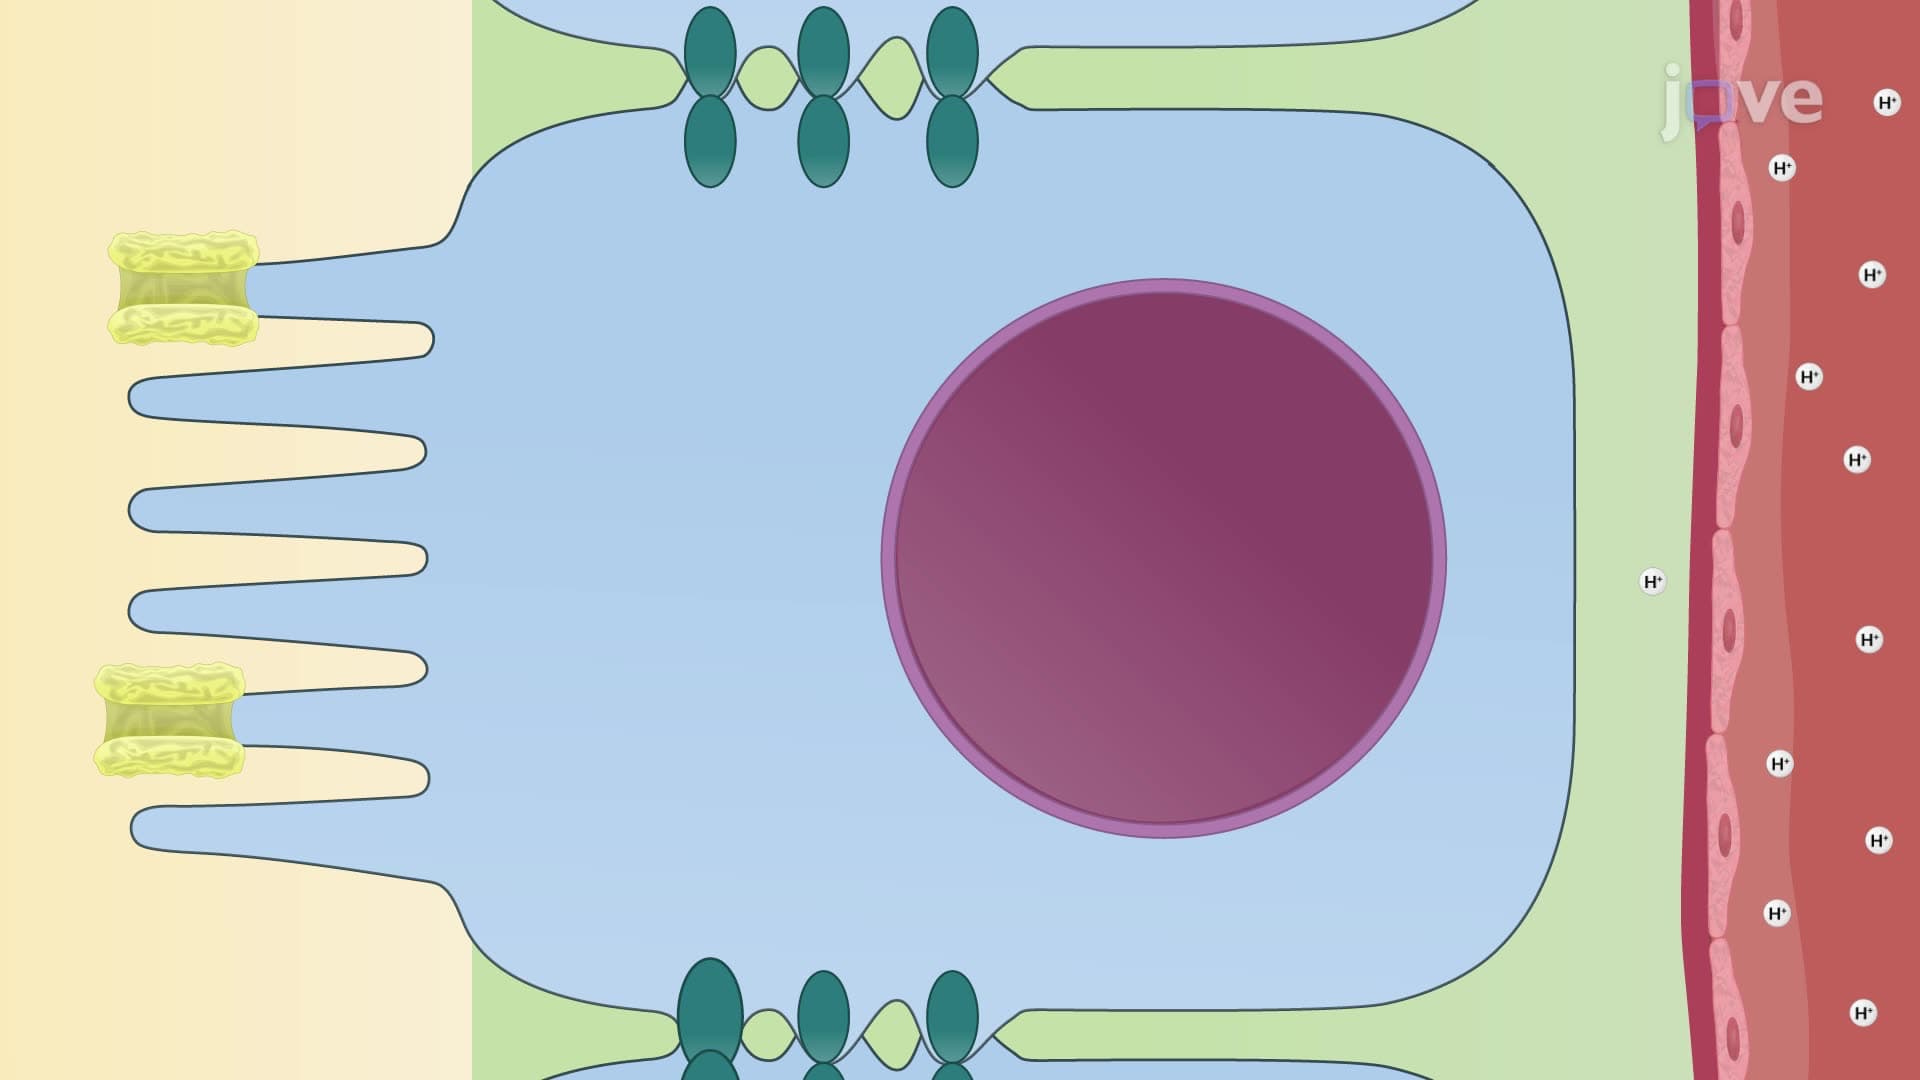
Tubular Reabsorption and Secretion
Tubular reabsorption is a selective process that starts when the filtrate enters the proximal tubules. It involves substances traveling through the transcellular route (through the tubule cell and peritubular...
 01:11
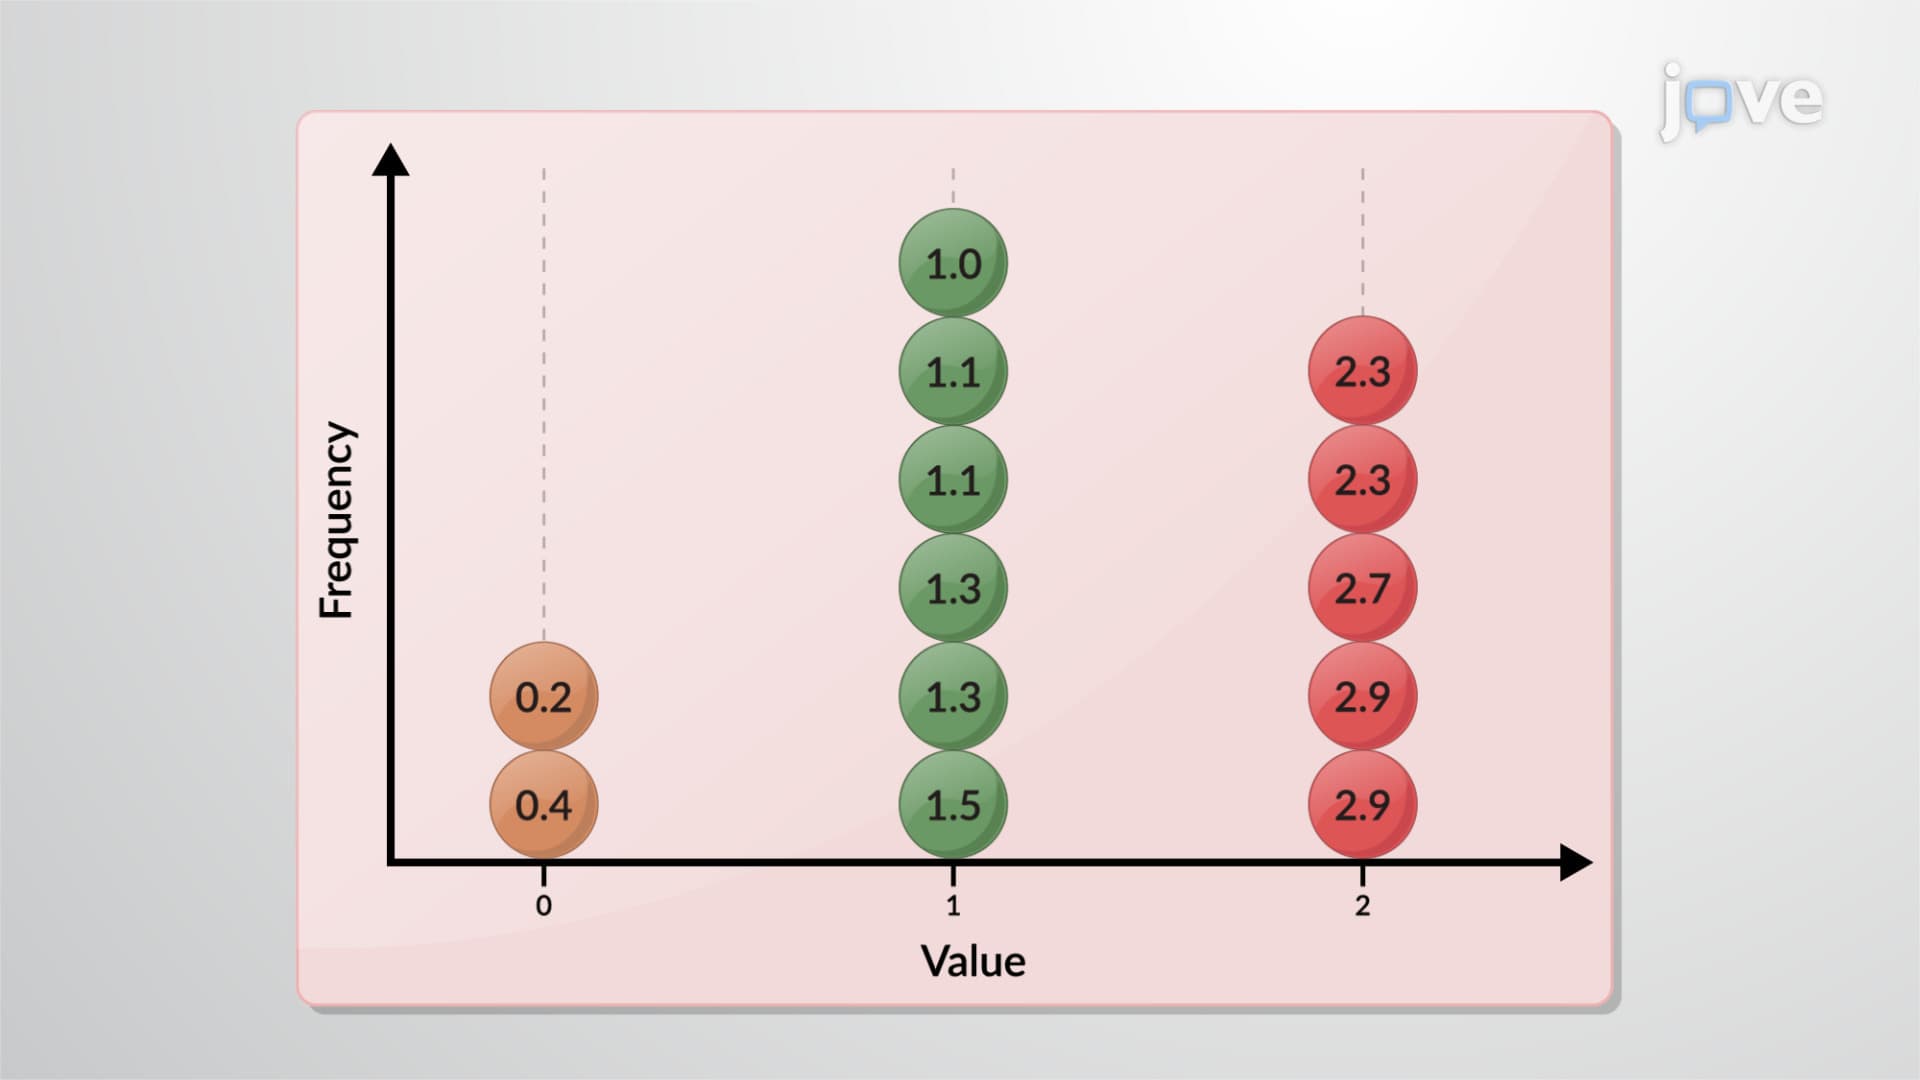
Variability: Analysis
The range is a simple measure of variability, indicating the difference between the highest and...
 01:09
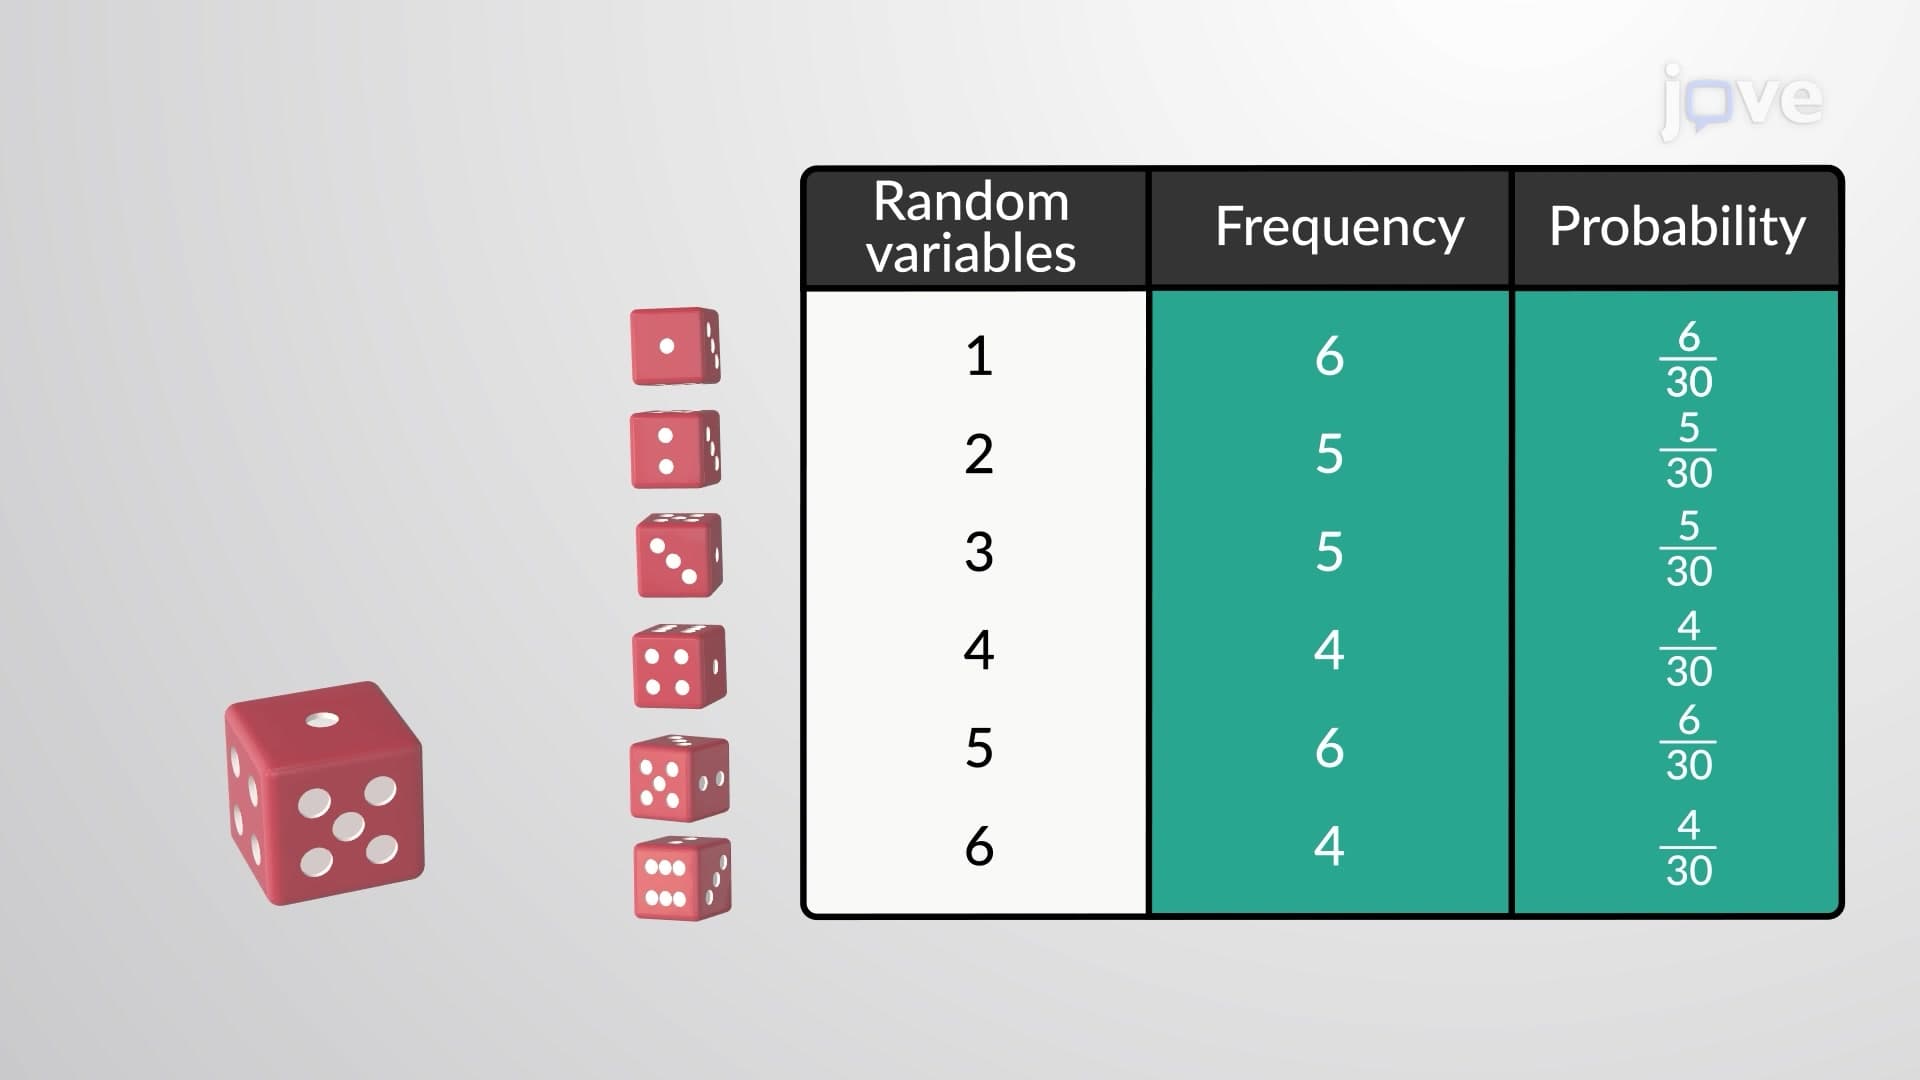
Random Variables
Uppercase letters such as X or Y denote a random variable. Lowercase letters like x or y denote the value of a random variable. If X is a random variable, then X is written in words, and x is given as a number.
For example, let X = the...