Related Experiment Video
Updated: Jan 23, 2026
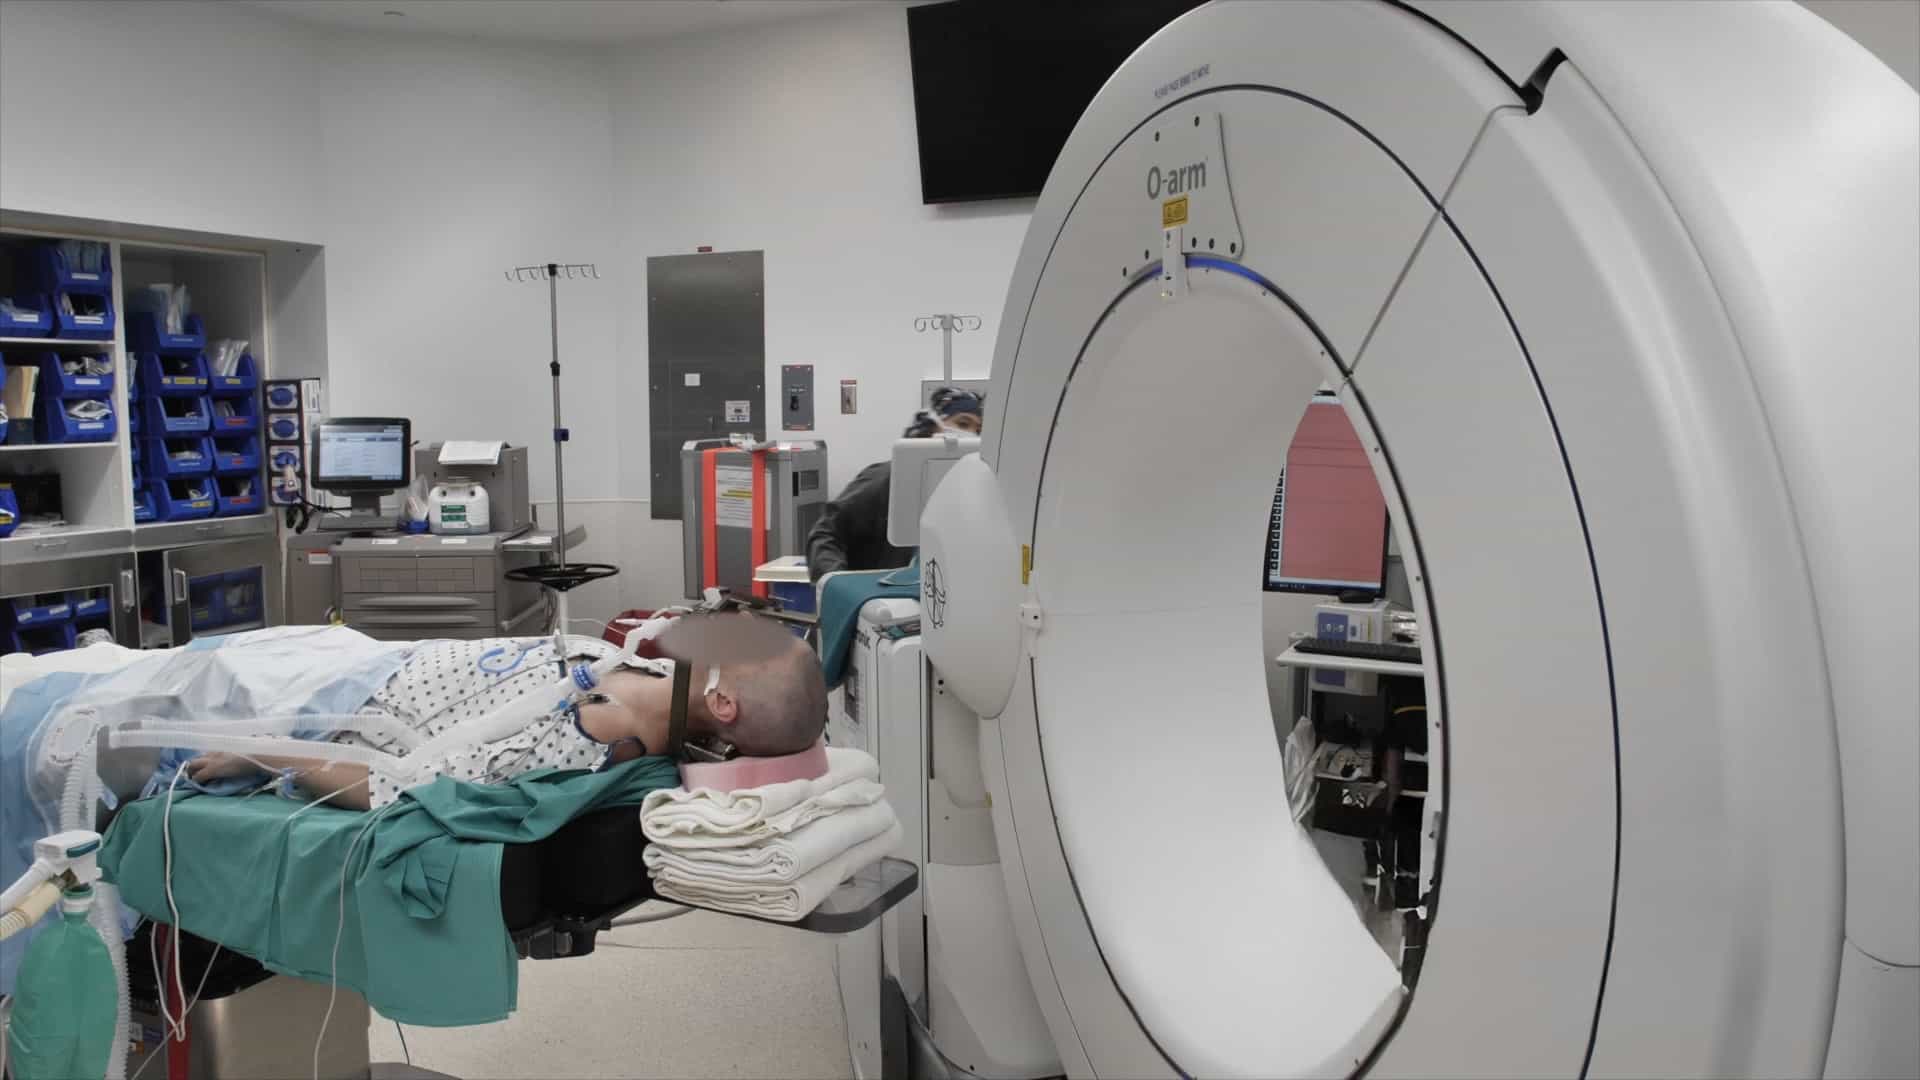

Robotic-Guided Stereoelectroencephalography for Invasive Epilepsy Monitoring
Published on: June 13, 2025
Teaching in the robotic environment: Use of alternative approaches to guide operative instruction
Courtney A Green1, Simon N Chu2, Emily Huang3
1University of California San Francisco, Department of Surgery, 513 Parnassus Avenue, S-321, San Francisco, CA, 94143-0470, USA.

Background:
With the rapid growth of robotic-assisted surgery, surgical educators recognize the need to develop appropriate curriculum for trainees. However, the unique robotic learning environment challenges educators to determine the most appropriate ways to instruct surgical residents. The purpose of this study was to characterize the instructional techniques used in the robotic teaching environment by observing attending surgeon's language and behaviors during resident robotic dissection.
Study Design:
Attending robotic surgeons guided senior residents through robotic dissection of live porcine tissue. Three observers documented the language, gestures and behaviors occurring at three different stations, and at a fourth station, they obtained video and audio recordings of the instructional interaction. Afterwards, instructors and residents met in separate focus groups. The authors used qualitative content analysis to summarize the type and frequency of teaching behaviors and focus group information to clarify the analysis. We compared the frequency of the behaviors to an existing taxonomy of 16 operative teaching behaviors in open and laparoscopic surgery.
Results:
Robotic instructors used 11 of the 16 behaviors previously described for surgical instruction. Frequency of use differed in the robotic environment due to relevance and application of new techniques. New, unique robotic teaching behaviors involved disengaging the resident from the operative console for either onscreen direction or for gesturing with verbal instruction. Focus group participants highlighted these behaviors as essential.
Conclusion:
Robotic instruction uses a different set of instructional approaches compared to open and laparoscopic surgery. New teaching behaviors emerged driven by physical separation within the robotic environment. Robotic faculty development should emphasize these unique features.
More Related Videos
 04:50
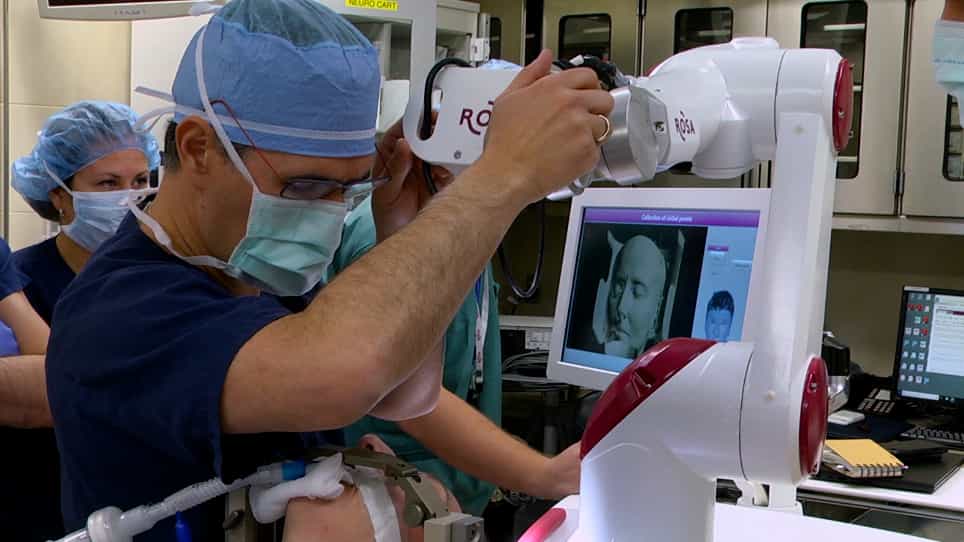
Operative Technique and Nuances for the Stereoelectroencephalographic SEEG Methodology Utilizing a Robotic Stereotactic Guidance System
Published on: June 9, 2023
 13:44
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011
Related Concept Videos
 02:18
Alternative RNA Splicing
There are five types of alternative RNA splicing that vary in the ways the pre-mRNA segments are removed or retained in the mature mRNA. The first...
02:18Alternative RNA Splicing
 01:16
Null and Alternative Hypotheses
The null hypothesis, denoted by H0 is a statement of no difference between the variables—they are not related. This can often be considered the status quo. As a result if you cannot accept the null, it requires some action.
The alternative hypothesis, denoted by H1 or Ha, is a claim about the...
 01:17
Operational Amplifiers
 01:20
Vector Operations
A vector multiplied by a scalar value is called scalar multiplication. The result obtained is a new vector with a different magnitude. If the scalar is positive, the direction of the vector remains the same, but if it is negative, the direction of the vector is reversed. For example, the product of the mass and velocity yields the momentum.
 01:21
Operant Conditioning
Reinforcement in operant conditioning can be positive or negative, both of which serve to increase the likelihood of a behavior. Positive...