Related Experiment Video
Updated: Jan 22, 2026


A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Robot-Assisted Pedicle Screw Placement: Learning Curve Experience
Mehdi I Siddiqui1, David J Wallace2, Luis M Salazar1
1Long School of Medicine, University of Texas Health Sciences Center, San Antonio, Texas, USA.

Objectives:
To describe the learning curve of pedicle screw placement using robot-assisted spine surgery of an experienced neurosurgeon and 2 supervised neurosurgical fellows.
Methods:
The first 120 cases of robot-assisted spine surgery at our institution were assessed. Patient variables included age, body mass index, and indication for surgery. Intraoperative variables included the vertebral level of screw placement, number of screws placed by each operator, intraoperative blood loss, and operative time. Postoperative variables included length of stay, discharge disposition, 30-day readmissions, wound complications, and hardware revisions. Screw accuracy was determined with image overlay analysis comparing planned screw trajectory on the navigation software with the intraoperative computed tomography scan with final screw placement. Two-dimensional accuracy was determined for the tip of the screw, tail of the screw, and angle at the screw was placed. The supervising physician and first fellow began utilizing the robot concurrently upon its arrival, and the second fellow began using the robot after the system had been in place for 7 months.
Results:
Both experienced surgeon and first fellow displayed a learning curve and achieved statistically significant improvement of accuracy after 30 screws. The second fellow had significantly better accuracy than the experienced surgeon in his first 30 screws. There were no complications from hardware placement in either group. There were no returns to the operating room for hardware issues.
Conclusions:
Robot-assisted spine surgery is a safe, accurate method of pedicle screw instrumentation. Our data show similar learning adaptation rates for the first fellow and the experienced surgeon. Techniques learned by the attending surgeon were immediately transferable to a new learner, who was able to achieve a faster learning curve than both the first fellow and the experienced surgeon.

Related Concept Videos
 01:16
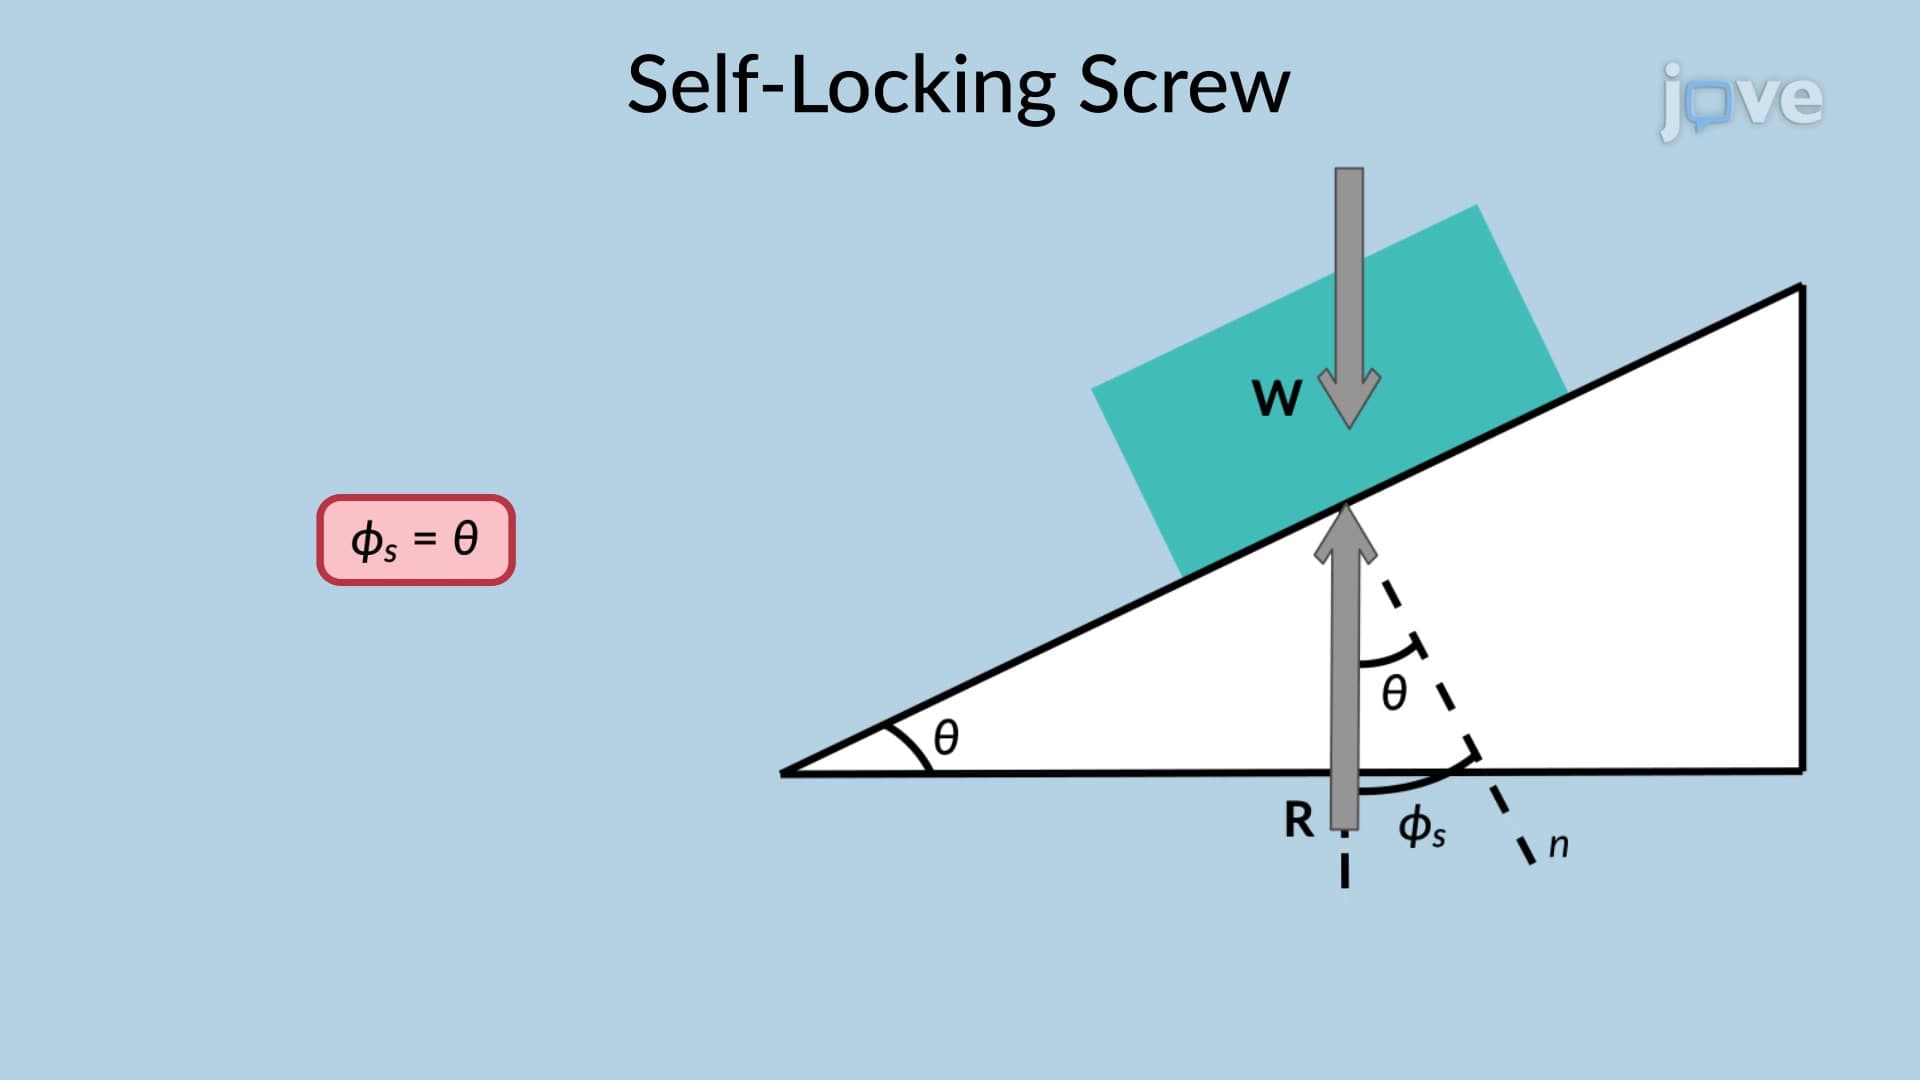
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 01:21
Screw: Problem Solving
To evaluate the...
 01:17
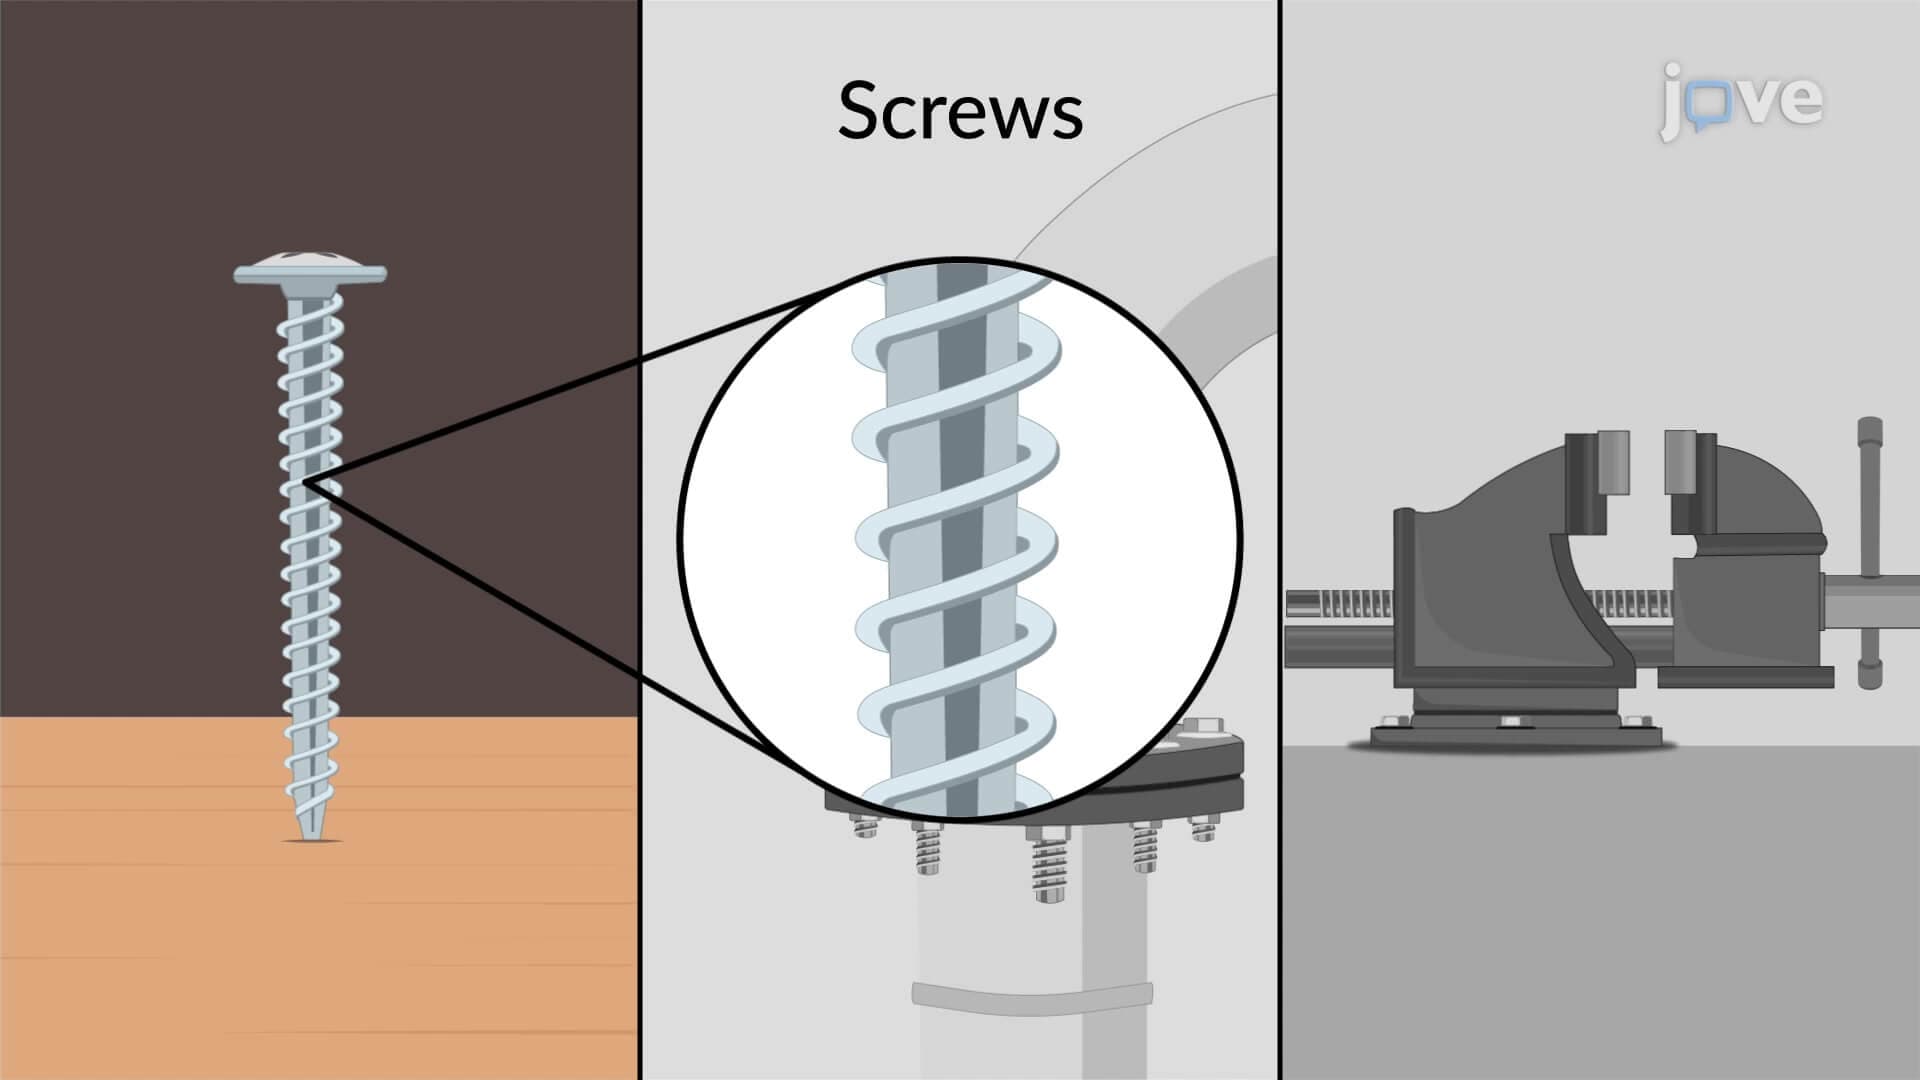
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 02:44
Heating and Cooling Curves
For instance, the addition of heat raises the temperature of a solid; the amount of heat absorbed depends on the heat capacity of the solid (q = mcsolidΔT). According to thermochemistry, the relation between the amount of heat absorbed or released by a substance, q, and its...
 02:23
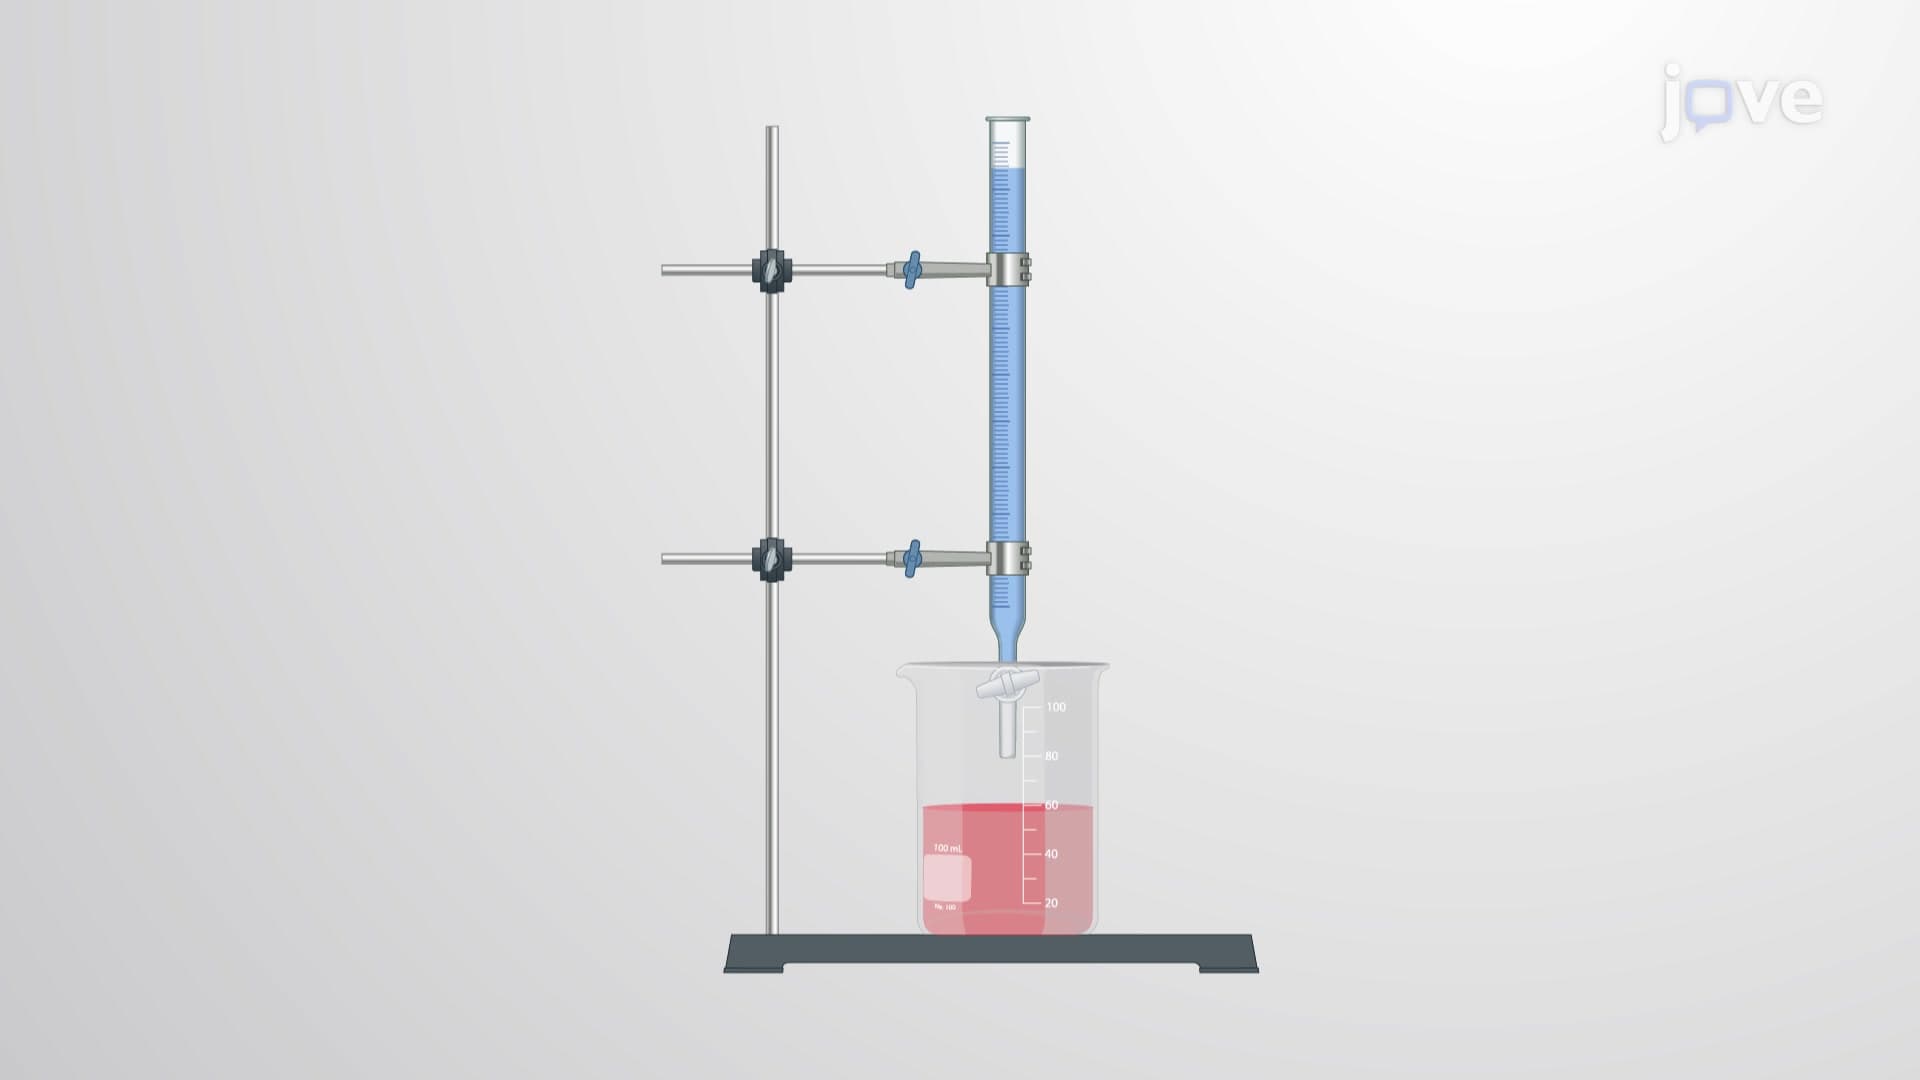
Acid-Base Titration Curves
For a titration carried out for 25.00 mL of...
 01:17
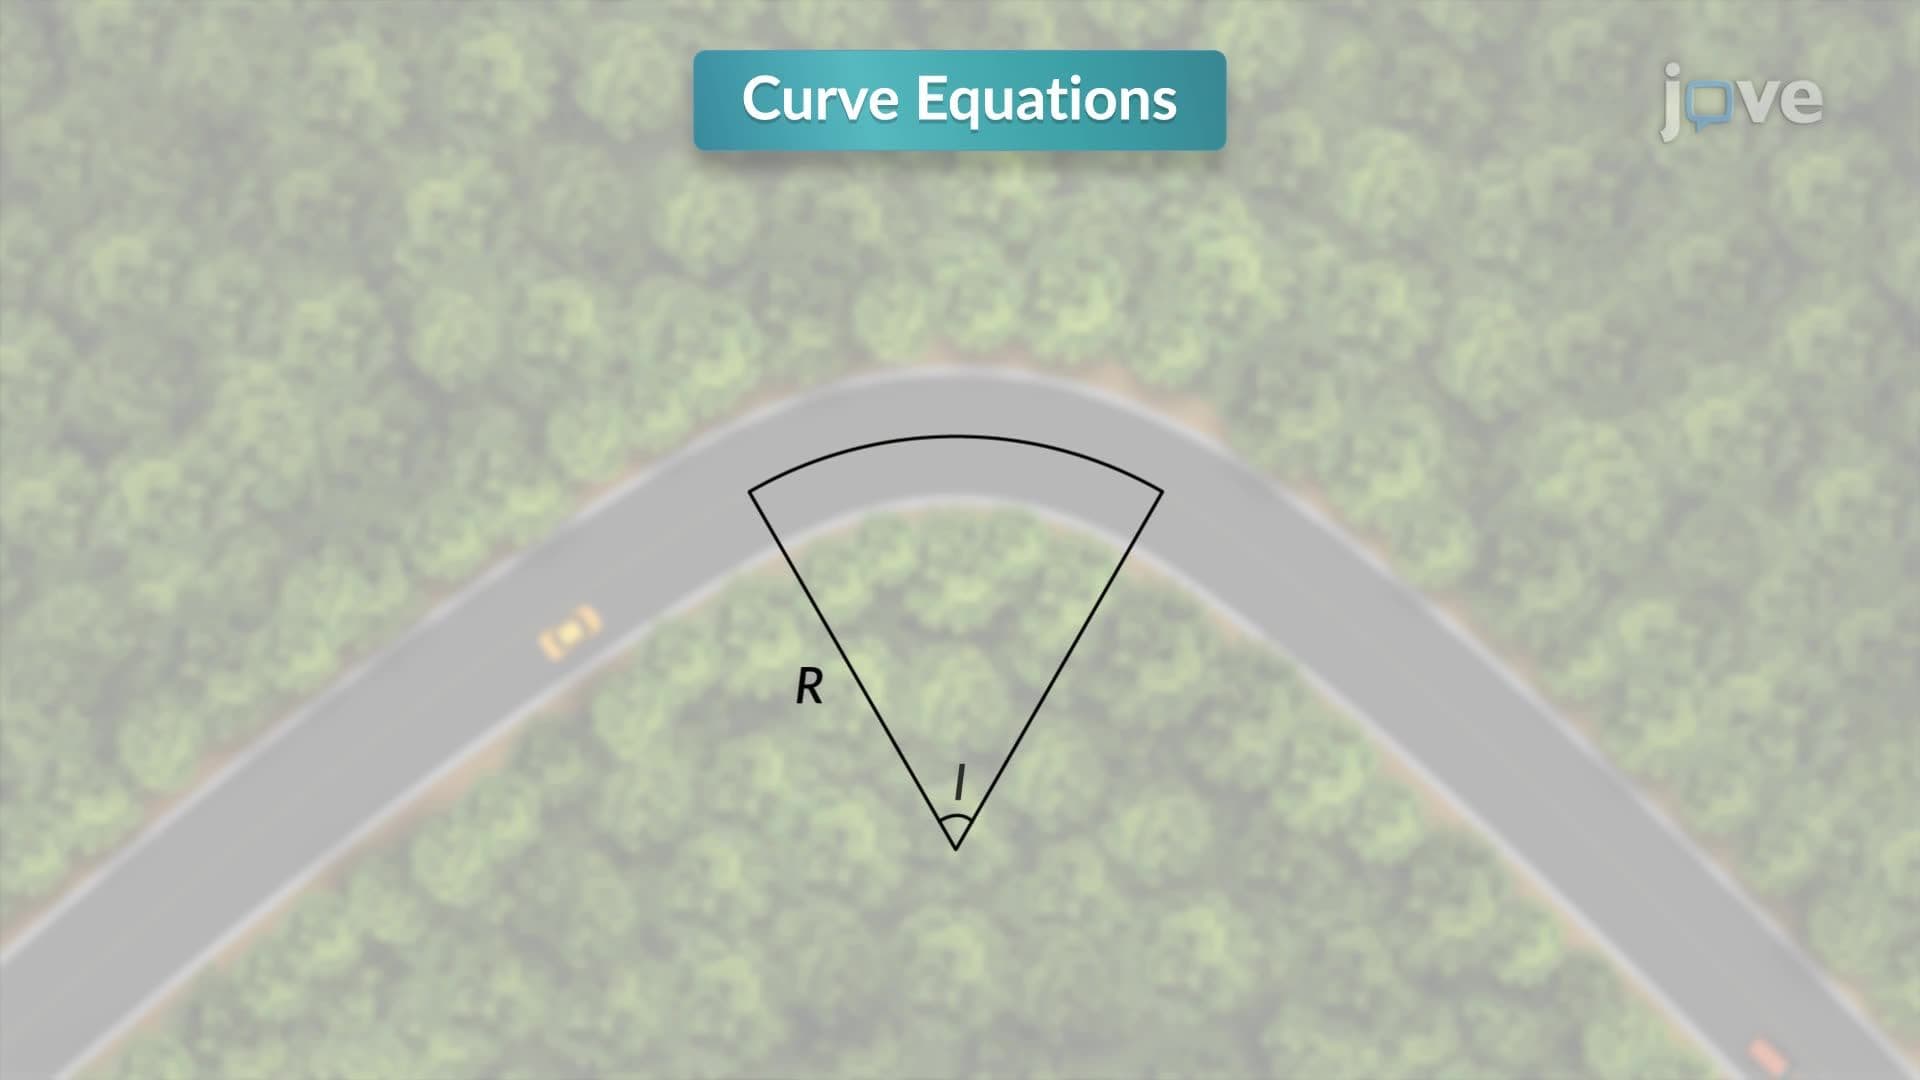
Curve Equations