Related Experiment Video
Updated: Jan 21, 2026
Terahertz Microfluidic Sensing Using a Parallel-plate Waveguide Sensor
Published on: August 30, 2012
Sensorized, Flat, Pneumatic Artificial Muscle Embedded with Biomimetic Microfluidic Sensors for Proprioceptive
Jackson Wirekoh1, Luis Valle2, Nishant Pol3
1NYU Langone Health, New York City, New York.

Abstract:
In recent years, soft components, such as pneumatic artificial muscles (PAMs), have been increasingly employed to design safer wearable devices. Despite the inherent compliance of the materials used to fabricate PAMs, the actuators are able to produce relatively large forces and work when compared to their weight. However, effective operation of these systems has traditionally required bulky external force and position sensors, which limit the maneuverability of users. To overcome these issues, inspiration was taken from organic muscles, which incorporate embedded sensors, such as Golgi tendon organs and muscle spindles, to provide real-time position and force feedback for muscles. As such, a sensorized, flat, pneumatic artificial muscle (sFPAM) with embedded force and position sensors was designed and fabricated. In addition, a hyperelastic model was developed and verified through comparison with the experimentally characterized mechanical and electrical performance of the sFPAM. Furthermore, a sliding mode controller was implemented to demonstrate the feasibility of embedded sensors to provide feedback during operation. Ultimately, a lightweight, compact actuation system was designed with the ability to be seamlessly incorporated into future wearable devices.
Related Concept Videos
 00:46
Feedback Inhibition
 01:01
Feedback Loops
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Facial Feedback Hypothesis
 01:28
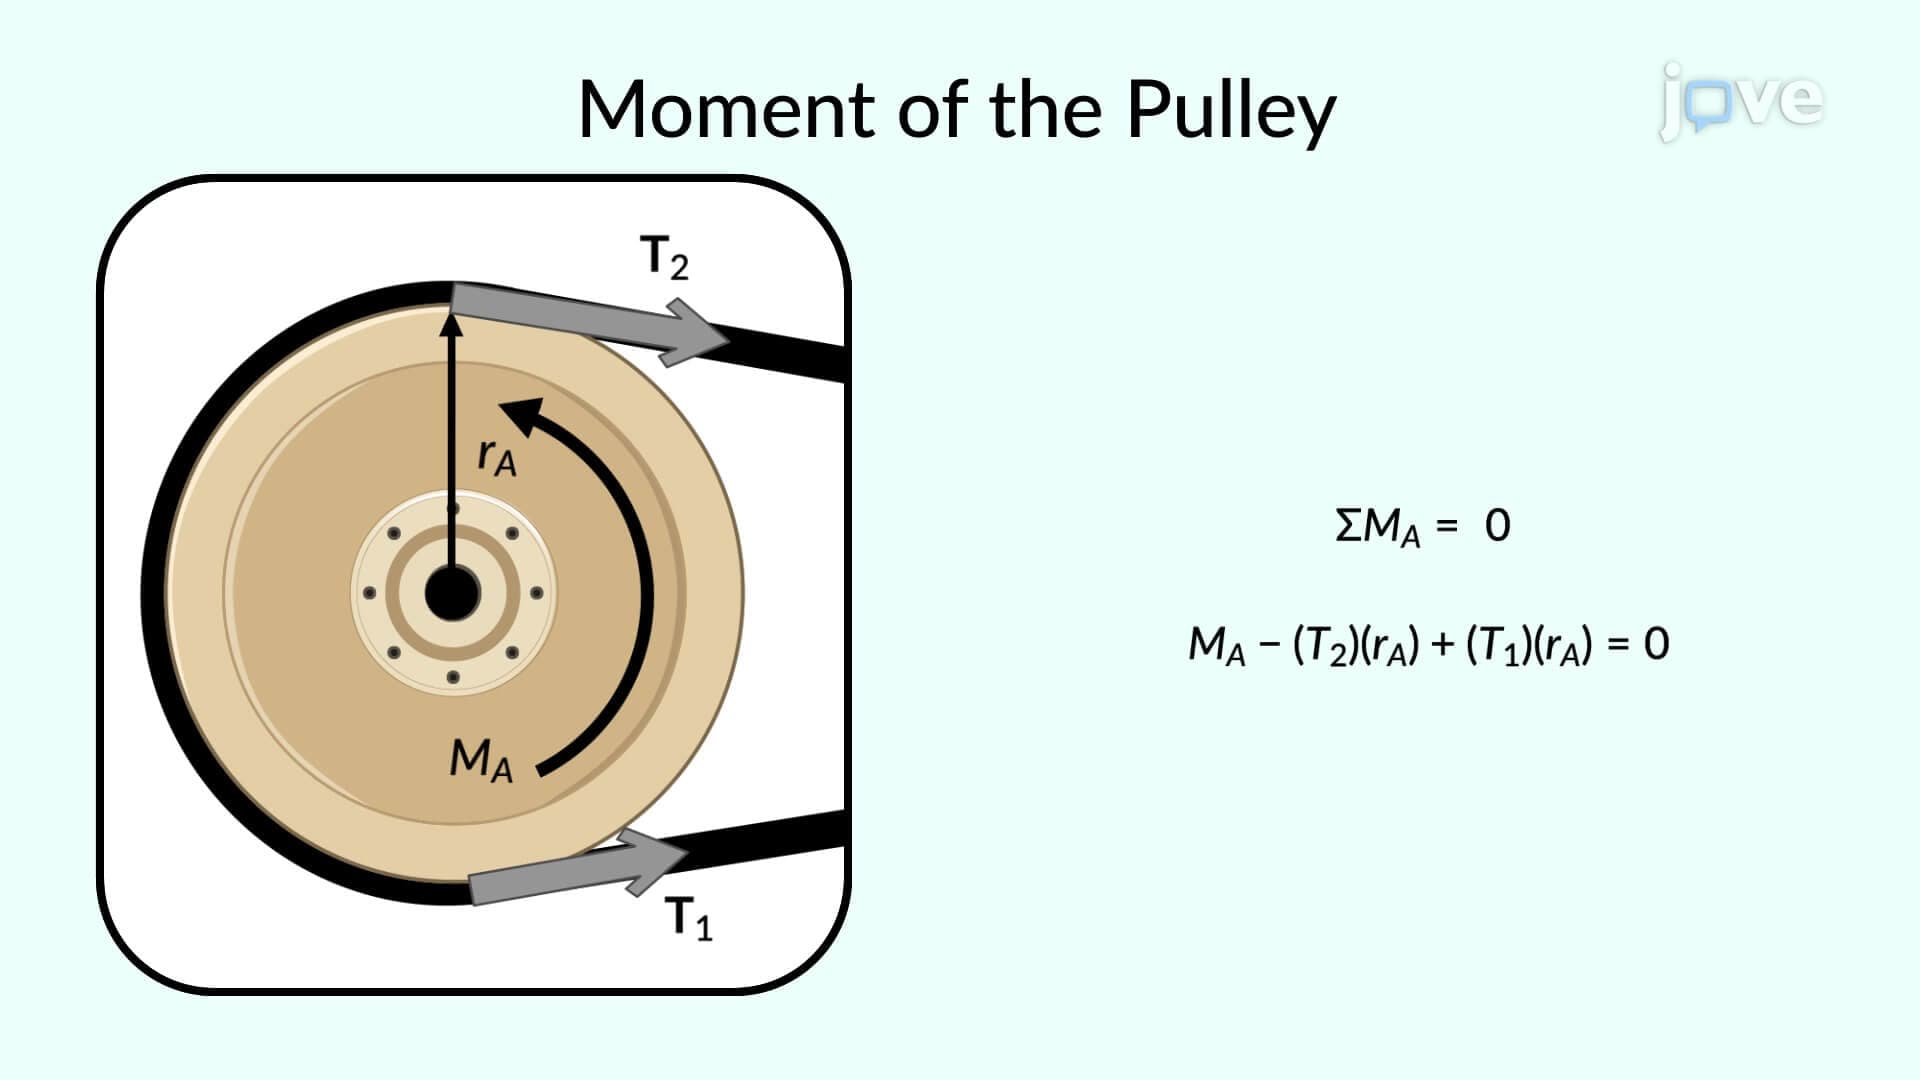
Flat Belts: Problem Solving