Related Experiment Video
Updated: Jan 21, 2026
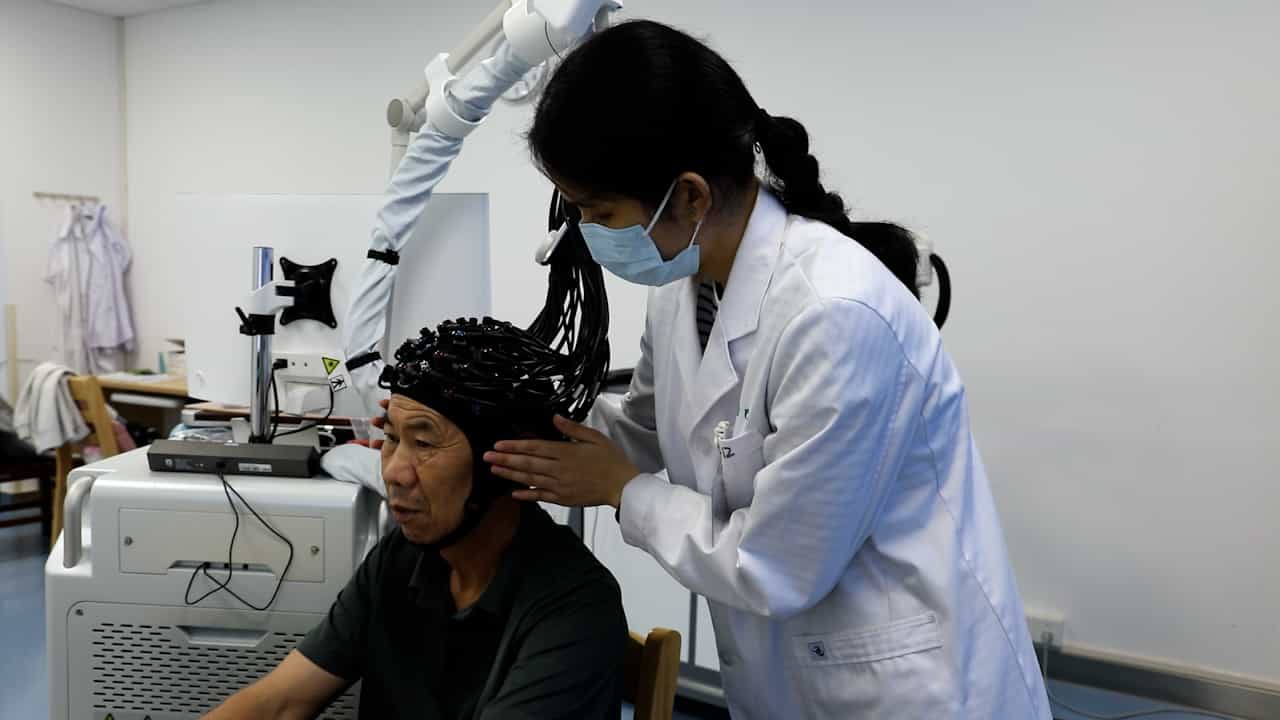
Soft Pneumatic Robot Modulates Graph Theory Metrics of Brain Network for Hand Rehabilitation After Stroke
Published on: October 10, 2025
Design of a 3D Printed Soft Robotic Hand for Stroke Rehabilitation and Daily Activities Assistance

Abstract:
In this paper, we present the new personalized 3D printed soft robotic hand for providing rehabilitation training and daily activities assistance to stroke survivors. The Soft-Elastic Composite Actuator (SECA) on the robotic hand is direct 3D printed to accommodate with different finger sizes. Flexion and extension can be actively facilitated on the SECA using the same pressurizing source. Iterative learning model predictive control (ILMPC) method is used to be the control algorithm of SECA. At 160 kPa of maximum input pressure, results show that the actuator bending angles can reach to 137 °, and tip output force can also reach to 2.45 N. Multiple 3D printed SECAs are integrated to a 3D printed hand base and then to be worn on stroke survivors. Two stroke survivors are recruited to evaluate the intention-based rehabilitation training with the 3D printed soft robotic hand, which improvement of their hand function can be observed on performing some daily tasks such as grasping a coin.
More Related Videos
Related Concept Videos
 01:28
Structure-Activity Relationships and Drug Design
SAR studies the intricate relationship between a drug's chemical structure and biological activity. It focuses on understanding how modifications to a drug's structure can influence...
 01:17
Classical Conditioning in Daily Life
John B. Watson and Rosalie Rayner famously demonstrated the development of fear through classical conditioning in their experiment with Little Albert. They paired the...
 01:23
Hand hygiene
Hand washing...
 02:01
Group Design
 02:01
Factorial Design
 01:25
Types of Reports I: Hands-off Report
Following are the key components and categories of hand-off reports:
Purpose and Process: