Related Experiment Video
Updated: Jan 21, 2026
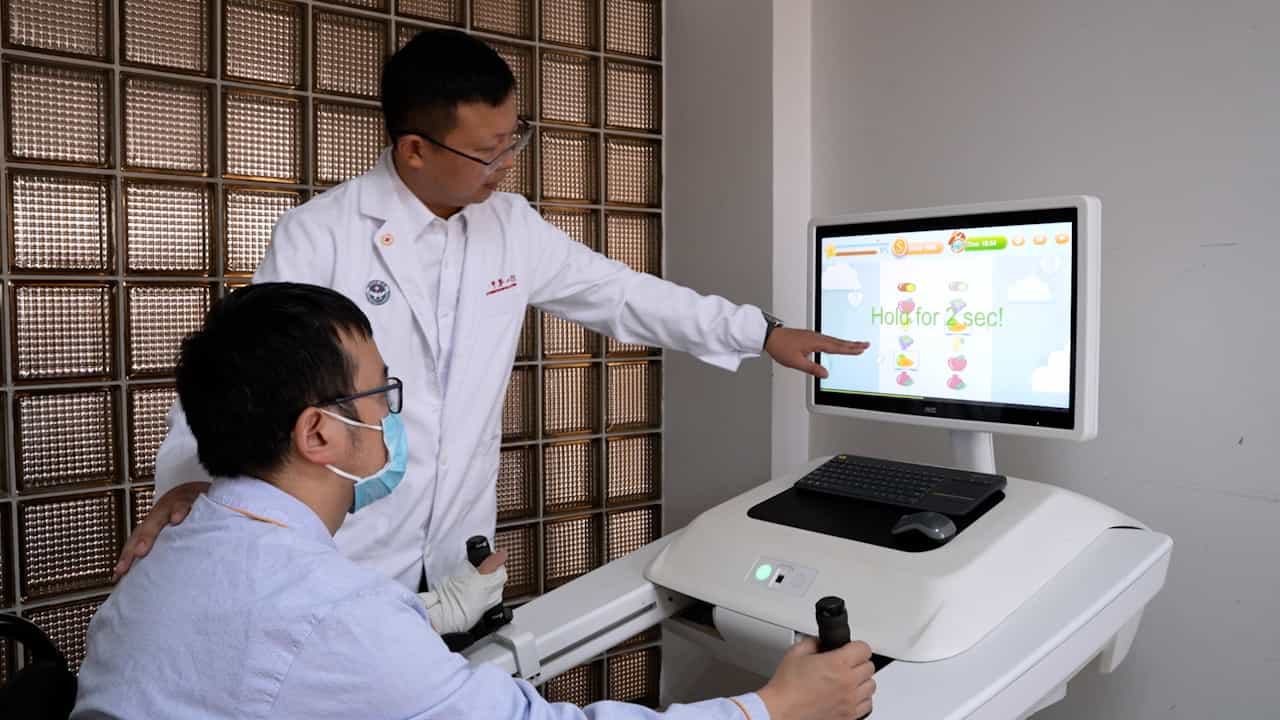

Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024
Adaptive Continuous Integral-Sliding-Mode Controller for Wearable Robots: Application to an Upper Limb Exoskeleton

Abstract:
This paper introduces an adaptive integral sliding mode controller for exoskeletons. The controller design is based on the hypothesis that only classical properties are known such as parameters' bounds, and all other functions are unknown. To ensure the convergence in position, velocity and acceleration for desired trajectories, disturbances are supposed to be bounded. The closed-loop stability of the system in the sense of Lyapunov is demonstrated. The effectiveness of the proposed approach is proved in real time using a 2-DOF upper limb exoskeleton in the rehabilitation context taking into account the security and the safety of the user.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Related Concept Videos
 01:12
Arteries of the Upper Limbs
 01:17
Veins of Upper Limbs
The deep venous system is primarily composed of the ulnar and radial veins. The ulnar vein, which drains the fingers through the superficial palmar venous arches, and the radial vein, which serves the palms via the deep palmar...
 01:19
Bones of the Upper Limb: Humerus
 01:15
Bones of the Upper Limb: Ulna
 01:09
Bones of the Upper Limb: Radius
The radius has a nail-shaped head, and a...
 01:30
Application of Integration: Problem Solving