Related Experiment Video
Updated: Jan 21, 2026
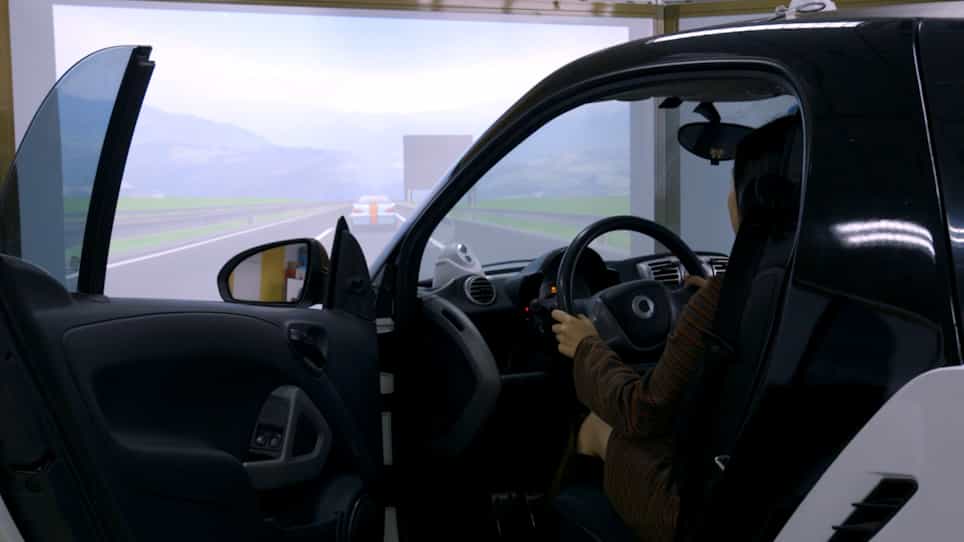
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Improvement of driver active interventions during automated driving by displaying trajectory pointers-A driving
Sayaka Ono1, Haruto Sasaki1, Hitoshi Kumon2
1a Automated Driving & Advanced Safety System Development Division, Toyota Motor Corporation , Toyota , Japan.

Abstract:
Objective: The handover of vehicle control from automated to manual operation is a critical aspect of interaction between drivers and automated driving systems (ADS). In some cases, it is possible that the ADS may fail to detect an object. In this event, the driver must be aware of the situation and resume control of the vehicle without assistance from the system. Consequently, the driver must fulfill the following 2 main roles while driving: (1) monitor the vehicle trajectory and surrounding traffic environment and (2) actively take over vehicle control if the driver identifies a potential issue along the trajectory. An effective human-machine interface (HMI) is required that enables the driver to fulfill these roles. This article proposes an HMI that constantly indicates the future position of the vehicle. Methods: This research used the Toyota Dynamic Driving Simulator to evaluate the effect of the proposed HMI and compares the proposed HMI with an HMI that notifies the driver when the vehicle trajectory changes. A total of 48 test subjects were divided into 2 groups of 24: One group used the HMI that constantly indicated the future position of the vehicle and the other group used the HMI that provided information when the vehicle trajectory changed. The following instructions were given to the test subjects: (1) to not hold the steering wheel and to allow the vehicle to drive itself, (2) to constantly monitor the surrounding traffic environment because the functions of the ADS are limited, and (3) to take over driving if necessary. The driving simulator experiments were composed of an initial 10-min acclimatization period and a 10-min evaluation period. Approximately 10 min after the start of the evaluation period, a scenario occurred in which the ADS failed to detect an object on the vehicle trajectory, potentially resulting in a collision if the driver did not actively take over control and manually avoid the object. Results: The collision avoidance rate of the HMI that constantly indicated the future position of the vehicle was higher than that of the HMI that notified the driver of trajectory changes, χ2 = 6.38, P < .05. The steering wheel hands-on and steering override timings were also faster with the proposed HMI (t test; P < .05). Conclusions: This research confirmed that constantly indicating the position of the vehicle several seconds in the future facilitates active driver intervention when an ADS is in operation.
More Related Videos
Related Concept Videos
 01:37
Energy to Drive Translocation
Generally, polypeptides are unfolded by two distinct...
 02:15
M-Cdk Drives Transition Into Mitosis
Cyclin-dependent kinases, or Cdks, work in concert with cyclins to control cell cycle transitions. M-Cdk, a complex of Cdk1 bound to M cyclin, is a well-known example of this coordinated control that drives the transition from the G2 to the M phase.
M cyclin...
 01:27
Drive-Reduction Theory: Push Theory of Motivation
 01:03
Nursing Interventions I: Taxonomy of Nursing Interventions
A nursing intervention is a treatment or action based on scientific concepts and knowledge from the nursing, behavioral, and physical sciences. Identifying and prioritizing nursing interventions based on the desired outcome...
 01:29
Nursing Interventions II: Selecting and Classifying the Nursing Interventions
 01:30
Community Based Intervention
Foundations of Community Mental Health Programs
Central to the success of community-based interventions is the...