Related Experiment Video
Updated: Sep 14, 2026

Automation of Mode Locking in a Nonlinear Polarization Rotation Fiber Laser through Output Polarization Measurements
Published on: February 28, 2016
Quasi-Synchronization of Discrete-Time Lur'e-Type Switched Systems With Parameter Mismatches and Relaxed PDT

Abstract:
This paper investigates the problem of quasi-synchronization for a class of discrete-time Lur'e-type switched systems with parameter mismatches and transmission channel noises. Different from the previous studies referring to the persistent dwell-time (PDT) switching signals, the average dwell-time (ADT) constraints combined with the PDT are considered simultaneously in this paper to relax the limitation of dwell-time requirements and to improve the flexibility of the PDT switching signal design. By virtue of the semi-time-varying (STV) Lyapunov function, the synchronization criteria for transmitter-receiver systems in a switched version are obtained to satisfy a prescribed synchronization error bound. An estimate of the synchronization error bound is provided via the reachable set approach and, further, an explicit description of the error bounds is given. Then, sufficient conditions on the existence of STV observers are derived with a predetermined error bound, and the corresponding observer gains are calculated via solving a group of linear matrix inequalities. Finally, the effectiveness and validness of the developed theoretical results are demonstrated via a numerical example.

Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from the...
 01:30
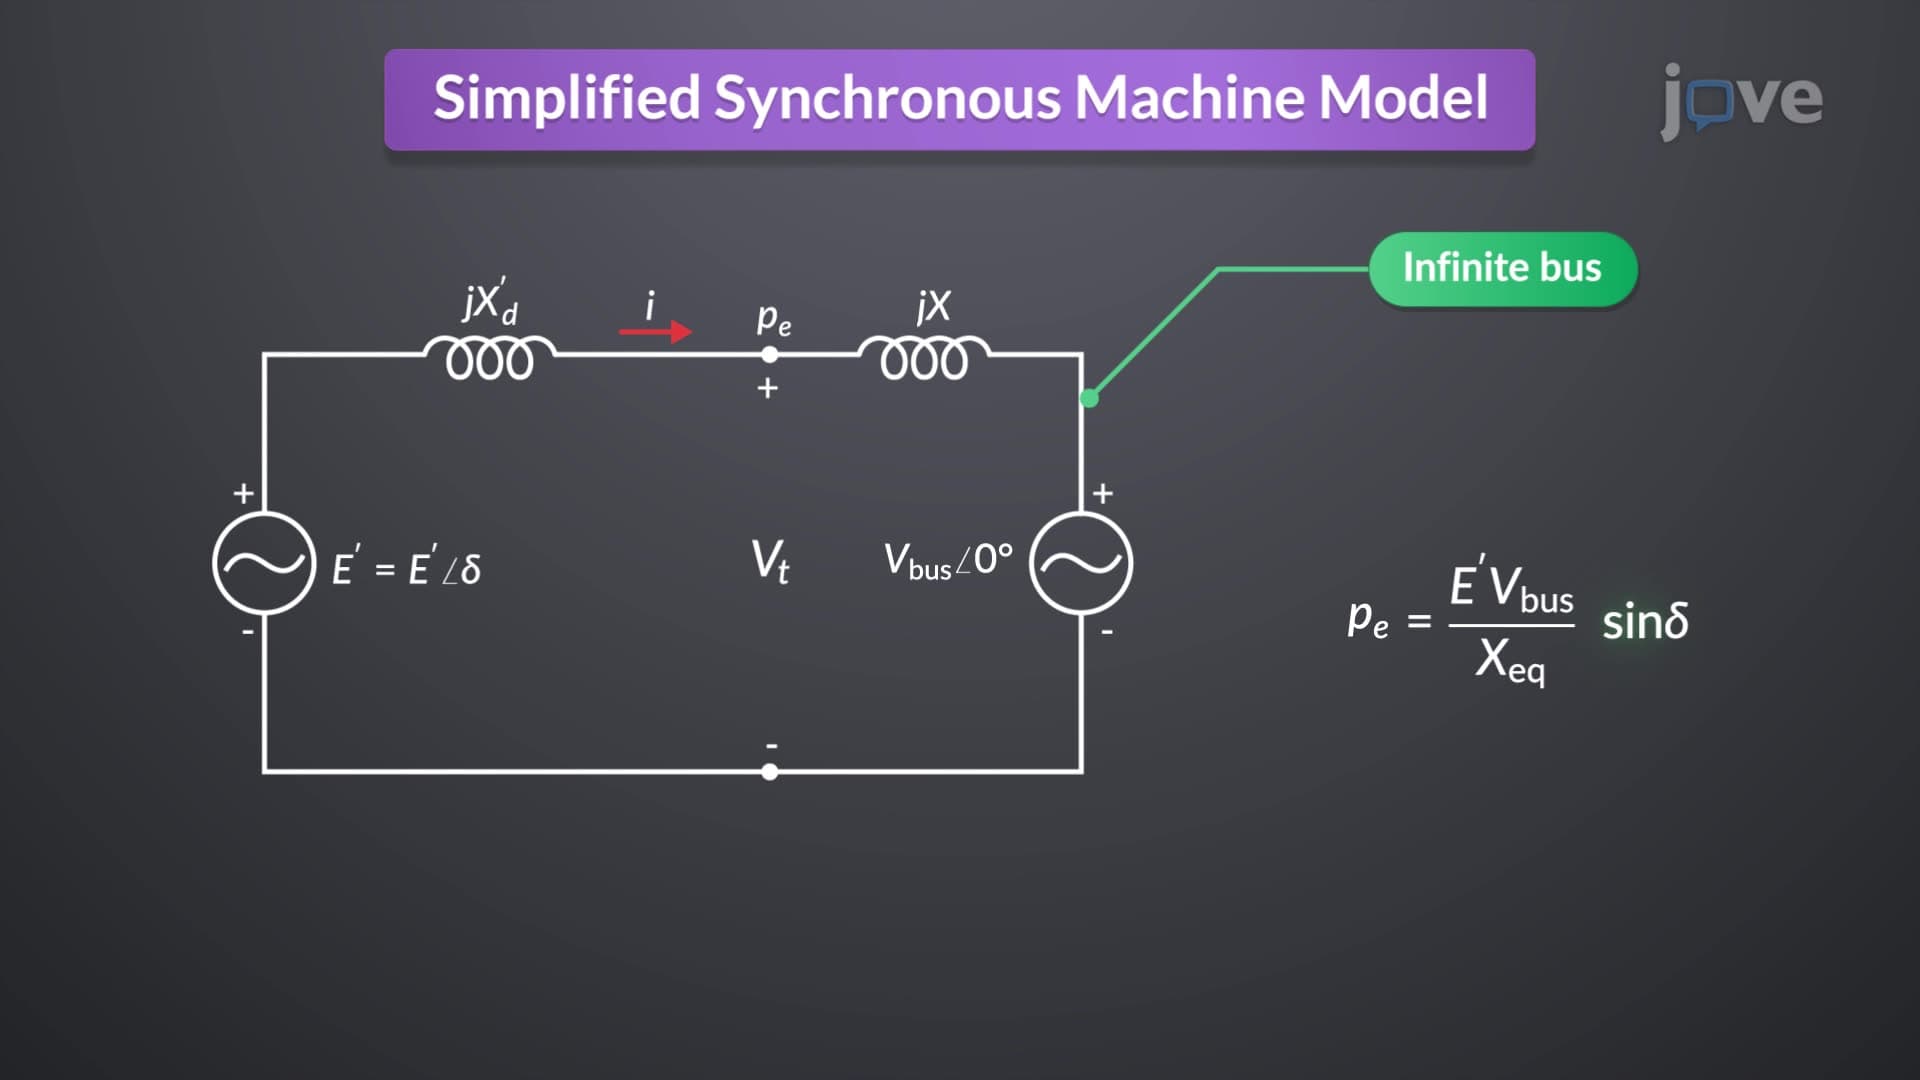
Simplified Synchronous Machine Model
In this model, each generator is connected to a...