Related Experiment Video
Updated: Sep 26, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Frequency-Shaped Natural Actor-Critic for Online Optimal Tracking Control of Unknown Stochastic Systems

Abstract:
In industrial and robotic control tasks, reference trajectories often concentrate within specific frequency bands, whereas noise and disturbances may dominate other frequency ranges. Conventional reinforcement learning (RL) methods typically employ time-domain cost functions that weight all frequency components equally, leading to excessive sensitivity to high-frequency noise and limited tracking accuracy. This limitation restricts the applicability of RL to time-varying trajectory-tracking problems. To address this issue, we propose a frequency-shaped implicit online natural actor-critic (FS-IONAC) approach that incorporates frequency-domain specifications into the RL framework. First, we theoretically show that the standard quadratic cost function inherently assigns uniform weighting across the frequency spectrum. To overcome this drawback, we introduce stable shaping filters centered on task-relevant frequencies and embed their dynamics into an augmented Markov decision process (MDP), thereby inducing a frequency-shaped objective while preserving the Markov property. Then, we develop a model-free natural actor-critic algorithm with implicit critic updates to learn the optimal tracking policy online without requiring knowledge of the system dynamics. We further prove that the proposed algorithm converges almost surely under two-timescale stochastic approximation conditions. The effectiveness of FS-IONAC is validated through illustrative examples, including a robotic control task, where it achieves improved tracking performance and sample efficiency compared with conventional baselines.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Control Systems
At the heart...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
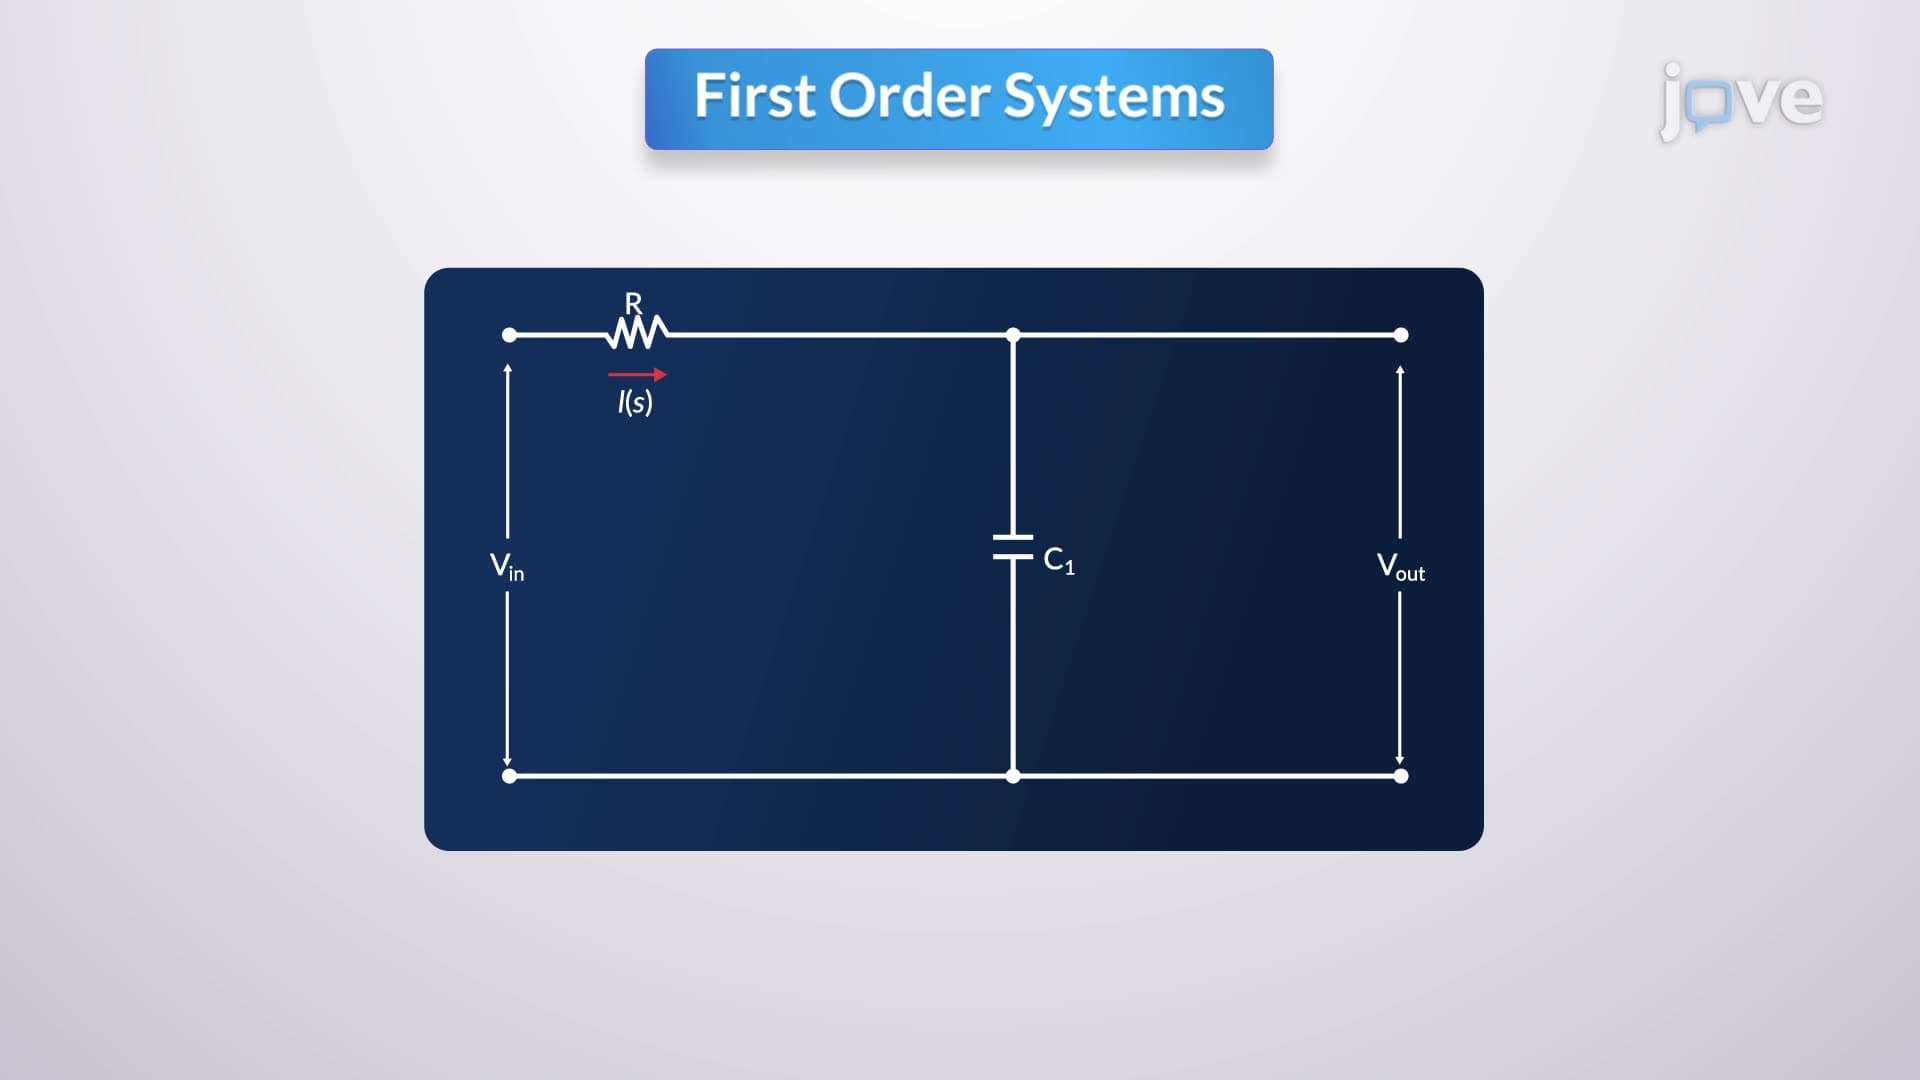
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...