Related Experiment Video
Updated: Jan 19, 2026

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Fully distributed containment control for second-order multi-agent systems with communication delay
Fu-Yong Wang1, Yuan-Hua Ni1, Zhong-Xin Liu1
1College of Artificial Intelligence, Nankai University, Tianjin, 300350, China; Tianjin Key Laboratory of Intelligent Robotics, Nankai University, Tianjin, 300350, China.

Abstract:
In this paper, fully distributed containment control problems of multi-agent systems with double-integrator dynamics are investigated under directed topologies. For the cases with and without communication delay, two new fully distributed control protocols are designed, which do not need any global information of the communication topology graph. Necessary and sufficient conditions are obtained to ensure the solvability of the considered containment control problems. Particularly, for the case with communication delay, the critical value of the maximum allowable time delay of containment control is found. Finally, numerical simulations are presented to demonstrate the effectiveness of the theoretical results.


Related Concept Videos
 01:18
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:10
Propagation of Uncertainty from Systematic Error
 00:59
Propagation of Uncertainty from Random Error
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:21
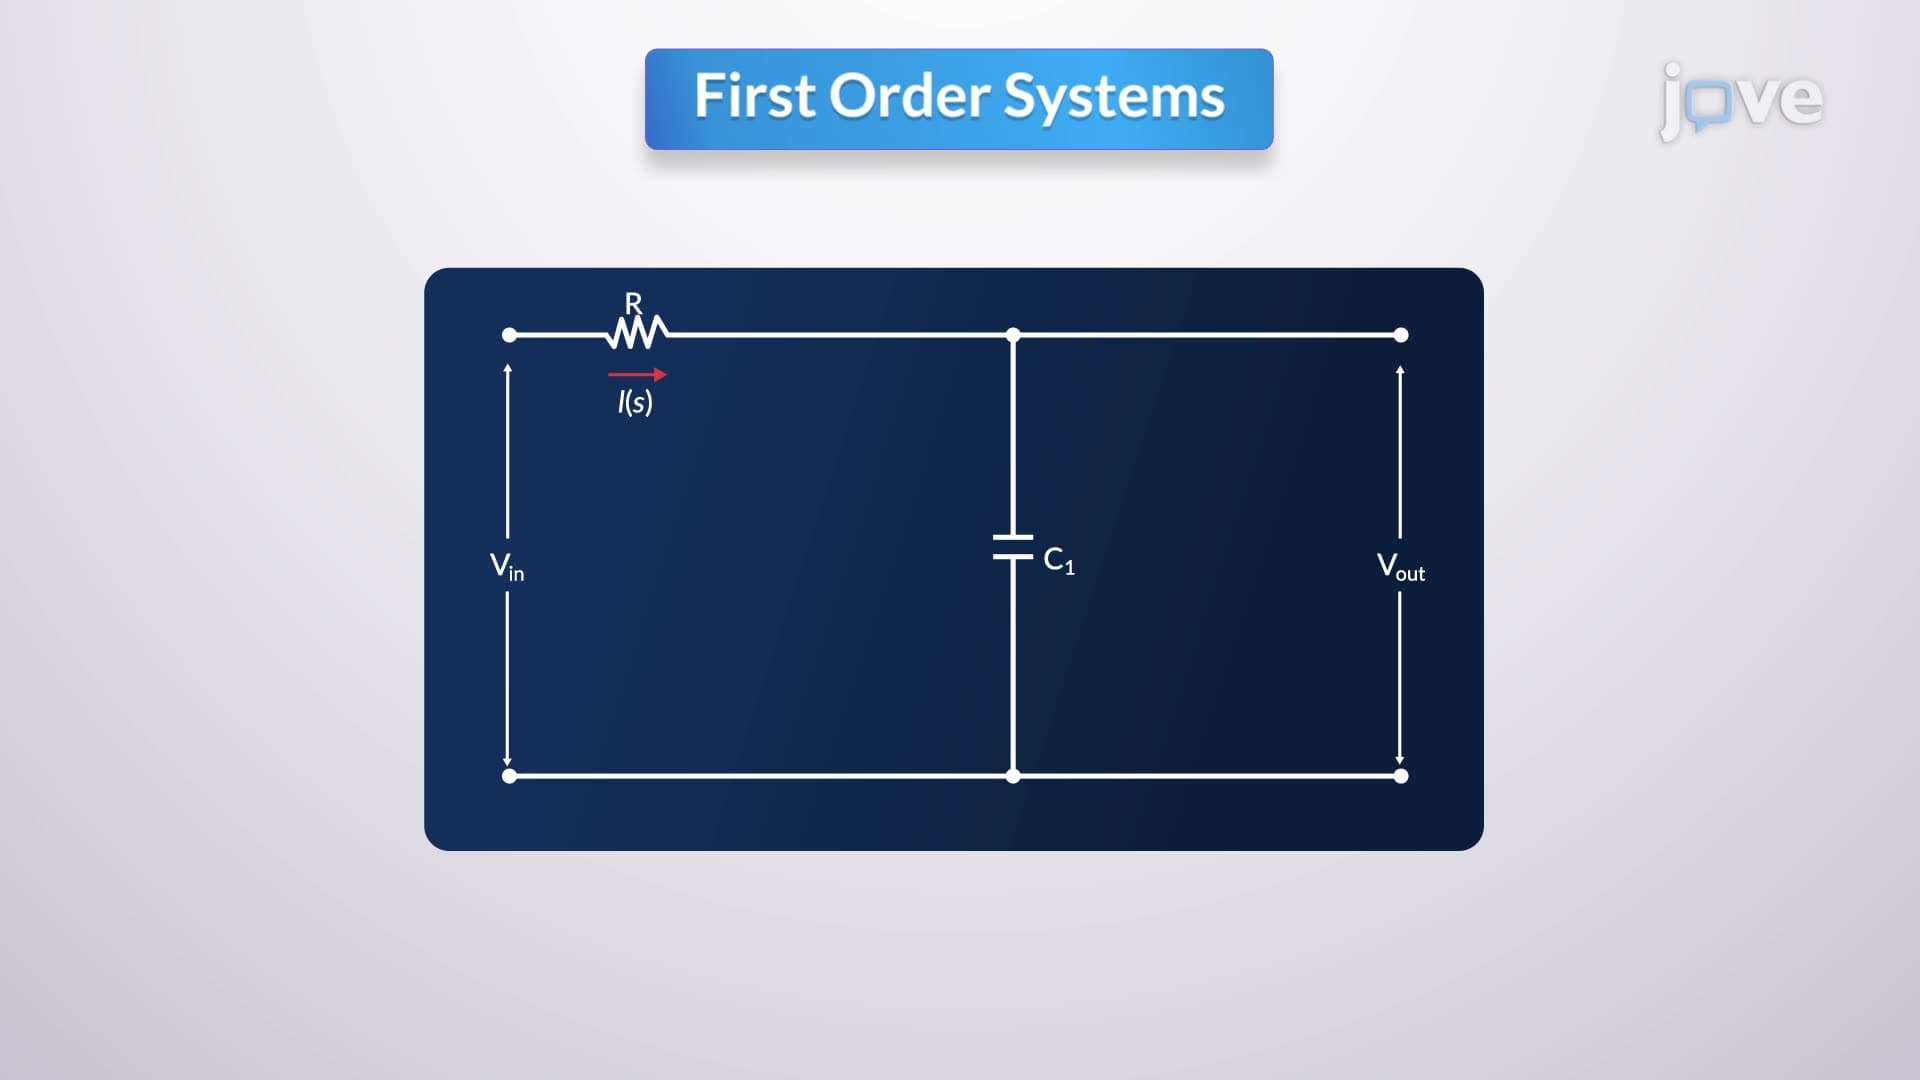
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...